
在肌肉骨模拟中建模膜部稳定性:与实体接触力进行验证研究

概括
在研究肩关节稳定性时,这项研究发现,在肌肉骨模拟中,基于约束的模型与基于约束的模型相比,基于罚款的模型更准确地预测了在腺腔内的腺接触力.
科学领域:
- 生物力学 生物力学
- 肌肉骨系统的建模
- 整形外科 整形外科 整形外科
背景情况:
- 模拟中的肌肉冗余往往导致不准确的肩接触力预测.
- 现有的模型很难保持关节关节的稳定性,因为力量从关节腔中出来.
研究的目的:
- 为了评估肌肉骨模拟的各种腺稳定性配方.
- 将预测的接触力与体内测量进行比较.
主要方法:
- 测试了基于约束和惩罚的稳定性配方,与Orthoload数据集相比.
- 在体内利用了从举抬起的膜部接触力数据.
- 评估力方向的准确性与状腔相对.
主要成果:
- 大多数配方在接触力大小上都显示出很好的一致性.
- 最严格的约束模型预测了腺体外的力量.
- 连续的惩罚模型产生了更准确的力方向在状腔内.
结论:
- 处罚配方提供了一个更准确和合理的方法来预测膜部接触力.
- 连续惩罚模型可以提高模拟保真度,以提高肩关节的稳定性.
相关概念视频
 01:21
Rigid Body Equilibrium Problems - II
7.9K
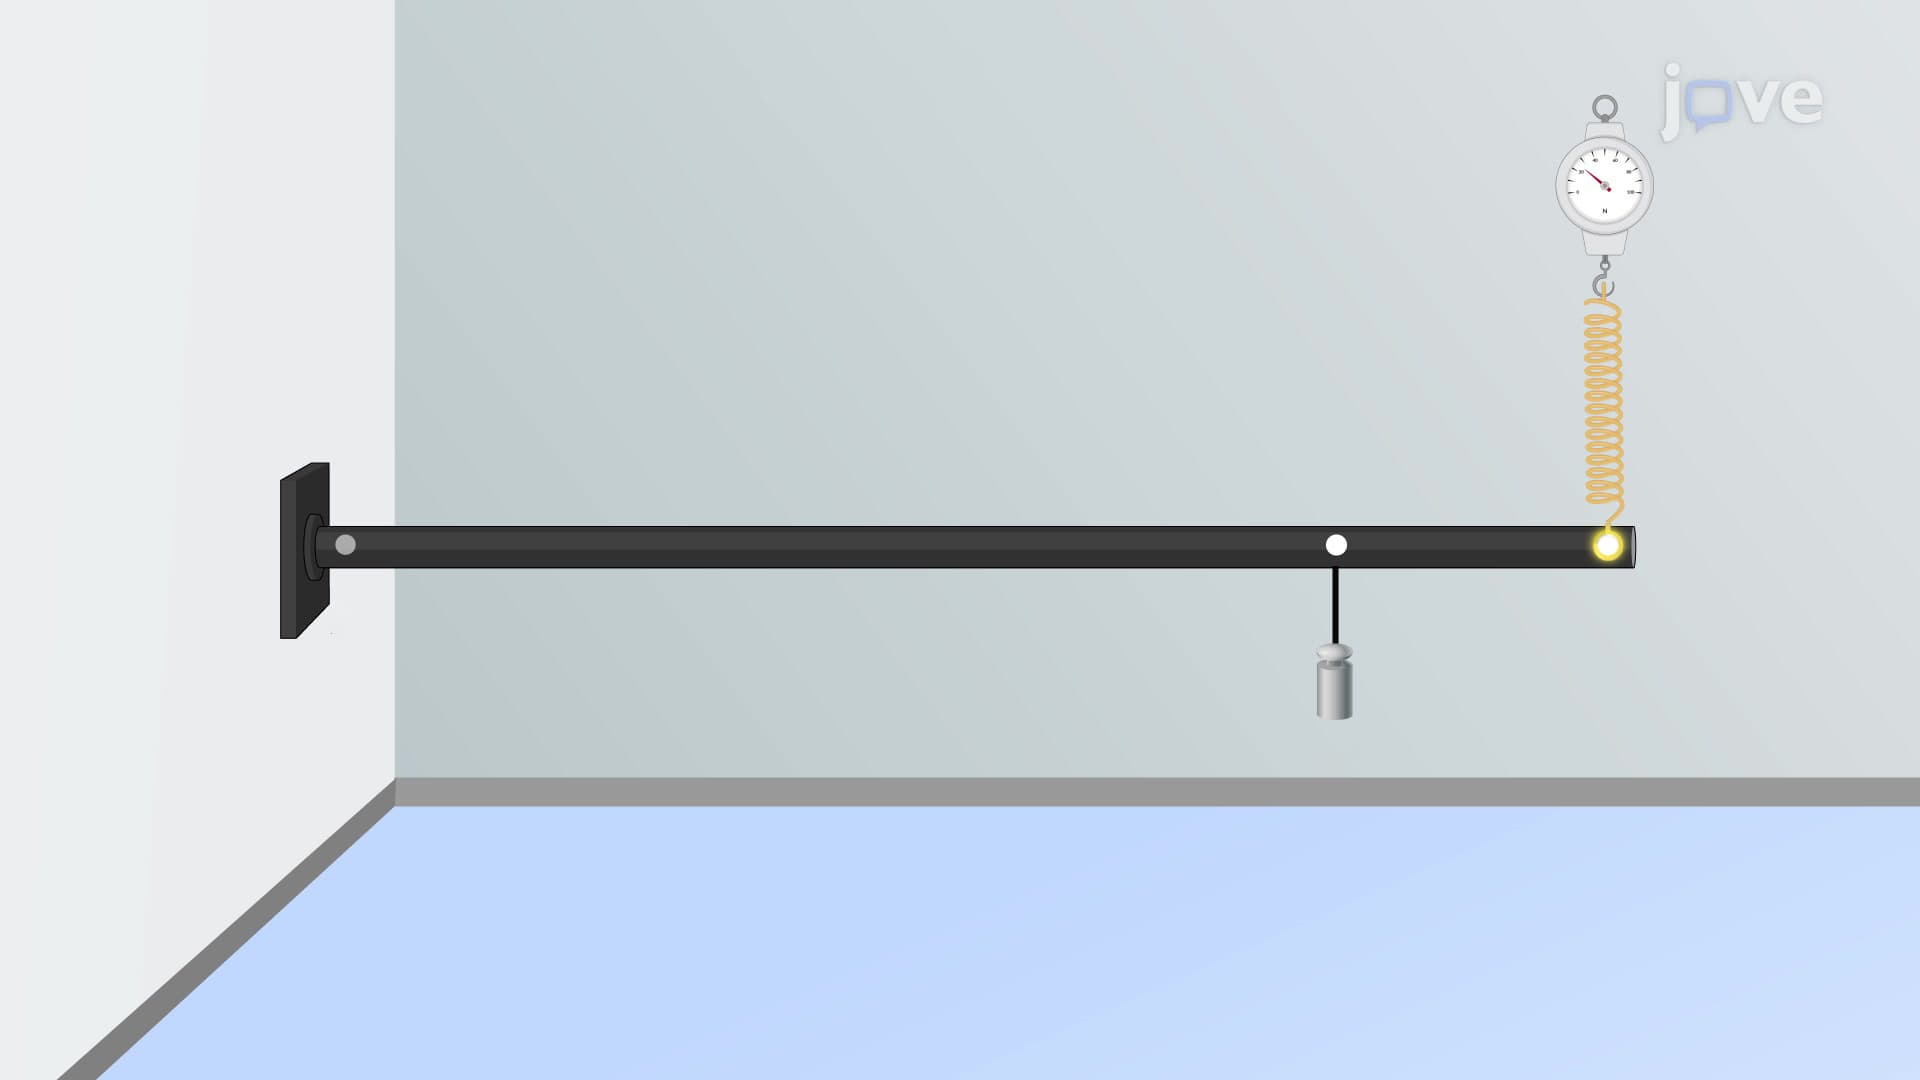
A rigid body is in static equilibrium when the net force and the net torque acting on the system are equal to zero.
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
7.9K
 00:49
Rigid Body Equilibrium Problems - I
5.3K
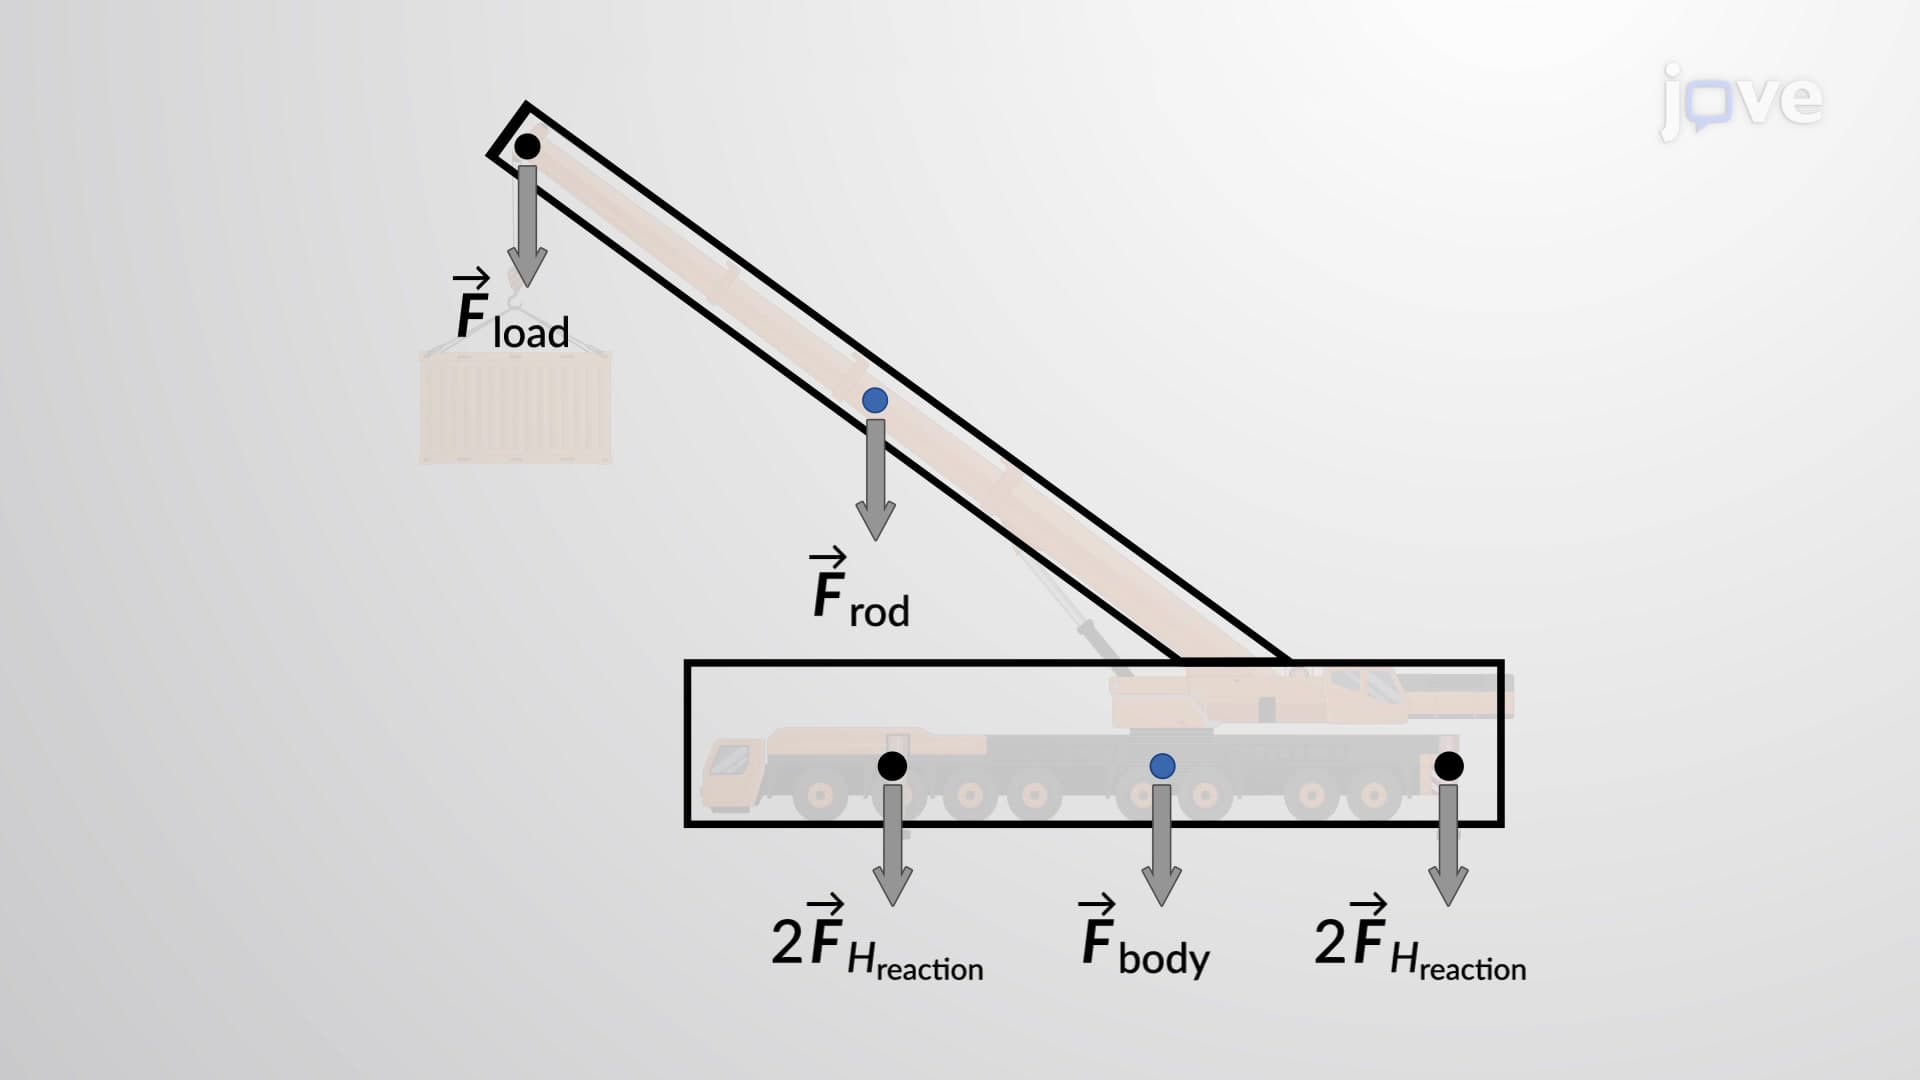
A rigid body is said to be in static equilibrium when the net force and the net torque acting on the system is equal to zero. To solve for rigid body equilibrium problems, do the following steps.
5.3K