
雅典:专业的自动追踪手,没有注释
Daanish M Mulla1, Mario Costantino2, Erez Freud2,3,4
1School of Kinesiology & Health Science, York University, Toronto, Ontario, Canada.
Journal of neurophysiology
|November 21, 2025

概括
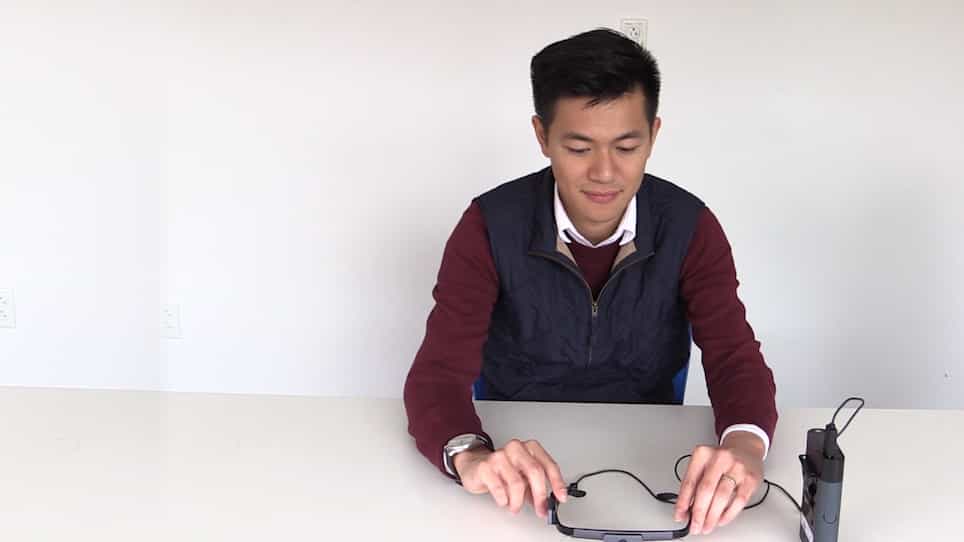
新的Python工具箱ATHENA为自然主义行为提供了准确的3D无标记手跟踪. 这种自动化解决方案降低了成本和参与者的负担,使得更多生态有效的运动控制研究成为可能.
科学领域:
- 生物力学和运动控制
- 人与计算机的交互
- 机器人技术 机器人技术 机器人技术
背景情况:
- 基于标记器的动作捕捉用于研究手的行为是昂贵的,耗时的,并限制了参与者的运动.
- 现有的无标记物姿势估计解决方案对于精确的手物操纵任务缺乏验证.
- 需要准确,易于使用的工具来进行自然主义的手动行为分析.
研究的目的:
- 介绍自动跟踪手无注释 (ATHENA),一个开源的Python工具箱用于3D无标记手跟踪.
- 通过基于行业标准的标记系统 (OptiTrack) 来验证ATHENA的准确性和可靠性.
- 为了证明ATHENA在促进生态有效的运动控制和学习研究方面的实用性.
主要方法:
- 开发了ATHENA,这是一个基于Python的工具箱,用于无标记的3D手跟踪.
- 同时使用ATHENA和OptiTrack系统记录手动力学.
- 比较动力学变量 (握柄孔径,手腕速度等) 在单手,双手和对象操纵任务中.
主要成果:
- 雅典号显示与OptiTrack具有很高的时空空间一致性 (R2 > 0.90).
- 在关键动力学变量 (<1厘米,<4厘米/秒,<5°-10°) 中观察到低根平均平方差异.
- ATHENA保留了试验对试验的动力学变异性,产生与基于标记的方法相同的科学结论.
结论:
- 雅典是一个准确,自动化和用户友好的平台,用于3D无标记手跟踪.
- 该工具箱显著降低了与移动捕捉相关的财务和时间成本.
- 雅典 (ATHENA) 能够对自然主义的手动行为和人类的灵巧性进行更多生态有效的研究.

相关概念视频
 01:24
Absolute Motion Analysis- General Plane Motion
756
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
756
 01:25
Relative Motion Analysis using Rotating Axes
1.1K
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
1.1K
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
844
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
844
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
1.0K
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
1.0K