

人类双脚的机器人操纵揭示了空间和时间的重叠内部表示
Paul Belzner1, Patrick A Forbes2, Calvin Kuo3
1School of Kinesiology, University of British Columbia, Vancouver, BC, Canada.
Science robotics
|November 26, 2025

概括
有效的双脚平衡控制整合了关于运动动态的过去感官信息. 机器人虚拟化揭示了如何改变身体物理,如惯性和粘度,影响平衡感知和稳定性,特别是与传感运动延迟.
科学领域:
- 神经科学是一个神经科学.
- 生物力学 生物力学
- 机器人技术 机器人技术 机器人技术
背景情况:
- 双脚姿势控制取决于整合过去的感觉数据来预测运动动态.
- 了解平衡的空间和时间属性之间的相互作用对于人类运动科学至关重要.
研究的目的:
- 研究空间 (惯性,粘度) 和时间 (感官运动延迟) 属性如何在人类平衡控制中相互作用.
- 探索潜在的感知和适应改变的身体动态的神经机制.
主要方法:
- 利用机器人虚拟化系统来操纵健康参与者的惯性,粘度和感觉运动延迟.
- 在各种虚拟物理条件下评估姿势稳定性和参与者对感知身体动态的调整.
主要成果:
- 改变惯性和粘度显著影响了姿势振荡和平衡极限,模仿感觉运动延迟.
- 参与者调整了他们的运动控制策略,调整了惯性和粘度的增加,以弥补感知或实际的延迟.
- 用特定的机器人参数来弥补200毫秒的延迟,提高了原始参与者的平衡稳定性.
结论:
- 机器人虚拟化是一种强大的工具,用于剖析双脚平衡中复杂的感觉运动相互作用.
- 神经系统动态调整身体物理的内部模型,以保持稳定,尽管时间干扰.
- 研究结果提供了关于感觉运动缺陷的见解,以及平衡障碍的潜在治疗策略.


相关概念视频
 01:14
Mechanical Efficiency of Real Machines
1.6K
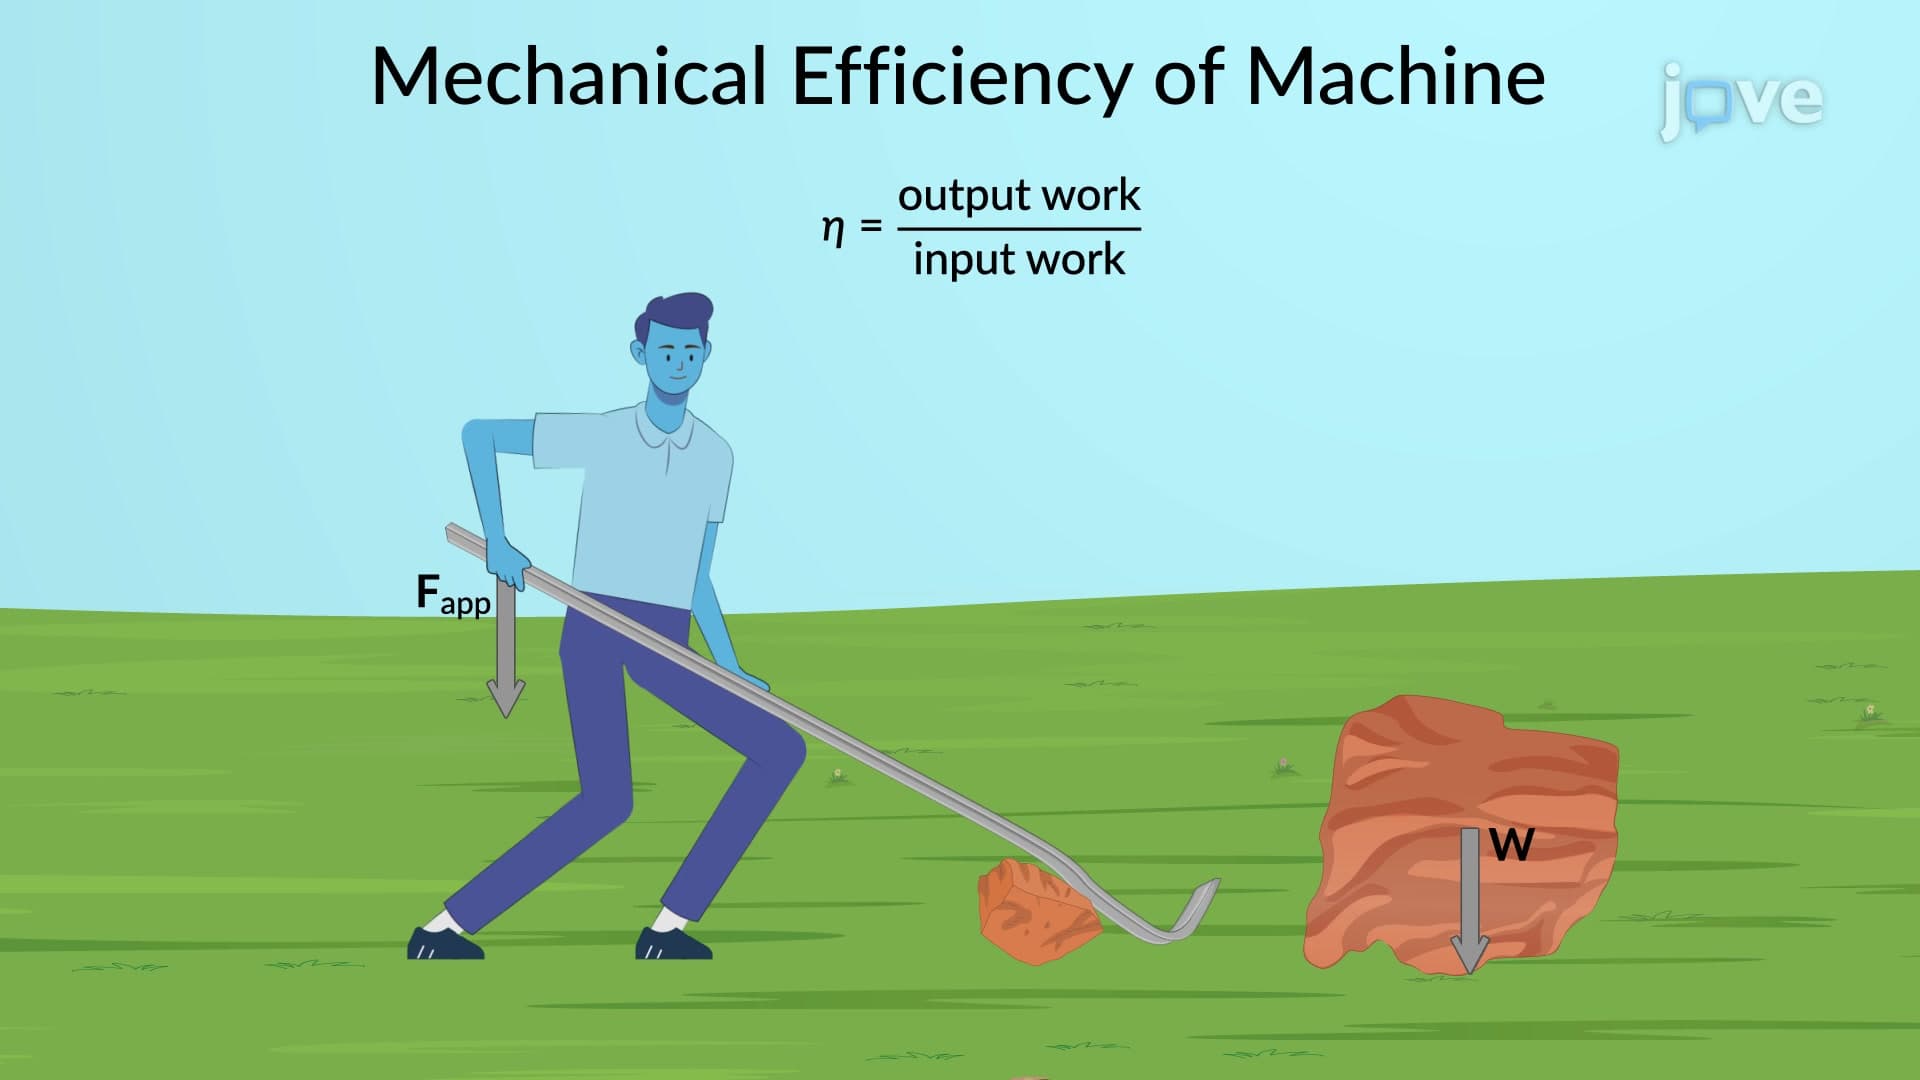
The mechanical efficiency of a machine is a fundamental concept that describes how effectively a machine can convert input work into output work. According to this concept, the efficiency of a machine is equal to the ratio of the output work to the input work. An ideal machine, meaning a machine that has no energy losses, has an efficiency of one. This implies that the input work and the output work are equal.
However, in reality, no machine can be truly ideal, and all of them experience some...
However, in reality, no machine can be truly ideal, and all of them experience some...
1.6K
 01:24
One-Degree-of-Freedom System
1.0K
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
1.0K
 01:24
Muscle Coordination and Action
3.8K
Muscle coordination is a complex and finely tuned process essential for smooth and purposeful movements like flexion, extension, adduction, abduction, and rotation. The human body orchestrates the actions of various muscles working in concert, each with a specific role. Four functional types describe how muscles work together: agonist, antagonist, synergist, and fixator.
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
Agonists
Agonist muscles, often called prime movers, are the primary muscles responsible for producing a specific movement....
3.8K
 01:22
Mechanical Systems
901
Mechanical systems are analogous to to electrical networks where springs and masses play similar roles to inductors and capacitors, respectively. A viscous damper in mechanical systems functions similarly to a resistor in electrical networks, dissipating energy. The forces acting on a mass in such systems include an applied force in the direction of motion, counteracted by forces from the spring, a viscous damper, and the mass's acceleration. This interplay of forces is mathematically...
901
 01:24
Sequence Networks of Rotating Machines
592
A Y-connected synchronous generator, grounded through a neutral impedance, is designed to produce balanced internal phase voltages with only positive-sequence components. The generator's sequence networks include a source voltage that is exclusively in the positive-sequence network. The sequence components of line-to-ground voltages at the generator terminals illustrate this configuration.
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
592