

基于角度的安全几何消除 (SAGE) 用于微机器人路径规划
Youngji Ko1,2,3, Seung-Hyun Im1,2,3, Hana Choi3
1Department of AI Convergence, Chonnam National University, 77 Yongbong-ro, Buk-gu, Gwangju 61186, Republic of Korea.
Micromachines
|November 27, 2025

概括
基于安全角度的几何消除 (SAGE) 是微机器人导航的新算法. 它在复杂的环境中产生高效,无碰撞的路径,提高安全性和速度.
科学领域:
- 机器人和自动化 机器人和自动化
- 微型机器人技术的发展
- 路径规划算法 路径规划算法
背景情况:
- 微机器人在狭窄空间中的导航需要路径规划,以提高效率和避免碰撞.
- 现有的方法通常通过在简化过程中忽视墙壁边界来创建容易碰撞的路径.
- 需要强大的算法来保证微机器人的无碰撞轨迹.
研究的目的:
- 引入基于安全角度的几何消除 (SAGE),用于微机器人导航的路径简化算法.
- 为了从像素级最短的路径实现实时,无碰撞的轨迹生成.
- 提高微机器人在受限制环境中的操作效率和安全性.
主要方法:
- SAGE是一个单通算法,它将像素级路径简化为低复杂度的轨迹.
- 它分析了三重点 (pi,pi+1,pi+2),根据转角值或直截面无碰撞检查删除了中间点.
- 该算法与Dijkstra和RRT计划器集成,并与Ramer-Douglas-Peucker算法进行计算比较.
主要成果:
- 与传统方法相比,SAGE实现了大约5%的路径长度缩短和20%的转成本降低.
- 该算法显示,在复杂的迷宫和血管环境中,碰撞率为0%.
- 计算性能与拉默-道格拉斯-皮克克算法相当.
结论:
- SAGE为高速,无碰撞的微机器人导航提供了高效可靠的框架.
- 该算法的有效性通过定量分析和实验微机器人演示来验证.
- SAGE适用于芯片实验室,化学反应和分子诊断系统中的自动化.


相关概念视频
 01:25
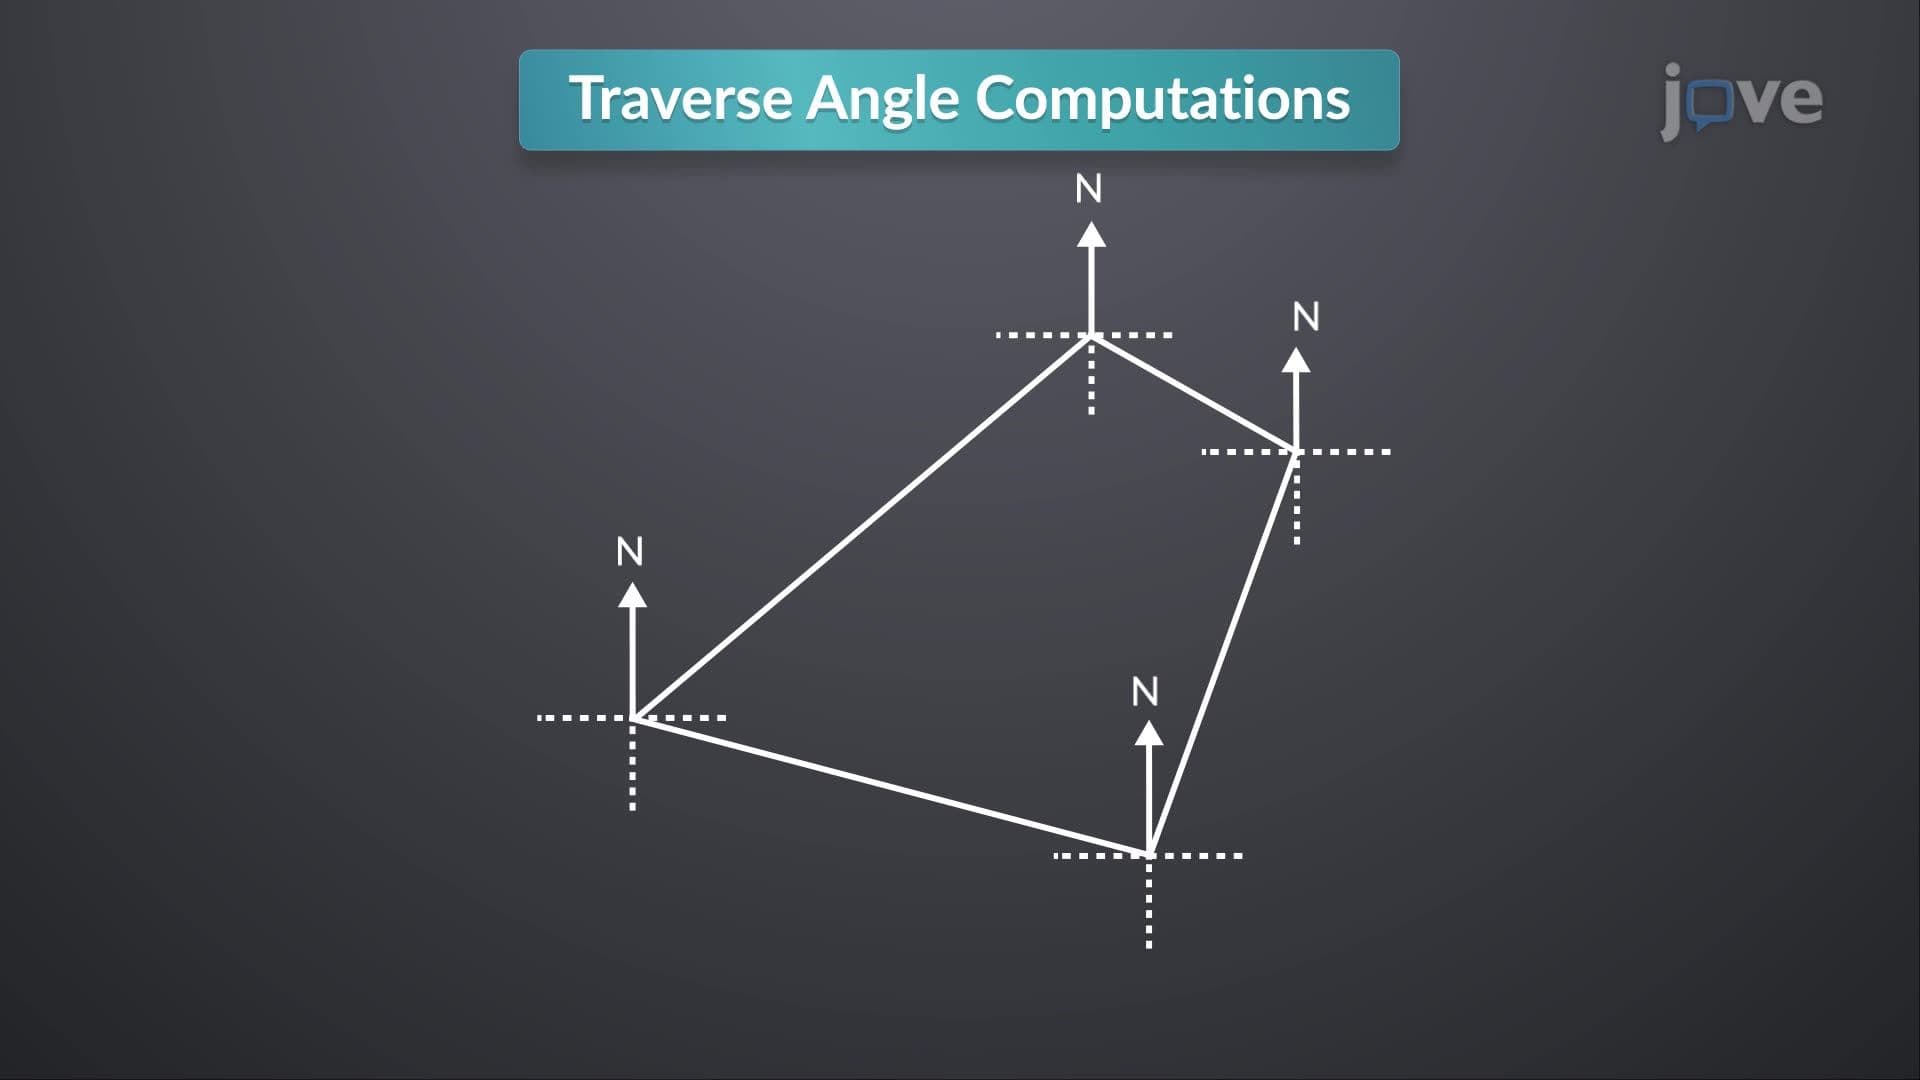
Design Example: Traverse Angle Computations
290
Traverse angle computations are a critical component of surveying, used to compute the internal angles within a closed traverse. A traverse consists of a series of connected lines forming a closed loop, often used for land boundary delineation or mapping. Calculating the internal angles ensures accuracy in the traverse geometry and is essential for checking survey data integrity.The process begins with known azimuths and bearings of the traverse sides. Internal angles at each vertex are...
290
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
685
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
685
 01:13
Angle of Twist: Problem Solving
736
An electric motor applies a torque of 700 N·m to an aluminum shaft, triggering a stable rotation. Two pulleys, B and C, are subjected to torques of 300 N·m and 400 N·m, respectively. The modulus of rigidity is provided as 25 GPa. With the knowledge of the length and diameter of each segment, the twist angle between the two pulleys can be computed. First, a section cut is made between pulleys B and C, and the cut cross-section is analyzed using a free-body diagram. Given that the torque...
736