
在暴露下的陀螺仪MEMS噪声的分数顺序识别
Dominik Sierociuk1,2, Michal Macias1,2, Konrad Andrzej Markowski1,2
1Institute of Control and Industrial Electronics, Warsaw University of Technology, ul. Koszykowa 75, 00-662 Warsaw, Poland.
Sensors (Basel, Switzerland)
|November 27, 2025

概括
这项研究分析了暴露于的MEMS惯性传感器中的陀螺仪噪声,使用分数计算来识别噪声模型. 结果详细介绍了暴露下噪声演变和传感器行为变化.
科学领域:
- 传感器技术 传感器技术
- 惯性导航系统 惯性导航系统
- MEMS 设备 MEMS 设备
背景情况:
- 惯性导航传感器对于导航系统至关重要.
- MEMS技术是现代惯性传感器的基础.
- 诸如气体暴露等环境因素会影响传感器性能.
研究的目的:
- 在暴露下分析和识别LSM06DSO32惯性传感器中的陀螺仪噪声.
- 为了研究陀螺仪噪声的偏差和偏差.
- 用微数计算来确定噪声模型的顺序.
主要方法:
- 收集的传感器数据在暴露期间的不同间隔.
- 应用差异和相关性分析来估计噪声模型的顺序.
- 使用分数式计算来识别噪音.
- 检查了暴露后的传感器行为.
主要成果:
- 在长时间暴露于气下,特征的陀螺仪噪声演变.
- 确定了受影响的特定噪声模型.
- 由于暴露而导致的偏差和方差的量化变化.
- 在去除后评估传感器性能恢复.
结论:
- 暴露显著影响MEMS陀螺仪的噪声特征.
- 分数式计算为噪声模型识别提供了一种有效的方法.
- 了解噪音行为对于在环境压力下可靠的惯性导航至关重要.
相关概念视频
 01:14
NMR Spectrometers: Resolution and Error Correction
1.0K
When magnetic nuclei in a sample achieve resonance and undergo relaxation, the signal detected in NMR is an approximately exponential free induction decay. Fourier transform of an exponential decay yields a Lorentzian peak in the frequency domain. Lorentzian peaks in an NMR spectrum are defined by their amplitude, full width at half maximum, and position, where the peak width is governed by the spin-spin relaxation time alone. In real experiments, however, the applied magnetic field is rendered...
1.0K
 01:24
Gyroscope: Precession
5.3K
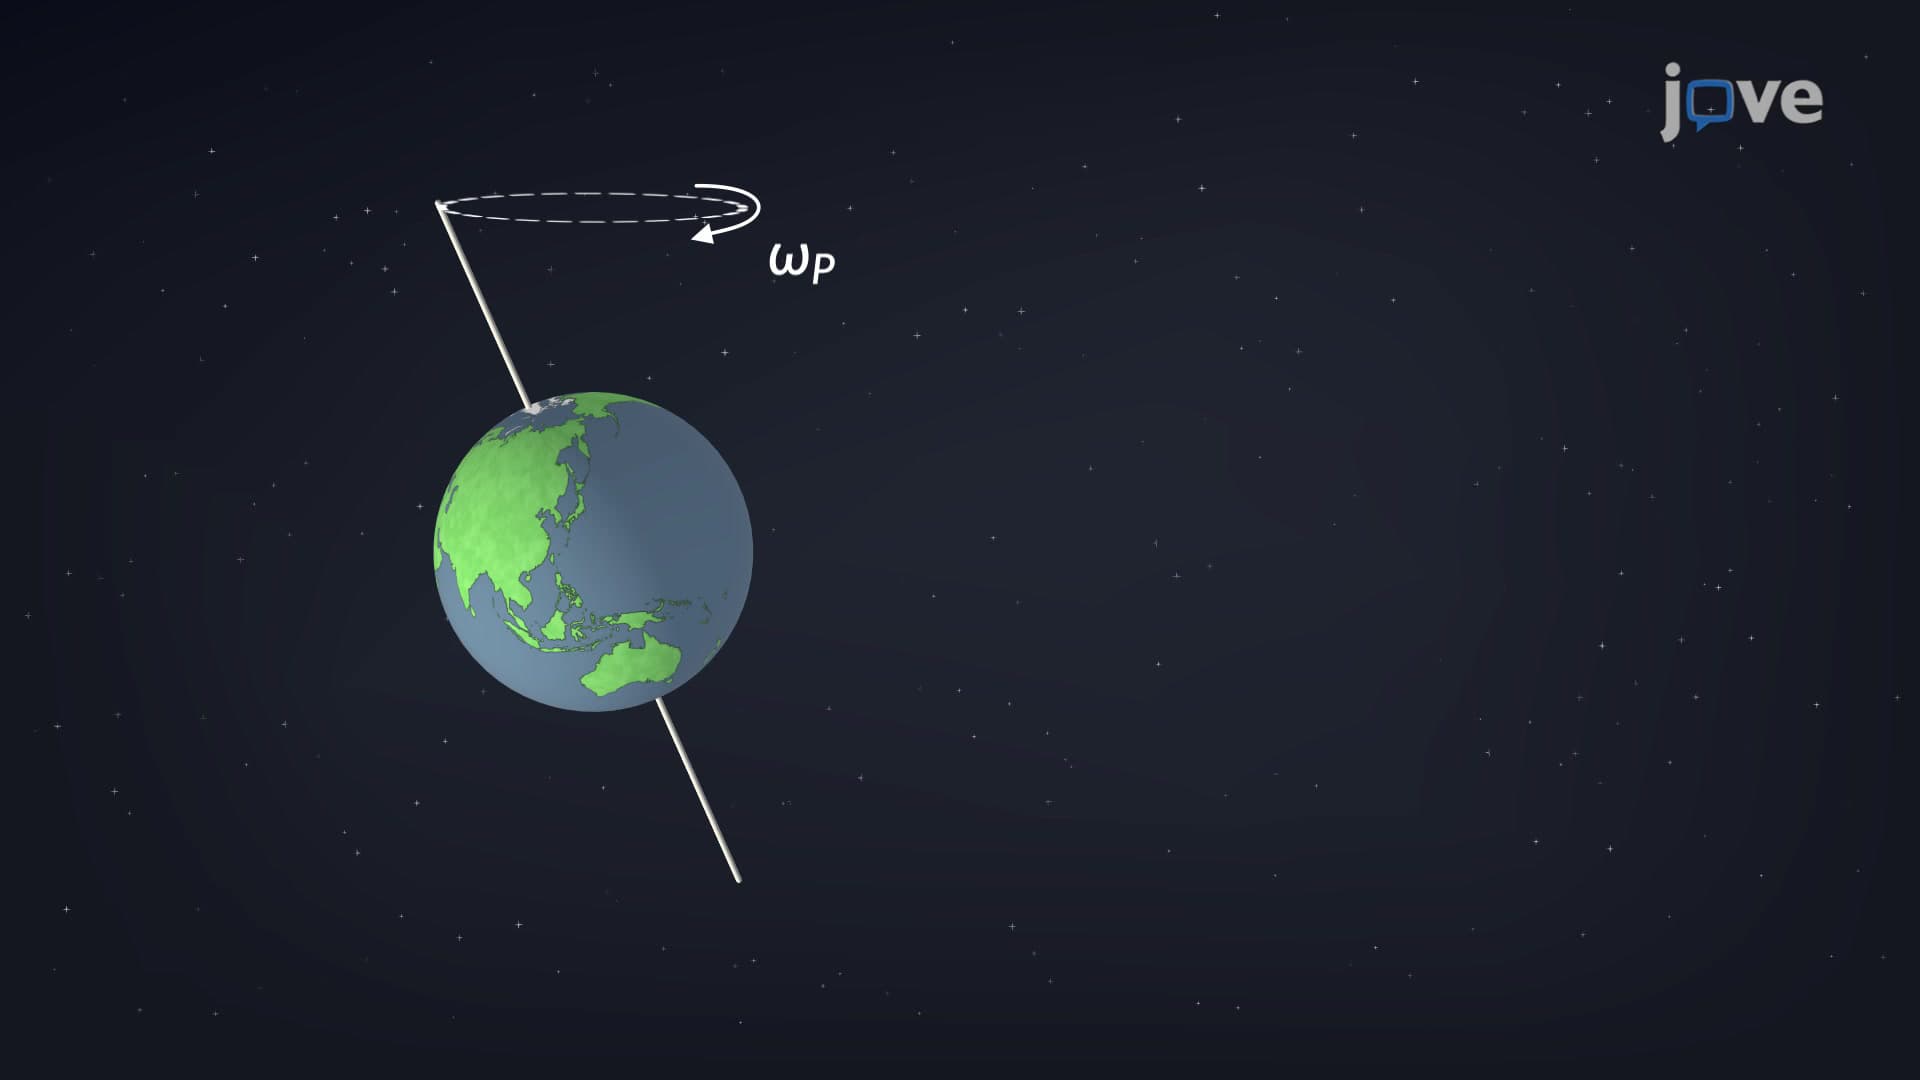
Precession can be demonstrated effectively through a spinning top. If a spinning top is placed on a flat surface near the surface of the Earth at a vertical angle and is not spinning, it will fall over due to the force of gravity producing a torque acting on its center of mass. However, if the top is spinning on its axis, it precesses about the vertical direction, rather than topple over due to this torque. Precessional motion is a combination of a steady circular motion of the axis and the...
5.3K