相关实验视频
Updated: Jan 10, 2026
06:54

Photorealistic Learned Landscapes for Augmented Reality
Published on: June 27, 2025
651
增强的3D高斯斯点用于真实场景的重建通过深度前置,自适应密集化,和denoising
Haixing Shang1,2,3, Mengyu Chen1, Kenan Feng1
1College of Geological Engineering and Geomatics, Chang'an University, Xi'an 710054, China.
Sensors (Basel, Switzerland)
|November 27, 2025

概括
这项研究增强了3D高斯喷涂 (3DGS) 以实现光现实的3D重建,提高了复杂场景的准确性和效率. 新的框架在具有挑战性的环境中表现出色,并提供实时染,使其适合智能城市和遗产保护.
科学领域:
- 计算机视觉 计算机视觉
- 三维重建的3D重建
- 这是一种摄影计量技术 (photogrammetry).
背景情况:
- 摄影现实的3D重建对于智慧城市和文化遗产至关重要.
- 现有的方法在复杂场景 (例如,反射表面,植被) 中难以获得准确性,效率和稳定性.
研究的目的:
- 提出一个增强的3D高斯三角裂纹 (3DGS) 框架.
- 在复杂的3D场景中提高重建精度,计算效率和稳定性.
主要方法:
- 集成了一个深度感知规范化模块,使用Depth-Anything V2进行几何信息化的优化.
- 实现了梯度驱动的自适应密集机制,以实现高效的高斯调整.
- 开发了一个基于邻居密度的方法来检测和过漂浮的文物.
主要成果:
- 在中等场景上实现了PSNR的34.15 dB和SSIM的0.9382的最先进的性能.
- 在1600x900分辨率下,实时染速度超过170FPS.
- 在具有挑战性的材料 (水,树叶) 上展示了卓越的概括性,并减少了过.
结论:
- 增强的3DGS框架显著提高了3D重建的质量和效率.
- 深度规范化和梯度敏感的适应对于性能增长至关重要.
- 最佳的输入分辨率缩放 (1/4-1/2) 平衡了保真性和效率,尽管大规模的内存消耗需要进一步研究.
相关概念视频
 01:20
Deconvolution
532
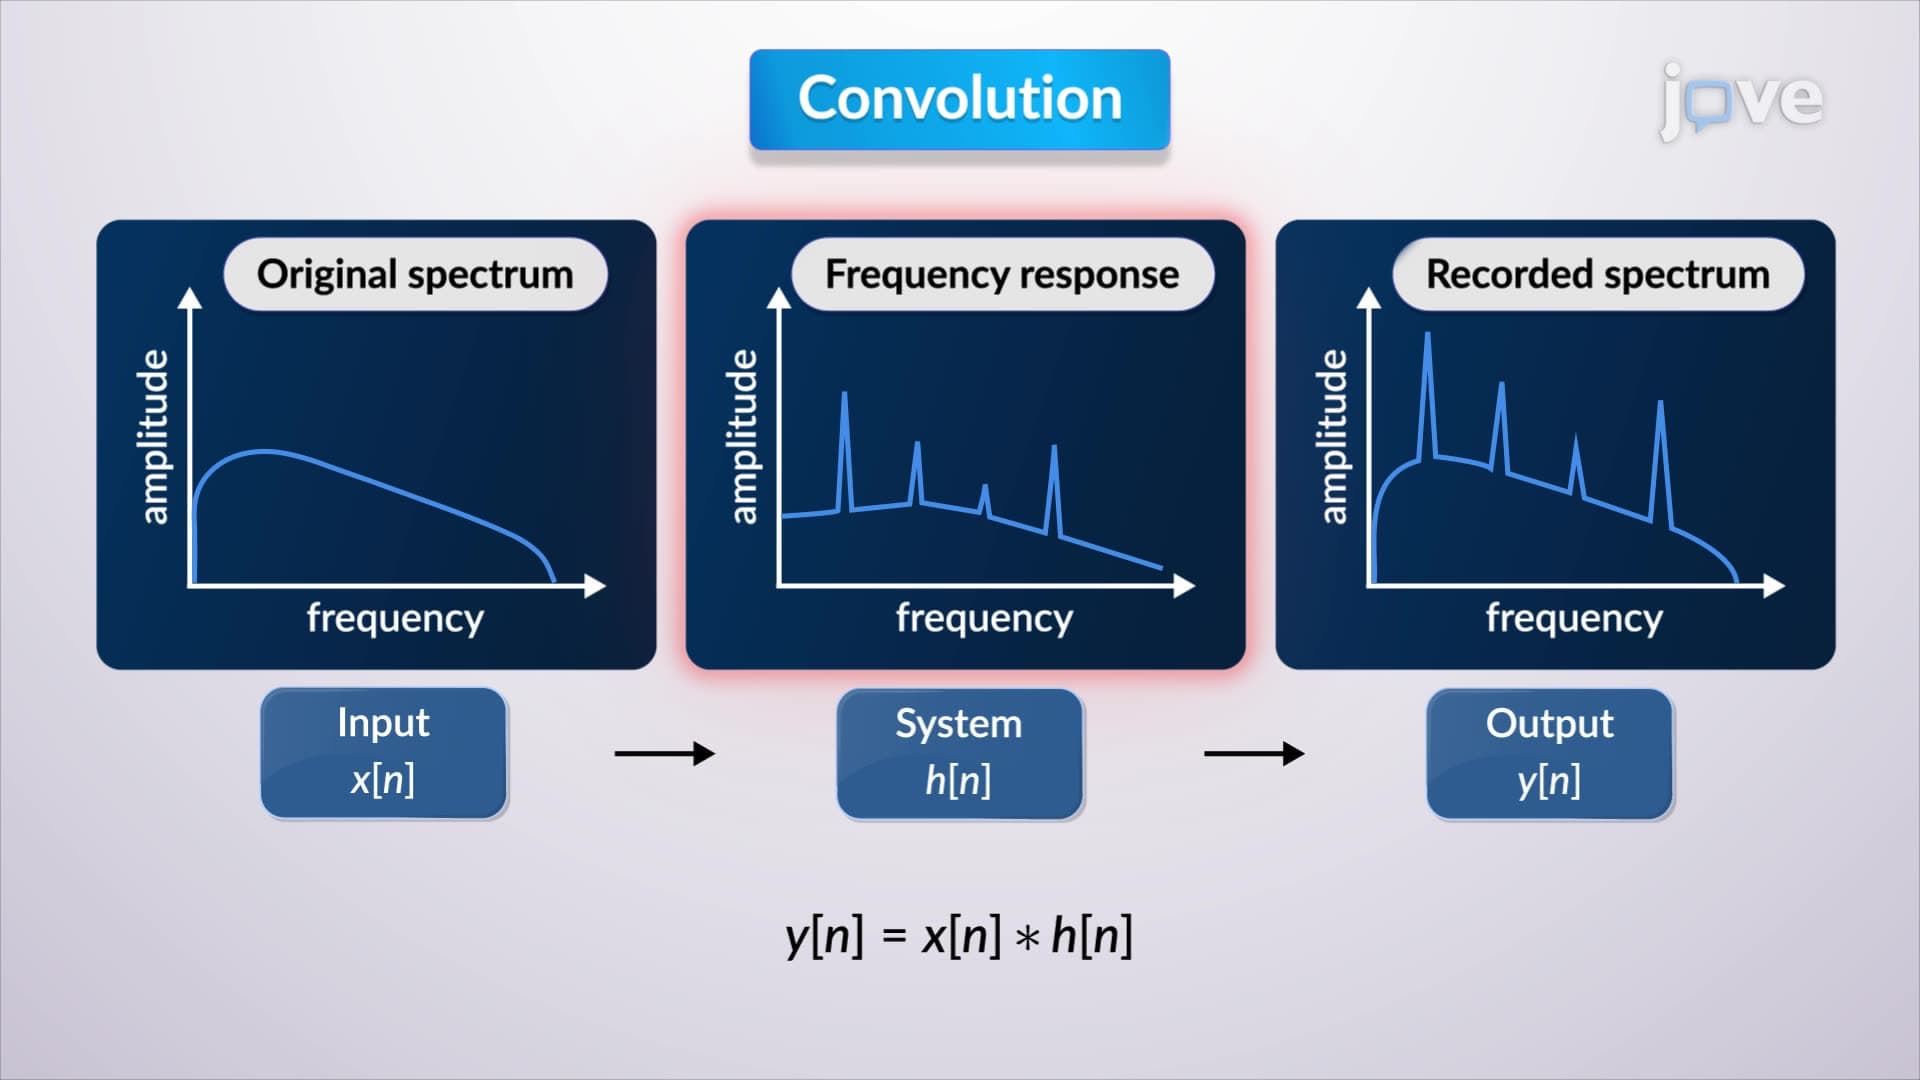
Deconvolution, also known as inverse filtering, is the process of extracting the impulse response from known input and output signals. This technique is vital in scenarios where the system's characteristics are unknown, and they must be inferred from the observable signals.
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
532
 01:15
Depth Perception and Spatial Vision
1.8K
Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.
1.8K