

基于时间变化的滑动模式控制为机器人操纵器的有限时间规定的性能功能
Sana Stihi1, Raouf Fareh2, Sofiane Khadraoui2
1Research Institute of Sciences and Engineering (RISE), University of Sharjah, Sharjah, United Arab Emirates.
ISA transactions
|November 30, 2025

概括
这项研究介绍了一种新的时间变化滑动模式控制器 (TVSMC),可以消除到达相,并确保机器人操纵器的有限时间误差趋同. 新的方法提高了稳定性,并减少了对精确控制的聊天.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统工程 控制系统工程
- 应用数学 应用数学 应用数学
背景情况:
- 滑动模式控制 (SMC) 为机器人操纵器提供了可靠性,但受到了聊天和长达阶段的困扰.
- 传统的时间变化的滑动模式表面 (TVSMS) 可能对初始条件和参数选择敏感,限制了有限时间的融合.
- 从任何初始状态实现稳定性和有限时间的融合仍然是机器人控制的一个重大挑战.
研究的目的:
- 开发一种新的时间变化的滑动模式控制器 (TVSMC),集成有限时间规定的性能功能 (FTPPF).
- 为了消除到达阶段,并确保机器人操纵器的有限时间误差趋同.
- 加强对不确定性和干扰的稳定性,同时减轻聊.
主要方法:
- 将有限时间规定的性能函数 (FTPPF) 集成到时间变化的滑动模式表面 (TVSMS) 设计中.
- 基于FTPPF的新型TVSMS的开发,以确保在预先确定的时间框架内实现错误趋同.
- 使用Lyapunov定理进行有限时间稳定性分析和在MICO 4-DOF机器人上的实验验证.
主要成果:
- 拟议的TVSMS确保了有限时间错误的融合,消除了达到阶段,并降低了对初始条件的灵敏度.
- 控制器有效地减轻了与SMC相关的喋喋不休问题,并在到达阶段提高了稳定性.
- 实验结果表明,与传统方法相比,性能,强度和对干扰的弹性都优越.
结论:
- 具有FTPPF的新型TVSMC为高精度机器人应用提供了简化但高度稳健的解决方案.
- 该方法保证了有限时间的融合和改进的短暂响应塑造与最小的参数调整.
- 这种控制器为在不确定性条件下精确可靠的机器人操纵提供了有希望的进步.


相关概念视频
 01:07
Time-Domain Interpretation of PD Control
351
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
351
 01:22
Controller Configurations
337
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
337
 01:26
PD Controller: Design
590
In automotive engineering, car suspension systems often employ Proportional Derivative (PD) controllers to enhance performance. PD controllers are utilized to adjust the damping force in response to road conditions. A controller, acting as an amplifier with a constant gain, demonstrates proportional control, with output directly mirroring input.
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
Designing a continuous-data controller requires selecting and linking components like adders and integrators, which are fundamental in Proportional,...
590
 01:17
Open and closed-loop control systems
1.5K
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
1.5K
 01:26
Feedback control systems
663
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
663
 01:21
Transfer Function in Control Systems
1.4K
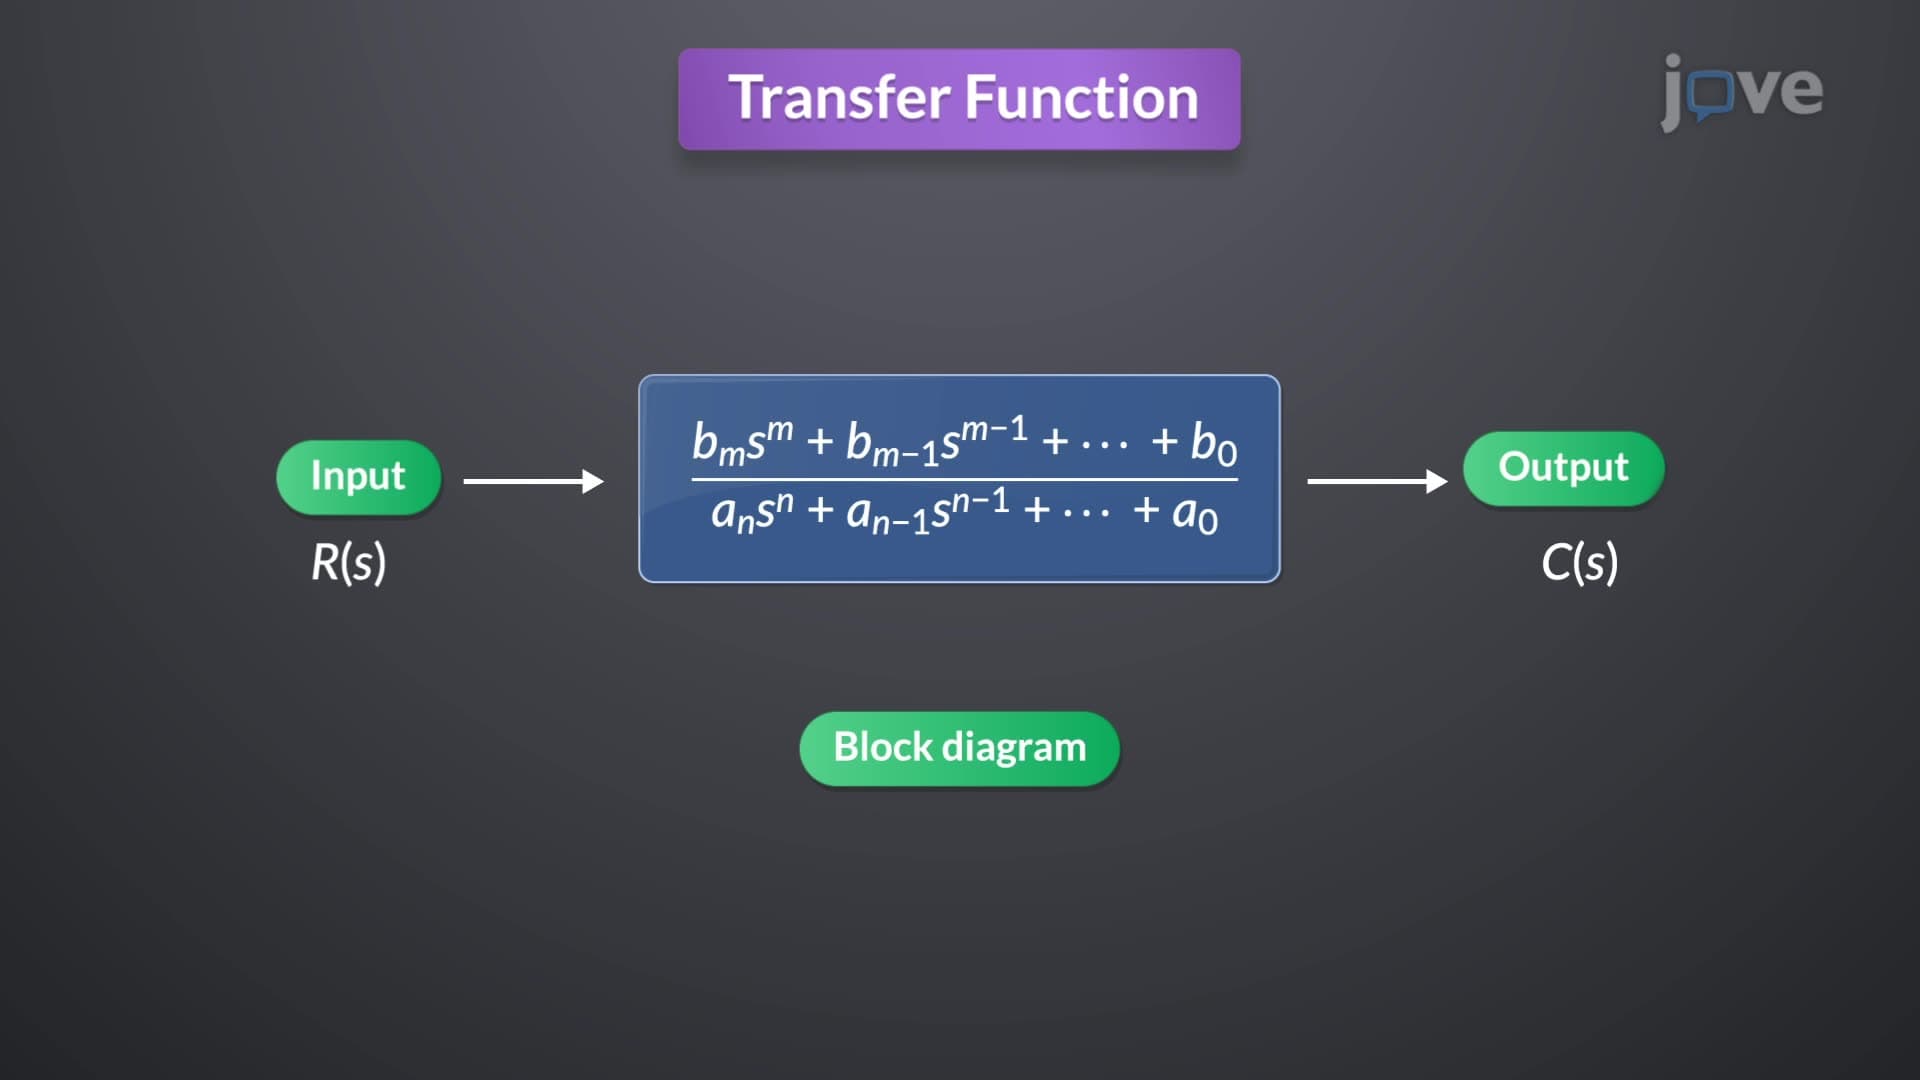
The transfer function is a fundamental concept in the analysis and design of linear time-invariant (LTI) systems. It offers a concise way to understand how a system responds to different inputs in the frequency domain. It serves as a bridge between the time-domain differential equations that describe system dynamics and the frequency-domain representation that facilitates easier manipulation and analysis.
To derive the transfer function, consider a general nth-order linear time-invariant...
To derive the transfer function, consider a general nth-order linear time-invariant...
1.4K