
带有输出约束和输入非线性性的分数顺序非非非非非线性系统的神经适应性故障耐受性跟踪控制
Fa Chen1, Lu Chen2, Huiyuan Li3
1The College of Information Science and Technology, Donghua University, Shanghai 201620, China.

本研究介绍了对分数顺序非线性系统 (FONSs) 的容错自适应跟踪控制. 该方法解决了规定的时间间隔输出约束 (PTIOC) 和执行器故障,确保了系统的稳定性和性能.
科学领域:
- 控制系统工程 控制系统工程
- 非线性动力学是一种非线性动力学.
- 分数微积分的计算.
背景情况:
- 分数级非线性系统 (FONS) 呈现复杂的动态.
- 执行器故障和输出限制挑战控制系统的可靠性.
- 规定的时间间隔输出约束 (PTIOC) 为系统运行引入了特定的时间要求.
研究的目的:
- 为了研究非非因子FONS的容错自适应跟踪控制.
- 解决PTIOC,非线性输入和执行器故障的系统.
- 开发一个控制策略,以适应限制和故障,而无需重新设计控制器.
主要方法:
- 利用了改进的依赖受约束错误函数和规定的时间缩放函数.
- 采用了障碍功能,将PTIOC的问题转化为边界性验证.
- 开发了一个自适应式容错控制算法.
主要成果:
- 成功地减轻了FONS中执行器故障的影响.
- 有效地适应多个约束和非线性输入.
- 通过模拟来证明拟议的控制方案的有效性.
结论:
- 拟议的自适应式故障耐受性控制方案对具有PTIOC和执行器故障的非affine FONS有效.
- 该方法确保了系统稳定性和在具有挑战性的条件下跟踪性能.
- 该方法为需要精确计时和故障容忍度的系统提供了强大的解决方案.
更多相关视频
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
 09:01
Gain-compensation Methodology for a Sinusoidal Scan of a Galvanometer Mirror in Proportional-Integral-Differential Control Using Pre-emphasis Techniques
Published on: April 4, 2017
相关概念视频
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:26
Linear Approximation in Frequency Domain
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:07
Time-Domain Interpretation of PD Control
Consider the example of control of motor torque. Initially, a positive...
 01:21
First Order Systems
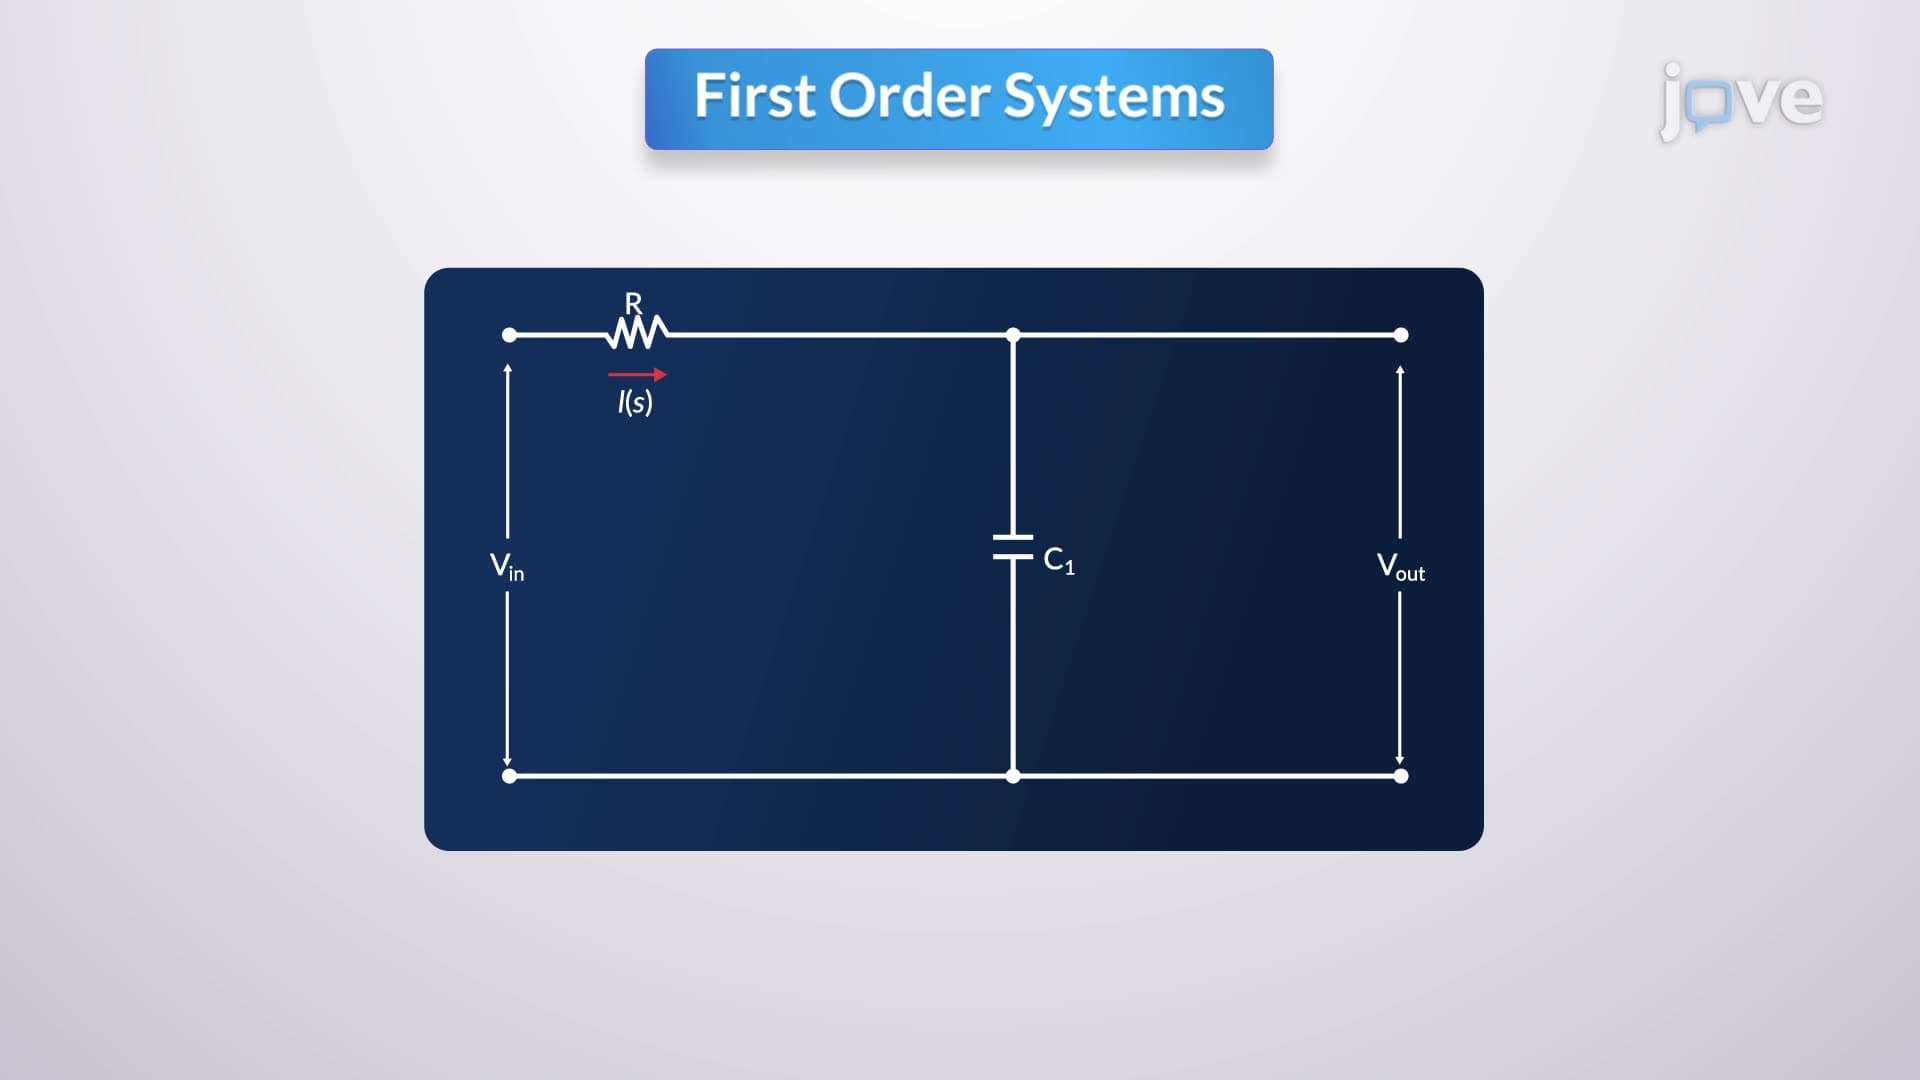
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
 01:22
Controller Configurations
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...