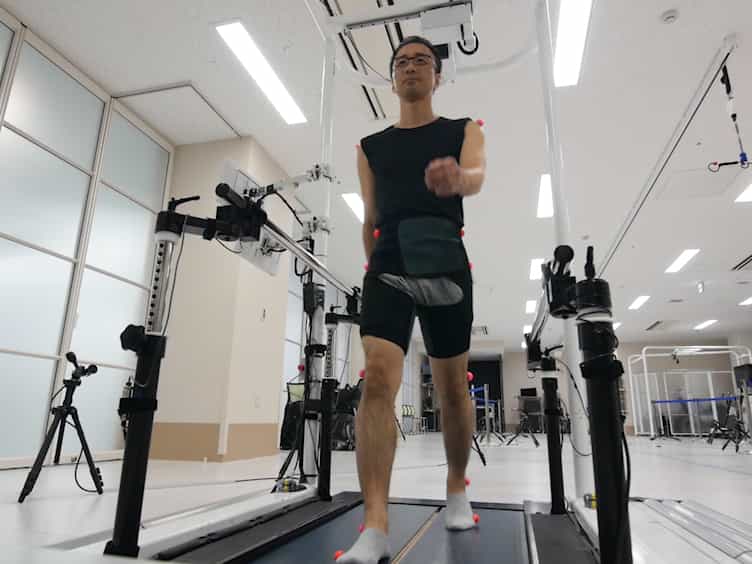

腰部加速步态估计:"逐步"算法更新和改进
Lukas Adamowicz1, Wenyi Lin1, F Isik Karahanoglu1
1AI/ML Quantitative Digital Sciences, Pfizer Research and Development, Pfizer, Cambridge, MA, United States.
Journal of medical Internet research
|December 12, 2025

概括
使用加速度计的增强步态算法提高了远程监控的准确性. 这些数字健康的进步为不同的人群和速度提供了可靠的步态分析.
科学领域:
- 数字健康数字健康
- 生物医学工程 生物医学工程
- 可穿戴技术可穿戴技术
背景情况:
- 基于加速度计的数字健康技术越来越多地用于步态监测,因为参与者负担较低,部署容易.
- 远程步行监测在长时间内提供连续的,可量化的健康指标,比传统的诊所访问提供更全面的视角.
- 该SciKit数字健康 (SKDH) 包提供了一个设备无关的框架,用于在各种设备上标准化步态指标.
研究的目的:
- 为SKDH步态算法引入基于文献的改进.
- 为了提高算法的性能与参考标准相比.
- 减少在不同人群中需要手动参数调整的需要.
主要方法:
- 采用了区块精细化过程来检查和增强单个算法组件.
- 评估了这些改进对完整的步态算法和生成指标的累积影响.
- 这项研究利用了健康成年人和儿科参与者的数据.
主要成果:
- 新的步态事件估计方法与前身相比,平均绝对误差减少了50%以上.
- 步行尺度与实验室内参考值的同类内相关值从0.50-0.74提高到0.81-0.90.
- 纠正了步行速度估计的系统偏差,将与参考值的差异从0.065-0.230 m/s缩小到0.00-0.03 m/s.
结论:
- 这项研究提供了强有力的证据,支持增强步态算法的有效性.
- 单个腰部加速度计可以以高准确性和可靠性捕捉步态特征.
- 该算法在各种步行速度和年龄组中表现良好.
相关概念视频
 01:34
Velocity and Position by Graphical Method
Velocity and position can be calculated from the known function of acceleration as a function of time. The total area under the acceleration-time graph and the velocity-time graph gives the change in velocity and position, respectively. In the case of an airplane, its acceleration is tracked using the inertial navigation system. The pilot provides the input of the airplane's initial position and velocity before takeoff. The inertial navigation system then uses the acceleration data to calculate...
 01:10
Relative Motion Analysis - Acceleration
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
 01:29
Application of Linearization and Approximation
A drone flying through complex terrain often relies on more than one sensing method to estimate small changes in altitude. Along with direct measurements, air pressure provides a useful indirect indicator of vertical movement. Atmospheric pressure decreases as altitude increases, and this relationship is commonly described using an exponential model. Although accurate, converting pressure measurements into altitude values requires calculations that are too complex to perform repeatedly during...
 01:29
Distance Problem
When an object's velocity changes over time, the total distance traveled can be determined by summing small displacement intervals over short increments. This approach approximates the true distance through numerical summation and the use of integral calculus. An estimate of the total displacement can be obtained by measuring velocity at regular intervals and multiplying each value by the corresponding time step.If a runner accelerates over the first three seconds of a race, speed measurements...
 01:26
Trapezoidal Rule
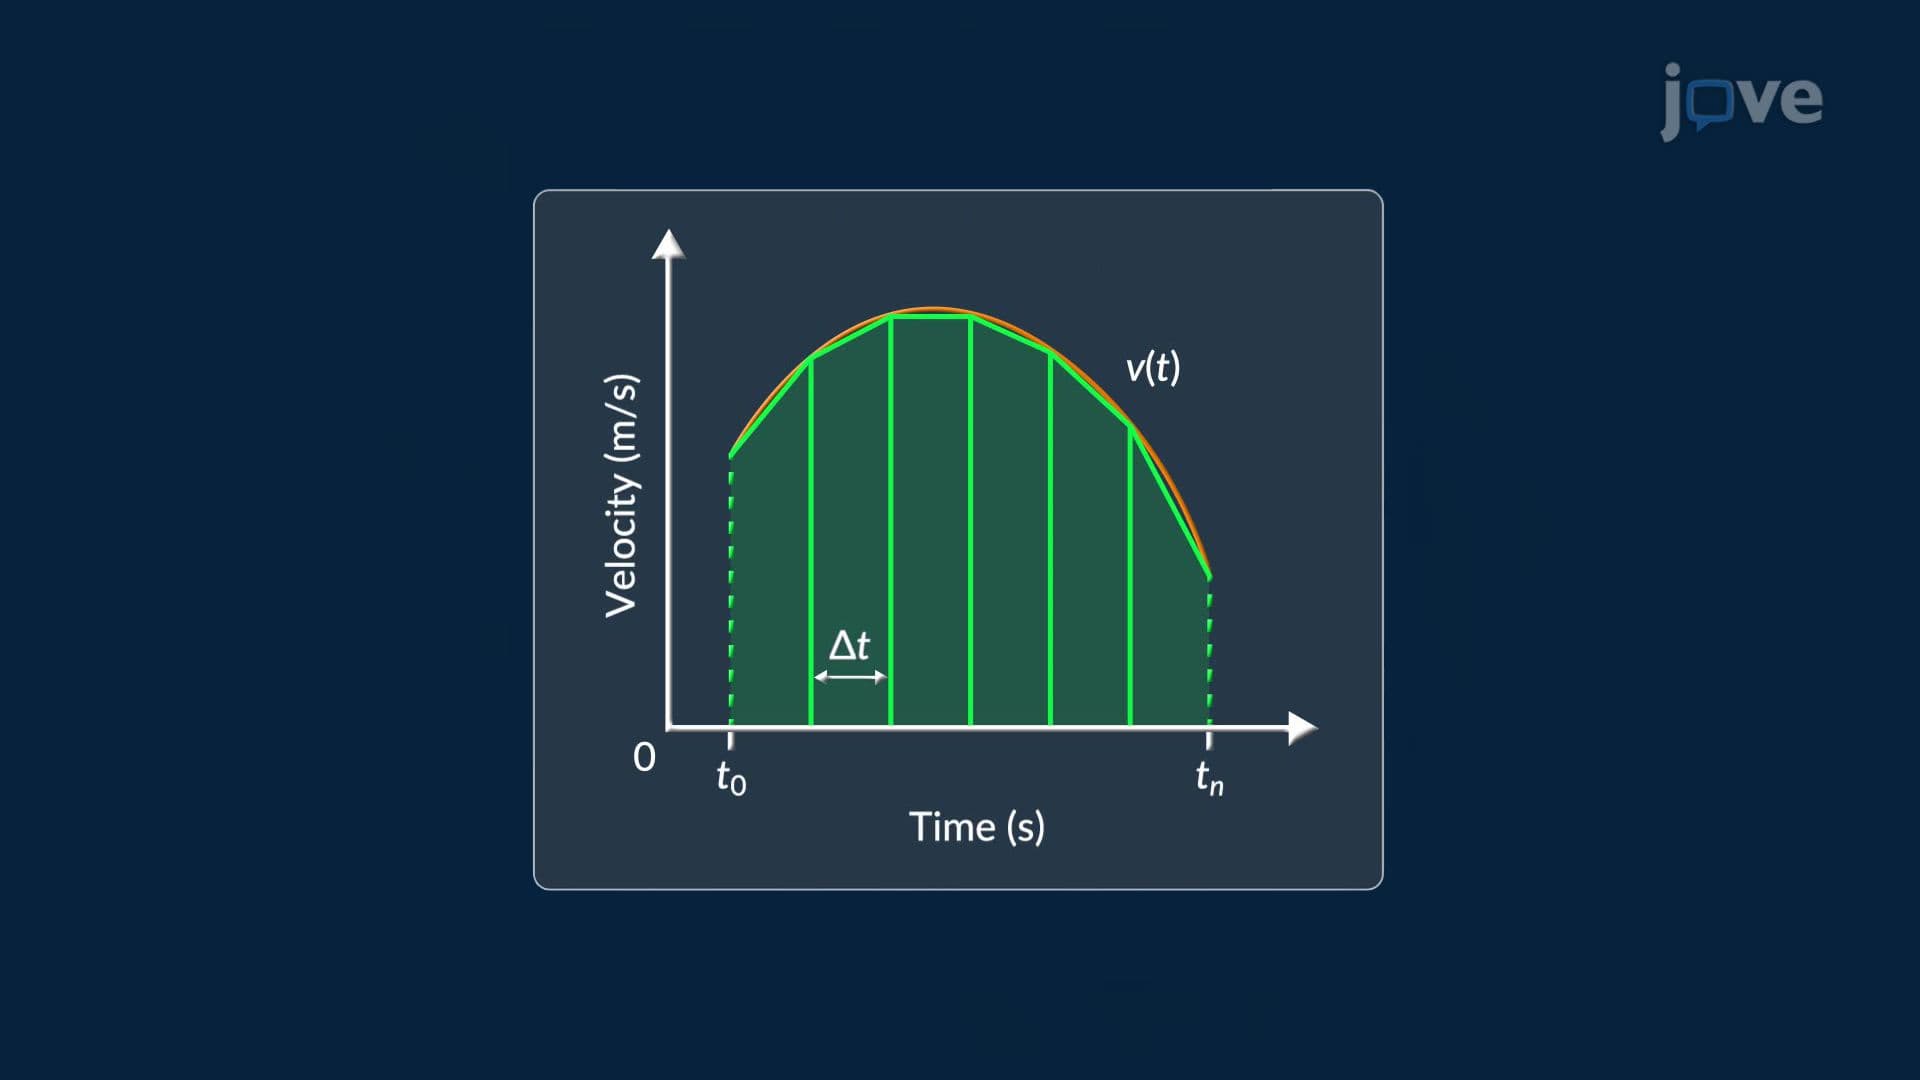
Estimating the distance traveled by a vehicle using its recorded velocity over time is a common problem in physics and engineering. When velocity data is available at discrete time intervals, rather than as a continuous function, numerical integration methods such as the trapezoidal rule are often employed to approximate the total displacement.The trapezoidal rule works by dividing the total time interval into several equal segments. Within each segment, the recorded velocities at the endpoints...