基于Triple I-3D Net的整体成像视频的中间预测
Optics express
|December 19, 2025

概括
本研究介绍了Triple I-3D Net,这是一种用于预测集成成像 (II) 中中间的新方法. 这种方法通过使高率元素图像阵列 (EIA) 生成来提高3D显示性能.
科学领域:
- 光学和光子学 在光学和光子学.
- 计算机视觉和图像处理
背景情况:
- 整体成像 (II) 提供了完全对称的3D显示,没有接-适应冲突.
- 为3D视频生成高率元素图像数组 (EIA) 是一个重大挑战.
研究的目的:
- 为整体成像提出一种新的中间预测方法.
- 通过高效的EIA序列合成,提高3D显示器的动态性能.
主要方法:
- 开发了Triple I-3D Net,具有适应式接收场和用于像素估计的补丁.
- 集成的运动估计和像素合成在一个统一的损失函数.
- 在没有光学系统修改的情况下利用内在的EIA属性来生成高率序列.
主要成果:
- 在客观和感知质量指标方面,Triple I-3D Net显著优于现有方法.
- 在PSNR中实现了12.2%的最大改进,在SSIM中达到37.8%,在LPIPS中达到95%.
- 减少了多达93.5%的各指标的样本差异,证实了框架稳定性.
结论:
- 拟议的方法可以为整体成像实现准确的插值.
- 三重I-3D Net有效地提高了3D整体成像显示器的动态性能.
相关概念视频
 01:26
Frames: Problem Solving II
457
Consider a hydraulic hoist supporting a load of 1 kN. Assuming a simplified schematic representation of this frame structure, the force acting on BD and BF members can be determined.
457
 01:24
Absolute Motion Analysis- General Plane Motion
507
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
507
 01:25
Relative Motion Analysis using Rotating Axes
858
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
858
 01:24
Frames: Problem Solving I
915
Consider a jib crane with an external load suspended from the pulley. The dimensions of the crane members are shown in the figure. A systematic analysis of the frame structure is required to determine the reaction forces at the pin joints, assuming that the pulleys are frictionless.
915
 01:10
Reconstruction of Signal using Interpolation
661
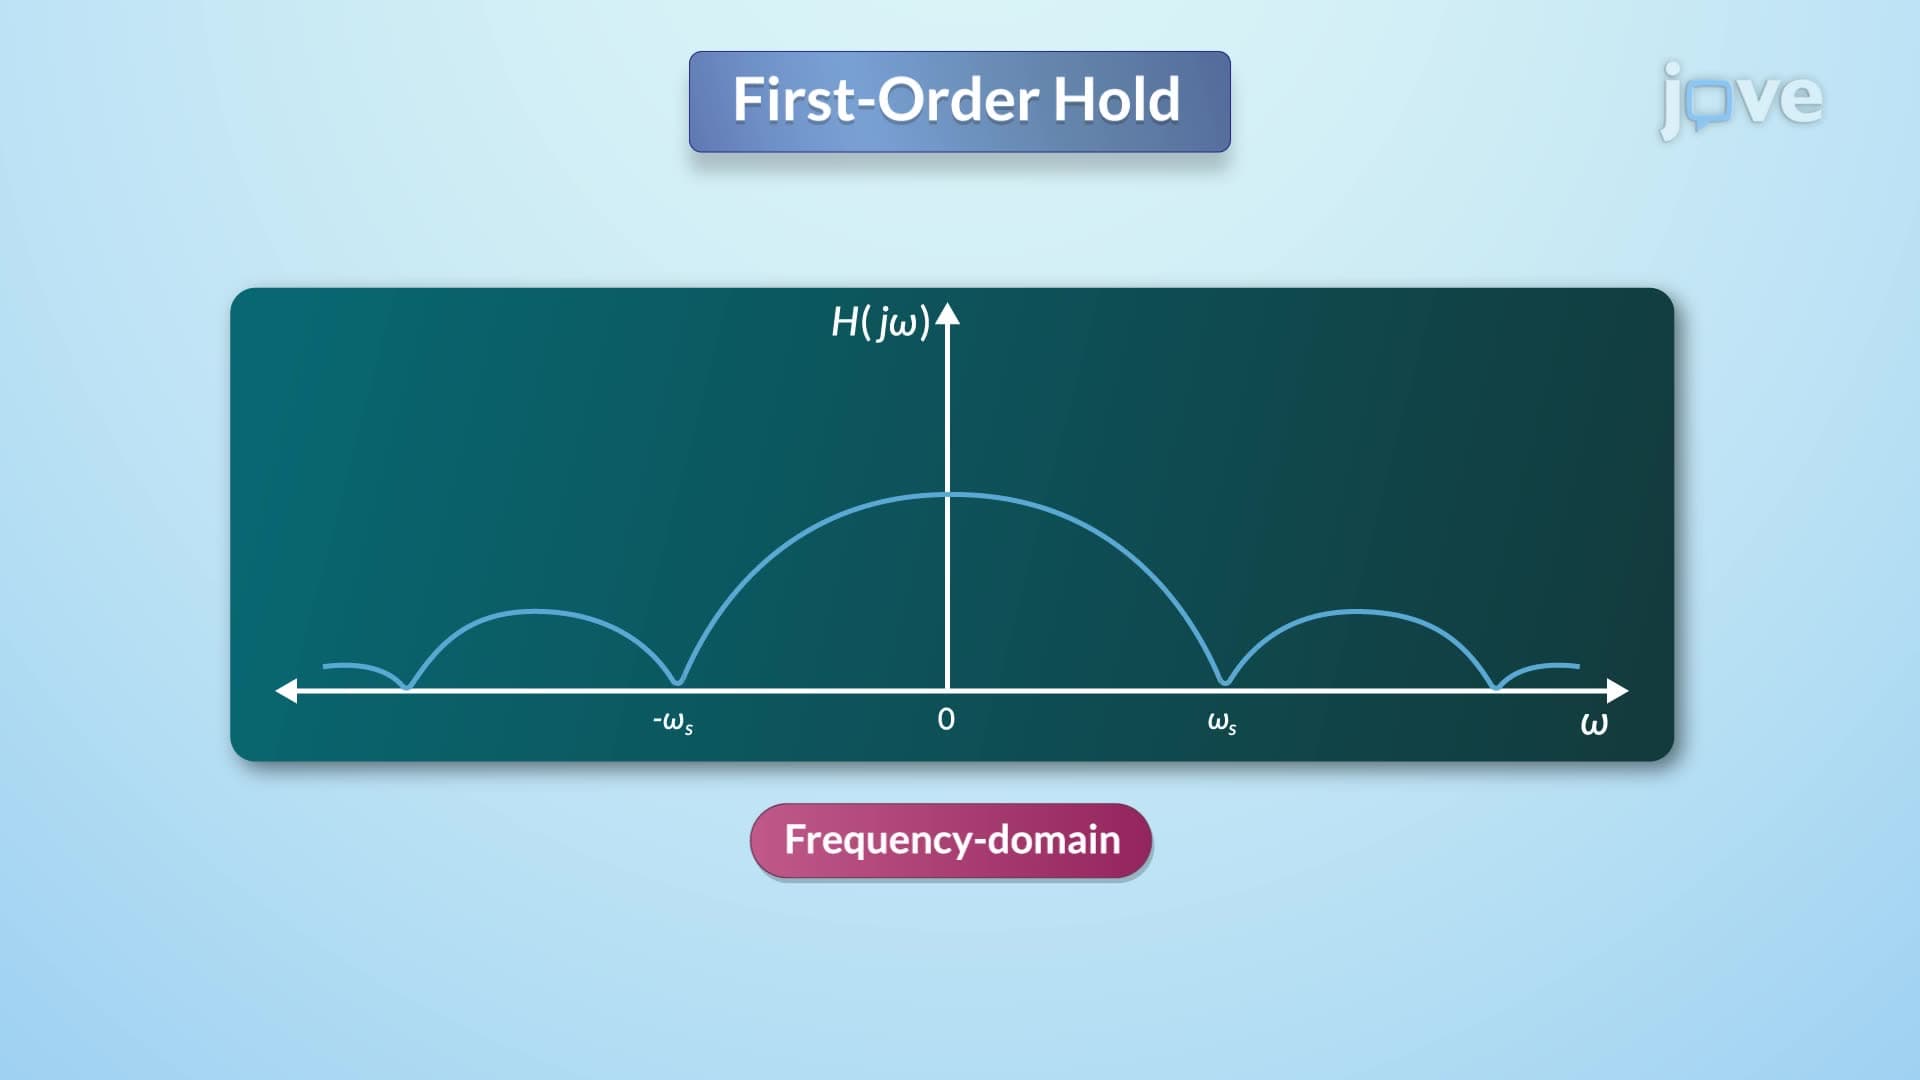
Signal processing techniques are essential for accurately converting continuous signals to digital formats and vice versa. When a continuous signal is sampled with a period T, the resulting sampled signal exhibits replicas of the original spectrum in the frequency domain, spaced at intervals equal to the sampling frequency. To handle this sampled signal, a zero-order hold method can be applied, which creates a piecewise constant signal by retaining each sample's value until the next...
661
 01:03
Inertial Frames of Reference
8.6K
Newton’s first law is usually considered to be a statement about reference frames. It provides a method for identifying a special type of reference frame: the inertial reference frame. In principle, we can make the net force on a body zero. If its velocity relative to a given frame is constant, then that frame is said to be inertial. So, by definition, an inertial reference frame is a reference frame where Newton's first law holds valid. Newton's first law applies to objects with...
8.6K