
在运动中定:手势如何塑造数字估计
Aglaé Navarre1, André Didierjean2, Pauline Genin2
1Université Marie et Louis Pasteur, Laboratoire de Psychologie, F-25000 Besançon, France; School of Psychology, University College Dublin, Ireland.
Consciousness and cognition
|December 25, 2025

概括
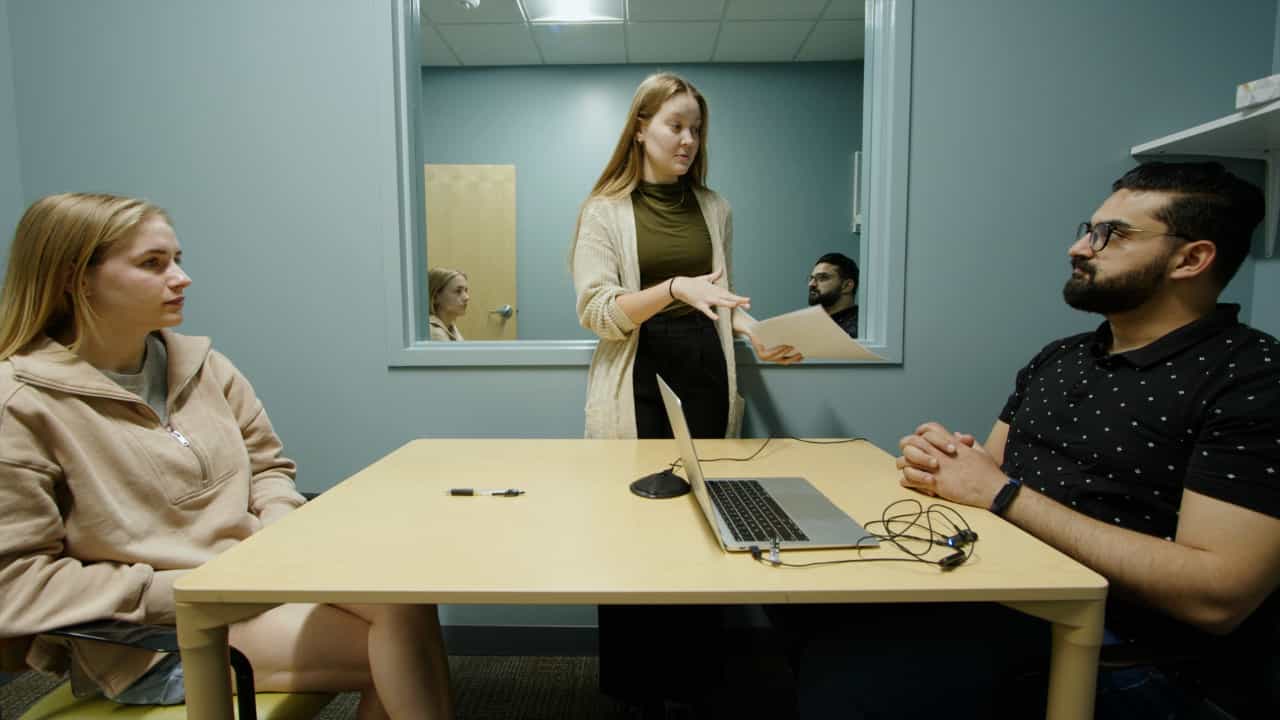
简单的手势无意识地影响数值估计,类似于定效应. 参与者没有意识到暗示高低位置的手势如何影响他们的数字判断.
科学领域:
- 认知心理学 认知心理学
- 社会心理学 社会心理学
- 行为经济学是一种行为经济学.
背景情况:
- 微妙的环境线索,如数字和手势,可以无意识地影响行为.
- 定效应表明了最初的数值信息如何影响后续判断.
研究的目的:
- 为了调查是否简单的手势暗示在虚拟尺度上高或低的位置可能会偏向数值估计.
- 为了确定这种手势偏差是否与已确定的定效应类似地运行.
- 评估参与者对任何手势影响其估计的意识.
主要方法:
- 一项涉及128名参与者的研究 (N = 128).
- 参与者接触到偶尔的手势,暗示在虚拟垂直尺度上高低的位置.
- 记录了数值估计,并将暴露于不同手势的组之间进行了比较.
主要成果:
- 与暗示低位的手势相比,暗示高位的手势导致数值估计显著更高.
- 大多数参与者报告说,他们没有意识到手势对他们的估计的影响.
- 这种手势偏差与定效应的原则保持一致.
结论:
- 偶然的手势可以无意识地偏向数值估计,作为一种非数值定形式.
- 选择性可访问性理论为理解这些无意识偏见如何运作提供了一个框架.
- 未来的研究应该探索手势影响决策的机制和程度.
更多相关视频

相关概念视频
 01:25
The Anchoring-and-Adjustment Heuristic
7.7K
In order to make good decisions, we use our knowledge and our reasoning. Often, this knowledge and reasoning is sound and solid. However, sometimes, we are swayed by biases or by others manipulating a situation. For example, let’s say you and three friends wanted to rent a house and had a combined target budget of $1,600. The realtor shows you only very run-down houses for $1,600 and then shows you a very nice house for $2,000. Might you ask each person to pay more in rent to get the...
7.7K
 01:25
Relative Motion Analysis using Rotating Axes
854
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
854
 01:23
Curvilinear Motion: Rectangular Components
1.0K
Curvilinear motion characterizes the movement of a particle or object along a curved path, notably evident when envisioning a car navigating a winding road. If the car starts at point A, its position vector is established within a fixed frame of reference, where the ratio of the position vector to its magnitude signifies the unit vector pointing in the position vector's direction.
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the...
1.0K
 01:10
Relative Motion Analysis - Acceleration
779
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
779
 01:22
Relative Motion Analysis using Rotating Axes - Acceleration
727
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame. The absolute velocity of point B is determined by adding the absolute velocity of point A, the relative velocity of point B in the rotating frame, and the effects caused by the angular velocity within the rotating frame.
Time differentiation is...
Time differentiation is...
727
 01:24
Absolute Motion Analysis- General Plane Motion
503
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
503