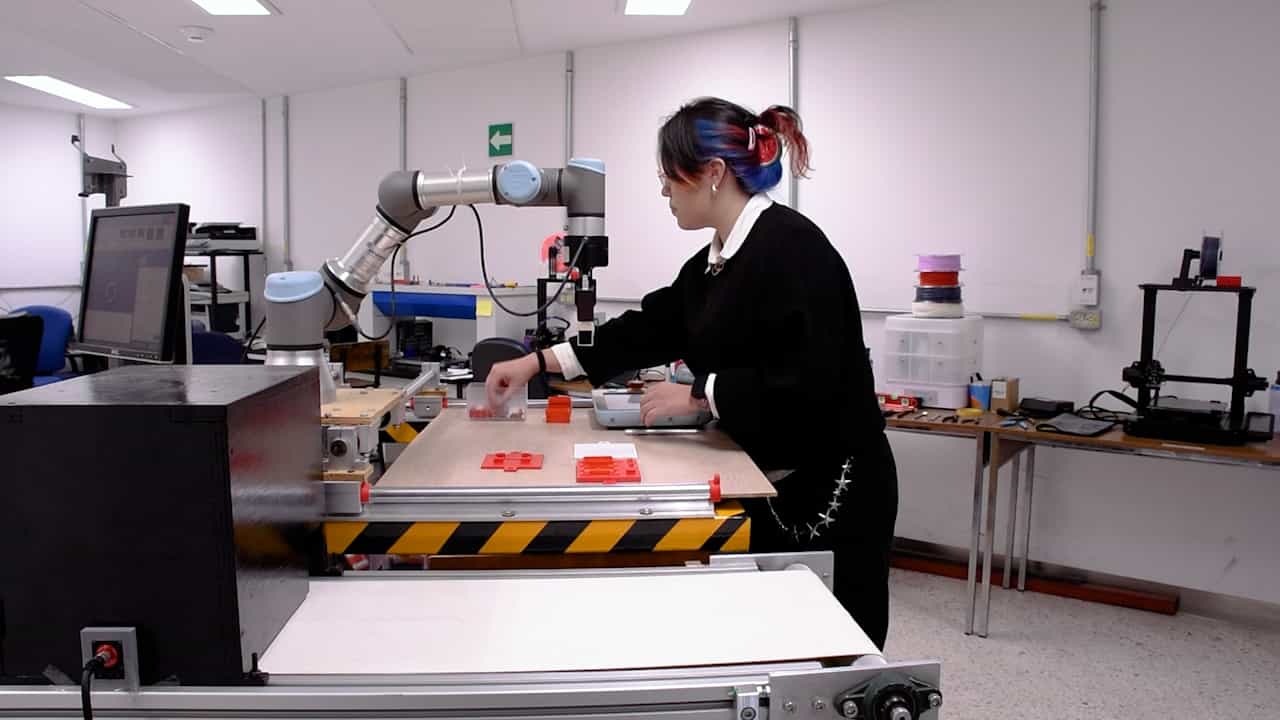

计划对多机器人系统进行同步,并进行主动观察
Patrick Zhong1, Federico Rossi2, Dylan A Shell1
1Texas A&M University, College Station, TX 77840 USA.
Autonomous robots
|December 29, 2025

概括
本研究介绍了一种新的马尔科夫决策过程 (MDP) 方法,用于多代理机器人系统,以有效地规划感知和通信行为. 该方法在不确定性条件下优化了联合状态估计,使合作任务的有效去中心化执行成为可能.
科学领域:
- 机器人和人工智能 机器人和人工智能
- 多代理系统 多代理系统
- 在不确定性下规划
背景情况:
- 合作型多代理机器人系统需要基于共享状态观测的联合行动规划.
- 规划在不确定性下的感知和沟通行为对于高效的合作至关重要.
- 现有的方法难以应对大型联合信仰空间的难以处理.
研究的目的:
- 为在不确定性条件下的多代理规划开发一种可处理的计算方法.
- 让机器人能够主动决定何时获得国家信息的成本是合理的.
- 制定一种适用于高质量的观测方法,可以恢复联合状态,即使不经常.
主要方法:
- 问题作为一个马尔科夫决策过程 (MDP) 的制定,通过宏观行动解决.
- 开发一个类似贝尔曼的反复性来指导政策的产生.
- 政策同时定义了低级别的行动,国家恢复阶段和未来的重新安排承诺.
主要成果:
- 拟议的MDP表述有效地回避了完全联合信仰空间建设的需要.
- 在实际形式中展示了多机构:协助,传感器融合和协调活动.
- 成功的模拟研究和物理机器人实现验证了分散执行的方法.
结论:
- 开发的方法为在多代理机器人系统中分散执行联合计划提供了有效的框架.
- 该方法可以适应现实世界的非理想性,正如基于硬件经验的增强所示.
- 这项工作在需要联合状态估计和行动计划的场景中推进了合作机器人能力.

相关概念视频
 02:30
Naturalistic Observations
16.9K
If you want to understand how behavior occurs, one of the best ways to gain information is to simply observe the behavior in its natural context. However, people might change their behavior in unexpected ways if they know they are being observed. How do researchers obtain accurate information when people tend to hide their natural behavior? As an example, imagine that your professor asks everyone in your class to raise their hand if they always wash their hands after using the restroom. Chances...
16.9K
 01:24
One-Degree-of-Freedom System
761
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
761
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
675
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
675
 01:12
Observational Learning
782
Albert Bandura's observational learning, also known as imitation or modeling, occurs when a person observes and imitates another's behavior. It is a quicker process than operant conditioning. A well-known example is the Bobo doll study, where children who saw an adult acting aggressively towards the doll were more likely to act aggressively when left alone, compared to those who observed a nonaggressive adult. Many psychologists view observational learning as a form of latent learning...
782
 01:24
Sequence Networks of Rotating Machines
466
A Y-connected synchronous generator, grounded through a neutral impedance, is designed to produce balanced internal phase voltages with only positive-sequence components. The generator's sequence networks include a source voltage that is exclusively in the positive-sequence network. The sequence components of line-to-ground voltages at the generator terminals illustrate this configuration.
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
Zero-sequence current induces a voltage drop across the generator's neutral impedance and other...
466
 01:22
Multi-input and Multi-variable systems
371
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence of...
In the absence of...
371