在患有双侧性脑的儿童中,不同斜脚步态模式的机械能量学
Kosar Barati1, Farzam Farahmand1, Saeed Behzadipour1
1Mechanical Engineering Department, Sharif University of Technology, Tehran, Iran.
Journal of biomechanics
|December 31, 2025

概括
患有脑 (CP) 的儿童表现出与他们特定的运动模式相关的明显的步态低效. 了解这些生物力学问题,如振幅和相位问题,可以指导针对性干预,以提高步行效率.
科学领域:
- 生物力学 生物力学
- 儿科康复儿童康复中心
- 步态分析 步态分析
背景情况:
- 患有脑 (CP) 的儿童经常表现出低效的步态模式.
- 在CP中,特定的斜腰步行模式和步行效率低下之间的确切关系尚未完全理解.
研究的目的:
- 为了研究双边性CP的儿童的步态的机械能量特性.
- 量化步行的低效率,特别是幅度和阶段问题,在CP的不同斜腰步行模式中.
- 为了比较患有CP的儿童和典型发育 (TD) 的儿童之间的步行能量特征.
主要方法:
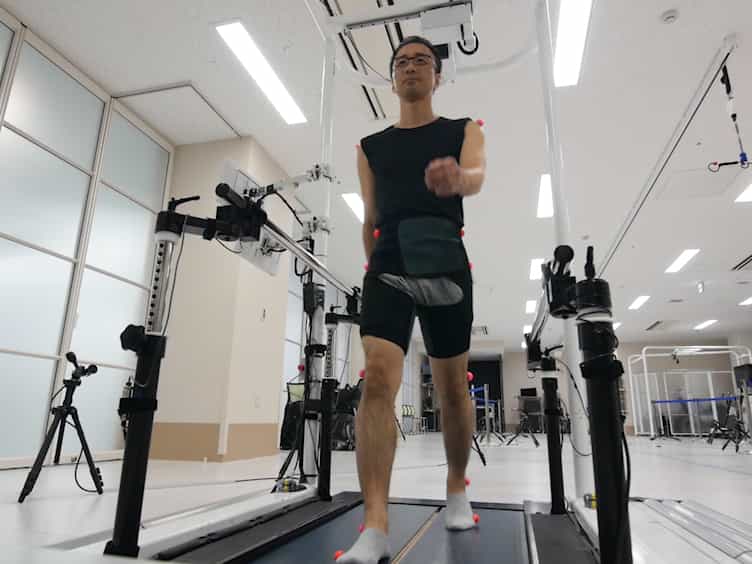
- 采集了148名双边性CP的儿童的3D步态数据和19名使用运动捕捉的TD控制器.
- 应用了扩展的倒置摆形框架来分析在单个支下无维的动力 (T) 和潜在 (V) 能量波形.
- 量化广度和相位问题,通过评估与最佳能量交换的偏差,并计算连续相对相位.
主要成果:
- 与幅度相关的低效率在Crouch步态模式中最为明显.
- 与TD相比,所有CP子组都表现出相位协调受损,通过积极的时间延迟和减少的连续相对相位相表现出来.
- CP子组显示了总能量波动,运输成本和能量回收指数显著增加,在Crouch和Jump模式中具有特定的能量消耗模式.
结论:
- 患有脑膜炎的儿童的步行效率低下是特定于他们的脚步行模式.
- 定量生物力学数据为开发有针对性的干预措施提供了基础,以提高CP儿童的步行效率.
- 了解模式特定的低效率可以导致更有效的CP步态障碍康复策略.
相关概念视频
 01:14
Energy Diagrams - I
The dynamics of a mechanical system can be easily understood by interpreting a potential energy diagram. Since energy is a scalar quantity, the interpretation of the dynamics of the system becomes even simpler.
Take the example of a skater on a parabolic ramp. The potential energy at different points along the ramp will be proportional to the height of the ramp, which varies quadratically with the horizontal position on the ramp. As the skater moves down the ramp from the highest position,...
Take the example of a skater on a parabolic ramp. The potential energy at different points along the ramp will be proportional to the height of the ramp, which varies quadratically with the horizontal position on the ramp. As the skater moves down the ramp from the highest position,...
 01:10
Energy Diagrams - II
Energy diagrams are important to understand the dynamics of a system. The topology of an energy diagram helps illustrate the equilibrium points of the system.
The point in the energy diagram at which the system’s potential energy is the lowest is known as the local minima. The system tends to stay in this position indefinitely unless acted upon by a net force. The slope of the potential energy diagram at the local minima is zero, indicating that zero net force is acting on the system. The slope...
The point in the energy diagram at which the system’s potential energy is the lowest is known as the local minima. The system tends to stay in this position indefinitely unless acted upon by a net force. The slope of the potential energy diagram at the local minima is zero, indicating that zero net force is acting on the system. The slope...
 01:24
One-Degree-of-Freedom System
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...