相关实验视频
Updated: Jan 13, 2026
11:41

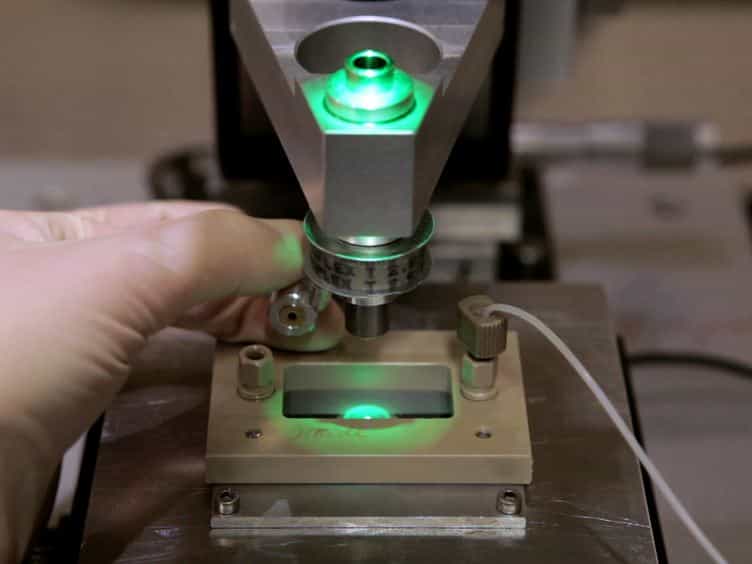
Magnetic Tweezers for the Measurement of Twist and Torque
Published on: May 19, 2014
23.8K
通过takagi-sugeno模糊控制增强了轨迹跟踪和磁悬浮的稳定性:实验方法
Yuvapriya T1, Vimala Kumari Jonnalagadda2, Vijaya Lakshmi Korupu3
1School of Electrical Engineering, Vellore Institute of Technology, Vellore, Tamil Nadu, 632014, India. yuvapriya.t@vit.ac.in.
Scientific reports
|January 7, 2026

概括
这项研究介绍了磁悬浮 (maglev) 系统的强大的模糊控制策略,增强了轨迹跟踪和稳定性. 这种新的方法确保了可靠的性能,尽管存在系统不确定性和外部干扰.
科学领域:
- 控制系统工程 控制系统工程
- 机器人技术 机器人技术 机器人技术
- 机械电子学是什么意思 机械电子学
背景情况:
- 磁悬浮 (磁悬浮) 系统面临着由于非线性和外部干扰导致的可靠控制方面的挑战.
- 现有的控制方法可能难以实现精确的轨迹跟踪和稳定性,在磁悬浮应用中.
研究的目的:
- 开发一种先进的控制技术,以提高磁悬浮系统的稳定性和轨迹跟踪性能.
- 为了应对磁悬浮系统内平滑无摩擦球悬浮的挑战.
主要方法:
- 通过平行分布式补偿 (PDC) 方法合成了一个Takagi-Sugeno (T-S) 模糊控制器.
- 集成了一种速度补偿技术和一个前控制器来管理引力偏差.
- 利用利亚普诺夫函数和线性矩阵不等式 (LMI) 来验证全局非对称稳定性.
主要成果:
- 提议的TS模糊控制策略与传统的比例-整数-导数 (PID) 方案相比,显示出更高的稳定性和轨迹跟踪.
- 硬件循环 (HIL) 测试证实了控制技术的有效性,用于稳定的磁悬浮系统悬浮.
- 综合方法成功地控制了重力偏差,并确保了平滑,无摩擦的操作.
结论:
- 该TS模糊的控制策略提供了一个强大的和有效的解决方案,用于磁悬浮系统的控制.
- 开发的方法增强了轨迹跟踪,并确保了稳定的悬浮,优于传统的控制方案.
- 这项研究有助于在需要高精度和可靠性的应用中推进磁悬浮技术.
相关概念视频
 01:17
Magnetic Damping
1.0K
Eddy currents can produce significant drag on motion, called magnetic damping. For instance, when a metallic pendulum bob swings between the poles of a strong magnet, significant drag acts on the bob as it enters and leaves the field, quickly damping the motion.
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
If, however, the bob is a slotted metal plate, the magnet produces a much smaller effect. When a slotted metal plate enters the field, an emf is induced by the change in flux; however, it is less effective because the slots limit the...
1.0K
 01:13
Torque On A Current Loop In A Magnetic Field
5.7K
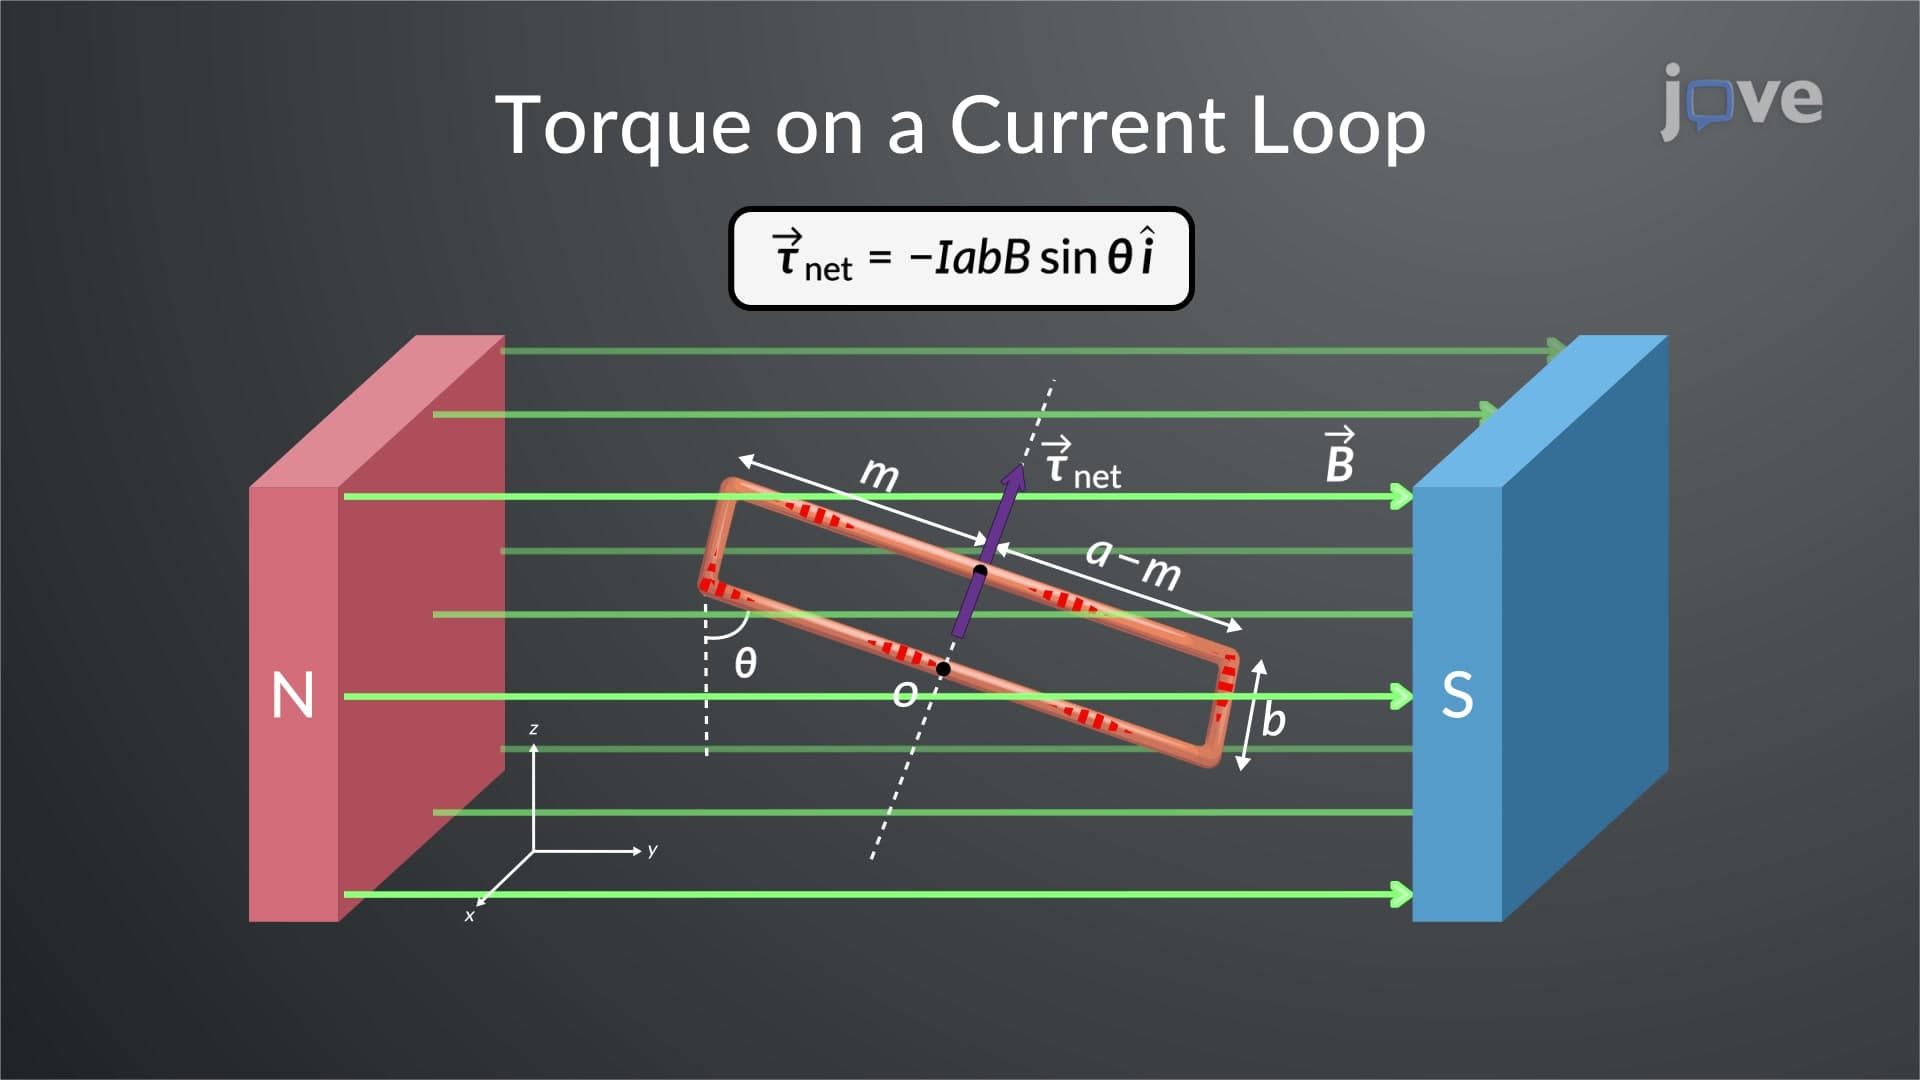
The most common application of magnetic force on current-carrying wires is in electric motors. These consist of loops of wire, which are placed between the magnets with a magnetic field. When current flows through the loops, the magnetic field applies torque, which causes the shaft to rotate, thus converting electrical energy to mechanical energy.
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
Consider a rectangular current-carrying loop containing N turns of wire, placed in a uniform magnetic field. The net force on a current-carrying loop...
5.7K
 01:18
Magnetic Force
1.8K
In addition to the electric forces between electric charges, moving electric charges exert magnetic forces on each other. A magnetic field is created by a moving charge or a group of moving charges known as the electric current. A magnetic force is experienced by a second current or moving charge in response to this magnetic field. Fundamentally, interactions between moving electrons in the atoms of two bodies produce magnetic forces between them.
The magnetic force acting on a moving charge...
The magnetic force acting on a moving charge...
1.8K
 01:15
Magnetic Vector Potential
1.5K
In electrostatics, the electric field can be written as the negative gradient of the potential. In magnetostatics, the zero divergence of the magnetic field ensures that the magnetic field can be expressed as the curl of a vector potential. This potential is known as the magnetic vector potential.
Consider an ideal solenoid with n turns per unit length and radius R. If I is the current through the solenoid, the magnetic field inside the solenoid is expressed as the product of vacuum...
Consider an ideal solenoid with n turns per unit length and radius R. If I is the current through the solenoid, the magnetic field inside the solenoid is expressed as the product of vacuum...
1.5K
 01:26
Feedback control systems
685
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
685
 01:26
Orthogonal Trajectories
3
Orthogonal trajectories describe the geometric relationship between two families of curves that intersect each other at right angles. One illustrative case involves a family of parabolas that open sideways along the x-axis. These curves share a common shape but differ by a scaling parameter, resulting in a set of curves that all pass through the origin and widen at different rates.Determining Orthogonal TrajectoriesTo identify the orthogonal trajectories for these parabolas, the first step...
3