

多变量高斯式基于过程的学习模型预测控制与无气味的卡尔曼波器用于自主地表车辆
1College of Marine Electrical Engineering, Dalian Maritime University, Dalian 116026, People's Republic of China.
ISA transactions
|January 11, 2026

概括
本研究引入了多变量高斯过程回归 (MVGPR) 用于建模自动地表车辆 (ASV) 动态. 开发的基于学习的模型预测控制 (MPC) 确保了强大的轨迹跟踪,即使是通信拒绝服务 (DoS) 攻击.
科学领域:
- 机器人和控制系统 机器人和控制系统
- 机器学习用于自主系统
- 海洋工程 海洋工程
背景情况:
- 由于水力动力学效应和环境不确定性,自动驾驶表面车辆 (ASV) 的非线性动力学建模具有挑战性.
- 传统方法在ASV系统中与高维数据和不确定性估计作斗争.
- 拒绝服务 (DoS) 攻击对ASV通信网络的可靠性构成重大威胁.
研究的目的:
- 使用先进的机器学习技术,为ASV开发一个强大的轨迹跟踪控制方案.
- 准确地建模ASV动态并估计复杂海上环境中的系统不确定性.
- 为了增强ASV对DoS攻击等通信中断的弹性.
主要方法:
- 多变量高斯过程回归 (MVGPR) 用于建模ASV的系统状态和观测动态,从而实现精确的多输入,多输出相关性和不确定性估计.
- 无气味卡尔曼波器 (UKF) 旨在改善状态估计,即使在无法测量的状态下也确保了稳定性.
- 使用MVGPR开发了一个基于学习的模型预测控制 (MPC) 框架,以处理轨迹跟踪并减轻没有外部补偿器的DoS攻击的影响.
主要成果:
- MVGPR方法有效地建模了复杂的ASV动态,在高维设置中表现优于传统方法.
- 集成的UKF提高了状态估计的准确性和稳定性.
- 基于MVGPR的学习MPC展示了强大而精确的轨迹跟踪性能,在不确定的条件下提高了系统稳定性,并模拟了DoS攻击.
结论:
- 拟议的基于MVGPR的学习MPC框架在自主地表车辆控制方面取得了重大进展,提供了准确的建模和强大的轨迹跟踪.
- 该方法有效地应对复杂动态,环境不确定性和通信安全威胁所带来的挑战.
- 通过模拟和硬件实验的验证证实了开发的控制策略的实际适用性和有效性.

相关概念视频
 01:16
Response Surface Methodology
595
Response Surface Methodology (RSM) is a collection of statistical and mathematical techniques used to develop, improve, and optimize processes. It is particularly valuable when many input variables or factors potentially influence a response variable.
The process of RSM involves several key steps:
The process of RSM involves several key steps:
595
 01:17
Open and closed-loop control systems
1.5K
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
1.5K
 01:22
Multi-input and Multi-variable systems
383
Cruise control systems in cars are designed as multi-input systems to maintain a driver's desired speed while compensating for external disturbances such as changes in terrain. The block diagram for a cruise control system typically includes two main inputs: the desired speed set by the driver and any external disturbances, such as the incline of the road. By adjusting the engine throttle, the system maintains the vehicle's speed as close to the desired value as possible.
In the absence of...
In the absence of...
383
 01:26
Feedback control systems
684
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
684
 01:21
State Space to Transfer Function
550
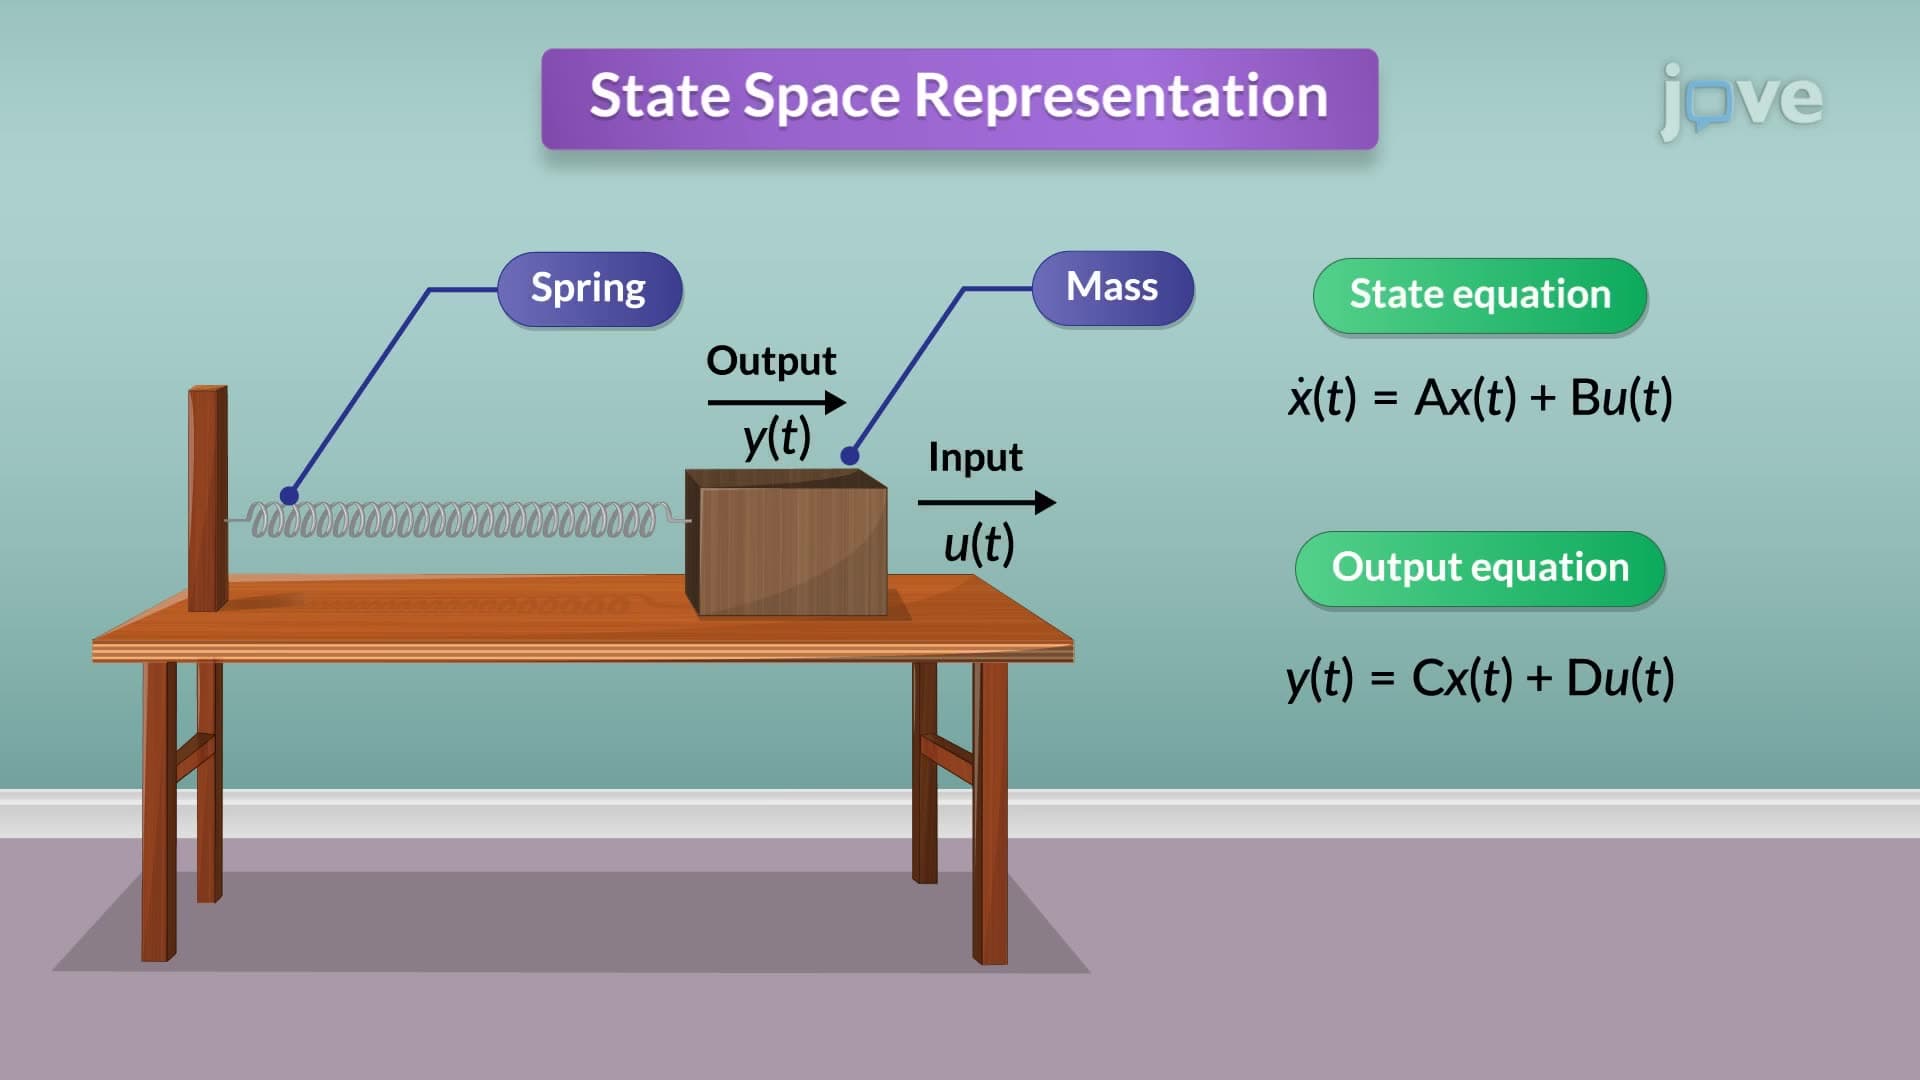
The conversion of state-space representation to a transfer function is a fundamental process in system analysis. It provides a method for transitioning from a time-domain description to a frequency-domain representation, which is crucial for simplifying the analysis and design of control systems.
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
The transformation process begins with the state-space representation, characterized by the state equation and the output equation. These equations are typically represented as:
550
 01:20
Calibration Curves: Linear Least Squares
4.1K
A calibration curve is a plot of the instrument's response against a series of known concentrations of a substance. This curve is used to set the instrument response levels, using the substance and its concentrations as standards. Alternatively, or additionally, an equation is fitted to the calibration curve plot and subsequently used to calculate the unknown concentrations of other samples reliably.
For data that follow a straight line, the standard method for fitting is the linear...
For data that follow a straight line, the standard method for fitting is the linear...
4.1K