
动态指定位及其适应:通过新型机器人任务量化
Luis Garcia-Fernandez1, Andria J Farrens2,3, Christopher A Johnson2
1Mechanical and Aerospace Engineering Department, University of California Irvine, Irvine, CA, 92617, USA. garciaf7@uci.edu.
Experimental brain research
|January 11, 2026

概括
这项研究表明,动态指定位,或者知道你的指在空间中的位置,并不完全准确,但可以使用视觉线索来适应. 大指和食指的定位能力与正常成年人有关.
科学领域:
- 神经科学是一个神经科学.
- 生物力学 生物力学
- 人类运动控制人体运动控制
背景情况:
- 亲感对于手的功能至关重要,但动态指的亲感能力并未得到充分理解.
- 量化指本地化及其适应能力对于理解手控至关重要.
研究的目的:
- 量化动态指定位能力在没有损害的个人.
- 为了研究指局部化如何适应自身视觉旋转扰动.
- 为了比较指和食指的定位能力及其与机器人自身感知评估的关系.
主要方法:
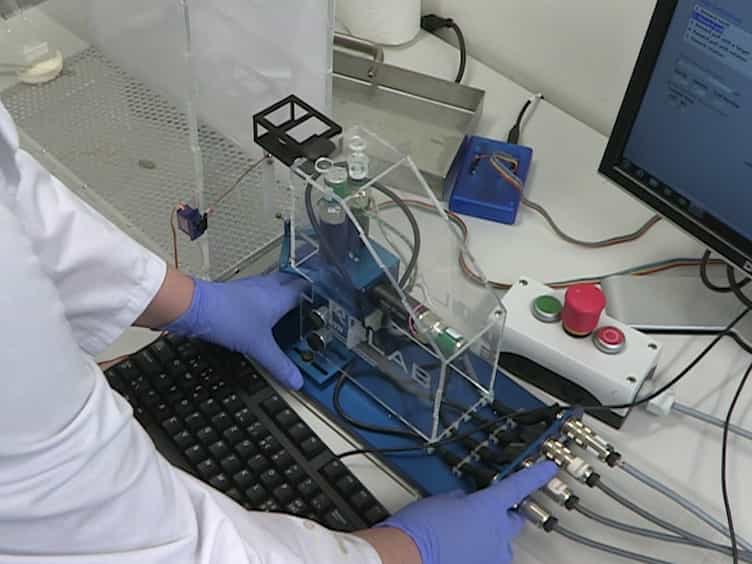
- 开发了一个新的机器人任务来测量动态指定位与视觉错误反.
- 整合了一个自身视觉旋转扰动来评估适应性.
- 改变了指的速度和旋转直径,并比较了食指的性能.
主要成果:
- 平均指定位错误 (常量错误: -5.9°,可变错误: 25.2°,绝对错误: 29.2°) 是相对一致的,并没有受到速度或直径的显著影响.
- 逆转指旋转导致了暂时的错误增加,随后是快速的适应,这表明了一个以身体为中心的参考框架.
- 指和食指的定位错误与机器人手指亲感评估相比并相关 (ρ = 0.61,p = 0.001).
结论:
- 动态指定位是中度不准确的,但可以在以身体为中心的参考框架内使用视觉反来适应.
- 大指和食指的动态定位能力与正常成年人有关.
- 这些发现有助于理解指自身感受及其在手部功能中的作用.

相关概念视频
 01:22
Controller Configurations
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller aligns...
 01:30
Vector Functions and Motion: Problem Solving
Accurate position tracking is fundamental to the safe and effective operation of unmanned aerial vehicles (UAVs), particularly during precision maneuvers near complex structures. In this scenario, a drone is programmed to perform a high-precision inspection of a vertical structure, starting at position ((x, y, z) = (3, 0, 0)), with an initial velocity oriented in the positive z-direction. The trajectory of the drone is governed by a time-dependent acceleration function a(t), which is predefined...