

概括
本研究为多代理系统 (MAS) 引入了差异化的私有领导者遵循共识控制 (DPLFCC). 这种新方法确保了隐私和共识控制,即使使用两个时间尺度.
科学领域:
- 控制工程 控制工程 控制工程
- 网络安全 网络安全
- 分布式系统 分布式系统
背景情况:
- 多代理系统 (MAS) 需要强大的协调控制策略.
- 确保MAS的数据隐私至关重要,特别是对于敏感的操作数据.
- 双倍尺度系统在控制设计和稳定性分析方面存在独特的挑战.
研究的目的:
- 调查不同私人领导者遵循共识控制 (DPLFCC) 问题,用于在两个时间尺度上运行的MAS.
- 开发一个新的共同设计框架,将隐私保护与共识控制相结合.
- 在保持差异性隐私的同时,实现平均平方领导者遵循的共识.
主要方法:
- 为共同设计框架开发了一个独特的时间尺度依赖于Lyapunov函数.
- 为每个追随者建立了一个具有噪音控制的新分布式共识控制器.
- 控制器解决标准和隐私级别是基于时间尺度参数设计的.
主要成果:
- 拟议的战略实现了最终的平均平方领导者遵循共识与差异性隐私.
- 调整噪声控制增益可以提高追随者初始状态的隐私.
- 数字模拟验证了开发的算法的有效性,扩展到领导者的隐私.
结论:
- 新的DPLFCC框架有效地解决了在两个时间尺度MASS中的控制和隐私挑战.
- 该方法提供了一个可靠的解决方案,可以在保护敏感信息的同时达成共识.
- 这些发现适用于各种需要安全和协调运行的MAS应用程序.
更多相关视频
 08:21
Monitoring GPCR-β-arrestin1/2 Interactions in Real Time Living Systems to Accelerate Drug Discovery
Published on: June 28, 2019
7.3K
 12:21
Large-Scale Production of Cardiomyocytes from Human Pluripotent Stem Cells Using a Highly Reproducible Small Molecule-Based Differentiation Protocol
Published on: July 25, 2016
11.1K
相关概念视频
 01:23
Linear time-invariant Systems
876
A system is linear if it displays the characteristics of homogeneity and additivity, together termed the superposition property. This principle is fundamental in all linear systems. Linear time-invariant (LTI) systems include systems with linear elements and constant parameters.
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
876
 01:24
BIBO stability of continuous and discrete -time systems
892
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
892
 02:41
pH Scale
79.0K
Hydronium and hydroxide ions are present both in pure water and in all aqueous solutions, and their concentrations are inversely proportional as determined by the ion product of water (Kw). The concentrations of these ions in a solution are often critical determinants of the solution’s properties and the chemical behaviors of its other solutes. Two different solutions can differ in their hydronium or hydroxide ion concentrations by a million, billion, or even trillion times. A common means of...
79.0K
 01:26
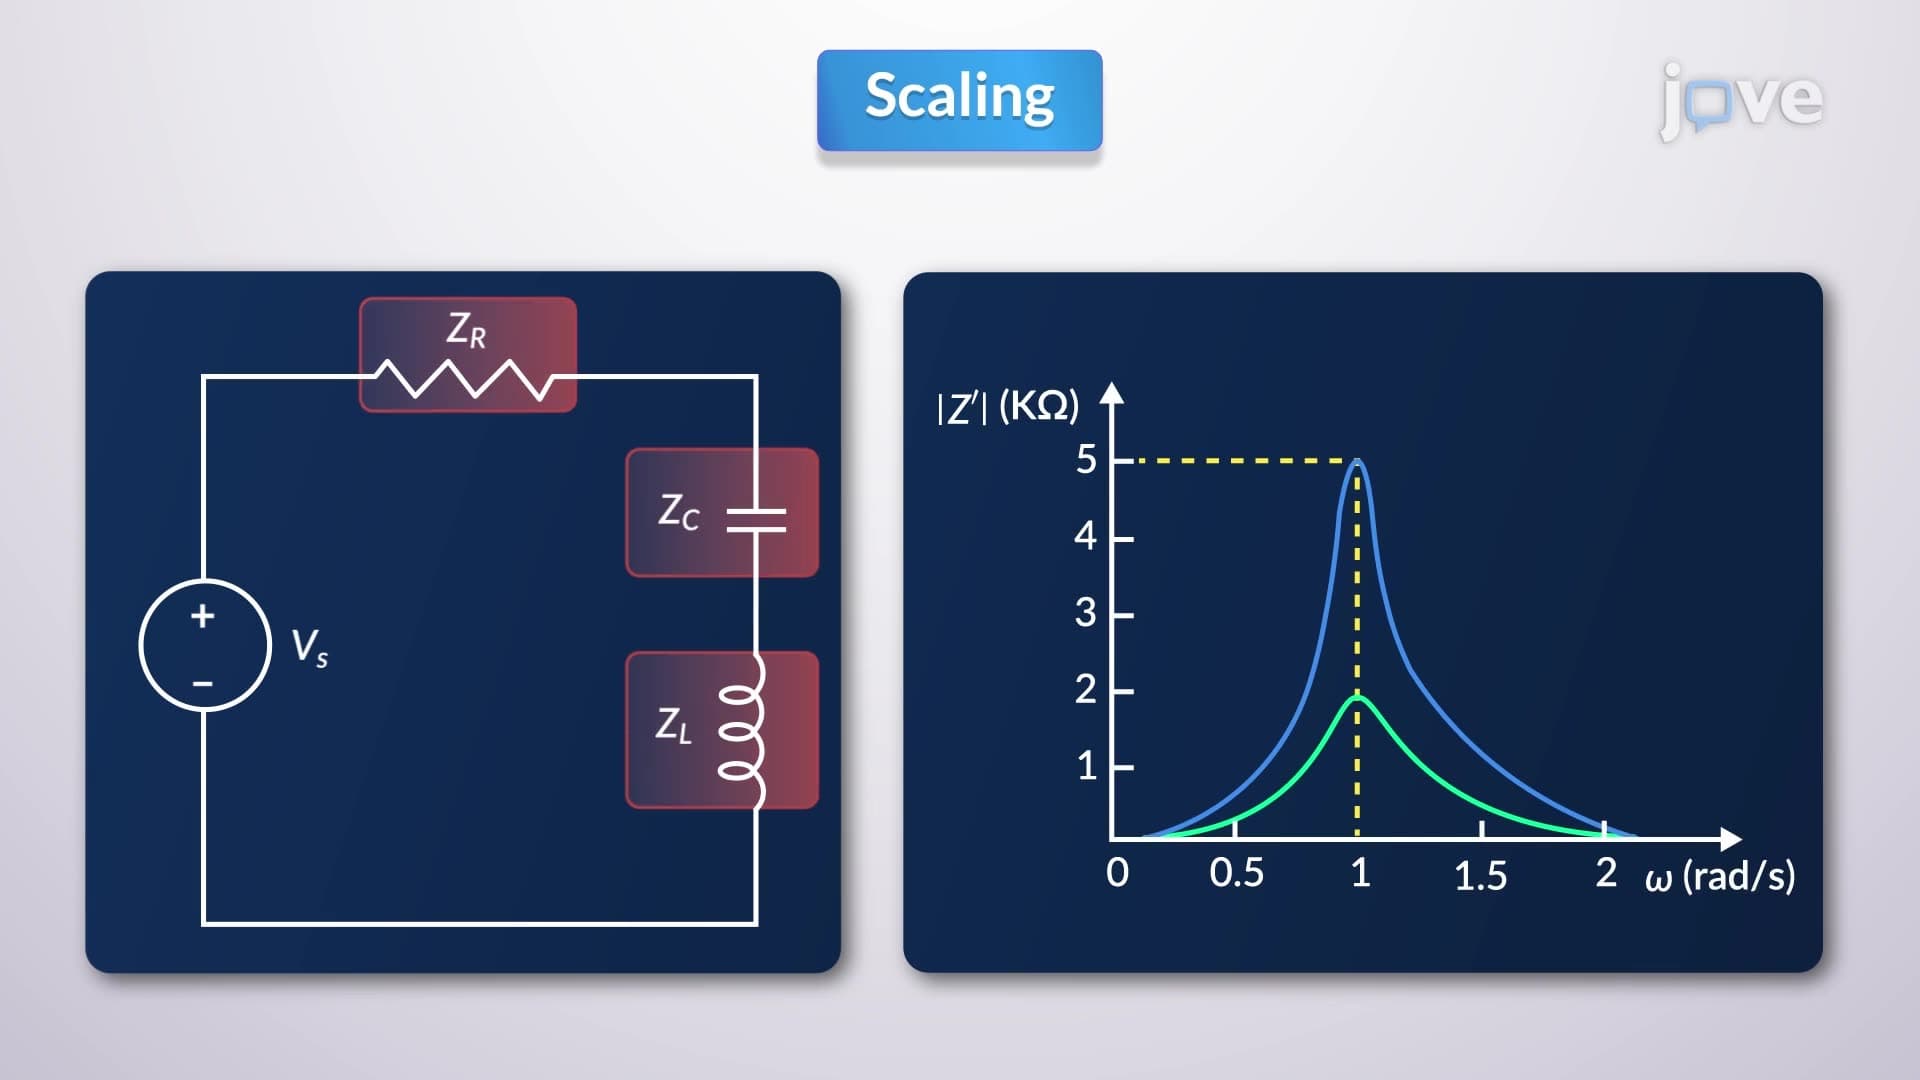
Scaling
566
In designing and analyzing filters, resonant circuits, or circuit analysis at large, working with standard element values like 1 ohm, 1 henry, or 1 farad can be convenient before scaling these values to more realistic figures. This approach is widely utilized by not employing realistic element values in numerous examples and problems; it simplifies mastering circuit analysis through convenient component values. The complexity of calculations is thereby reduced, with the understanding that...
566
 01:18
Second Order systems II
390
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
390
 01:21
First Order Systems
402
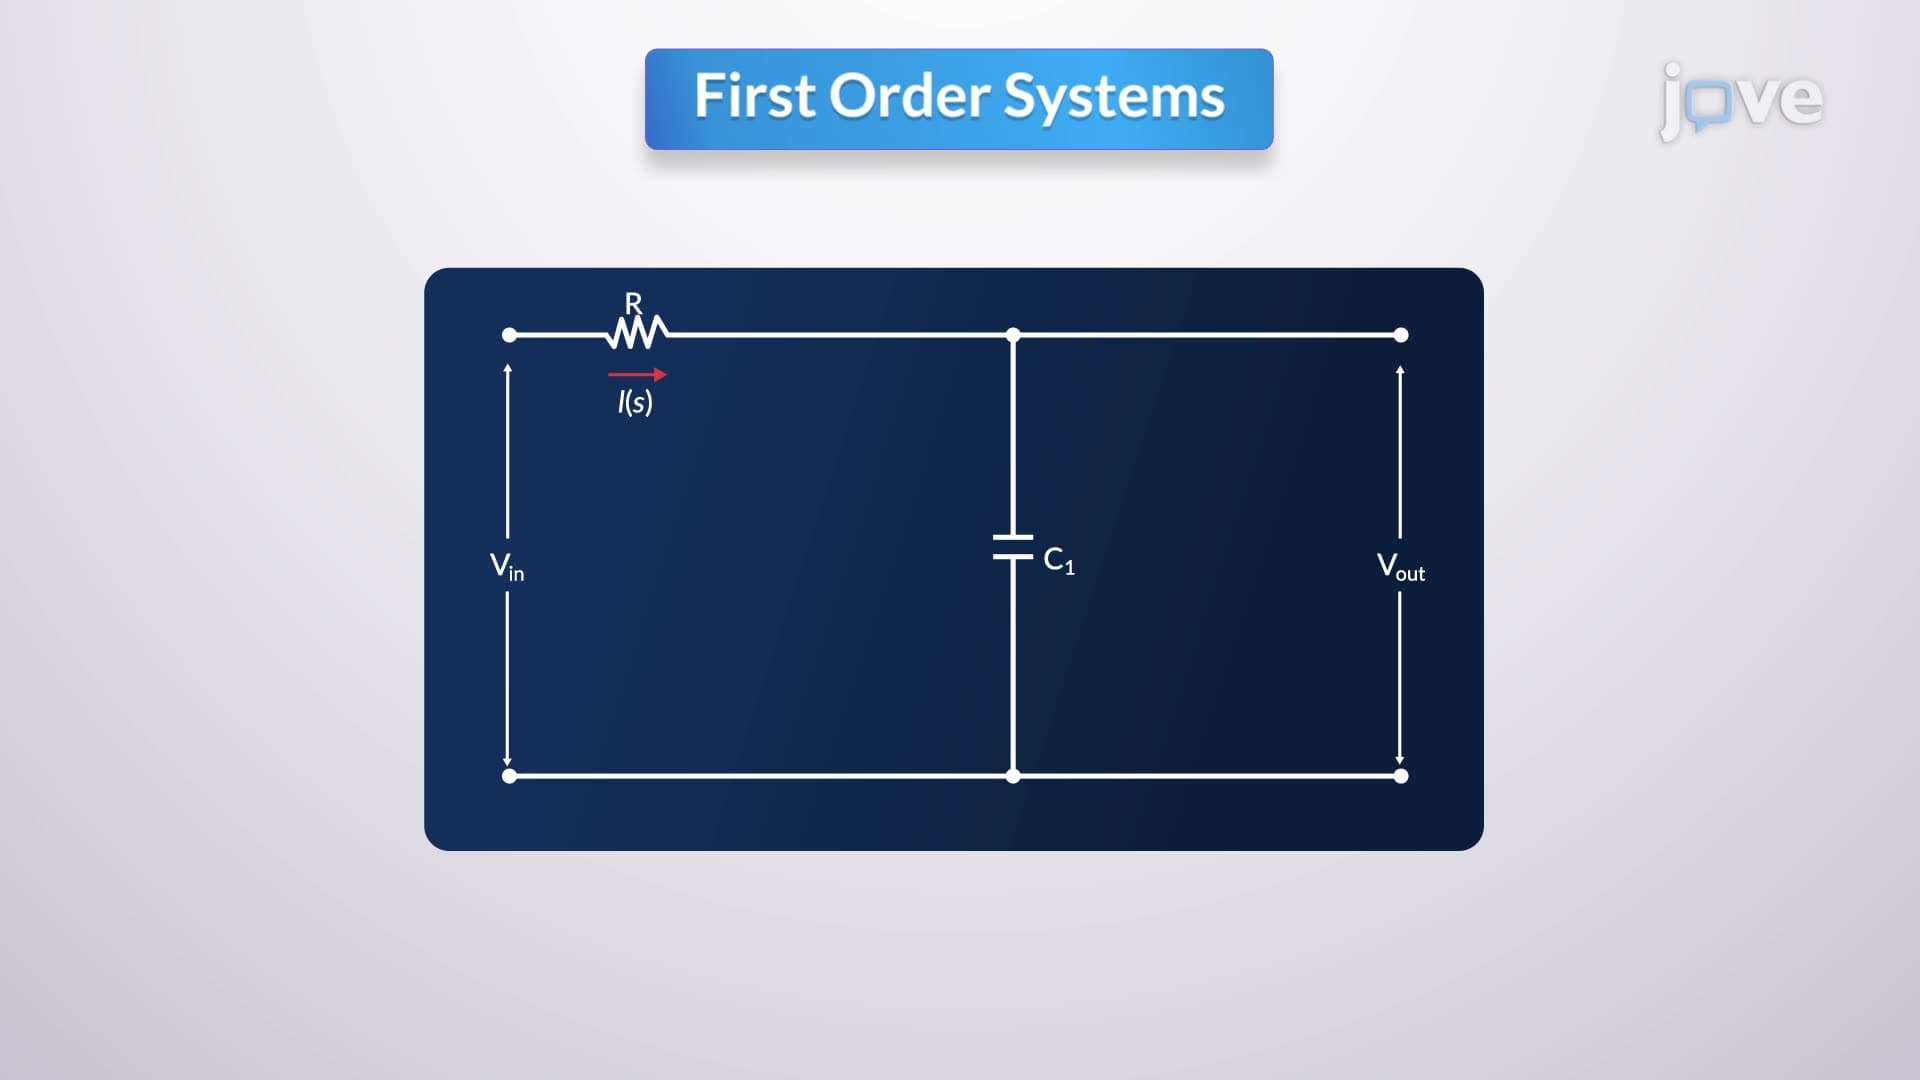
First-order systems, such as RC circuits, are foundational in understanding dynamic systems due to their straightforward input-output relationship. Analyzing their responses to different input functions under zero initial conditions reveals significant insights into system behavior.
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
When a first-order system is subjected to a unit-step input, its response is characterized by its transfer function. By applying the Laplace transform of the unit-step input to the transfer function, expanding the...
402