
机器人辅助设备对中风后患者的膝运动进行比较分析:基于IMU的试点研究
Toshiaki Tanaka1,2, Shunichi Sugihara3, Takahiro Miura4
1Research Center for Advanced Science and Technology (RCAST), The University of Tokyo, Tokyo 113-8656, Japan.
Journal of functional morphology and kinesiology
|January 21, 2026

概括
这项研究用惯性测量单位 (IMU) 量化了步行康复期间的人机同步. 两种机器人设备都改善了膝盖运动,curara®显示了更顺的协调,验证了基于IMU的分析,以优化辅助步行技术.
科学领域:
- 生物医学工程 生物医学工程
- 康复机器人 康复机器人
- 步态分析 步态分析
背景情况:
- 机器人辅助设备对于中风后的步行康复至关重要.
- 在步行中对人机同步的定量评估是有限的.
- 越来越多地使用外骨架设备,如HAL®和curara®.
研究的目的:
- 量化评估步态动力学和人机联合运动同步.
- 在中风后的患者中比较两个外骨架类型设备 (HAL®和curara®).
- 评估基于IMU的同步测量对人机交互的可行性.
主要方法:
- 两名中风后患者在跑步机上行走,有或没有HAL®和curara®辅助.
- 惯性测量单元 (IMU) 同时记录了膝关节的角度.
- 使用布兰德-阿尔特曼图,RMSE和MSJ进行了同步分析.
主要成果:
- 这两种设备都改善了膝盖的动运动,减少了RMSE.
- 通过curara®辅助的步行显示了较低的平均同步冲动 (MSJ),表明协调更顺.
- 布兰德-阿尔特曼分析显示,与辅助设备 (尤其是curara®) 达成一致的偏差减少和更窄的界限.
结论:
- 在中风后的患者中,HAL®和curara®都提高了步态同步和流性.
- curara® 展示了优越的扭矩控制和与人类运动的调整.
- 基于IMU的分析对于量化人机同步是有效的,有助于机器人步行康复优化.
相关概念视频
 01:20
Comparing the Survival Analysis of Two or More Groups
573
Survival analysis is a cornerstone of medical research, used to evaluate the time until an event of interest occurs, such as death, disease recurrence, or recovery. Unlike standard statistical methods, survival analysis is particularly adept at handling censored data—instances where the event has not occurred for some participants by the end of the study or remains unobserved. To address these unique challenges, specialized techniques like the Kaplan-Meier estimator, log-rank test, and...
573
 01:24
Absolute Motion Analysis- General Plane Motion
542
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
542
 01:21
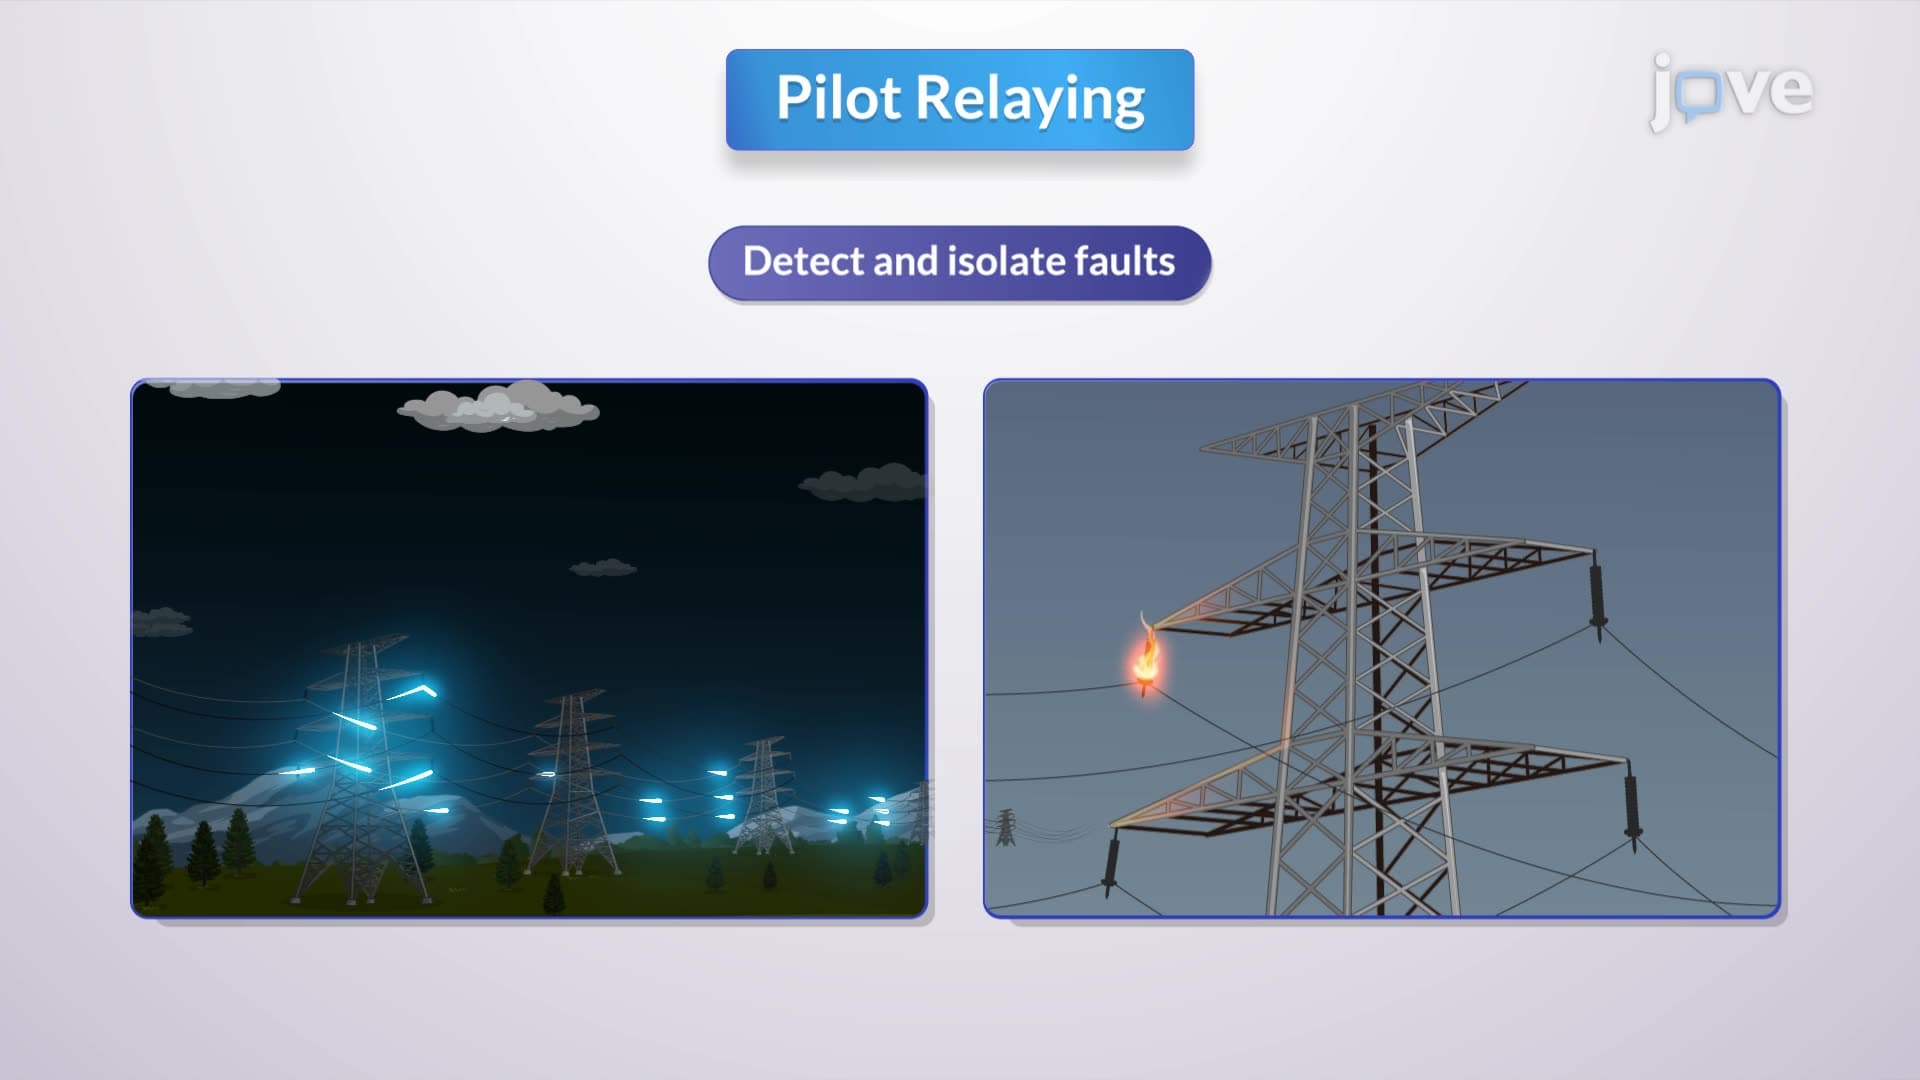
Pilot and Numeric Relaying
483
Pilot relaying is a type of differential protection used in power systems. It compares electrical quantities at the terminals of equipment via a communication channel instead of direct relay interconnection. This method is essential for transmission lines where the terminals are far apart, typically up to 80 km for lines with 69 to 115 kV ratings. Four types of communication channels are used for pilot relaying:
483
 01:10
Relative Motion Analysis - Acceleration
838
A slider-crank mechanism converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider. The movement of the slider-crank is an example of general plane motion as the fluctuating angle between the crank and the connecting rod. Consider a segment AB where point A is at the end of the slider and point B is on the diametrically opposite end to point A, on a crack. The variance in...
838
 01:24
Relative Motion Analysis - Velocity
707
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
707
 01:23
Knee Joint
3.1K
The knee joint is the most complicated joint in the body. It consists of three articulations– two tibiofemoral and one patellofemoral. As is characteristic of synovial joints, the knee joint has a thin articular capsule that partially surrounds this joint cavity. Additionally, several ligaments, muscles, and cartilaginous structures support the movement of the knee.
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
A total of seven ligaments support the knee joint. The patellar ligament, which is also attached to the quadriceps femoris...
3.1K