相关实验视频
Updated: Jan 23, 2026
09:01

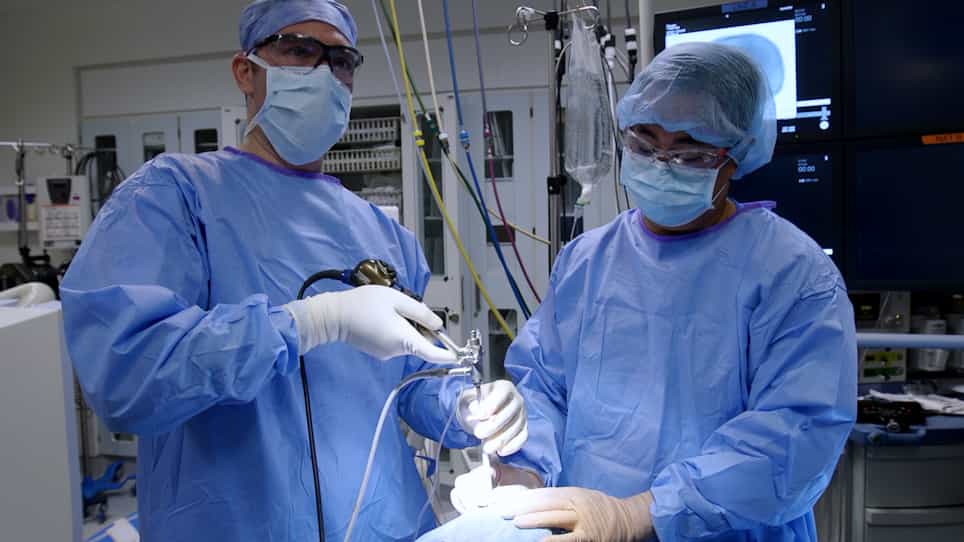
Minimally Invasive Endoscopic Intracerebral Hemorrhage Evacuation
Published on: October 15, 2021
8.5K
慢性腹腔内血瘤的最小侵入性疏散:重新使用脊柱刚性内镜
M Majovsky1, T Moravec1, A Khadanovich2
1Department of Neurosurgery and Neurooncology, First Faculty of Medicine, Charles University and Military University Hospital, Prague, Czech Republic.
Brain & spine
|January 22, 2026

概括
当内镜无法使用时,将脊柱内镜用于慢性腹腔内血瘤 (cSDH) 疏散是可行的替代方案. 这种技术可以改善复杂cSDH病例的可视化和有效管理.
科学领域:
- 神经外科 神经外科
- 最少侵入性的手术
背景情况:
- 慢性亚皮血瘤 (cSDH) 是一种流行的神经外科疾病,特别是在老年患者中.
- 标准的孔疏散对于复杂的病例可能是不够的,如隔膜或复发性cSDH.
- 内镜技术提高了疏散效果,但需要专门的头骨神经内镜,这些神经内镜并不普遍可用.
研究的目的:
- 为了研究重新使用脊柱刚性内镜进行内镜疏散的可行性和有效性,复发性,隔膜cSDH.
- 证明非专用内镜系统在管理复杂cSDH时的实用性.
主要方法:
- 一个单个案例的概念验证研究使用硬脊柱内镜进行.
- 该程序涉及一个小的骨切割,用于内镜引入到体外空间.
- 内镜有助于检查,凝块疏散,静血和精确的体内排水位置.
主要成果:
- 脊柱内镜提供了有组织的血块,和新血管的清晰可视化.
- 直接可视化使得手术内发现的有效管理和精确的排水位置.
- 手术后CT显示出血瘤体积减少83%,中线转移纠正和完全的神经恢复没有并发症.
结论:
- 重用脊柱内镜是内镜cSDH疏散的实际替代方案,特别是在资源有限的环境中.
- 该技术改善了可视化,允许膜和血管的管理,并有助于准确的排水位置.
- 需要进一步的研究来验证这种方法在更大的患者队列中的有效性,安全性和可重复性.
相关概念视频
 00:49
Rigid Body Equilibrium Problems - I
5.4K
A rigid body is said to be in static equilibrium when the net force and the net torque acting on the system is equal to zero. To solve for rigid body equilibrium problems, do the following steps.
5.4K
 01:21
Rigid Body Equilibrium Problems - II
7.9K
A rigid body is in static equilibrium when the net force and the net torque acting on the system are equal to zero.
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
7.9K
 01:13
Kinetic Energy for a Rigid Body
519
Imagine a solid object involved in a general planar movement, with its center of mass pinpointed at a spot labeled G. The object's kinetic energy relative to an arbitrary point A can be quantified for each of its particles - the ith particle in this case. This measurement is achieved through the employment of the relative velocity definition. The position vector, known as rA, extends from point A to the mass element i.
519
 01:12
Equation of Motion for a Rigid Body
613
The movement of a rigid object can be understood through the equations that explain both translational and rotational motion about the center of mass of the object, point G. This center of mass is the point where the equation of motion for translational motion comes into play, as per Newton's Second Law.
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different...
The combined moments generated about the center of mass of the object are equal to the rate of change of the angular momentum of the body. An external force, when applied at a different...
613
 01:06
Virtual Work for a System of Connected Rigid Bodies
742
Virtual work is a powerful method used to solve problems involving several connected rigid bodies. When the system is in equilibrium, virtual work is zero. This allows the calculation of the resulting forces when a system undergoes a virtual displacement. When attempting to analyze such a system, first, use a free-body diagram, where an independent coordinate represents the configuration of the links, and mark its deflected position resulting from the positive virtual displacement.
Next,...
Next,...
742
 01:11
Angular Momentum: Rigid Body
15.5K
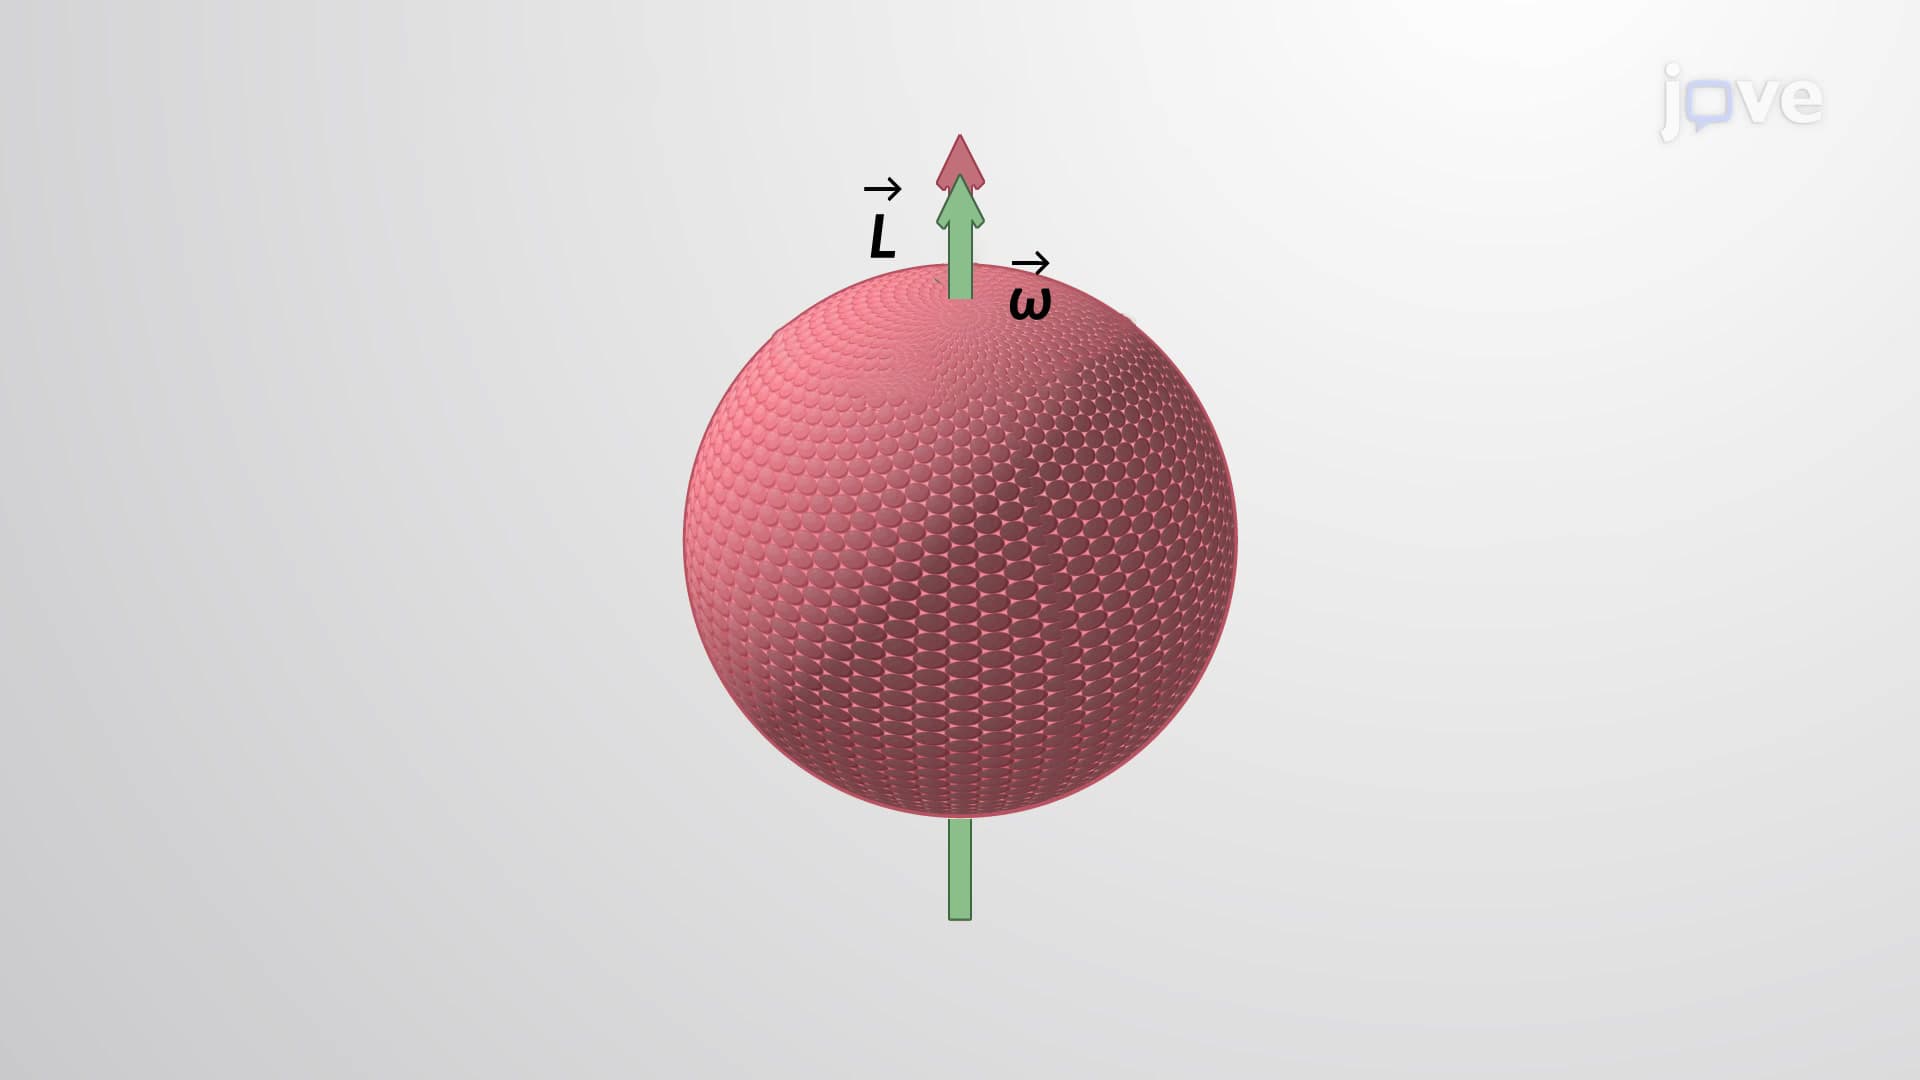
The total angular momentum of a rigid body can be calculated using the summation of the angular momentum of all the tiny particles rotating in the same plane. Considering all the tiny particles rotating in the x-y plane, the direction of angular momentum of all such particles and that of the rigid body would be perpendicular to the plane of the rotation along the z-axis.
This calculation can get complicated when tiny particles within the rigid body are not rotating in the same plane but have...
This calculation can get complicated when tiny particles within the rigid body are not rotating in the same plane but have...
15.5K