儿童电动自行车伤害严重程度的配置途径:fsQCA对全球证据的研究
Yanni Li1, Qing Li2,3, Mingming Liang2
1Tuberculosis Prevention and Control Institute, Anhui Provincial Center for Disease Control and Prevention, Hefei, Anhui, China.
Frontiers in public health
|January 22, 2026

概括
儿童电动自行车受伤是复杂的,受研究质量和设计的影响,而不是单一的因素. 严格的研究和以儿童为重点的样本提高了安全性,为儿童骑自行车者提供了更好的预防策略.
科学领域:
- 儿科伤害研究儿童伤害研究
- 公共卫生 公共卫生
- 道路交通安全问题 道路安全问题
背景情况:
- 全球儿童和青少年使用电动自行车的激增.
- 对受伤严重程度和安全管理的担忧.
- 对影响儿科电动自行车伤害结果的因素的理解有限.
研究的目的:
- 调查严重的儿科电动自行车伤害的配置途径.
- 使用模糊集定性比较分析 (fsQCA) 整合方法和上下文因素.
- 确定与受伤严重程度相关的条件和配置.
主要方法:
- 将fsQCA应用于22个案例,分析了7个条件.
- 条件包括研究质量,研究设计和样本特征.
- 探索了严重伤害结果的必要条件和足够的配置.
主要成果:
- 高质量的研究,强大的设计和以儿童为中心的样本与严重程度差异有关.
- 确定了三条足够的途径,增加了儿科电动自行车伤害严重程度.
- 缺乏行为风险分析,严格的设计与较低的严重程度相关.
结论:
- 儿童电动自行车损伤的严重程度是由复杂的相互作用造成的,而不是单一的因素.
- fsQCA为分析异质证据提供了一个新的框架.
- 调查结果为儿童电动自行车用户提供了有效的伤害预防和安全政策.
相关概念视频
 02:55
The Evidence for Evolution
47.7K
Genetic variations accumulating within populations over generations give rise to biological evolution. Evolutionary changes can result in the formation of novel varieties and entire new species. These changes are responsible for the diverse forms of life inhabiting the planet. The evidence for evolution suggests that all living organisms descended from common ancestors.
47.7K
 01:50
Global Climate Change
28.8K
Throughout its ~4.5 billion year history, the Earth has experienced periods of warming and cooling. However, the current drastic increase in global temperatures is well outside of the Earth’s cyclic norms, and evidence for human-caused global climate change is compelling. Paleoclimatology, the study of ancient climate conditions, provides ample evidence for human-caused global climate change by comparing recent conditions with those in the past.
28.8K
 02:46
Electron Configurations
25.5K
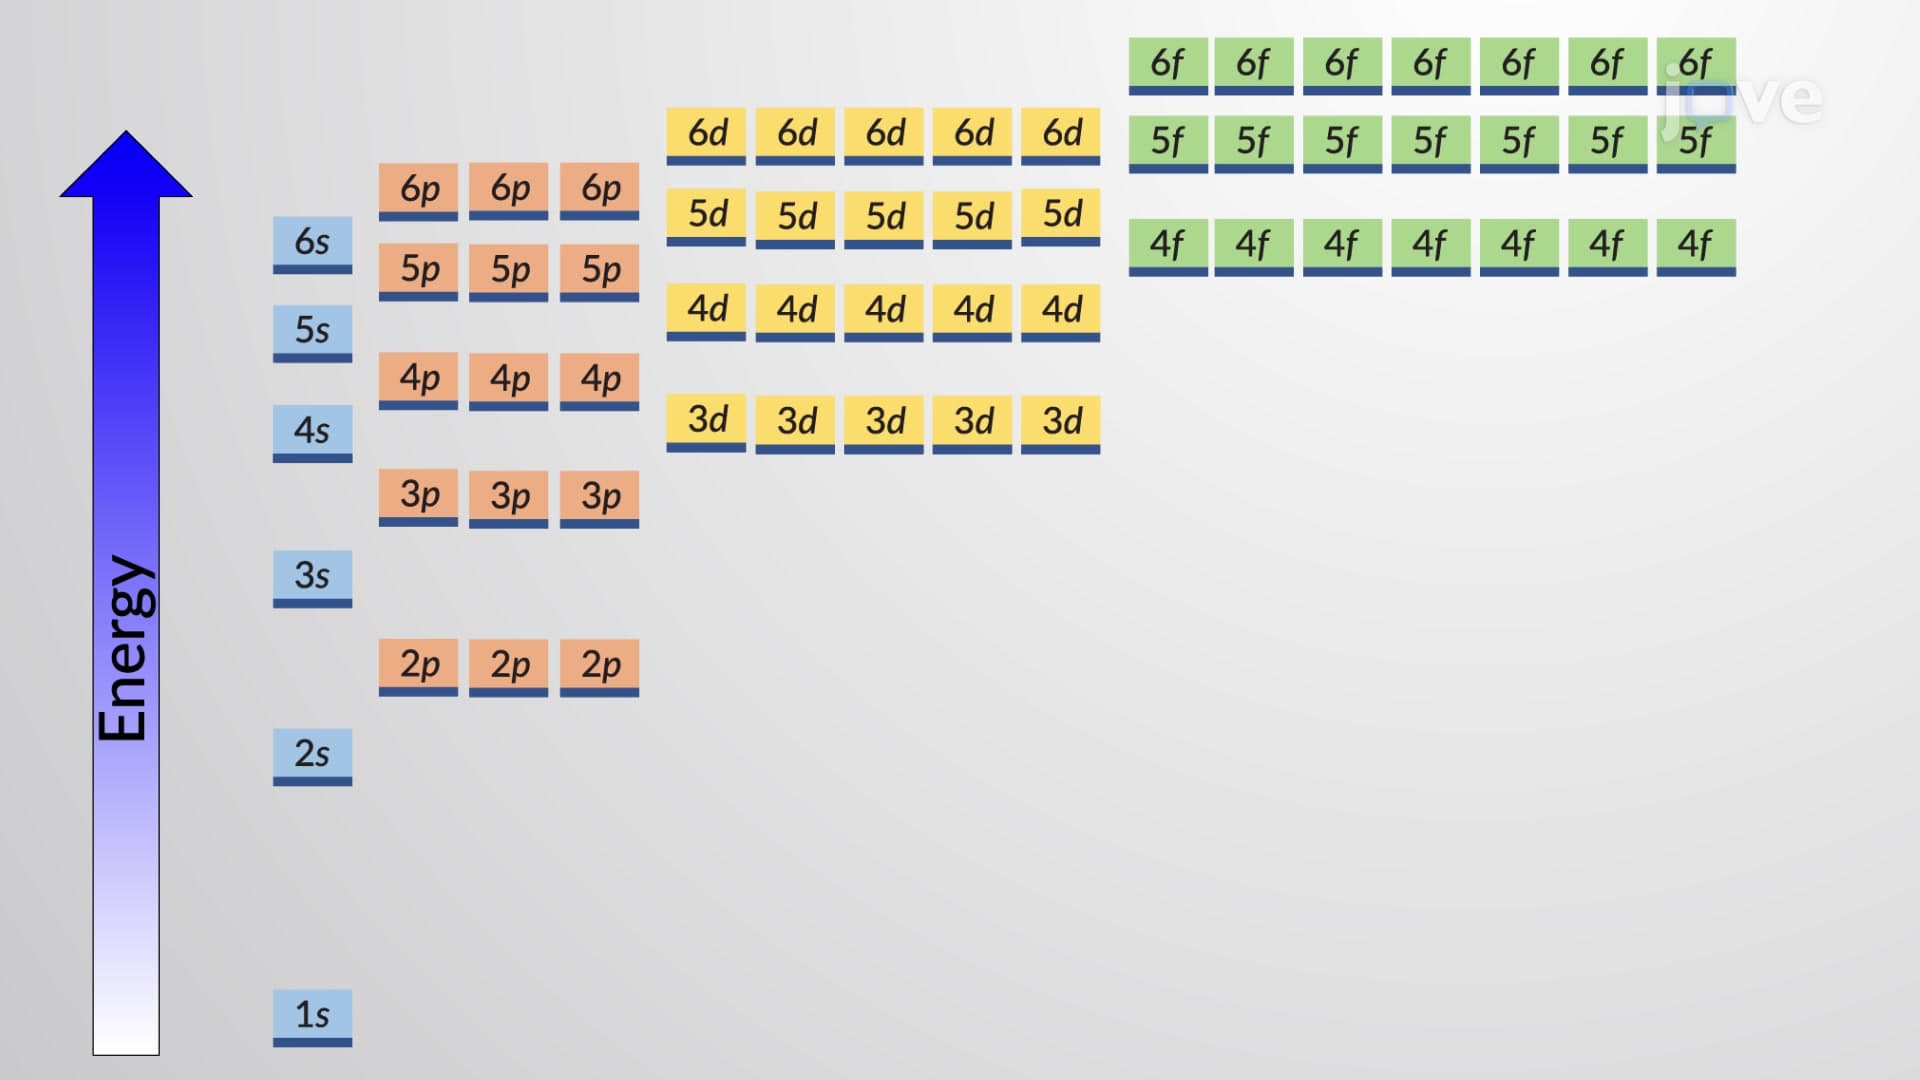
Electron configurations and orbital diagrams can be determined by applying the Aufbau principle (each added electron occupies the subshell of lowest energy available), Pauli exclusion principle (no two electrons can have the same set of four quantum numbers), and Hund’s rule of maximum multiplicity (whenever possible, electrons retain unpaired spins in degenerate orbitals).
The relative energies of the subshells determine the order in which atomic orbitals are filled (1s, 2s, 2p, 3s, 3p,...
The relative energies of the subshells determine the order in which atomic orbitals are filled (1s, 2s, 2p, 3s, 3p,...
25.5K
 01:22
Controller Configurations
357
Controller configurations are crucial in a car's cruise control system because they manage speed over time to maintain a consistent pace regardless of road conditions, thereby meeting design goals. In traditional control systems, fixed-configuration design involves predetermined controller placement. System performance modifications are known as compensation.
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
Control-system compensation involves various configurations, most commonly series or cascade compensation, in which the controller...
357
 03:26
Electron Configuration of Multielectron Atoms
64.6K
The alkali metal sodium (atomic number 11) has one more electron than the neon atom. This electron must go into the lowest-energy subshell available, the 3s orbital, giving a 1s22s22p63s1 configuration. The electrons occupying the outermost shell orbital(s) (highest value of n) are called valence electrons, and those occupying the inner shell orbitals are called core electrons. Since the core electron shells correspond to noble gas electron configurations, we can abbreviate electron...
64.6K
 01:23
Stability of Equilibrium Configuration
783
Understanding the stability of equilibrium configurations is a fundamental part of mechanical engineering. In any system, there are three distinct types of equilibrium: stable, neutral, and unstable.
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...
783