相关实验视频
Updated: Jan 28, 2026
10:19
3D Kinematic Gait Analysis for Preclinical Studies in Rodents
Published on: August 3, 2019
11.3K
由水动力液压人工肌肉驱动的生物四足机器人的步态规划和承载能力分析
Jun Li1, Zengmeng Zhang1,2, Shoujie Feng1
1Naval Architecture and Ocean Engineering College, Dalian Maritime University, Dalian 116026, China.
Biomimetics (Basel, Switzerland)
|January 27, 2026

概括
这项研究介绍了一种灵感来自的机器人,它使用水液压人造肌肉 (WHAM) 用于水生环境. 一个新的模型基于WHAM压力准确预测腿部关节负荷,从而实现有效的机器人运动.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 生物模拟学是一种生物模拟学.
- 流体力学 流体力学 流体力学
背景情况:
- 传统的爬行机器人由于电气或油液压系统,在水中环境中面临着防水挑战.
- 灵感来自的设计提供了稳定的运动,特别是在水下应用中.
- 现有的机器人关节模块缺乏动态负载调整的理论基础.
研究的目的:
- 开发一个由水液动力人工肌肉 (WHAMs) 驱动的生物四足机器人,克服防水问题.
- 建立一个理论模型,用于脚关节负荷调整在WHAM驱动的机器人.
- 通过实验测试验证模型的预测.
主要方法:
- 设计和制造一个以为灵感的四足机器人,使用WHAMs.
- 基于WHAM原则的腿部关节压力差负荷模型的开发.
- 步态规划分析,以确定运动期间最大的支力.
- 一个单脚原型的实验测试,以评估静态和动态负载能力.
主要成果:
- 这种由WHAM驱动的机器人成功地绕过了水中操作的传统防水挑战.
- 为腿部关节建立了一个经过验证的压力差负荷模型,将WHAM压力与关节负荷相关联.
- 实验测试显示,最大静态负载能力为23公斤,动态负载能力为10公斤.
- 该模型与实验结果有很好的一致性,为负载调整提供了理论指导.
结论:
- 水液压人工肌肉为水生环境中的机器人系统的防水提供了可行的解决方案.
- 开发的压力差负载模型为优化腿部关节性能和WHAM驱动机器人的负载管理提供了至关重要的理论支持.
- 这项研究为更强大,更适应水下机器人运动系统铺平了道路.
相关概念视频
 01:47
Lung Capacity
56.2K
The air in the lungs is measured in volumes and capacities. Lung volume measures reflect the amount of air taken in, released, or left over after a lung function, like a single inhalation. Lung capacity measures are sums of two or more lung volume measures.
56.2K
 01:16
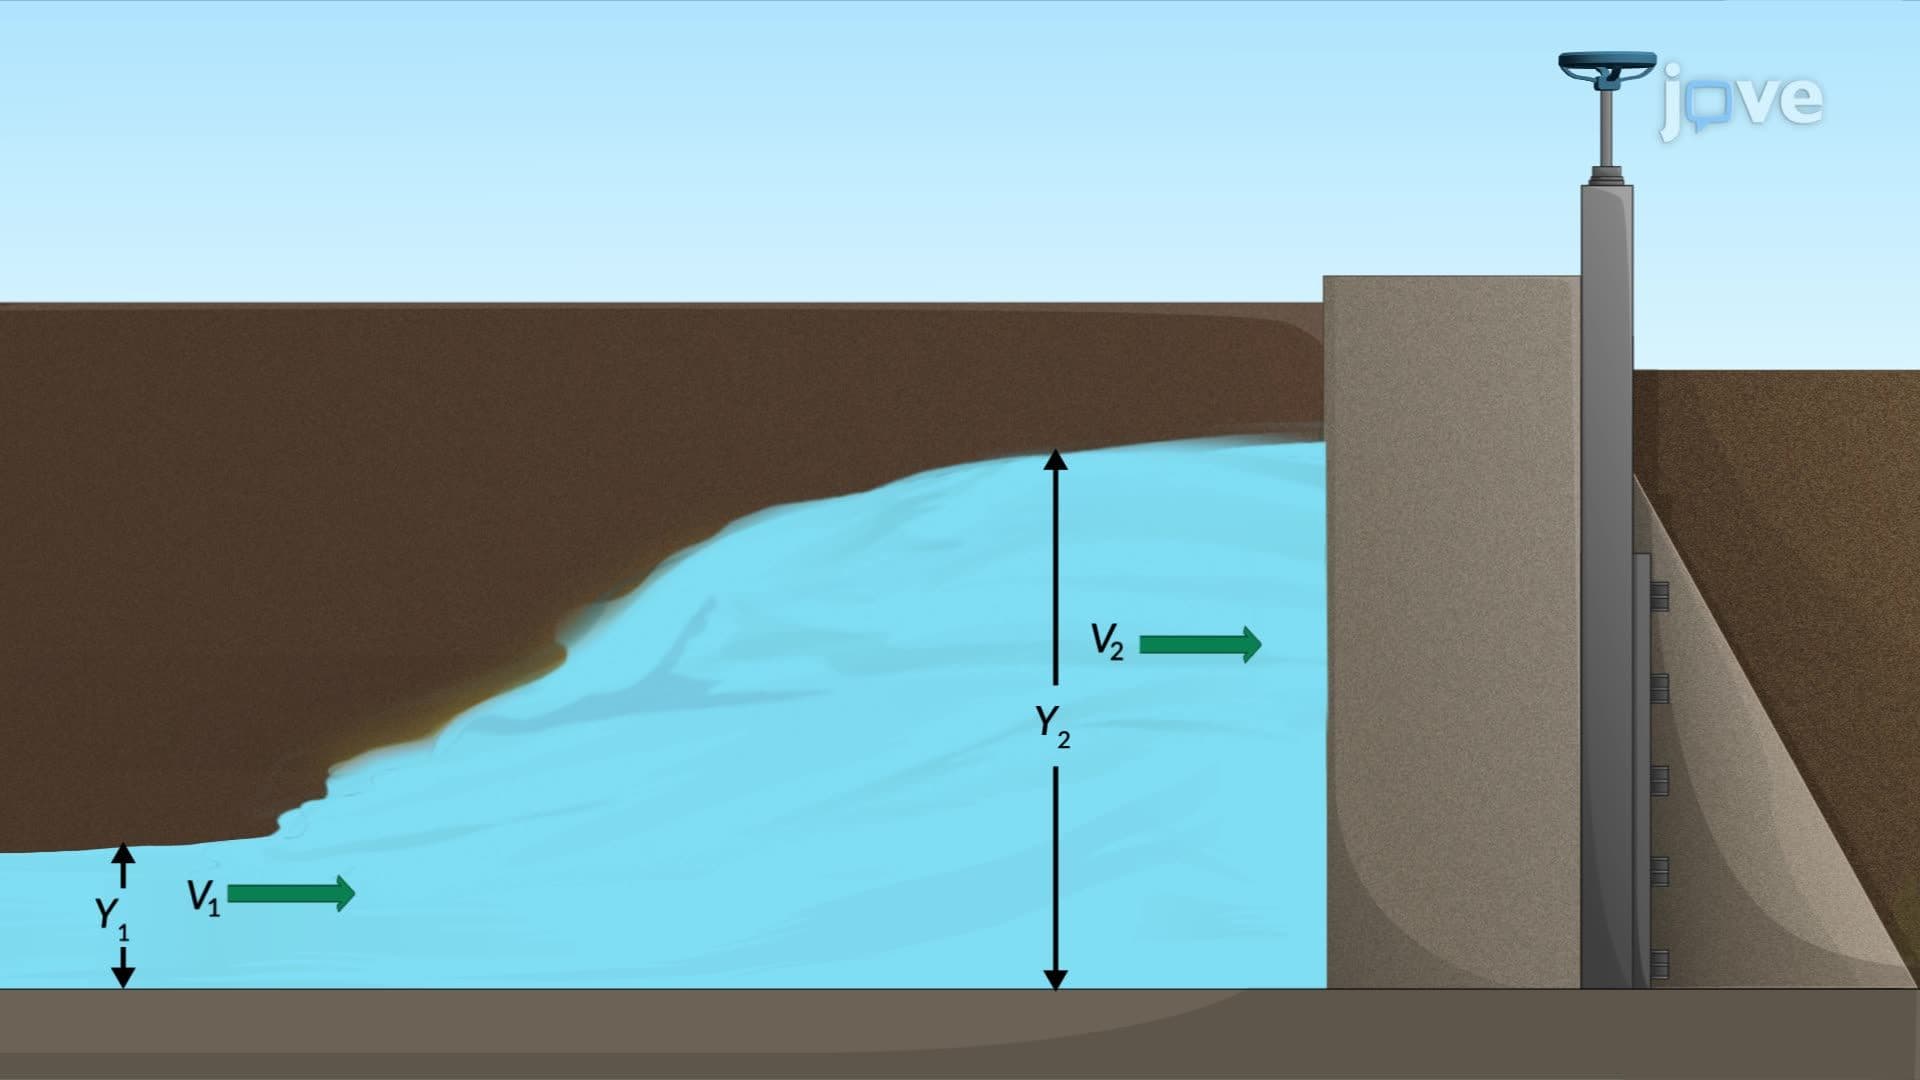
Hydraulic Jump: Problem Solving
534
To analyze a hydraulic jump in a rectangular channel with a flow speed of 6 meters per second, follow these steps:Calculate Effective Upstream Velocity:When the downstream gate closes, a hydraulic jump forms, traveling upstream at 2 meters per second. This wave speed combines with the initial channel flow velocity, creating an effective upstream velocity.Identify Flow Velocities Before and After the Hydraulic Jump:Upstream of the hydraulic jump, the effective flow velocity includes both the...
534
 01:29
Hydraulic Jump
665
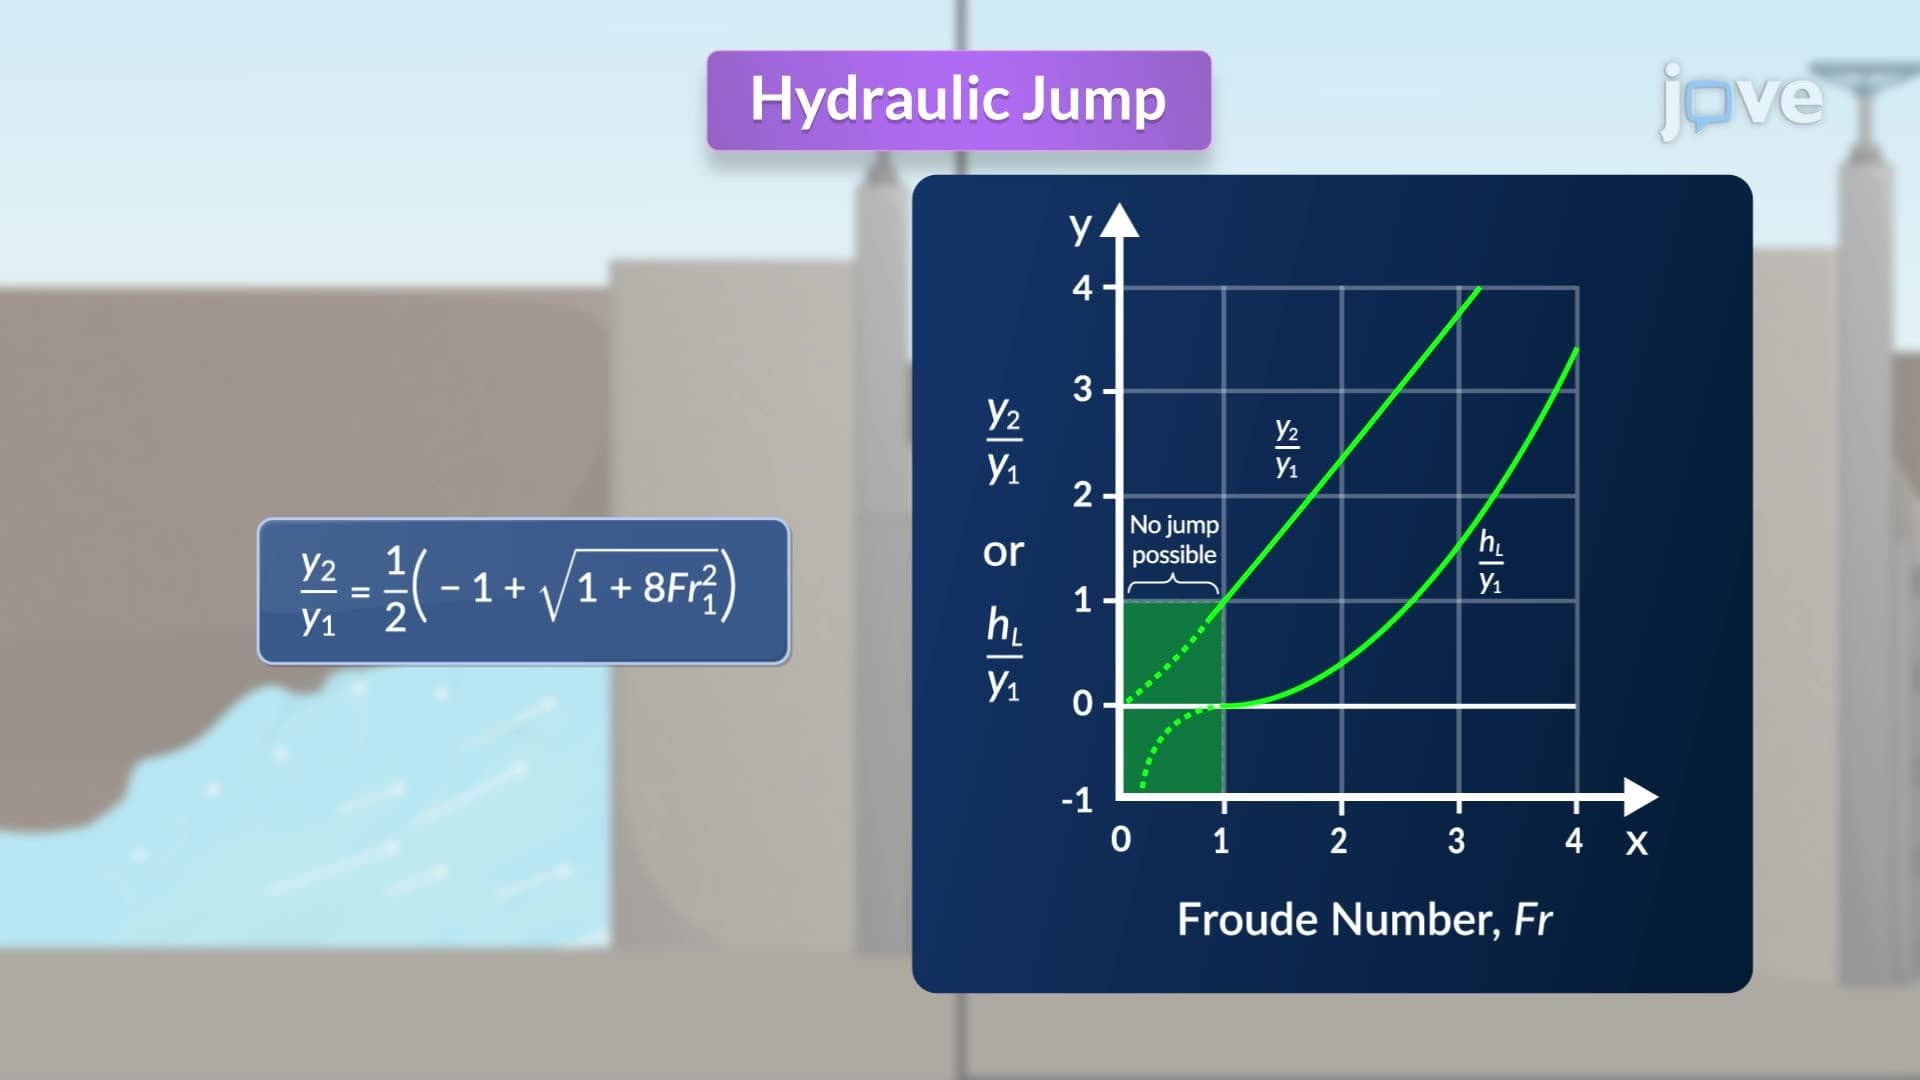
A hydraulic jump is a sudden rise in fluid depth in open channels, occurring when high-velocity (supercritical) flow transitions to low-velocity (subcritical) flow. This phenomenon requires an upstream Froude number greater than 1, as flows with Fr1<1 remain subcritical, making a hydraulic jump impossible due to the need for negative head loss, which violates thermodynamic principles.The characteristics of a hydraulic jump depend on the upstream Froude number and are classified as...
665
 01:27
Energy Line and Hydraulic Gradient Line
2.2K
Based on Bernoulli's equation, the energy line (EL) and hydraulic grade line (HGL) provide graphical representations of energy distribution in a fluid flow system. For steady, incompressible, inviscid flows, Bernoulli's equation is expressed as:
2.2K
 01:23
Pivot Bearings
2.2K
In mechanical systems, bearings are crucial in facilitating relative motion between two components while minimizing friction and wear. They help distribute various loads (radial, axial or a combination of both loads) across machinery parts, ensuring smooth and efficient operation.
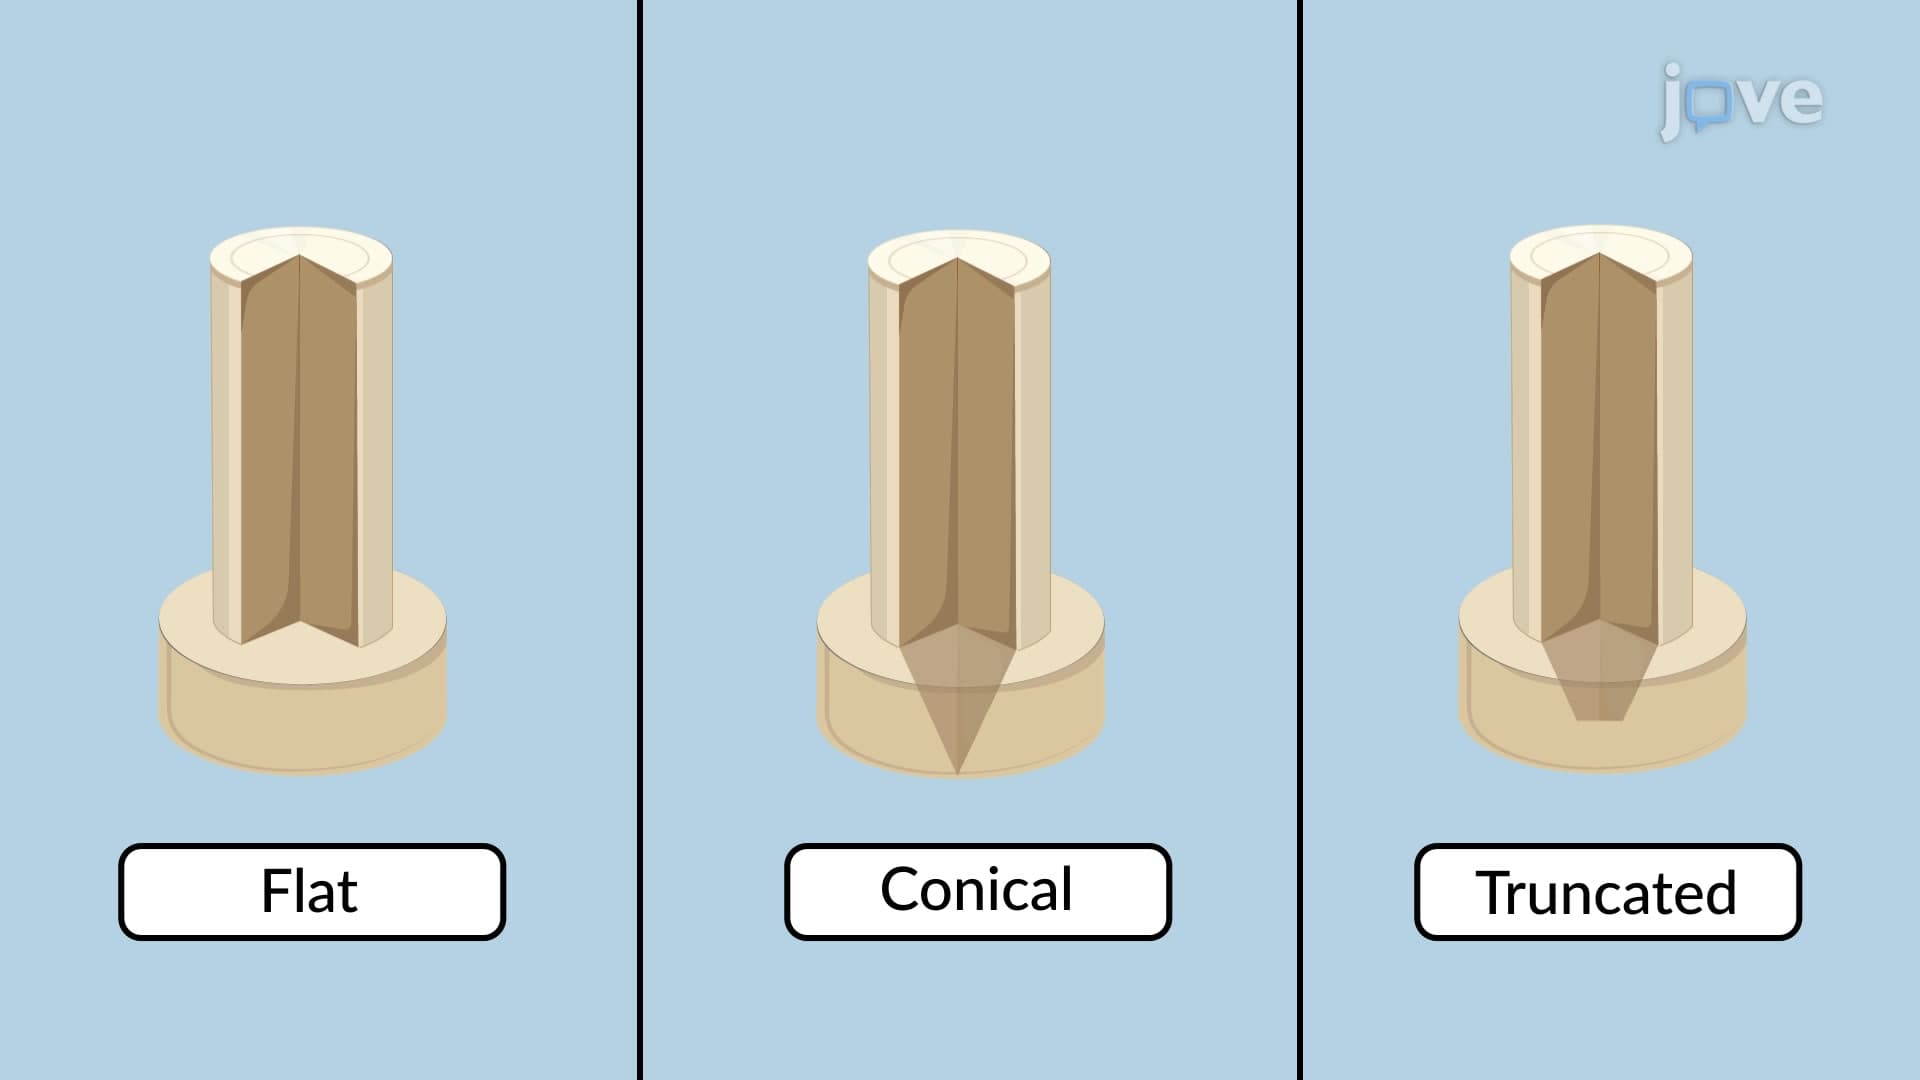
A pivot bearing is a specialized type of bearing designed to support axial loads on a rotating shaft. The bearing surface, or the pivot, is positioned at the end of a shaft to support the axial thrust. The pivot may...
A pivot bearing is a specialized type of bearing designed to support axial loads on a rotating shaft. The bearing surface, or the pivot, is positioned at the end of a shaft to support the axial thrust. The pivot may...
2.2K
 01:23
Journal Bearings
1.1K
Journal bearings are mechanical components that support and provide lateral stability to rotating shafts and axles. They are crucial in reducing friction, wear, and vibration in machinery such as engines, turbines, and pumps. The principle behind journal bearings is forming a thin lubricant film between the bearing surface and the rotating shaft, which minimizes direct contact and reduces frictional forces.
To better understand the concept of journal bearings, consider a rope winch with dry or...
To better understand the concept of journal bearings, consider a rope winch with dry or...
1.1K