
对一类改进的两度自由度控制器的概括比例整体导数解释
Wenfei Yu1, Ping Lin1,2, Shang Jiang3
1School of Control Science and Engineering, Dalian University of Technology, Dalian 116024, China.
Sensors (Basel, Switzerland)
|January 28, 2026

概括
改进的线性主动干扰排斥控制器 (ADRC) 通过消除超越和增强干扰排斥,特别是在直流-直流转换器中,提供比传统的ADRC更好的性能.
科学领域:
- 控制工程 控制工程 控制工程
- 系统科学 系统科学
- 电气工程 电气工程
背景情况:
- 传统的活性干扰排斥控制器 (ADRC) 使用估计状态,可能导致相位滞后.
- 改进的线性ADRC利用工厂输出进行反,旨在减轻相位滞后问题.
- 关于传统和改进的线性ADRC之间的数学关系的研究有限.
研究的目的:
- 建立传统的线性ADRC和改进的线性ADRC之间的数学关系.
- 从一般化的PID控制角度分析它们在频域中的区别.
- 评估改进的ADRC对控制性能的改进.
主要方法:
- 传统和改进的线性ADRC之间的关系的数学推导.
- 对于这两种控制器类型的一般化PID控制解释.
- 在DC-DC转换器中进行时间域分析和干扰排斥测试的数值模拟.
主要成果:
- 改进的ADRC提供了一种全新的,三参数的方法来对一般化PID控制,参数比标准的一般化PID少.
- 时间域模拟显示,改进的ADRC在设置值跟踪过程中消除了超标.
- 对于改进的ADRC,DC-DC转换器的干扰排斥表现出明显更好的性能,最大电压下降降幅度降低了7.44倍,电压上升幅度微不足道.
结论:
- 与传统的ADRC相比,改进的线性ADRC提供了增强的控制性能,更快的跟踪和优越的干扰排斥.
- 该研究通过通用PID控制提供了传统和改进的ADRC之间的明确数学联系.
- 改进的ADRC提供了一种更有效的方法,以更少的调参数实现通用PID控制.
相关概念视频
 01:24
One-Degree-of-Freedom System
846
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
846
 01:02
Degrees of Freedom
7.2K
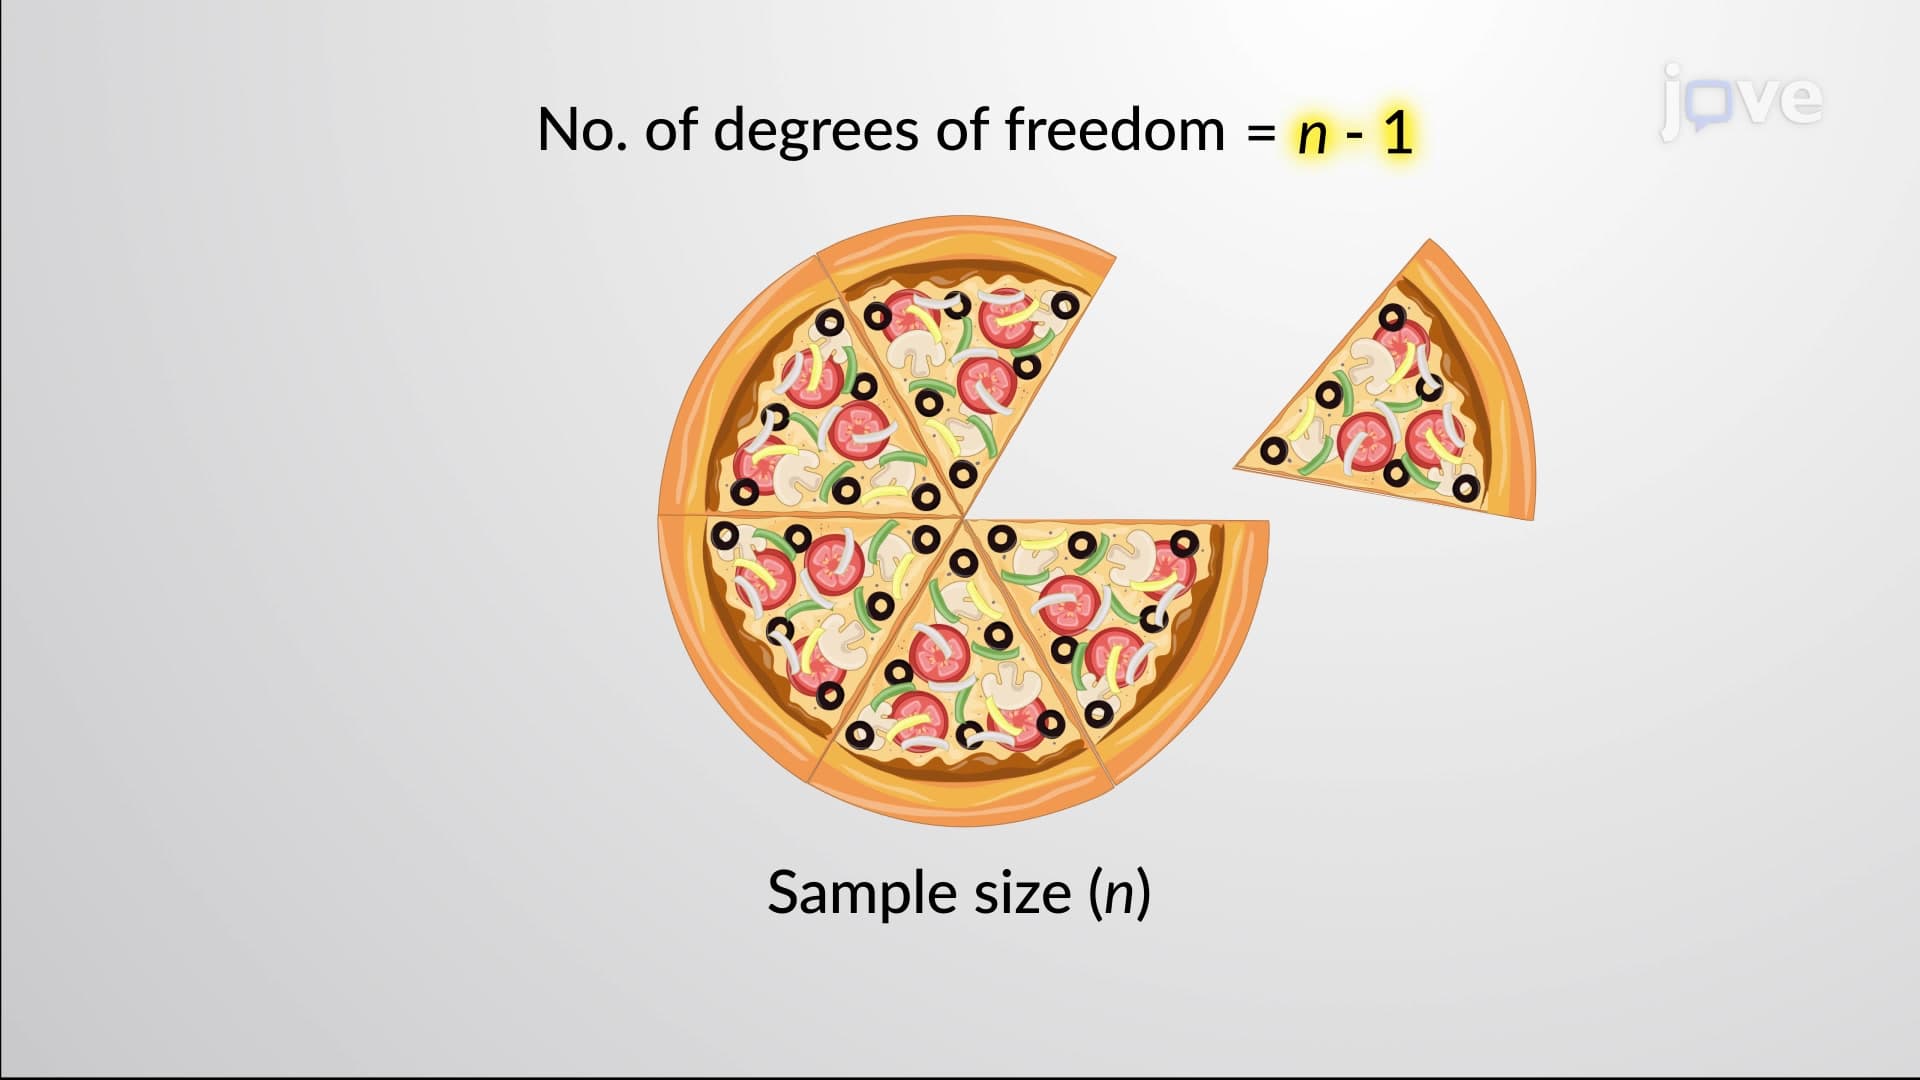
The degree of freedom for a particular statistical calculation is the number of values that are free to vary. Thus, the minimum number of independent numbers can specify a particular statistic. The degrees of freedom differ greatly depending on known and uncalculated statistical components.
For example, suppose there are three unknown numbers whose mean is 10; although we can freely assign values to the first and second numbers, the value of the last number can not be arbitrarily assigned.
For example, suppose there are three unknown numbers whose mean is 10; although we can freely assign values to the first and second numbers, the value of the last number can not be arbitrarily assigned.
7.2K
 01:02
Degrees of Freedom
10.3K
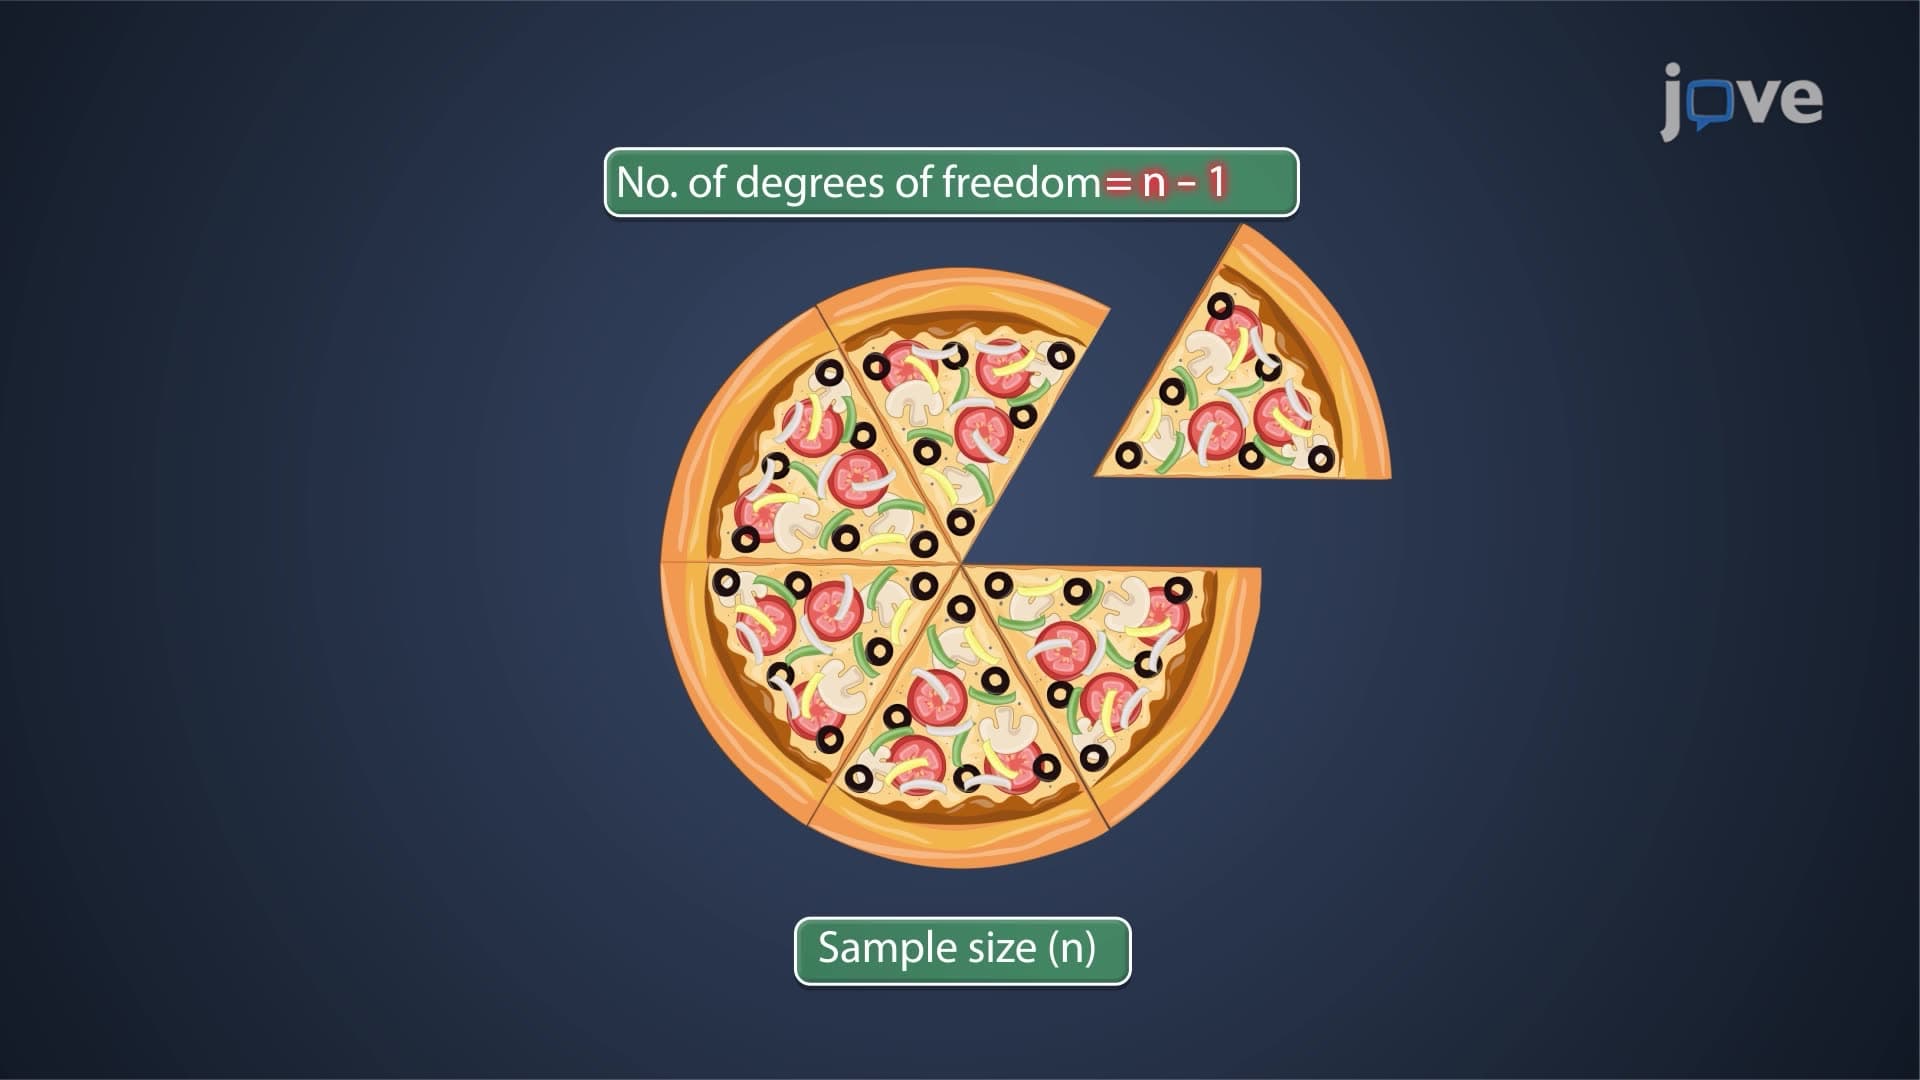
The degree of freedom for a particular statistical calculation is the number of values that are free to vary. As a result, the minimum number of independent numbers can specify a particular statistic. The degrees of freedom differ greatly depending on known and uncalculated statistical components.
For example, suppose there are three unknown numbers whose mean is 10; although we can freely assign values to the first and second numbers, the value of the last number can not be arbitrarily...
For example, suppose there are three unknown numbers whose mean is 10; although we can freely assign values to the first and second numbers, the value of the last number can not be arbitrarily...
10.3K
 01:20
Sample Proportion and Population Proportion
6.8K
Collecting samples or responses from an entire population takes significant time and effort, so a researcher collects responses from only a sample of that population. Suppose a study needs to collect information about a specific mobile application. After sample collection, the researcher analyzes the data and discovers that most individuals in the sample use that specific mobile application. The sample proportion measures the number of individuals in a sample who either use or don't use the...
6.8K
 01:07
Time-Domain Interpretation of PD Control
396
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
396
 01:24
Frequency-Domain Interpretation of PD Control
364
Proportional-Derivative (PD) controllers are widely used in fan control systems to improve stability and performance. A fan control system can be effectively represented using a Bode plot to illustrate the impact of a PD controller through its transfer function. The Bode plot visually conveys how PD control modifies the fan's response across various frequencies, providing a frequency domain interpretation of the controller's behavior.
The proportional control gain, combined with the...
The proportional control gain, combined with the...
364