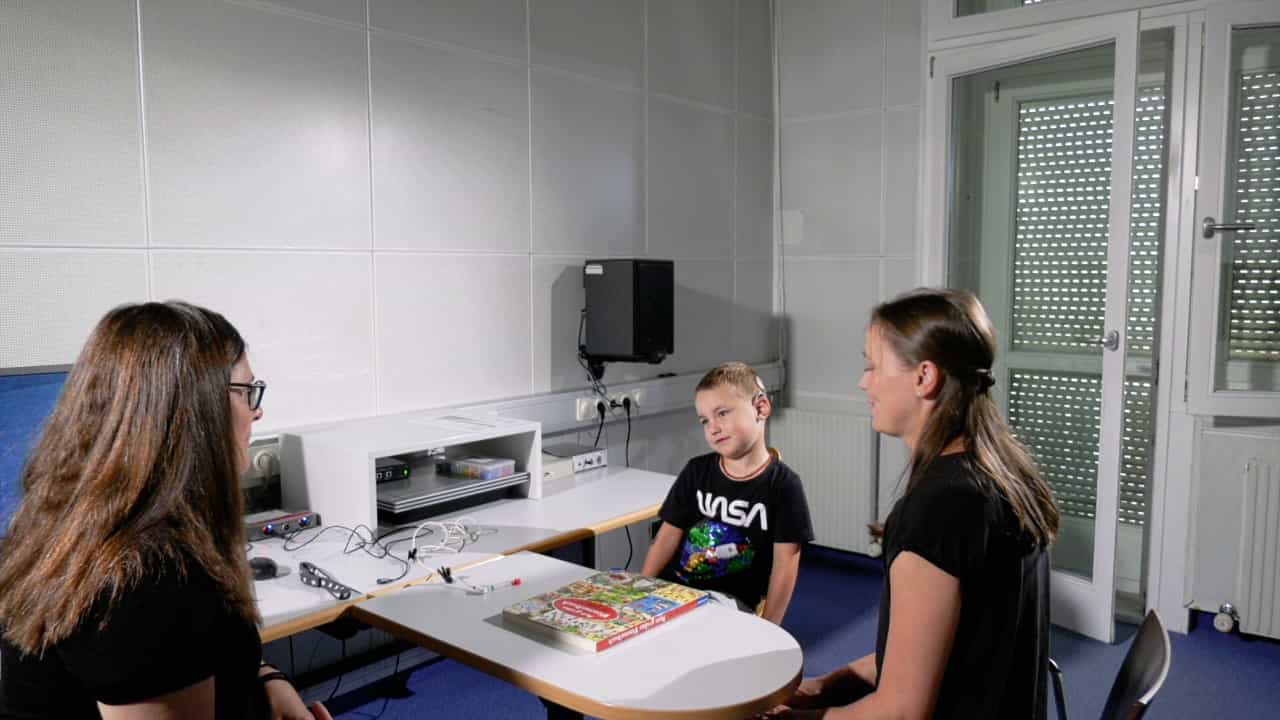

基于视觉的物体检测和跟踪从外科显微镜视频用于增强耳植入体手术
Shayan Alvansazyazdi1, Razeen Hussain1, Jan Margeta2
1DIBRIS, University of Genoa, Genoa, Italy.
Cochlear implants international
|January 29, 2026

概括
这项研究介绍了一种基于视觉的跟踪系统,使用YOLOv9和BoT-SORT用于耳植入器手术. 该系统准确地跟踪手术工具和患者解剖学,提高了手术精度和安全性.
科学领域:
- 医学技术 医学技术 医学技术
- 计算机视觉 计算机视觉 计算机视觉
- 手术机器人手术机器人手术机器人手术机器人
背景情况:
- 耳植入物 (CIs) 治疗严重的听力损失,但需要精确的电极放置,无需视觉指导.
- 在微妙的耳中进行手术导航,对外科医生来说构成了重大挑战.
研究的目的:
- 开发基于视觉的跟踪策略,在CI手术过程中实时监测患者和外科工具的移动.
- 通过提供视觉反来提高外科准确性和安全性.
主要方法:
- 使用YOLOv9和修改后的BoT-SORT算法开发了一个全面的对象检测和跟踪工作流.
- 在in-vivo和ex-vivo骨数据集上训练并验证了该系统.
- 评估了包括工具,电极,手和患者头部位置在内的各种手术元素的性能.
主要成果:
- 基于YOLOv9的框架表现出卓越的性能,实现了0.788的mAP50检测和0.762的细分.
- 综合系统保持了稳定的身份保护和轨迹一致性.
- 表现在ex vivo和in vivo环境之间有所不同,突出了翻译方面的挑战.
结论:
- 基于视觉的跟踪模型显示了改善外科设置的重大前景,特别是在CI手术中.
- YOLOv9和BoT-SORT系统为现实世界手术应用提供了强大的解决方案.
- 需要进一步的研究来优化不同外科环境的性能.
相关概念视频
 01:24
Vision
60.0K
Vision is the result of light being detected and transduced into neural signals by the retina of the eye. This information is then further analyzed and interpreted by the brain. First, light enters the front of the eye and is focused by the cornea and lens onto the retina—a thin sheet of neural tissue lining the back of the eye. Because of refraction through the convex lens of the eye, images are projected onto the retina upside-down and reversed.
60.0K
 01:24
Color Vision
1.5K
Color perception begins in the retina, the light-sensitive layer at the back of the eye. Two main theories explain how colors are seen: the trichromatic theory and the opponent-process theory. The trichromatic theory, proposed by Thomas Young in 1802 and extended by Hermann von Helmholtz in 1852, suggests that color vision is based on three types of cone receptors in the retina. These cones are sensitive to different but overlapping ranges of wavelengths corresponding to red, blue, and green.
1.5K
 01:18
Velocity of an Object
199
Understanding how an object moves along a path requires distinguishing between motion over a time span and motion at a precise moment. A useful example is a vehicle traveling along a straight and level path, where its position at any given time is known. The initial step in analyzing this motion is to measure how far the vehicle travels over a fixed time period. This measurement, called average velocity, is computed by dividing the total change in position by the duration over which the change...
199
 01:15
Depth Perception and Spatial Vision
2.0K
Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.
2.0K
 01:29
Potential Due to a Polarized Object
780
A neutral atom consists of a positively charged nucleus surrounded by a negatively charged electron cloud. When placed in an external electric field, the external electric force pulls the electrons and nucleus apart, opposite to the intrinsic attraction between the nucleus and the electrons. The opposing forces balance each other with a slight shift between the center of masses of the nucleus and the electron cloud, resulting in a polarized atom. On the other hand, a few molecules, like water,...
780
 01:24
Potential Due to a Magnetized Object
794
Magnetic dipoles in magnetic materials are aligned when placed under an external magnetic field. For paramagnets and ferromagnets, dipole alignment occurs in the direction of the magnetic field. However, the dipoles align opposite to the field in the case of diamagnets. This state of magnetic polarization due to the external field is called magnetization. Magnetization is defined as the dipole moment per unit volume. It plays a similar role to polarization in electrostatics.
The vector...
The vector...
794