
强大的基于计算机视觉的施工现场检测,用于辅助技术应用
Junchi Feng1,2, Giles Hamilton-Fletcher3,4, Nikhil Ballem4
1Department of Biomedical Engineering, Tandon School of Engineering, New York University, Brooklyn, NY, USA.
Disability and rehabilitation. Assistive technology
|February 1, 2026

概括
一个新的计算机视觉系统准确地检测城市建筑区的视力障碍者. 这项技术提供实时警报,增强通过危险的临时障碍物安全导航.
科学领域:
- 计算机视觉 计算机视觉
- 辅助技术 辅助技术 辅助技术
- 城市流动性 城市流动性
背景情况:
- 城市导航对视力障碍者来说是一个巨大的挑战,尤其是在建设区.
- 建筑工地引入了不可预测的危险,如不均的表面,障碍物和改变的路线,危及安全.
- 当前的导航工具和危险检测系统不足以应对建筑工地动态性质和视觉变化.
研究的目的:
- 开发和评估基于计算机视觉的辅助系统,用于检测施工区.
- 增强城市环境中盲人或视力低下者实时危险识别.
- 为了提高视力受损的行人在复杂的城市景观中驾驶的安全性和独立性.
主要方法:
- 开发了一种多模块计算机视觉系统:一个开放词汇的物体探测器,一个基于YOLO的专门的脚手架/柱子模型,以及一个光学字符识别 (OCR) 模块.
- 集成这些模块来识别不同的建筑元素和解释标志.
- 通过使用第一人称视频数据,在七个建筑工地进行静态测试,并在0.5英里的城市路线上进行动态测试.
主要成果:
- 静态测试实现了88.56%的整体准确性,在2-4米处实现了完美的检测 (100%),在10米内实现了一致的识别.
- 动态测试显示,区分建筑区的准确率为87.26%,使用多数票过器提高到92.0%.
- 该系统可靠地在提供足够预警时间 (2-10m) 的距离上检测到建筑元素.
结论:
- 开发的系统可靠地实时检测建筑工地,提供关键的预警.
- 这项技术使有视力障碍的人能够做出明智的移动决策,提高安全性.
- 该系统在施工区处理视觉变化的能力标志着辅助导航的重大进步.
相关概念视频
 01:24
Vision
60.0K
Vision is the result of light being detected and transduced into neural signals by the retina of the eye. This information is then further analyzed and interpreted by the brain. First, light enters the front of the eye and is focused by the cornea and lens onto the retina—a thin sheet of neural tissue lining the back of the eye. Because of refraction through the convex lens of the eye, images are projected onto the retina upside-down and reversed.
60.0K
 01:24
Color Vision
1.5K
Color perception begins in the retina, the light-sensitive layer at the back of the eye. Two main theories explain how colors are seen: the trichromatic theory and the opponent-process theory. The trichromatic theory, proposed by Thomas Young in 1802 and extended by Hermann von Helmholtz in 1852, suggests that color vision is based on three types of cone receptors in the retina. These cones are sensitive to different but overlapping ranges of wavelengths corresponding to red, blue, and green.
1.5K
 01:15
Depth Perception and Spatial Vision
2.0K
Depth perception is the ability to perceive objects three-dimensionally. It relies on two types of cues: binocular and monocular. Binocular cues depend on the combination of images from both eyes and how the eyes work together. Since the eyes are in slightly different positions, each eye captures a slightly different image. This disparity between images, known as binocular disparity, helps the brain interpret depth. When the brain compares these images, it determines the distance to an object.
2.0K
 01:31
Hybridoma Technology
17.7K
Hybridoma technology is used for the large-scale production of monoclonal antibodies. Monoclonal antibodies bind to only a single antigenic determinant or epitope. Such antibodies are used in research, diagnostics, and disease therapy. The hybridoma technology established in 1975 by Georges Köhler and Cesar Milstein was awarded the Nobel Prize in Medicine in 1984 for revolutionizing research and therapy.
Hybridoma Selection
Commonly used fusion techniques — electroporation,...
Hybridoma Selection
Commonly used fusion techniques — electroporation,...
17.7K
 01:30
Health Information Technology and Healthcare Information System
3.4K
Health Information Technology (HIT)
Health Information Technology, commonly called HIT, integrates advanced information systems and technology in healthcare settings. Its primary functions include:
Health Information Technology, commonly called HIT, integrates advanced information systems and technology in healthcare settings. Its primary functions include:
3.4K
 01:15
Construction of Root Locus
418
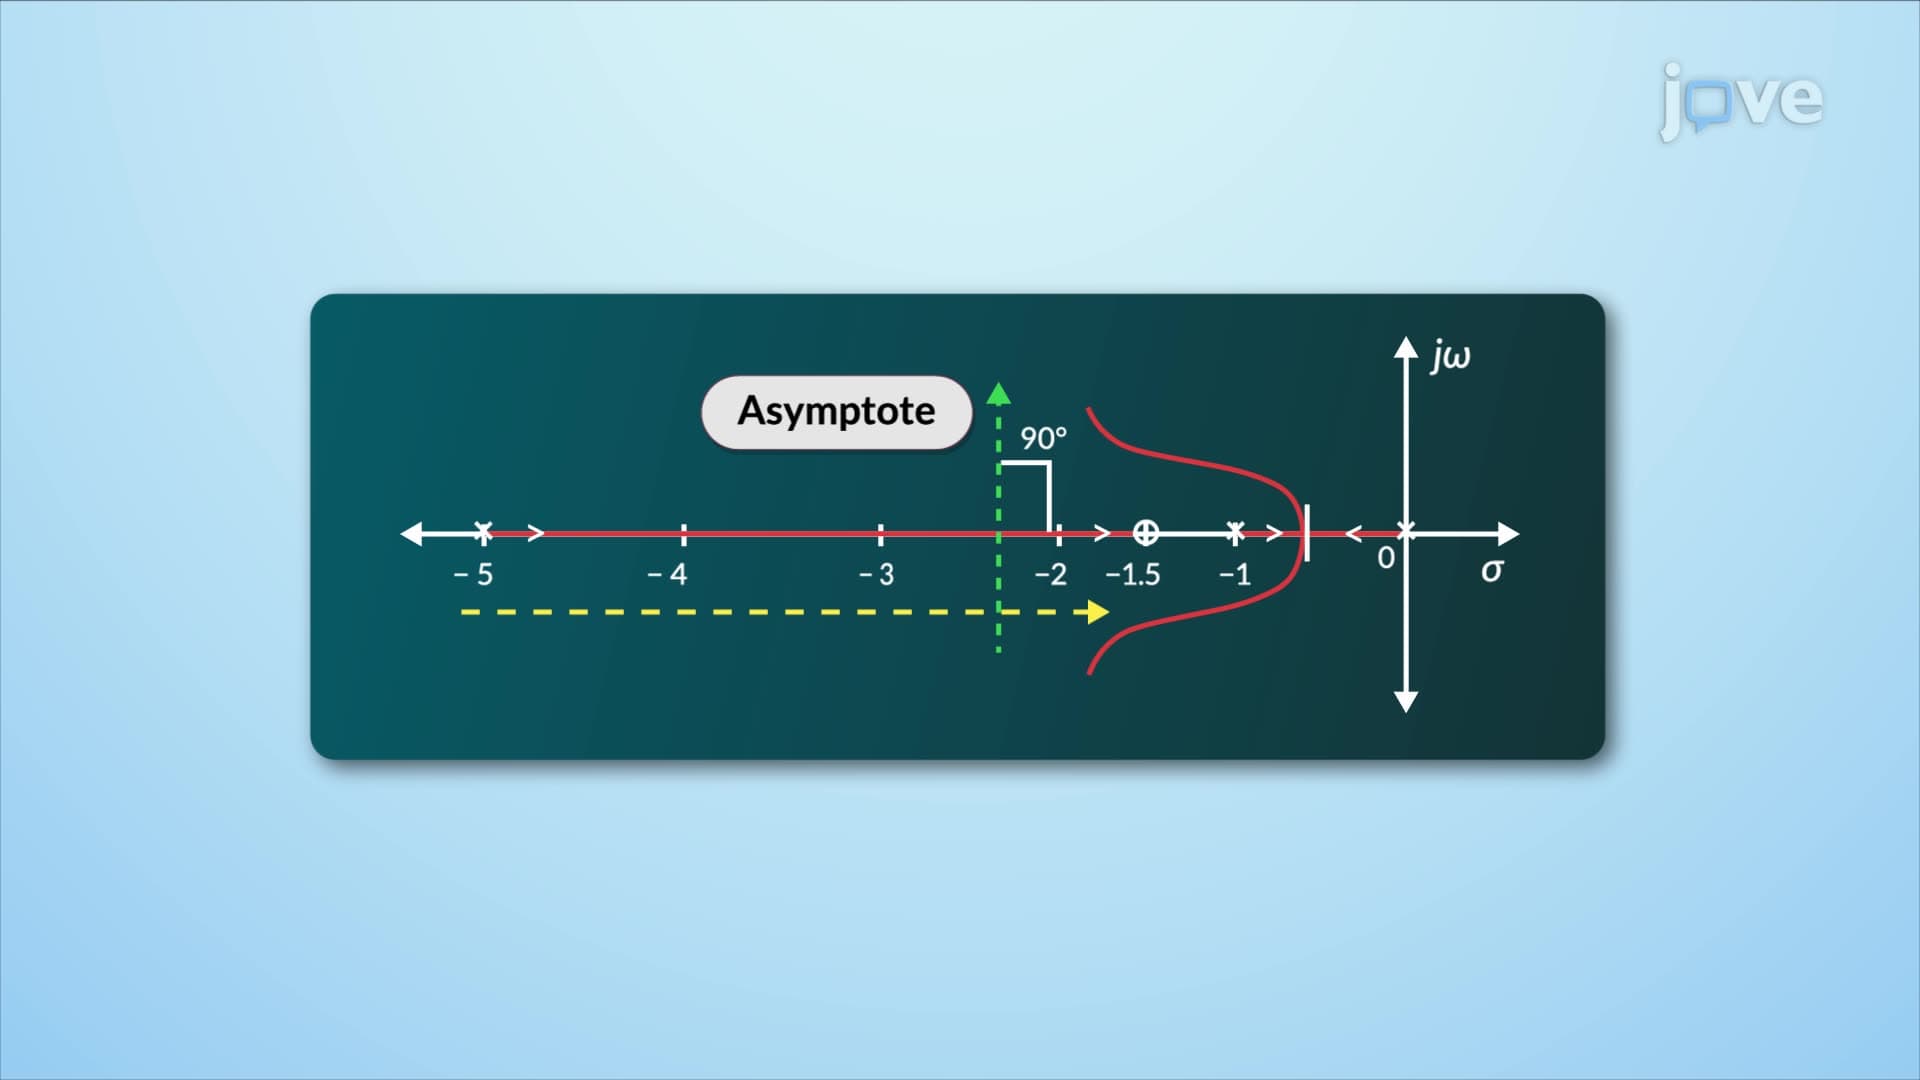
The construction of a root locus involves several key steps to analyze and visualize the behavior of a system's poles with varying gain. The number of branches in the root locus equals the number of closed-loop poles and is symmetrical about the real axis.
For positive gain values, the root locus exists on the real axis to the left of an odd number of finite open-loop poles or zeros. The root locus starts at the open-loop poles and traces the paths of the closed-loop poles as the gain...
For positive gain values, the root locus exists on the real axis to the left of an odd number of finite open-loop poles or zeros. The root locus starts at the open-loop poles and traces the paths of the closed-loop poles as the gain...
418