
一个基于高斯过程动态模型的减少顺序模型,用于依赖时间的参数化部分微分方程
Tiantian Wang1, Zhen Gao1,2, Longjiang Mu3
1School of Mathematical Sciences, Ocean University of China, Qingdao 266100, China.
Chaos (Woodbury, N.Y.)
|February 3, 2026

概括
一个新的减少顺序建模框架集成了张量列车分解 (TTD),高斯过程回归 (GPR) 和高斯过程动态模型 (GPDM) 复杂的参数化部分微分方程.
科学领域:
- 计算流体动力学 计算流体动力学
- 数字分析 数字分析
- 机器学习是机器学习.
背景情况:
- 参数化的部分微分方程 (PDEs) 提出了重要的高维挑战.
- 减少顺序建模 (ROM) 对于高效的复杂系统模拟至关重要.
- 现有的ROM与非线性时间动态和不确定性量化作斗争.
研究的目的:
- 为高维度参数化PDEs开发一种新的减少顺序建模框架.
- 整合张力列车分解 (TTD),高斯过程回归 (GPR) 和高斯过程动态模型 (GPDM).
- 为了使精确的时间演变预测和不确定性量化复杂的动态.
主要方法:
- 张力列车分解 (TTD) 用于低级近似的溶液快照.
- 用高斯过程回归 (GPR) 将参数空间映射到TTD格式.
- 高斯过程动态模型 (GPDMs) 用于时间动态建模和不确定性量化.
主要成果:
- 拟议的框架有效地处理高维参数化的PDEs.
- 与传统方法相比,在模拟非线性时间动态方面表现出卓越的准确性.
- 实现了精确的时间域插值和强大的不确定性量化.
结论:
- 综合的TTD-GPR-GPDM框架为复杂的参数化PDEs提供了一个强大的方法.
- 这种方法显著提高了动态系统的减少顺序建模能力.
- 该框架为科学计算中的预测和不确定性评估提供了可靠的工具.
相关概念视频
 01:25
Modeling with Differential Equations
84
Population dynamics can be described mathematically by considering the population size P(t) as a function of time. The rate of change of the population is then represented by the derivative of P(t). A simple assumption is that the rate of growth is proportional to the size of the population itself. This leads to an exponential growth model, where the population increases rapidly without bound. While this is a useful first approximation, it does not reflect realistic long-term...
84
 02:39
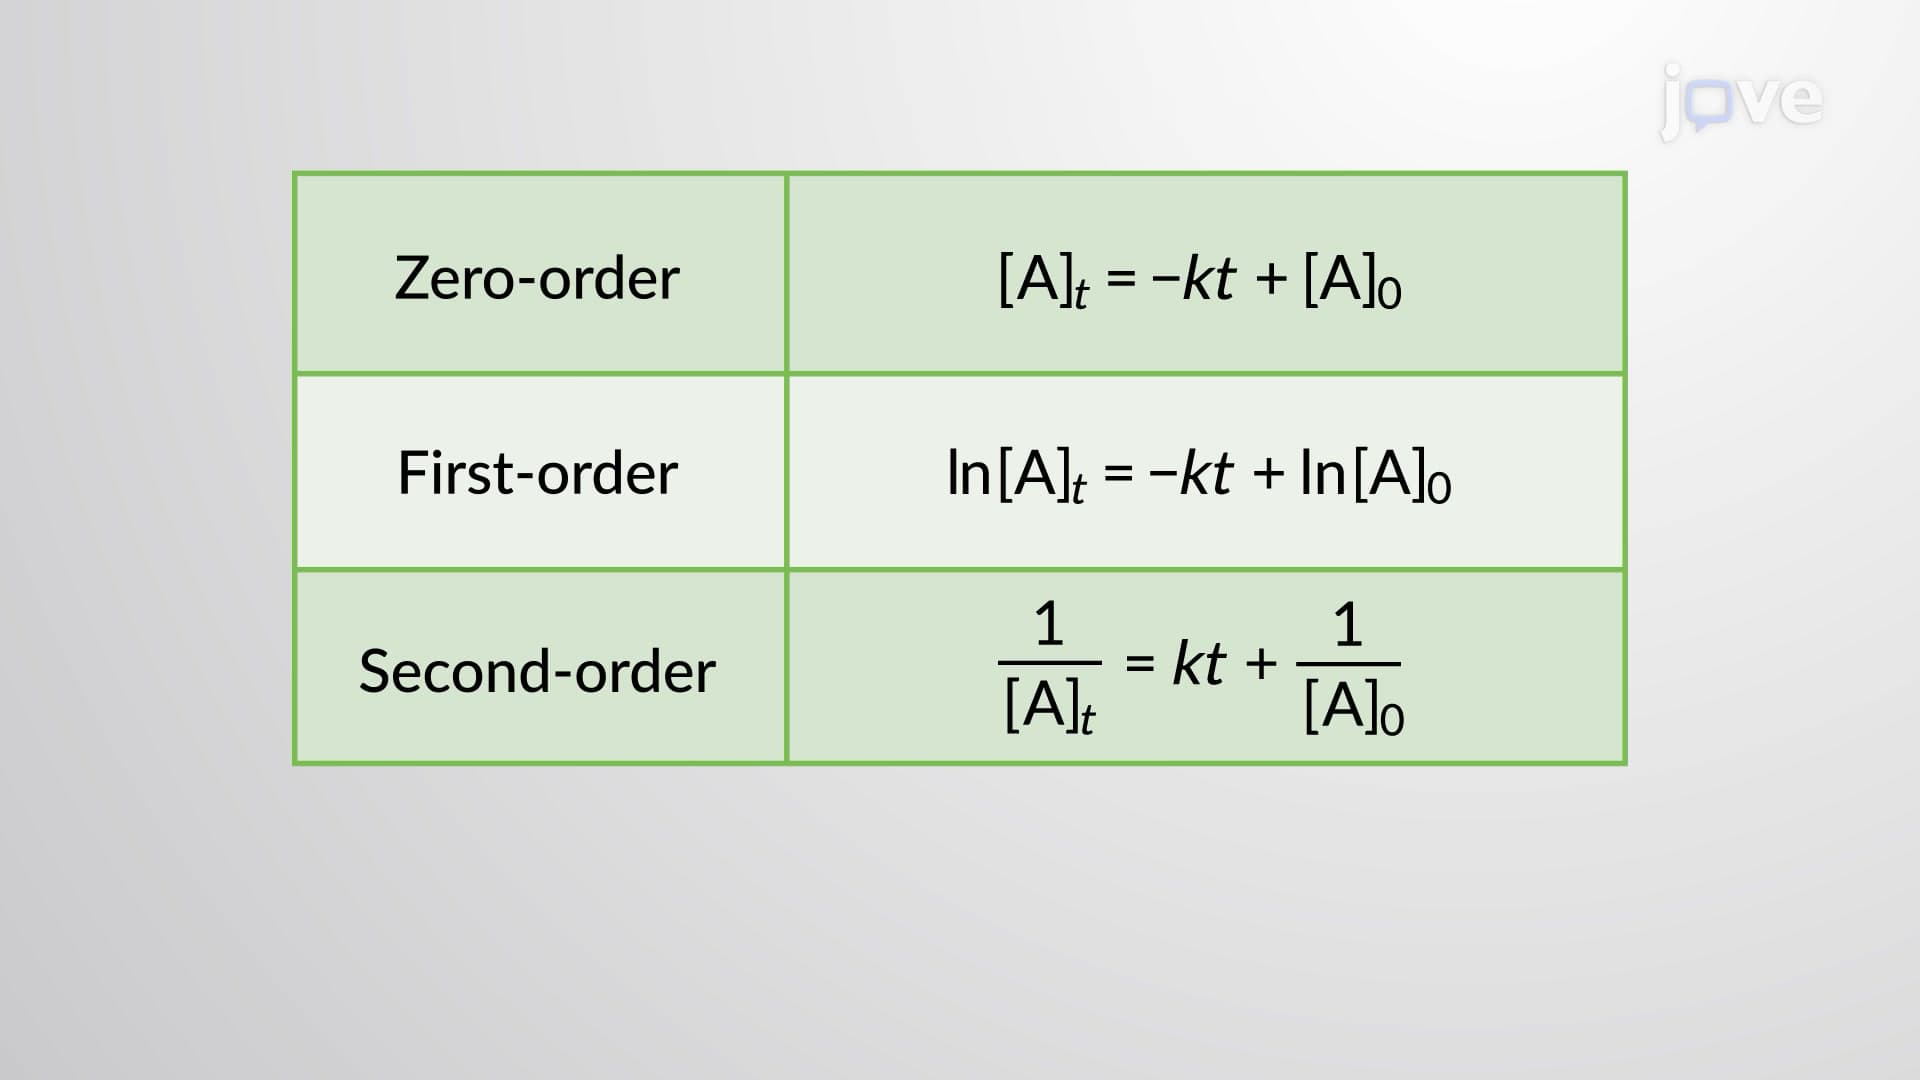
The Integrated Rate Law: The Dependence of Concentration on Time
42.3K
While the differential rate law relates the rate and concentrations of reactants, a second form of rate law called the integrated rate law relates concentrations of reactants and time. Integrated rate laws can be used to determine the amount of reactant or product present after a period of time or to estimate the time required for a reaction to proceed to a certain extent. For example, an integrated rate law helps determine the length of time a radioactive material must be stored for its...
42.3K
 01:08
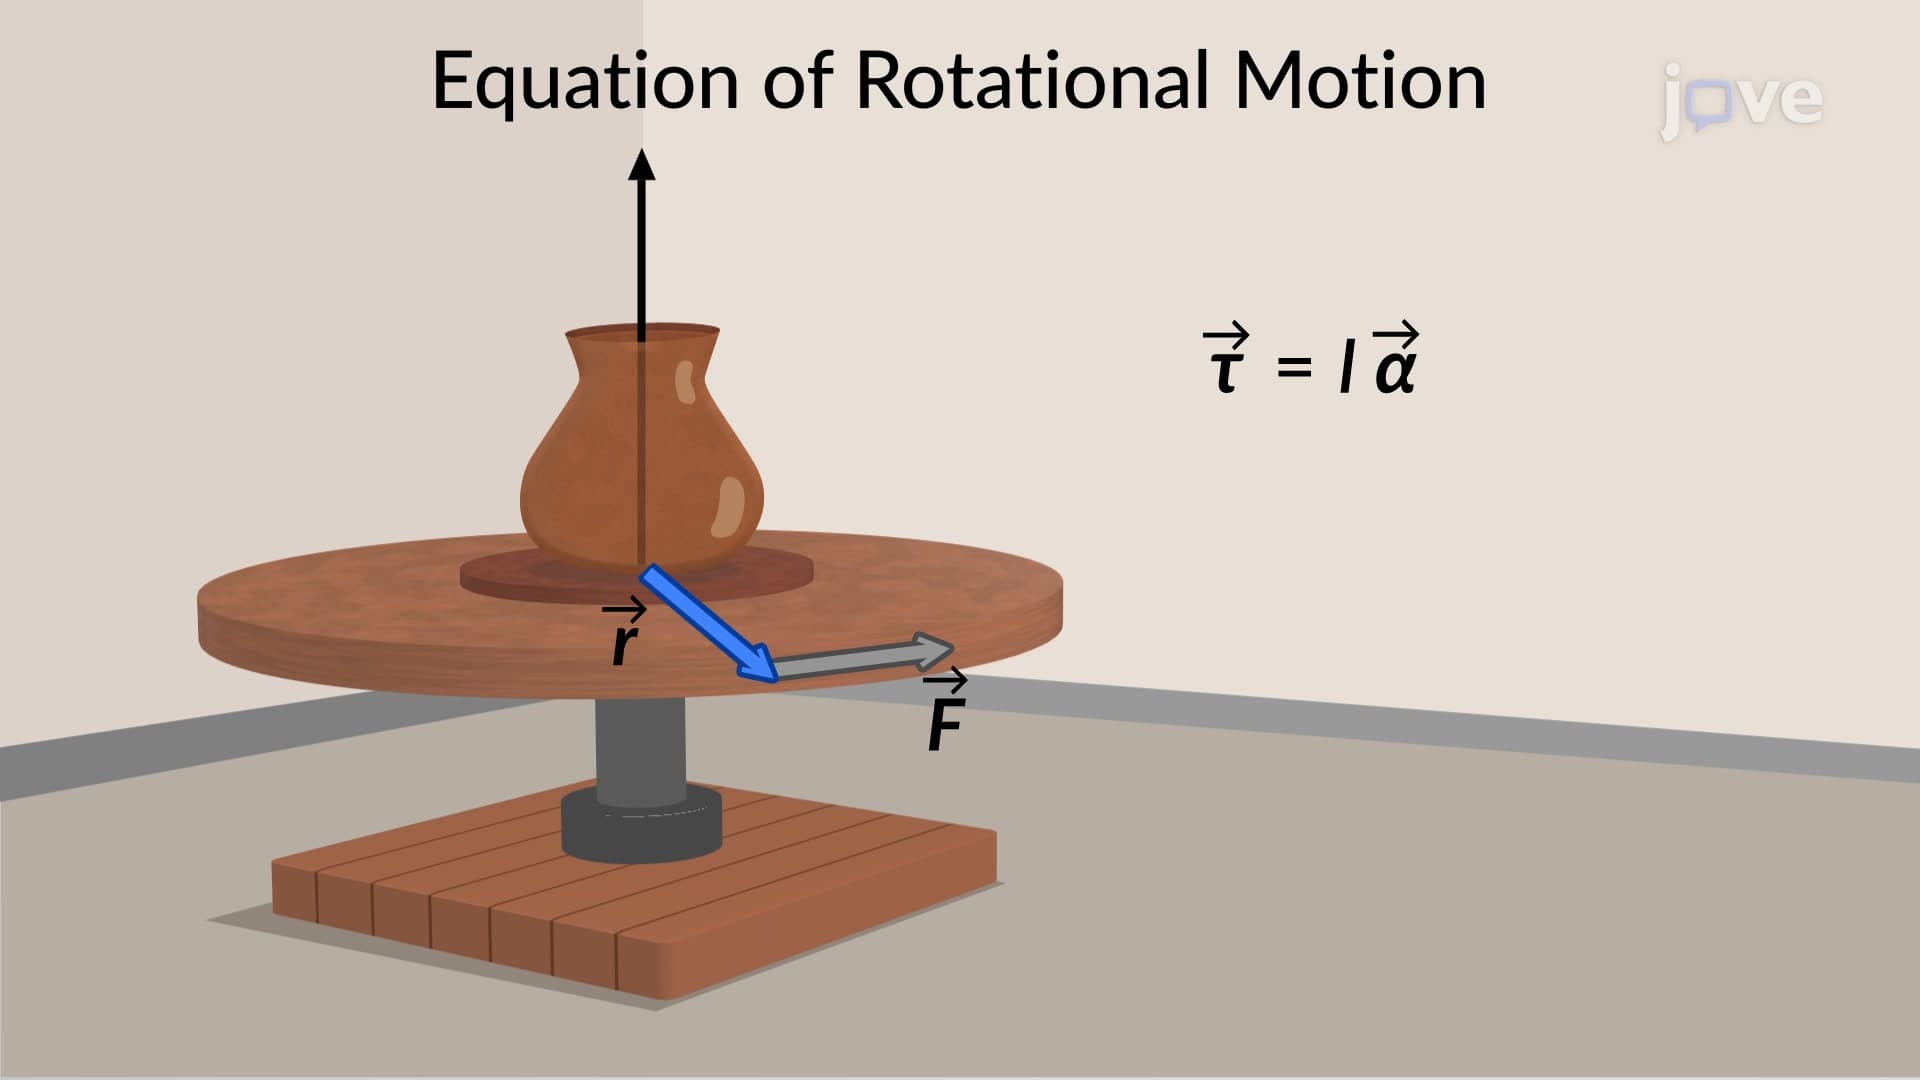
Equation of Rotational Dynamics
14.8K
Angular variables are introduced in rotational dynamics. Comparing the definitions of angular variables with the definitions of linear kinematic variables, it is seen that there is a mapping of the linear variables to the rotational ones. Linear displacement, velocity, and acceleration have their equivalents in rotational motion, which are angular displacement, angular velocity, and angular acceleration. Similar to the rotational variables, a mapping exists from Newton's second law of motion...
14.8K
 01:26
Transmission-Line Differential Equations
1.0K
Transmission lines are essential components of electrical power systems. They are characterized by the distributed nature of resistance (R), inductance (L), and capacitance (C) per unit length. To analyze these lines, differential equations are employed to model the variations in voltage and current along the line.
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured from...
Line Section Model
A circuit representing a line section of length Δx helps in understanding the transmission line parameters. The voltage V(x) and current i(x) are measured from...
1.0K
 01:20
Separable Differential Equations
93
A separable differential equation is a type of first-order differential equation where the derivative dy/dx can be expressed as a product of two functions: one that depends only on x and another that depends only on y. This allows for the rearrangement of the equation so that all terms involving y are on one side, and all terms involving x are on the other. This process, known as the separation of variables, simplifies the process of solving the equation by enabling the integration of both...
93
 01:20
Introduction to Differential Equations
134
A differential equation is a mathematical expression that establishes a relationship between a function and its derivatives. These equations are fundamental in modeling dynamic systems across various fields of science and engineering. The order of a differential equation is defined by the highest order derivative present in the equation. A first-order differential equation includes only the first derivative, while a second-order differential equation includes up to the second derivative of the...
134