
基于自适应差异卡尔曼过的GNSS/SINS/DVL集成导航算法
Zhao Zhan1, Changjian Liu1, Kaidi Jin2
1Information Engineering University, Zhengzhou, China.
PloS one
|February 5, 2026

概括
本研究引入了自适应差异卡尔曼过 (ADKF) 方法,以提高无人潜艇 (UUV) 的导航精度. 与标准卡尔曼过器相比,ADKF方法在复杂的海洋环境中提高了参数估计的稳定性和准确性.
科学领域:
- 海上导航技术 技术
- 机器人技术和自主系统
- 信号处理和控制理论
背景情况:
- 综合导航系统,结合全球导航卫星系统/Strapdown惯性导航系统/多普勒速度记录器 (GNSS/SINS/DVL),对海运公司至关重要.
- 无人驾驶水下车辆 (UUV) 在动态海上航行中面临重大挑战,原因是观测异常和动态模型不准确.
- 标准卡尔曼过器 (KF) 在复杂的海洋环境中难以保持准确性,影响UUV导航参数估计.
研究的目的:
- 为GNSS/SINS/DVL集成导航数据开发一种改进的过方法,专门用于UUVs.
- 为了解决标准卡尔曼过器在处理动态海上导航复杂性的局限性.
- 提高UUV在具有挑战性的海洋环境中导航参数估计的准确性和稳定性.
主要方法:
- 实现一个自适应差异卡尔曼过 (ADKF) 算法.
- 来自GNSS/SINS/DVL子系统的集成导航数据的处理.
- 使用实验数据对ADKF与标准卡尔曼波器 (KF) 的比较分析.
主要成果:
- 拟议的ADKF方法在导航参数估计中显著提高了准确性.
- 与标准KF相比,ADKF算法在参数估计中显示出更好的稳定性.
- 实验结果证实了ADKF在复杂的海洋环境中的有效性.
结论:
- 适应差异卡尔曼过 (ADKF) 方法是针对UUVs的综合导航数据后处理的强大解决方案.
- 在UUV导航的准确性和稳定性方面,ADKF提供了比标准KF更好的性能.
- 开发的方法非常适合在具有挑战性的海洋条件下提高UUV导航的可靠性.

相关概念视频
 01:13
Integrator and Differentiator
1.5K
Op-amp circuits have significant applications in various fields, including automotive engineering. One such application is cruise control systems in cars, where op-amp circuits are integral for maintaining a constant speed. In these systems, op-amps function as both integrators and differentiators.
An integrator within an op-amp circuit produces an output directly proportional to the integral of the input signal. This is achieved by replacing the feedback resistor in a typical inverting...
An integrator within an op-amp circuit produces an output directly proportional to the integral of the input signal. This is achieved by replacing the feedback resistor in a typical inverting...
1.5K
 01:27
Passive Filters
1.0K
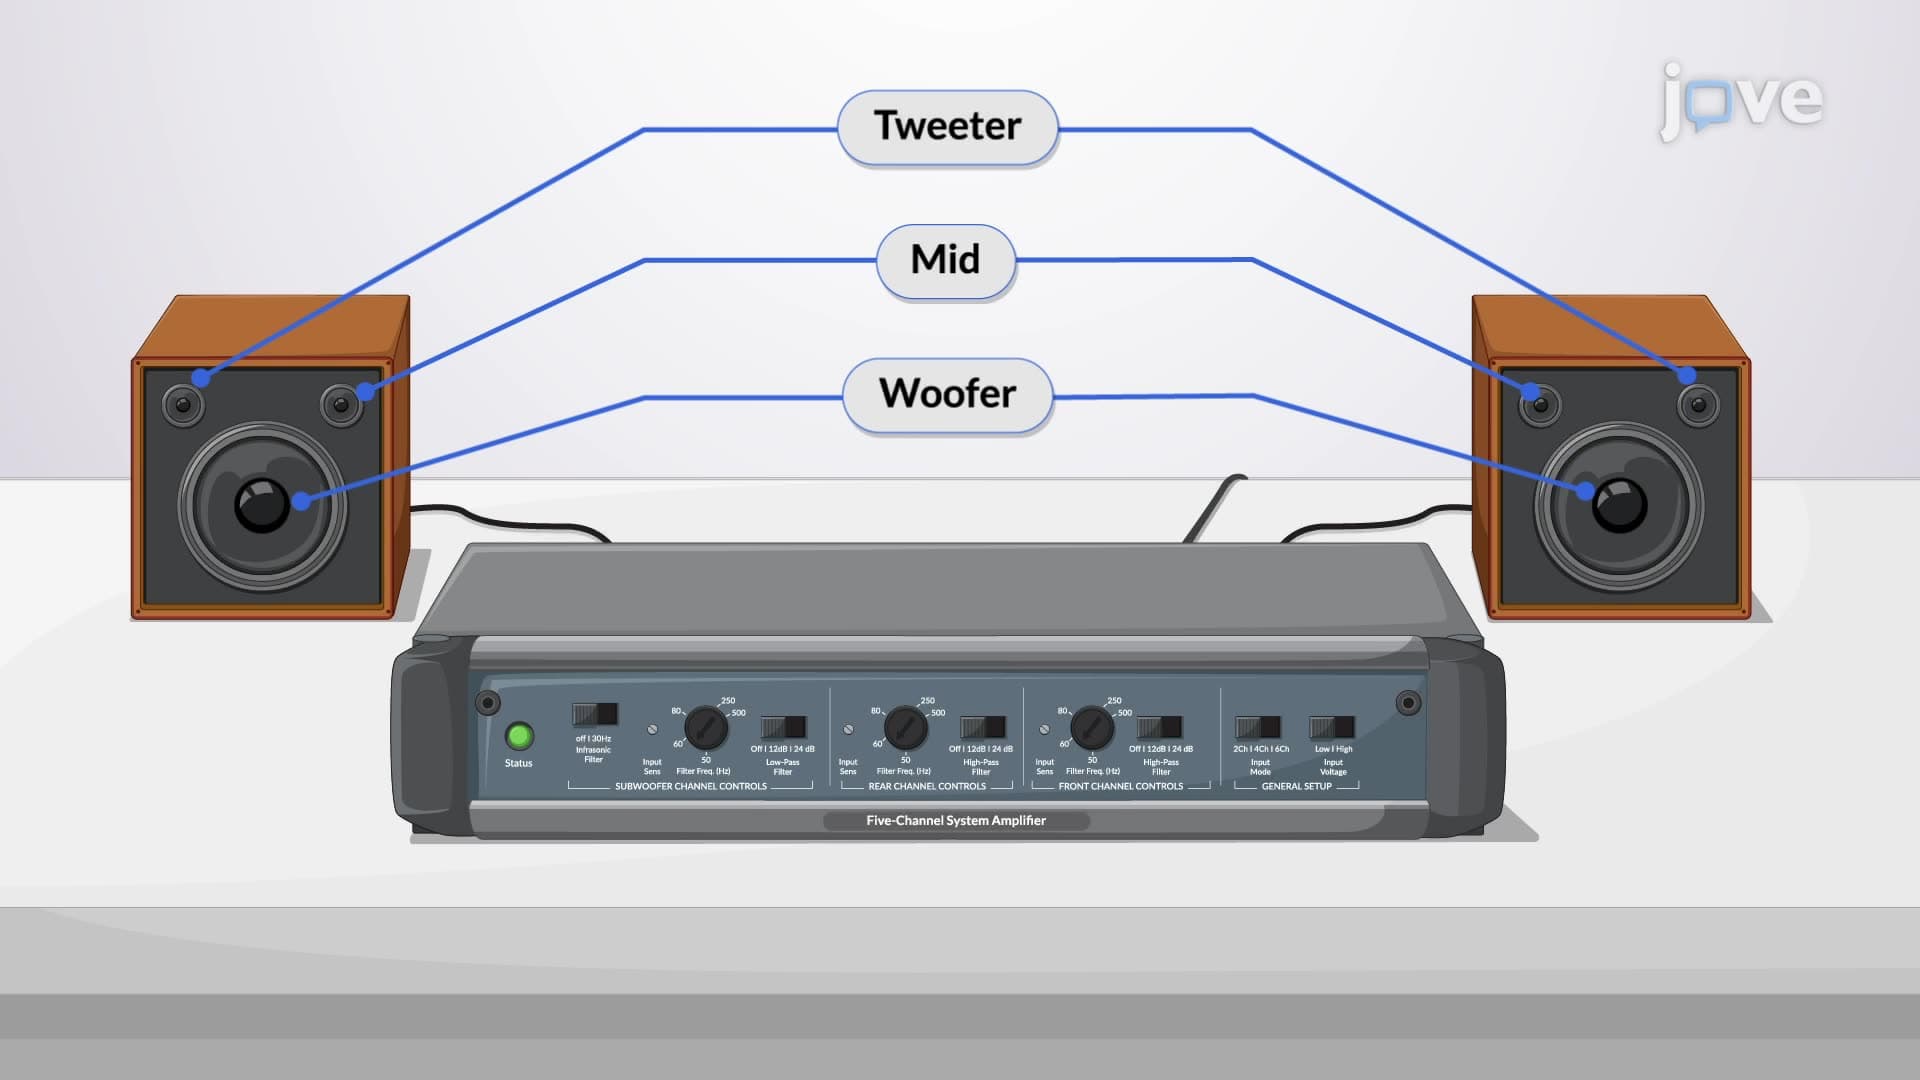
Passive filters are utilized to shape the frequency spectrum of signals across a diverse array of applications. These filters, using only passive elements like resistors (R), inductors (L), and capacitors (C), are capable of selectively allowing or blocking certain frequency ranges without the need for external power sources.
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
Low-Pass Filters
Low-pass filters are designed to transmit signals with frequencies lower than the cutoff frequency, ωc, and attenuate those above it. The cutoff...
1.0K
 01:25
Active Filters
1.3K
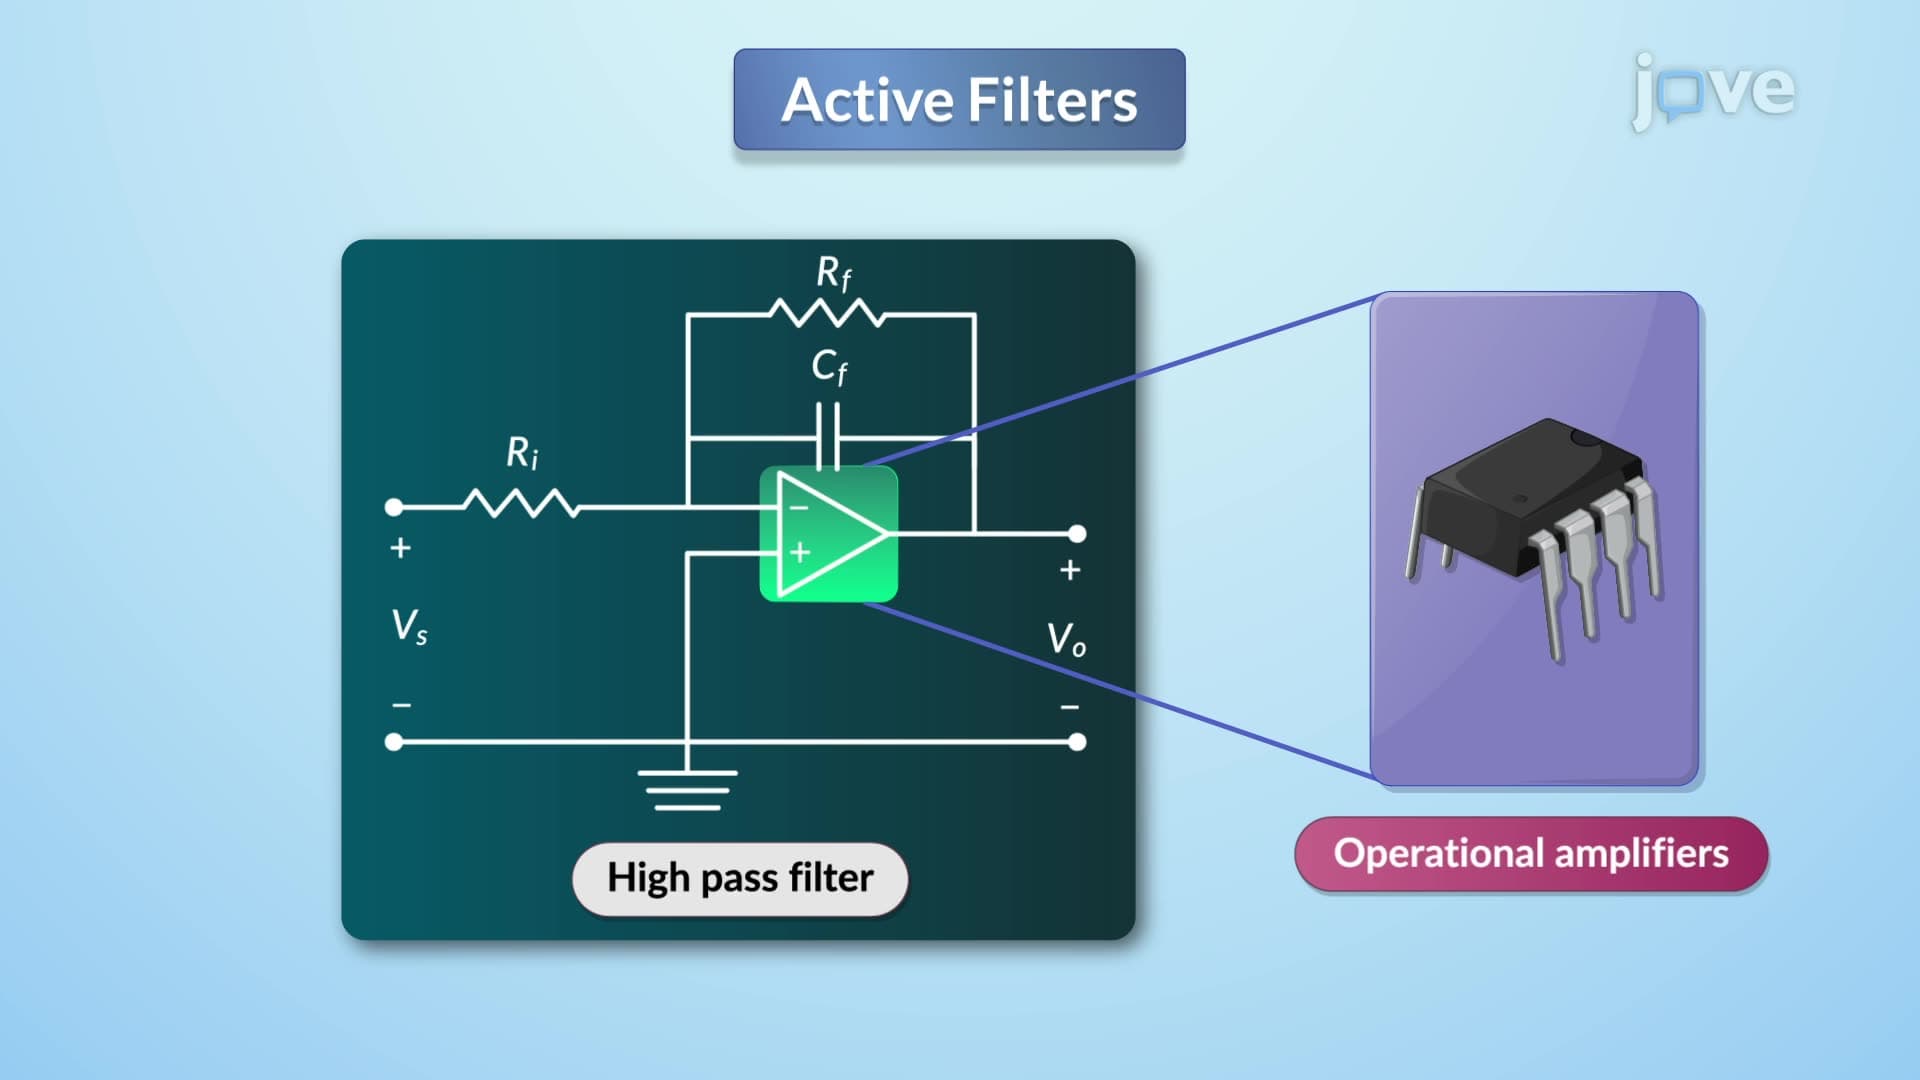
Active filters are electronic circuits that use operational amplifiers (op-amps), resistors, and capacitors to filter out unwanted frequency components from a signal. A first-order low-pass active filter is designed to pass signals with a frequency lower than a certain cutoff frequency and attenuate frequencies higher than that cutoff frequency. The transfer function for a first-order low-pass active filter is:
1.3K
 01:12
Trial and Error and Algorithm
424
A problem-solving strategy is a plan of action used to find a solution. Different strategies have distinct action plans. Trial and error involves trying different solutions until one works. For instance, to fix a broken printer, you might check ink levels, ensure the paper tray isn't jammed, and verify the printer's connection to your laptop. This method can be time-consuming but is commonly used. Thomas Edison, for example, used trial and error to find a suitable filament for the light...
424
 01:26
Integration by Parts: Indefinite Integrals
189
Integration by parts is a fundamental technique in calculus for evaluating integrals involving the product of two functions. It is particularly useful when direct integration is not feasible. The method is based on the product rule for differentiation, which states that the derivative of a product equals the derivative of the first function times the second, plus the first function times the derivative of the second. By integrating this identity and rearranging terms, the integration by parts...
189
 01:23
Integration by Parts: Definite Integrals
87
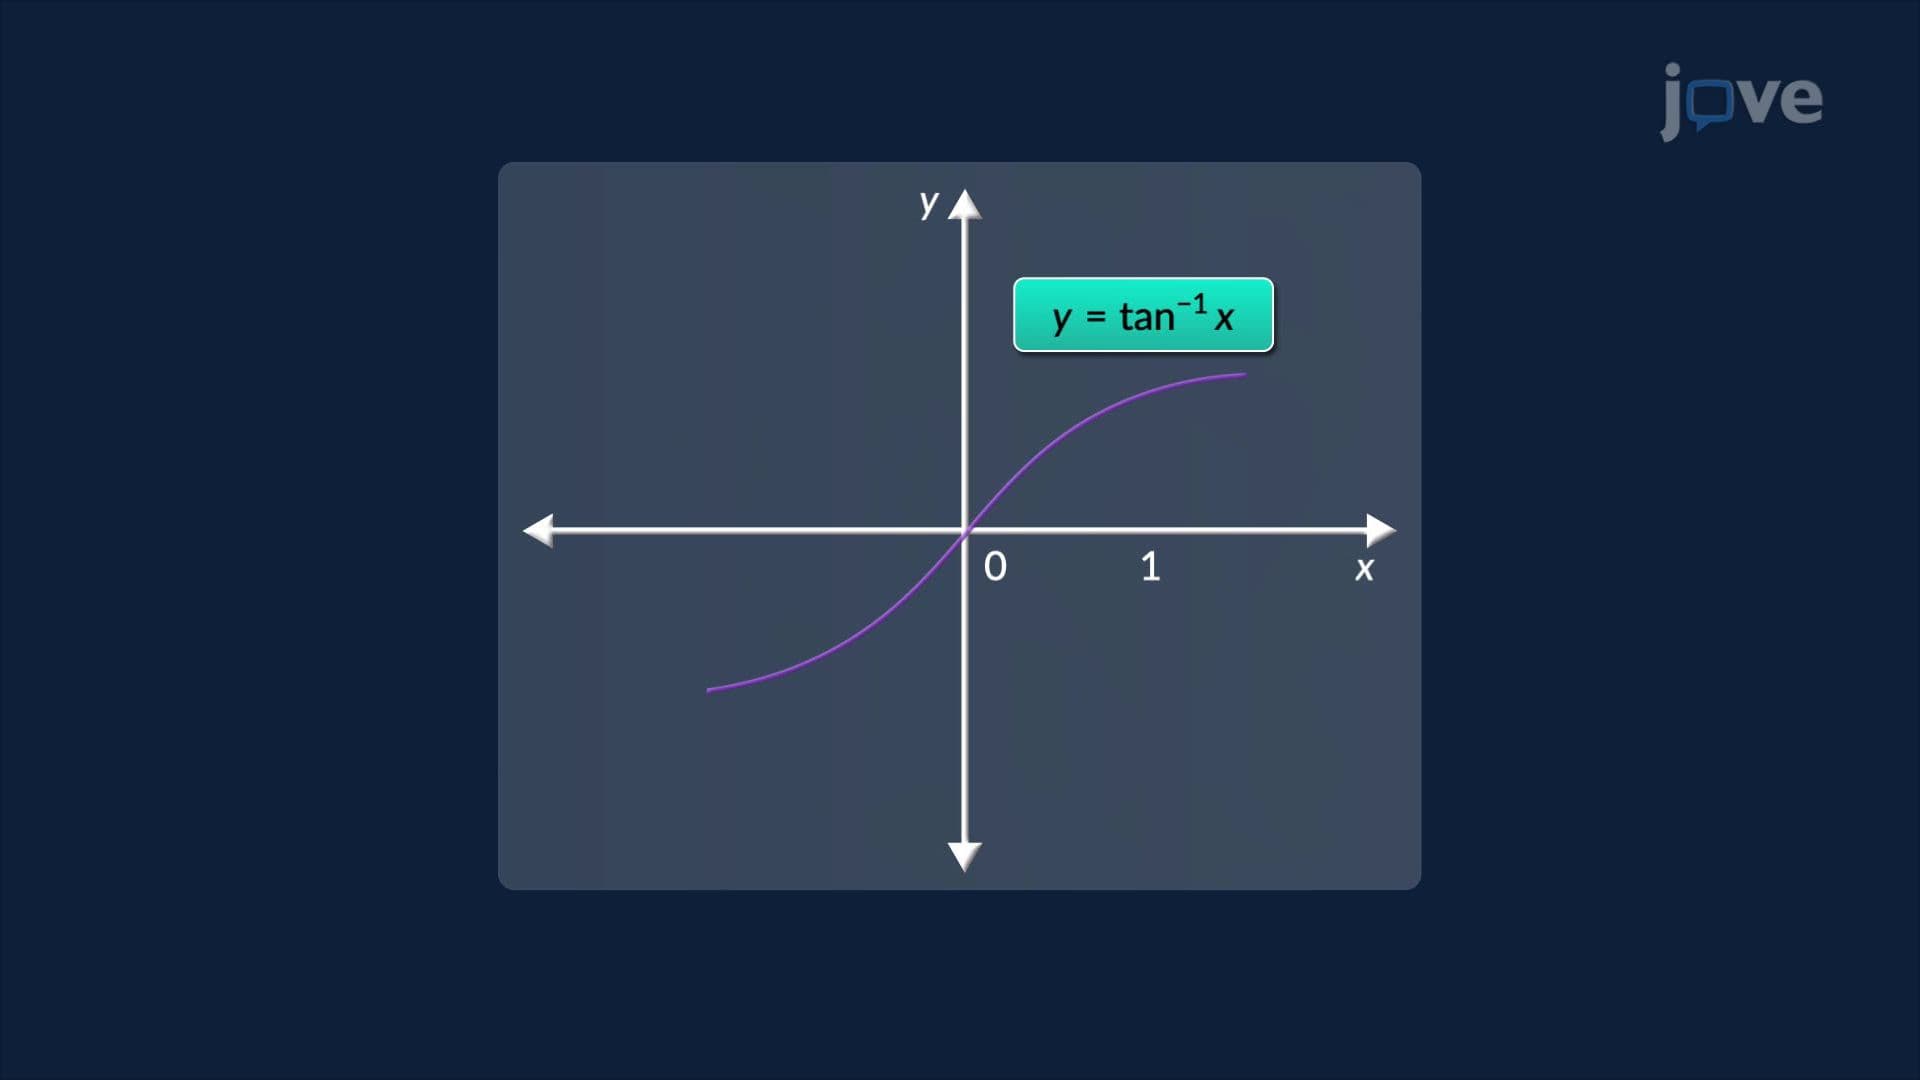
Definite integrals involving the product of two functions over a fixed interval can be evaluated using integration by parts. This method rewrites the integral as the difference of a product evaluated at the endpoints and a remaining definite integral that is often simpler to compute.A representative example is the definite integral of the inverse tangent function. Since there is no direct integration formula for arctan x, the integrand is rewritten as a product of arctan x and the...
87