
任意总角动量 矢量全息使用双层元表面
Joonkyo Jung1, Hyeonhee Kim1, Jonghwa Shin1
1Department of Materials Science and Engineering, KAIST, Daejeon, Republic of Korea.
Advanced materials (Deerfield Beach, Fla.)
|February 9, 2026

概括
研究人员开发了一种用于总角动量 (TAM) 矢量全息的双层超表面,使真极化-轨道角动量 (OAM) 复杂化用于先进的光学信息处理.
科学领域:
- 光子学和超表面技术
- 光学信息处理 光学信息处理
- 全息影像的使用方法.
背景情况:
- 先进的全息技术对于高容量,安全的信息处理至关重要.
- 轨道角动量 (OAM) 为光学复杂化提供了一套强大的,无限的模式.
- 超表面在光控制方面表现出色,使其成为OAM多重复合全息的关键,但在极化工程中缺乏奇拉性控制.
研究的目的:
- 引入一种全新的双层超表面架构,用于总角动量 (TAM) 矢量全息.
- 通过控制旋转角动量 (SAM) 和OAM,实现真极化-OAM复杂化.
- 为了证明对直角TAM状态的矢量全息图像的独立生成.
主要方法:
- 设计并模拟了一个双层的超表面结构.
- 通过结合SAM和OAM控制实现了TAM矢量全息.
- 通过数值模拟和实验验证验证了该概念.
主要成果:
- 使用双层元表面实现了真极化-OAM多重复合.
- 证明了用于不同TAM输入的矢量全息图像的独立生成.
- 在数值和实验上证实了TAM矢量全息的可行性.
结论:
- 拟议的双层超表面可以实现多功能TAM矢量全息.
- 这种方法克服了单层超表面在极化控制中的局限性.
- 该框架与其他全息技术集成,扩大了未来光子系统的多重复合能力.
相关概念视频
 01:11
Angular Momentum about an Arbitrary Axis
471
Imagine a rigid body with a mass denoted as 'm', which has its center of mass at point G and is rotating around an inertial reference frame. The angular momentum at an arbitrary point P can be calculated by taking the cross product of the position vector and linear momentum vector for each individual mass element.
The velocity of a mass element comprises its translational velocity and the relative velocity instigated by the body's rotation. Substituting the velocity equation into...
The velocity of a mass element comprises its translational velocity and the relative velocity instigated by the body's rotation. Substituting the velocity equation into...
471
 01:21
Angular Momentum
828
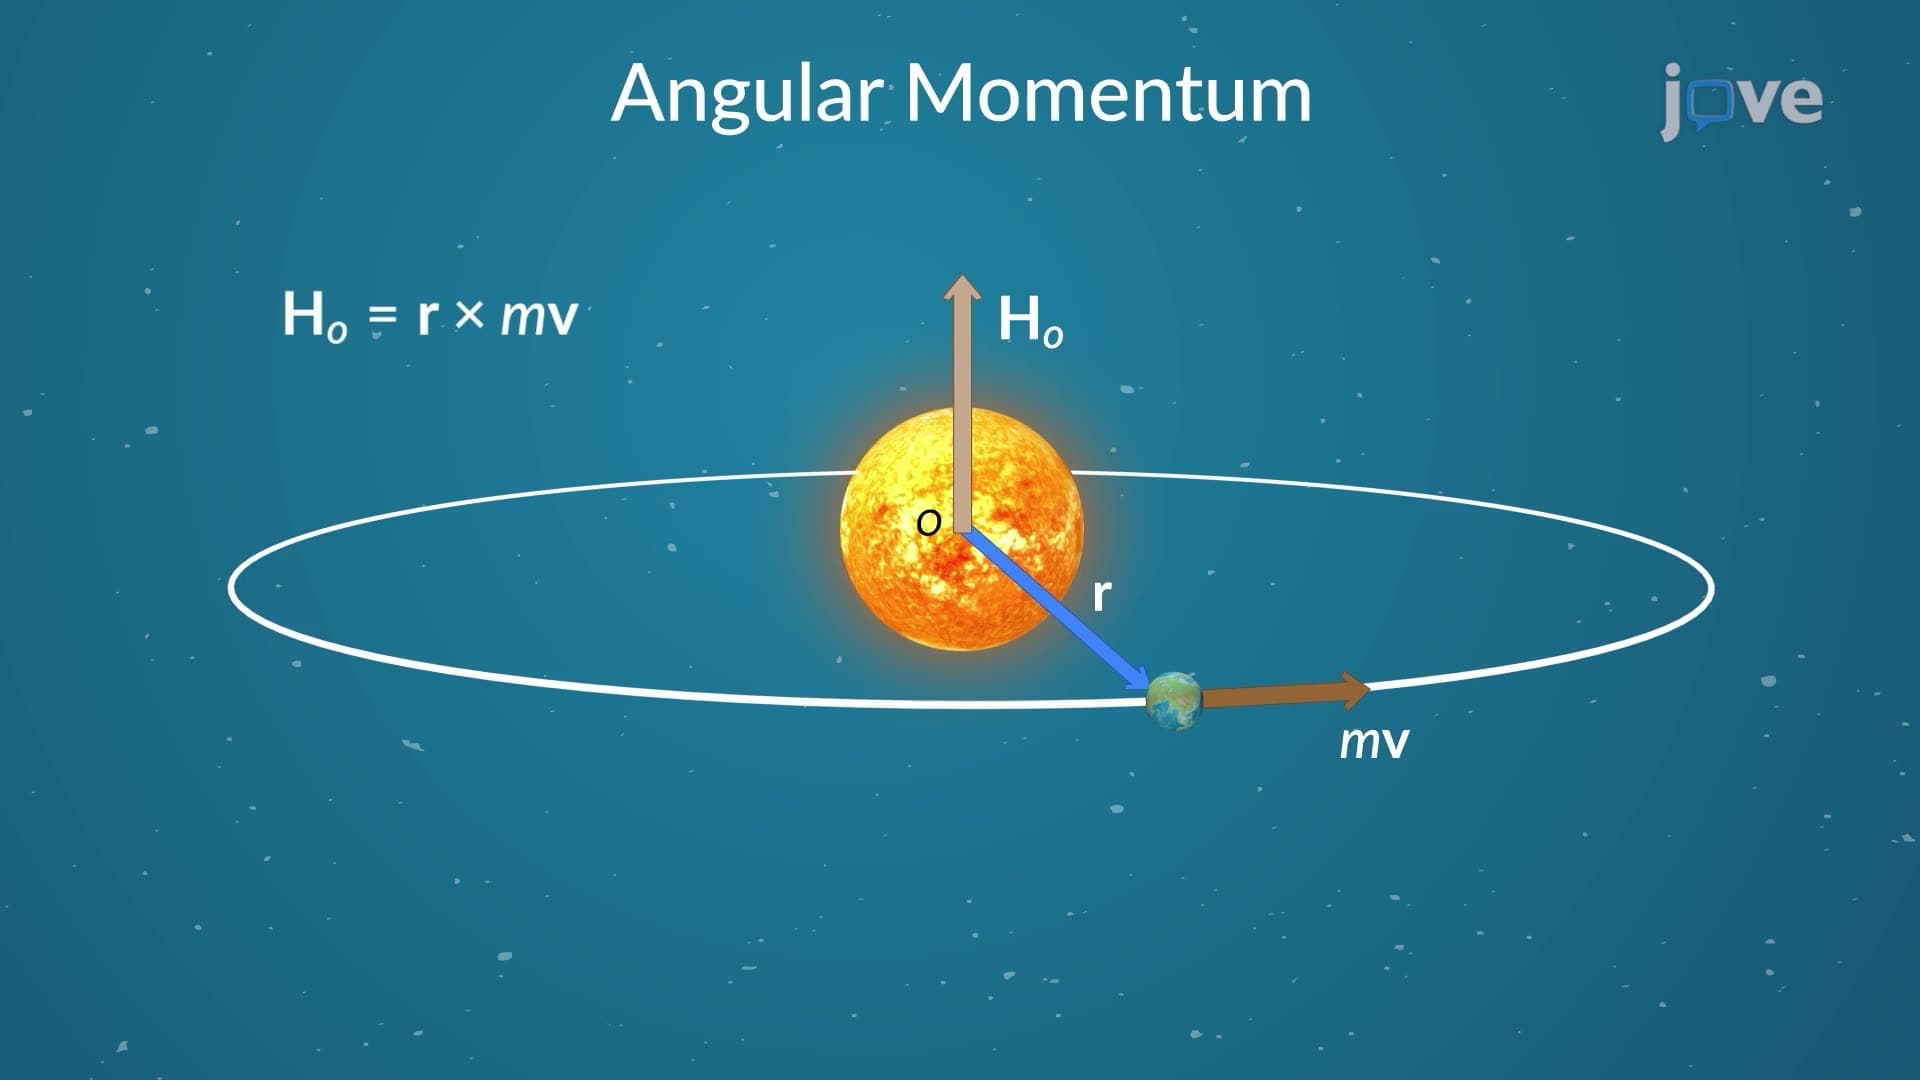
Angular momentum characterizes an object's rotational motion and is defined as the moment of its linear momentum about a specified point O. When a particle moves along a curved path in the x-y plane, the scalar formulation calculates the magnitude of its angular momentum, utilizing the moment arm (d), representing the perpendicular distance from point O to the line of action of the linear momentum. Despite being scalar in formulation, angular momentum is inherently a vector quantity. Its...
828
 01:09
Conservation of Angular Momentum
16.3K
A system's total angular momentum remains constant if the net external torque acting on the system is zero. Considering a system that consists of n tiny particles, the angular momentum of any tiny particle may change, but the system's total angular momentum would remain constant. The principle of conservation of angular momentum only considers the net external torque acting on the system. While there are internal forces exerted by different particles within the system that also produce...
16.3K
 01:23
Principle of Angular Impulse and Momentum
1.3K
The angular impulse and momentum principle provides insights into how forces applied at a distance from an object's rotational axis influence its angular velocity. It builds upon the crucial relationship between the moment of force and angular momentum. By integrating this equation, substituting the limits for the initial and final times, a comprehensive expression representing the angular impulse and momentum principle is derived.
1.3K
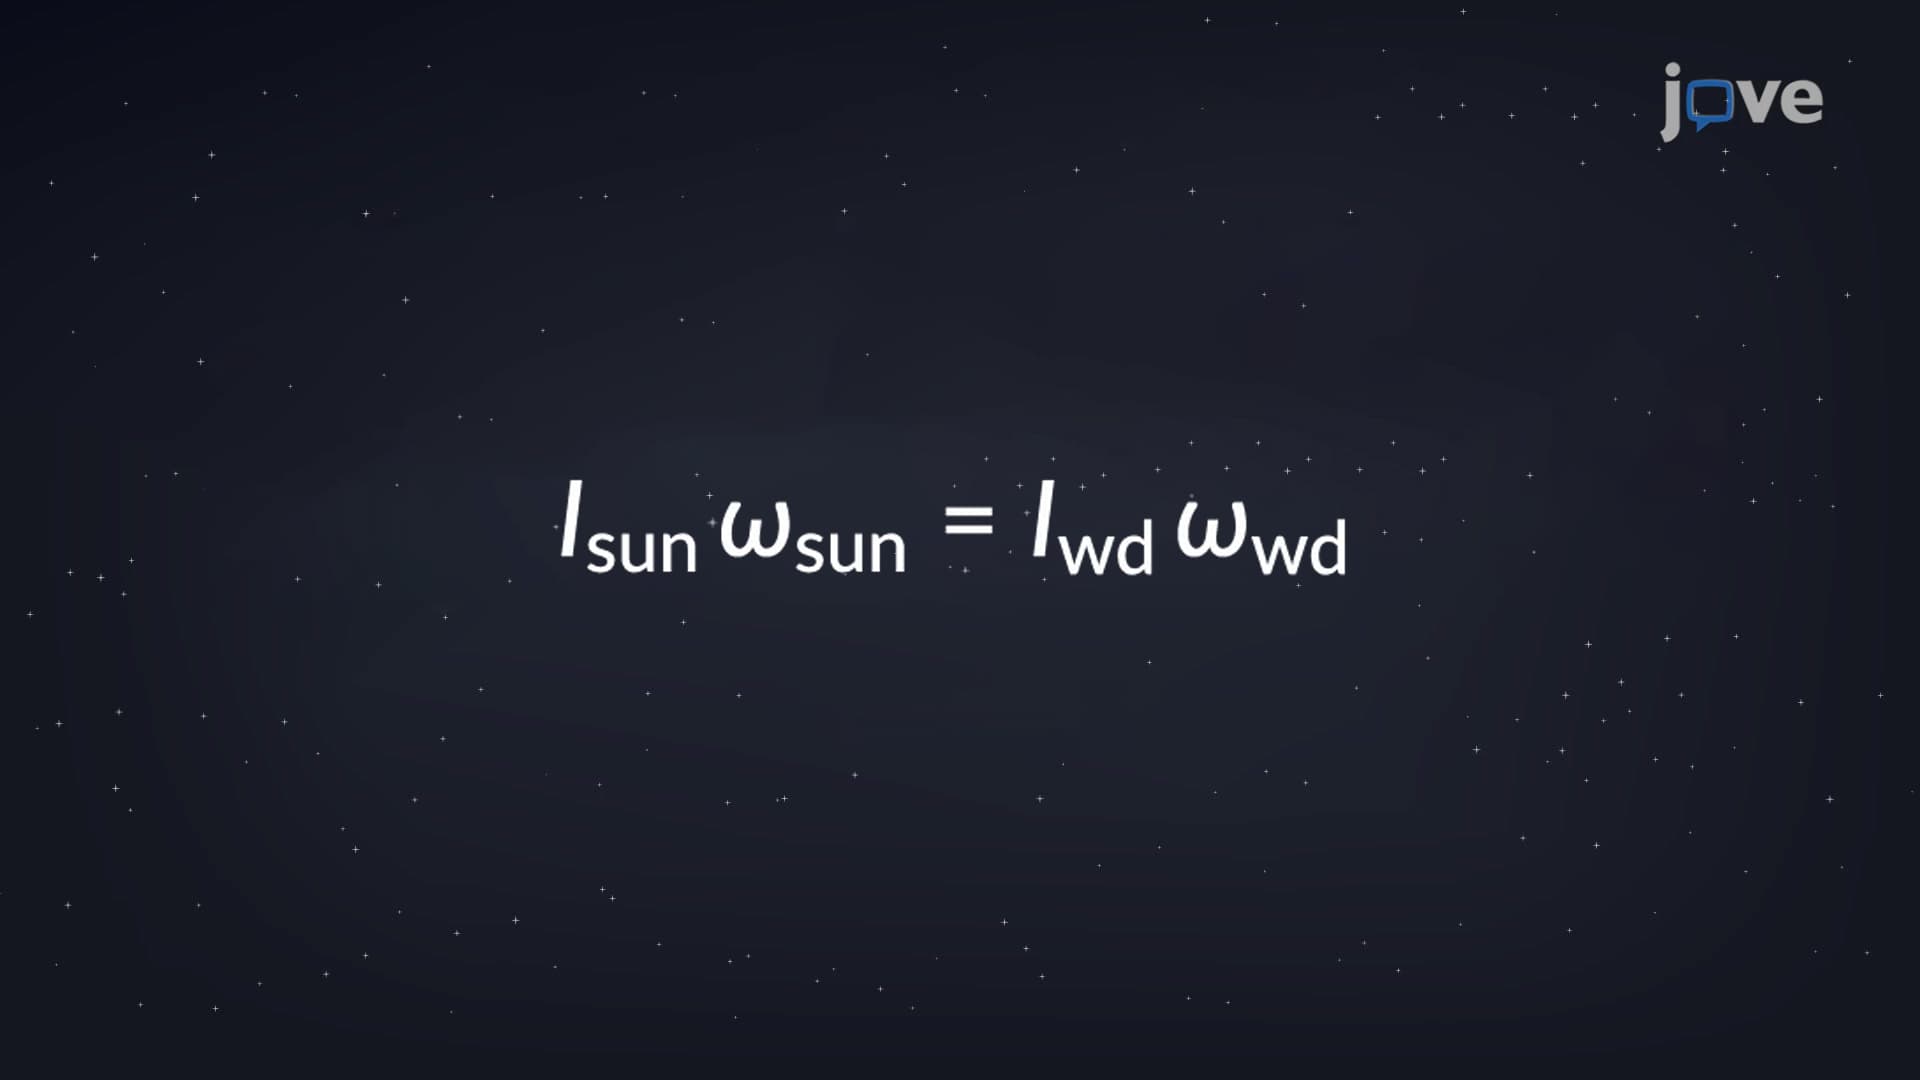 01:18
Conservation of Angular Momentum: Application
12.3K
A system's total angular momentum remains constant if the net external torque acting on the system is zero. Examples of such systems include a freely spinning bicycle tire that slows over time due to torque arising from friction, or the slowing of Earth's rotation over millions of years due to frictional forces exerted on tidal deformations. However in the absence of a net external torque, the angular momentum remains conserved. The conservation of angular momentum principle requires a...
12.3K
 01:10
Angular Momentum: Single Particle
7.8K
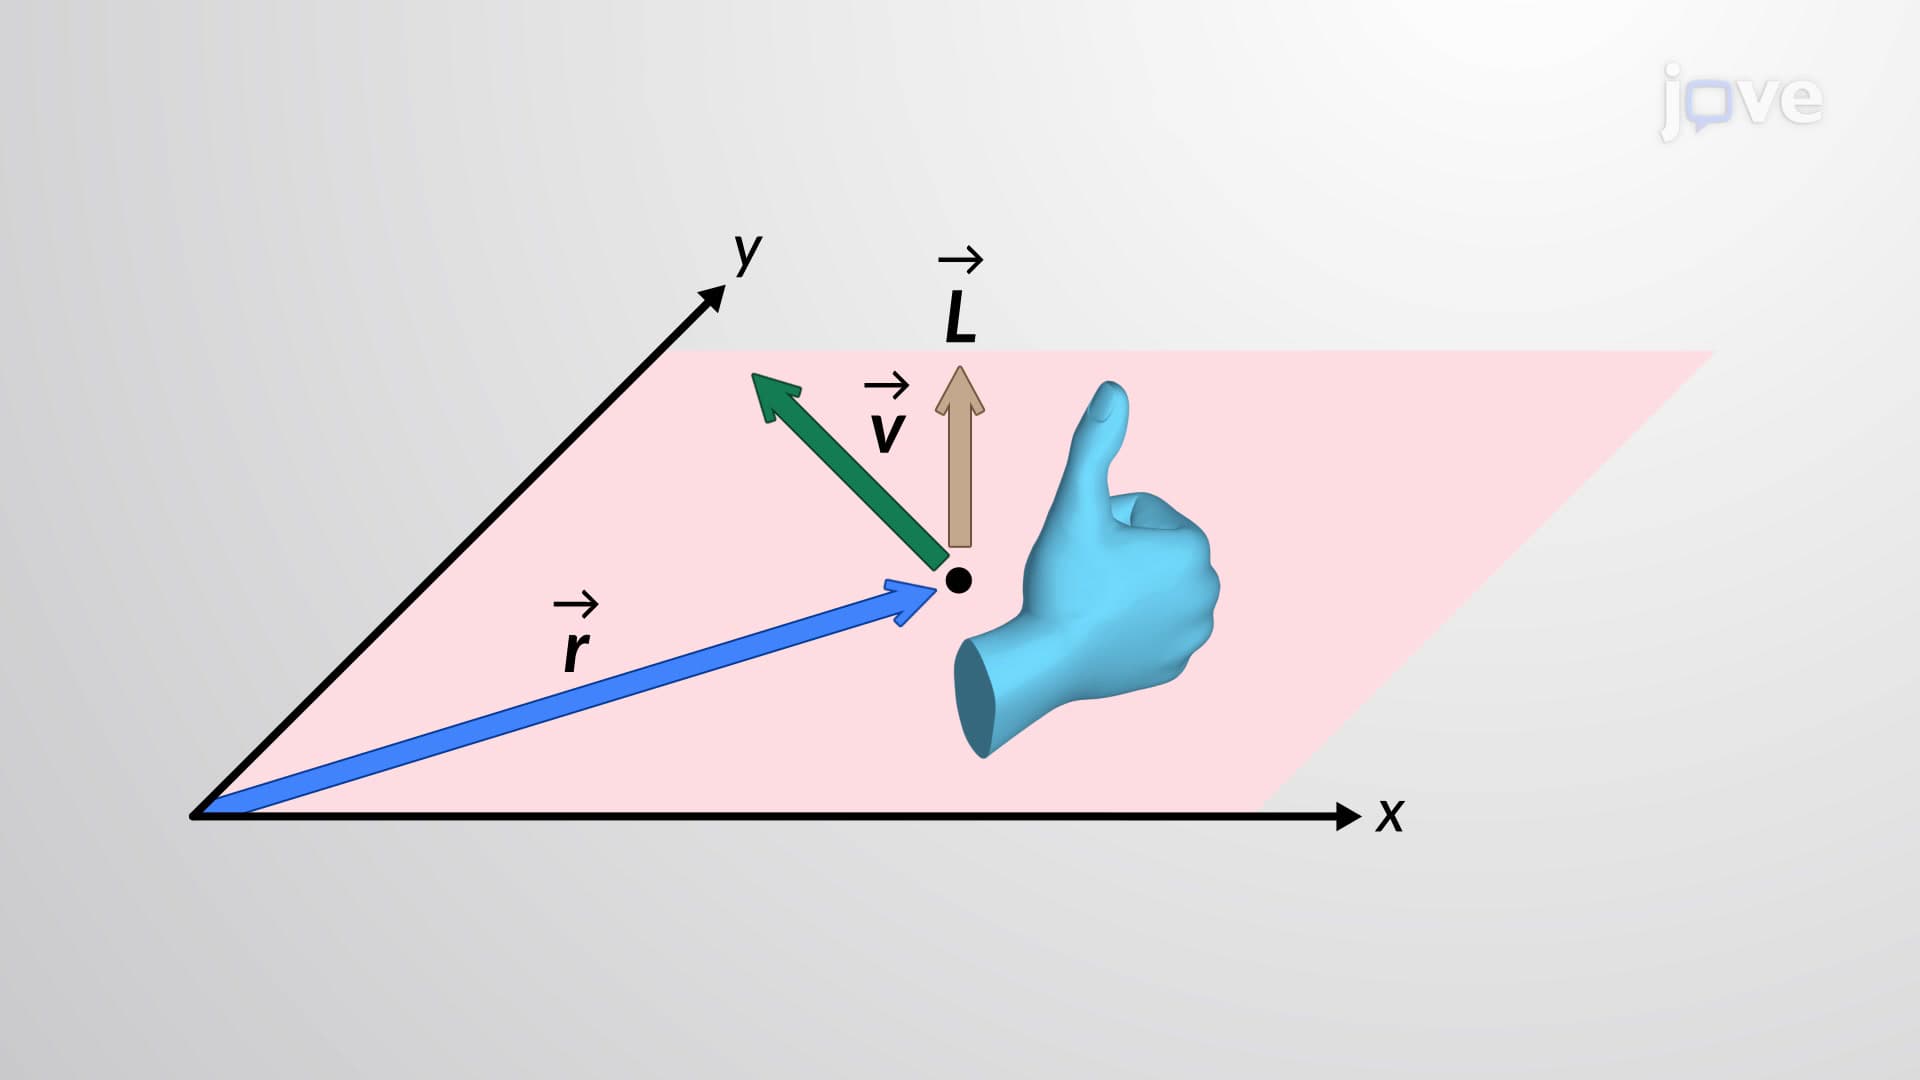
Angular momentum is directed perpendicular to the plane of the rotation, and its magnitude depends on the choice of the origin. The perpendicular vector joining the linear momentum vector of an object to the origin is called the “lever arm.” If the lever arm and linear momentum are collinear, then the magnitude of the angular momentum is zero. Therefore, in this case, the object rotates about the origin such that it lies on the rim of the circumference defined by the lever arm...
7.8K