
使用两无人机 (AUAV) 和基于深度学习的计算机视觉,在浅水中进行具有成本效益的生态监测
Fan Zhao1, Jiaqi Wang1, Yijia Chen1
1Graduate School of Frontier Sciences, The University of Tokyo, Japan.
Marine environmental research
|February 12, 2026

概括
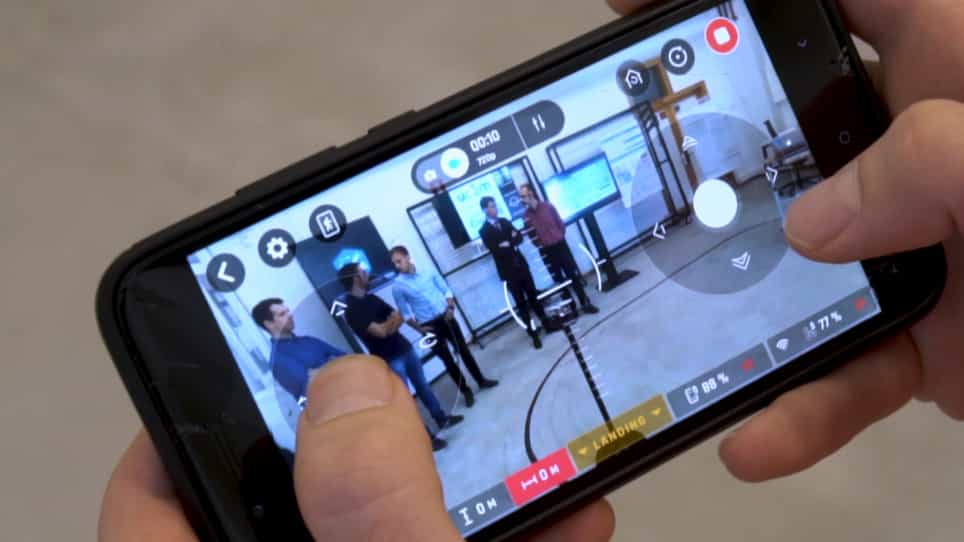
本研究介绍了一种带有深度学习的两无人机 (AUAV),用于高效的海洋监测. 该AUAV系统在检测水下垃圾和细分海黄瓜方面取得了很高的准确性,为浅水生态调查提供了切实可行的替代方案.
科学领域:
- 海洋生物学 海洋生物学
- 机器人技术 机器人技术 机器人技术
- 人工智能的人工智能
背景情况:
- 传统的海洋监测方法是低效和昂贵的.
- 像AUV和P-SSS这样的现代技术在成本,劳动力和数据质量方面都有局限性.
研究的目的:
- 开发一个高效和实用的浅水生态监测系统.
- 将深度学习与两无人机 (AUAV) 整合起来,用于海洋调查.
主要方法:
- 一种两无人驾驶飞行器 (AUAV),配备实时GNSS,用于空中和水下成像.
- 整合YOLOv8深度学习模型用于水下垃圾检测和海黄实例细分.
- 使用实例细分结果对海黄瓜大小进行定量分析.
主要成果:
- 对于水下垃圾检测,YOLOv8的平均精度 (mAP) 为0.764,比之前的基准值有显著改善.
- 在海物体检测 (mAP 0.792) 和实例细分 (mAP 0.798) 中,YOLOv8表现出高性能.
- 该框架允许精确的像素级大小估计海黄瓜.
结论:
- AUAV-YOLOv8框架为浅水生态监测提供了高效和定量解决方案.
- 这种综合系统为传统的水下勘测平台提供了实用且具有成本效益的替代方案.
- 该研究强调了人工智能驱动的无人机在促进海洋研究和保护方面的潜力.
相关概念视频
 02:26
Ecological Disturbance
21.1K
An ecological disturbance is a temporary disruption in the environment resulting from abiotic, biotic, or anthropogenic factors, causing a pronounced change in an ecosystem. The impact of an ecological disturbance, which can depend on its intensity, frequency, and spatial distribution, plays a significant role in shaping the species diversity within the ecosystem.
21.1K
 02:17
Ecological Succession
21.6K
Ecological succession is influenced by the processes of facilitation, inhibition, and toleration. Facilitation occurs when early successional species create more favorable ecological conditions for subsequent species, such as enhanced nutrient, water, or light availability. In contrast, inhibition happens when early successional species create unfavorable ecological conditions for potential successive species, such as limiting resource availability. In some cases, later successional species...
21.6K
 02:02
Ecological Niches
26.8K
All organisms have a position within an ecosystem. The complete set of living and nonliving factors—including food resources, climate, and terrain—that define the position of a given organism are collectively referred to as the organism’s ecological niche.
26.8K
 01:24
Vision
60.3K
Vision is the result of light being detected and transduced into neural signals by the retina of the eye. This information is then further analyzed and interpreted by the brain. First, light enters the front of the eye and is focused by the cornea and lens onto the retina—a thin sheet of neural tissue lining the back of the eye. Because of refraction through the convex lens of the eye, images are projected onto the retina upside-down and reversed.
60.3K
 02:30
Water: A Bronsted-Lowry Acid and Base
59.2K
The reaction between a Brønsted-Lowry acid and water is called acid ionization. For example, when hydrogen fluoride dissolves in water and ionizes, protons are transferred from hydrogen fluoride molecules to water molecules, yielding hydronium ions and fluoride ions:
59.2K
 01:24
Color Vision
1.5K
Color perception begins in the retina, the light-sensitive layer at the back of the eye. Two main theories explain how colors are seen: the trichromatic theory and the opponent-process theory. The trichromatic theory, proposed by Thomas Young in 1802 and extended by Hermann von Helmholtz in 1852, suggests that color vision is based on three types of cone receptors in the retina. These cones are sensitive to different but overlapping ranges of wavelengths corresponding to red, blue, and green.
1.5K