

在微半球共振陀螺仪中,通过交替的伪旋转调制和自适应比例积分 (PI) 控制来提高偏差稳定性和带宽
Shiji Dai1, Peng Sun2, Yihao Zhang3
1Chengdu University of Technology, Chengdu, Sichuan 610059, China.
The Review of scientific instruments
|February 19, 2026

概括
本研究介绍了微半球共振器陀螺仪 (μHRGs) 的优化PI控制系统. 适应性调整增强了带宽并消除了偏差,改善了惯性导航和航空航天应用的性能.
科学领域:
- 传感器技术 传感器技术
- 控制系统工程 控制系统工程
- 应用物理 应用物理
背景情况:
- 微半球共振器陀螺仪 (μHRGs) 在惯性导航和航空航天等高精度应用中至关重要.
- 传统的比例积分 (PI) 控制方法难以满足μHRG要求的带宽,噪声和稳定性要求.
研究的目的:
- 为μHRGs开发一个优化的PI闭环控制系统.
- 提高μHRG的性能指标,特别是带宽,降噪和长期稳定性.
主要方法:
- 在现场可编程门阵列 (FPGA) 平台上实现PI增强参数的自适应调整机制.
- 整合交替伪旋转调制以抵消零偏差错误.
主要成果:
- μHRG带宽从最低的1.5 Hz显著增强到超过8 Hz.
- 提出的方法有效地消除了由μHRG环形不均性引起的零偏差.
- 实验验证证了自适应PI算法的可靠性和有效性.
结论:
- 优化的自适应PI控制系统明显改善了μHRG性能.
- 开发的系统解决了高端陀螺仪应用传统控制方法的关键局限性.
- 这种进步对于需要精确惯性测量的领域具有重大潜力.

相关概念视频
 01:02
Gyroscope
3.6K
A gyroscope is defined as a spinning disk in which the axis of rotation is free to assume any orientation. When spinning, the orientation of the spin axis is unaffected by the orientation of the body that encloses it. The body or vehicle enclosing the gyroscope can be moved from place to place, while the orientation of the spin axis remains the same. This makes gyroscopes very useful in navigation, especially where magnetic compasses cannot be used, such as in crewed and crewless spacecraft,...
3.6K
 01:24
Gyroscope: Precession
4.8K
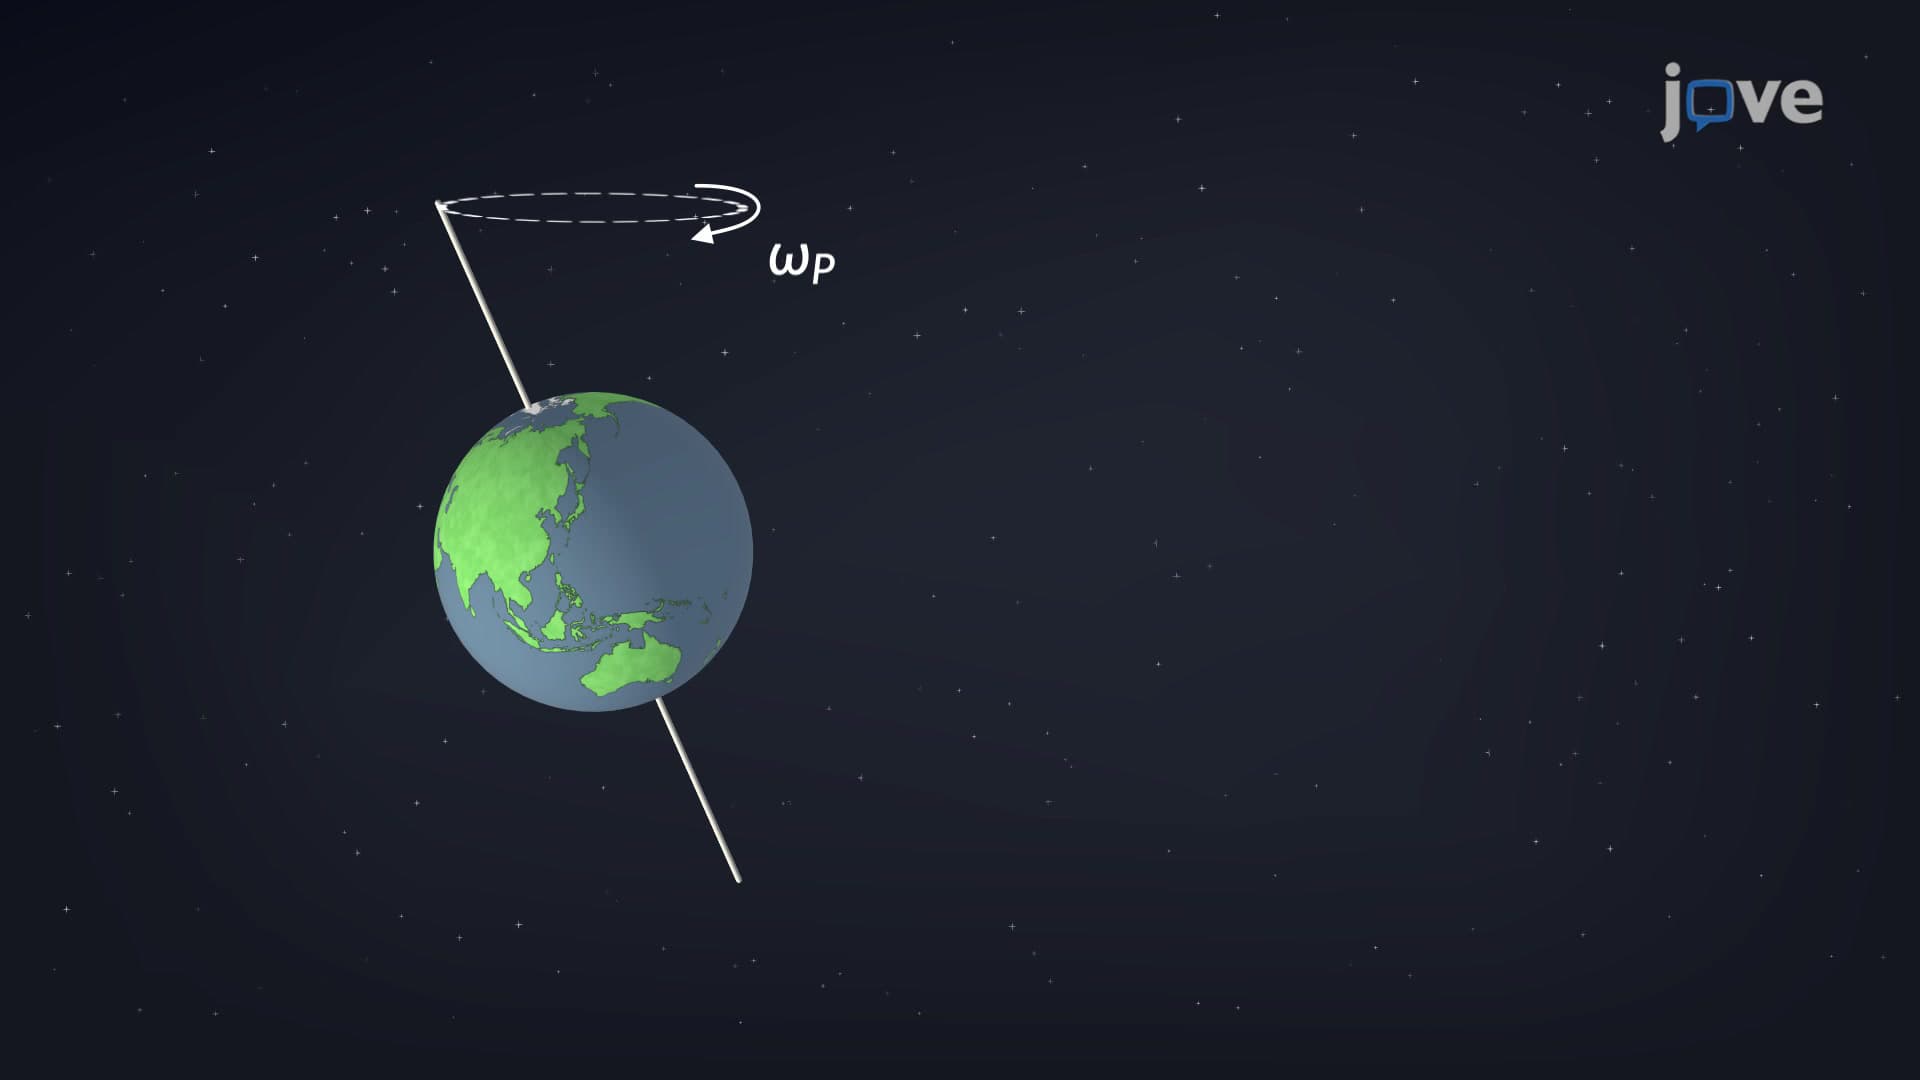
Precession can be demonstrated effectively through a spinning top. If a spinning top is placed on a flat surface near the surface of the Earth at a vertical angle and is not spinning, it will fall over due to the force of gravity producing a torque acting on its center of mass. However, if the top is spinning on its axis, it precesses about the vertical direction, rather than topple over due to this torque. Precessional motion is a combination of a steady circular motion of the axis and the...
4.8K
 01:24
Pole and System Stability
1.3K
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
1.3K
 01:07
Time-Domain Interpretation of PD Control
500
Proportional-Derivative (PD) control is a widely used control method in various engineering systems to enhance stability and performance. In a system with only proportional control, common issues include high maximum overshoot and oscillation, observed in both the error signal and its rate of change. This behavior can be divided into three distinct phases: initial overshoot, subsequent undershoot, and gradual stabilization.
Consider the example of control of motor torque. Initially, a positive...
Consider the example of control of motor torque. Initially, a positive...
500
 01:24
PI Controller: Design
1.6K
Proportional Integral (PI) controllers are a fundamental component in modern control systems, widely used to enhance performance and mitigate steady-state errors. They are particularly effective in applications such as automatic brightness adjustment on smartphones, where they excel at mitigating steady-state errors for step-function inputs. Unlike PD controllers, which require time-varying errors to function optimally, PI controllers leverage their integral component to address residual...
1.6K
 01:27
Time and frequency -Domain Interpretation of PI Control
503
Proportional-Integral (PI) controllers are essential in many control systems to improve stability and performance. They are commonly used in everyday devices like thermostats to enhance system damping and reduce steady-state error. When the zero in the controller's transfer function is optimally placed, the system benefits significantly in terms of stability and accuracy.
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
Acting as a low-pass filter, the PI controller slows the system's response and extends settling times. This requires...
503