动态系统的减少顺序建模与振荡器的平均场相结合:适用于热声系统
Rohan K Nakade1, Samarjeet Singh1, Jayesh M Dhadphale1
1Indian Institute of Technology Madras, Indian Institute of Technology Madras, Department of Aerospace Engineering, Chennai 600036, India and Centre of Excellence for Studying Critical Transitions in Complex Systems, Chennai 600036, India.
Physical review. E
|February 20, 2026

概括
这项研究引入了一个新的框架,用于分析具有许多相互作用振荡器的复杂动态系统. 该方法简化了高维模型,使稳定性分析更容易用于实际应用.
科学领域:
- 复杂的系统复杂的系统.
- 非线性动力学是一种非线性动力学.
- 统计物理 统计物理
背景情况:
- 具有相互作用的振荡器群体的动态系统在自然界中很常见.
- 随着振荡器数量的增加,分析这些系统在计算上变得具有挑战性.
- 现有的模型通常依赖于简化对称分布,这在现实世界中是罕见的.
研究的目的:
- 开发一个通用的框架来分析与振荡器群的动态系统中的同步.
- 通过适应非标准振荡器分布来解决现有模型的局限性.
- 为了使复杂的,高维的系统稳定性制度的分析研究.
主要方法:
- 提出一个通用的框架来减少动态系统的维度.
- 应用模型缩小技术,如奥特-安东森的替代方法.
- 将高维模型缩小到一个可管理的顺序 (大约十个方程).
主要成果:
- 一种用于降低具有振荡器群体的动态系统的维度的新方法.
- 该框架成功地处理了非标准的振荡器分布.
- 减少订单模型允许分析识别系统稳定性制度.
结论:
- 拟议的框架为分析具有不同振荡器行为的复杂动态系统提供了一个强大的工具.
- 这种方法克服了传统方法的局限性,通过将非标准分布概括为非标准分布.
- 该方法被证明是有效的,在热声学等领域有潜在的应用.
相关概念视频
 01:07
Damped Oscillations
In the real world, oscillations seldom follow true simple harmonic motion. A system that continues its motion indefinitely without losing its amplitude is termed undamped. However, friction of some sort usually dampens the motion, so it fades away or needs more force to continue. For example, a guitar string stops oscillating a few seconds after being plucked. Similarly, one must continually push a swing to keep a child swinging on a playground.
Although friction and other non-conservative...
Although friction and other non-conservative...
 01:24
One-Degree-of-Freedom System
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:19
Second-order Op Amp Circuits
Implementing second-order low-pass filters in audio systems is crucial in refining audio signals by eliminating undesirable high-frequency noise. These filters typically involve second-order op-amp circuits configured as voltage followers, encompassing two nodes with distinct storage elements.
The analysis of such circuits follows a systematic approach, similar to the second-order RLC circuits. In practical scenarios, bulky inductors are rarely employed due to their size and weight. This means...
The analysis of such circuits follows a systematic approach, similar to the second-order RLC circuits. In practical scenarios, bulky inductors are rarely employed due to their size and weight. This means...
 01:22
Mechanical Systems
Mechanical systems are analogous to to electrical networks where springs and masses play similar roles to inductors and capacitors, respectively. A viscous damper in mechanical systems functions similarly to a resistor in electrical networks, dissipating energy. The forces acting on a mass in such systems include an applied force in the direction of motion, counteracted by forces from the spring, a viscous damper, and the mass's acceleration. This interplay of forces is mathematically described...
 01:20
Relation between Mathematical Equations and Block Diagrams
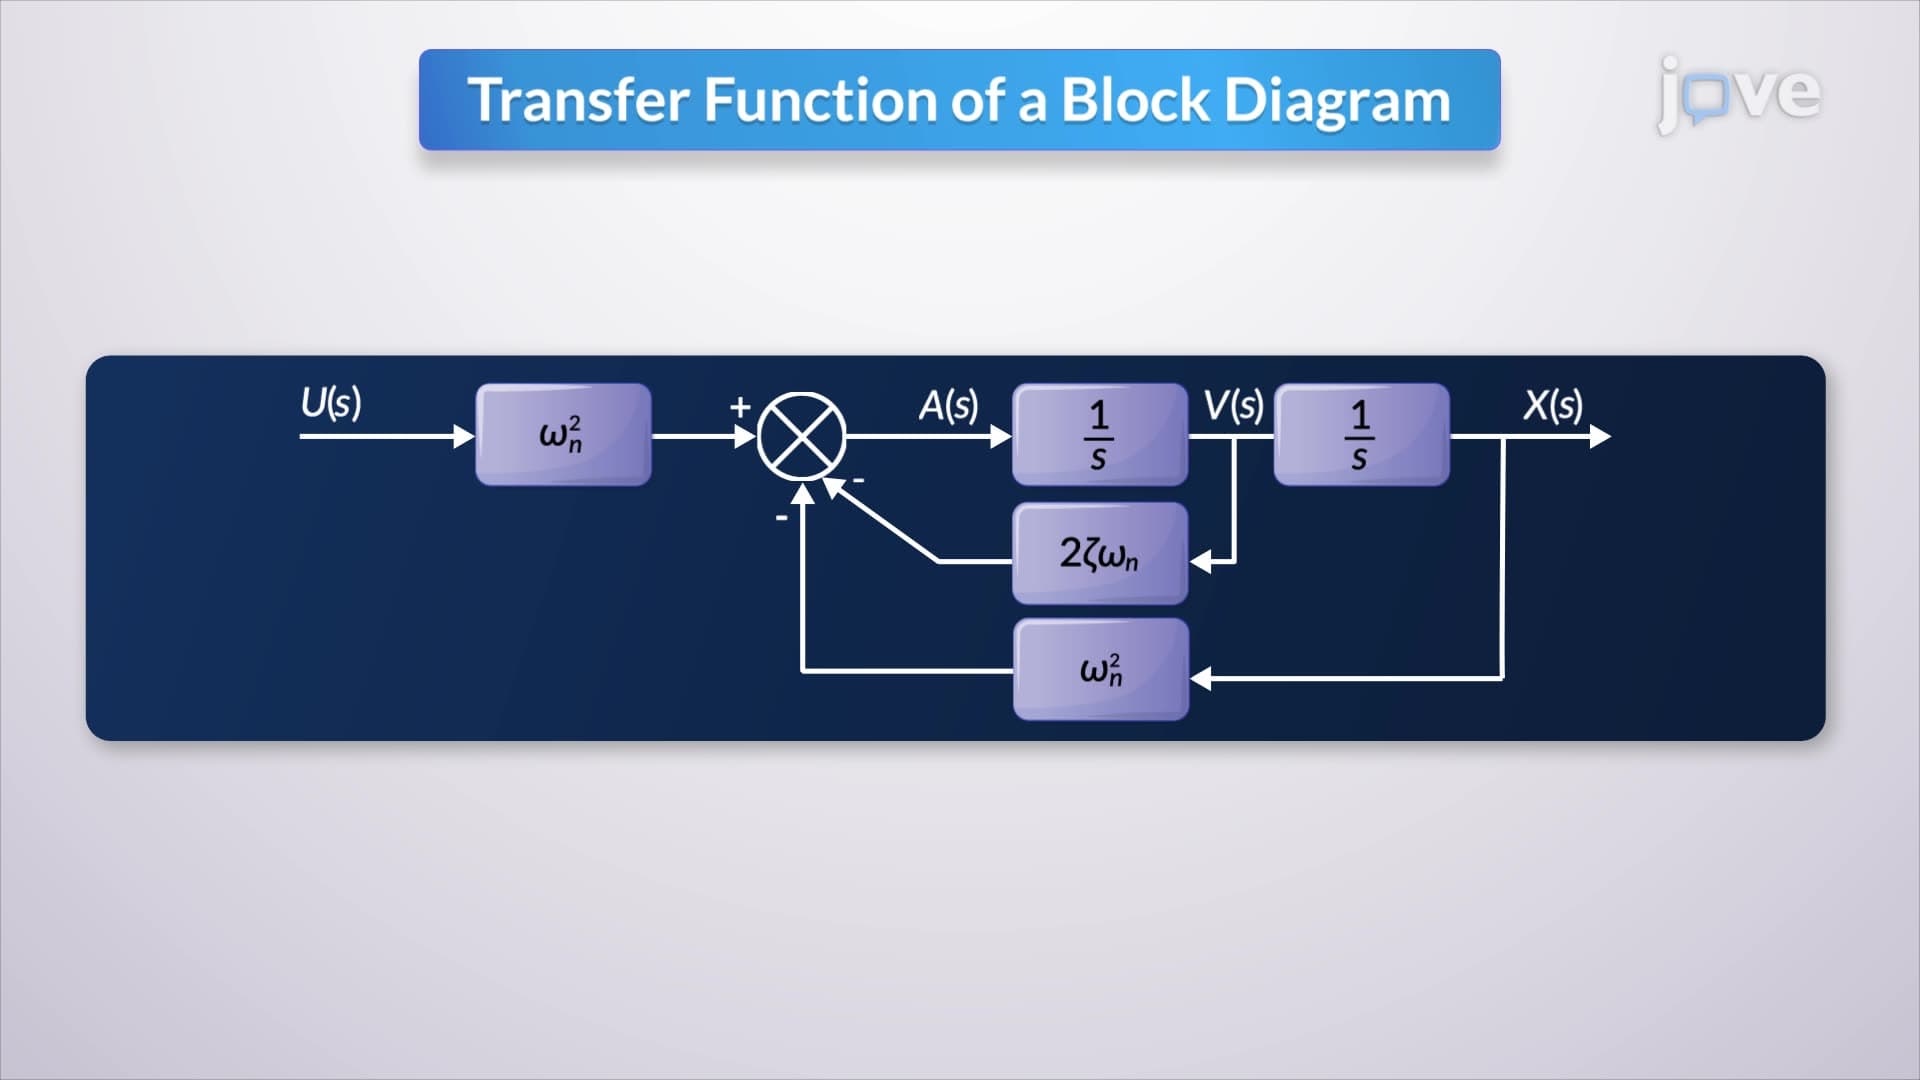
In a spring-mass-damper system, the second-order differential equation describes the dynamic behavior of the system. When transformed into the Laplace domain under zero initial conditions, this equation can be effectively analyzed and manipulated. The transformation into the Laplace domain converts differential equations into algebraic equations, simplifying the process of isolating the output.
 01:18
Second Order systems II
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
If ζ...
If ζ...