相关实验视频
Updated: Feb 24, 2026

08:12

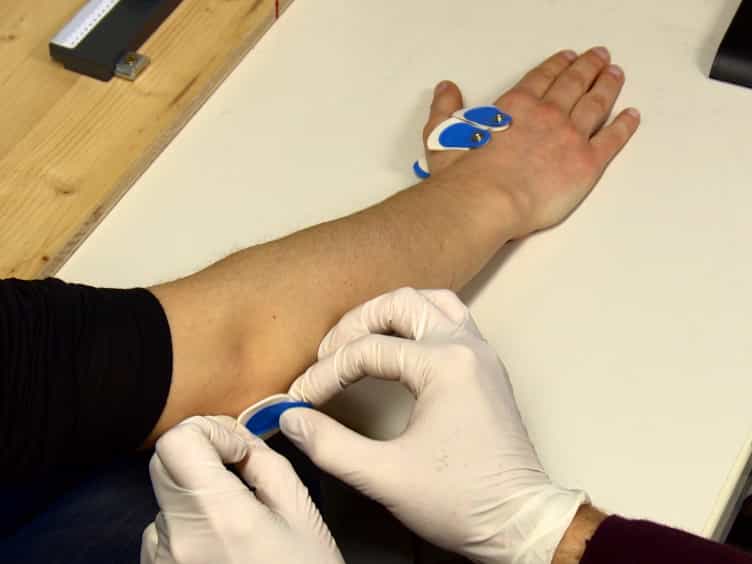
Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
10.2K
联合扭矩控制的质量中心反:可穿戴机器人平衡增强的通用方法
Research square
|February 23, 2026

概括
这项研究开发了一种新的可穿戴机器人控制器,它使用质量中心 (CoM) 偏差来预测平衡校正扭矩. 该控制器显示,它有望提高可穿戴机器人设备的稳定性,从而潜在地降低掉落风险.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 生物力学 生物力学
- 控制系统 控制系统
背景情况:
- 外骨架可以改善平衡并降低跌倒风险.
- 目前的控制器仅限于单个运动平面和特定任务 (站立或行走).
- 需要在不同的扰动和运动中制定一个通用的控制方案.
研究的目的:
- 为可穿戴机器人提出和评估一种新的扭矩控制框架.
- 为了评估延迟质量中心 (CoM) 反控制器的概括性.
- 预测多关节扭矩对不同大小,方向和运动背景的扰动的反应.
主要方法:
- 开发了一个延迟的CoM反控制器,灵感来自人类平衡策略.
- 在九名健康成年人身上测试了控制器,使用斜坡和支和侧面支表面扰动.
- 评估了控制器从站立状态到循环运动的概括能力.
主要成果:
- 控制器很好地概括了各种悬架和保持扰动 (R2 > 0.84).
- 从站立到循环运动的泛化仅限于部和膝盖的曲 (R2 > 0.70).
- 在循环运动期间,脚和部 adduction 的性能不那么强大.
结论:
- 一个灵感来自生理学的CoM反控制器可以有效地预测部/膝关节外骨架在站立和运动期间的平衡扭矩.
- 在站立时,控制器对脚外骨架有效.
- 这种方法需要的培训数据比ML算法少,使得实施速度更快,从而降低掉落风险.

相关概念视频
 01:14
Equation of Motion: Center of Mass
720
The equation of motion for a single particle can be expanded to encompass a system of particles consisting of n particles. For any arbitrarily chosen particle within this system, the net force acting upon it is the aggregate of both internal and external forces. Extending this principle to all particles within the system results in the equation of motion for the entire assembly.
Internal forces between any pair of particles manifest as collinear pairs of equal magnitude but opposite directions,...
Internal forces between any pair of particles manifest as collinear pairs of equal magnitude but opposite directions,...
720
 01:26
Feedback control systems
744
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
744
 01:03
Center of Mass: Introduction
22.2K
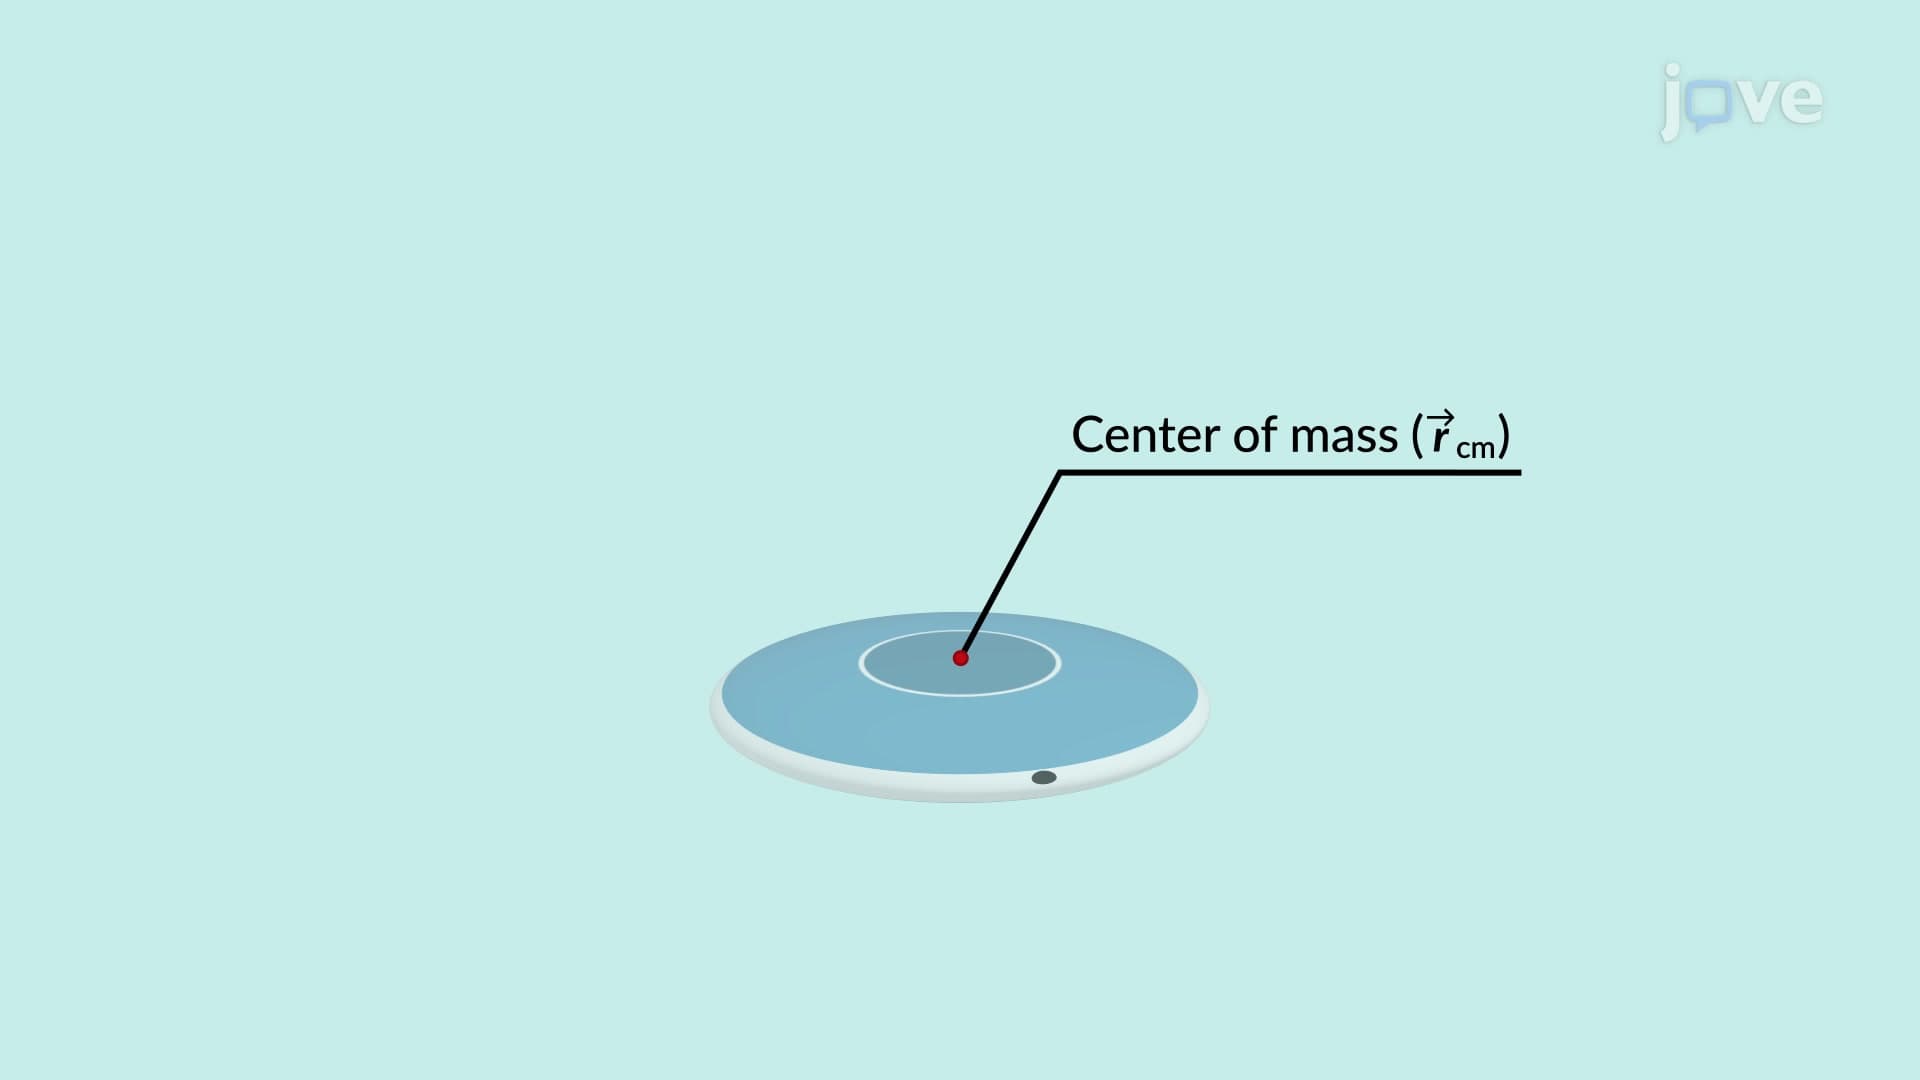
Any object that obeys Newton's second law of motion is made up of a large number of infinitesimally small particles. Objects in motion can be as simple as atoms or as complex as gymnasts performing in the Olympics. The motion of such objects is described about a point called the center of mass of the object. The center of mass of an object is a point that acts as if the whole mass is concentrated at that point. The center of mass of an object with a large number of infinitesimally small...
22.2K
 00:59
Center of Mass
2.1K
The center of mass is the point at which the total mass of an object can be said to be concentrated. It is a fundamental principle in mechanics and physics that applies to all objects regardless of their shape or size. The center of gravity is the point at which an object’s weight appears to be concentrated and can be used to balance the object perfectly.
The knowledge of the center of mass can also help us to describe and predict the motion of objects. For example, when a ball is thrown...
The knowledge of the center of mass can also help us to describe and predict the motion of objects. For example, when a ball is thrown...
2.1K
 01:15
Torque Free Motion
877
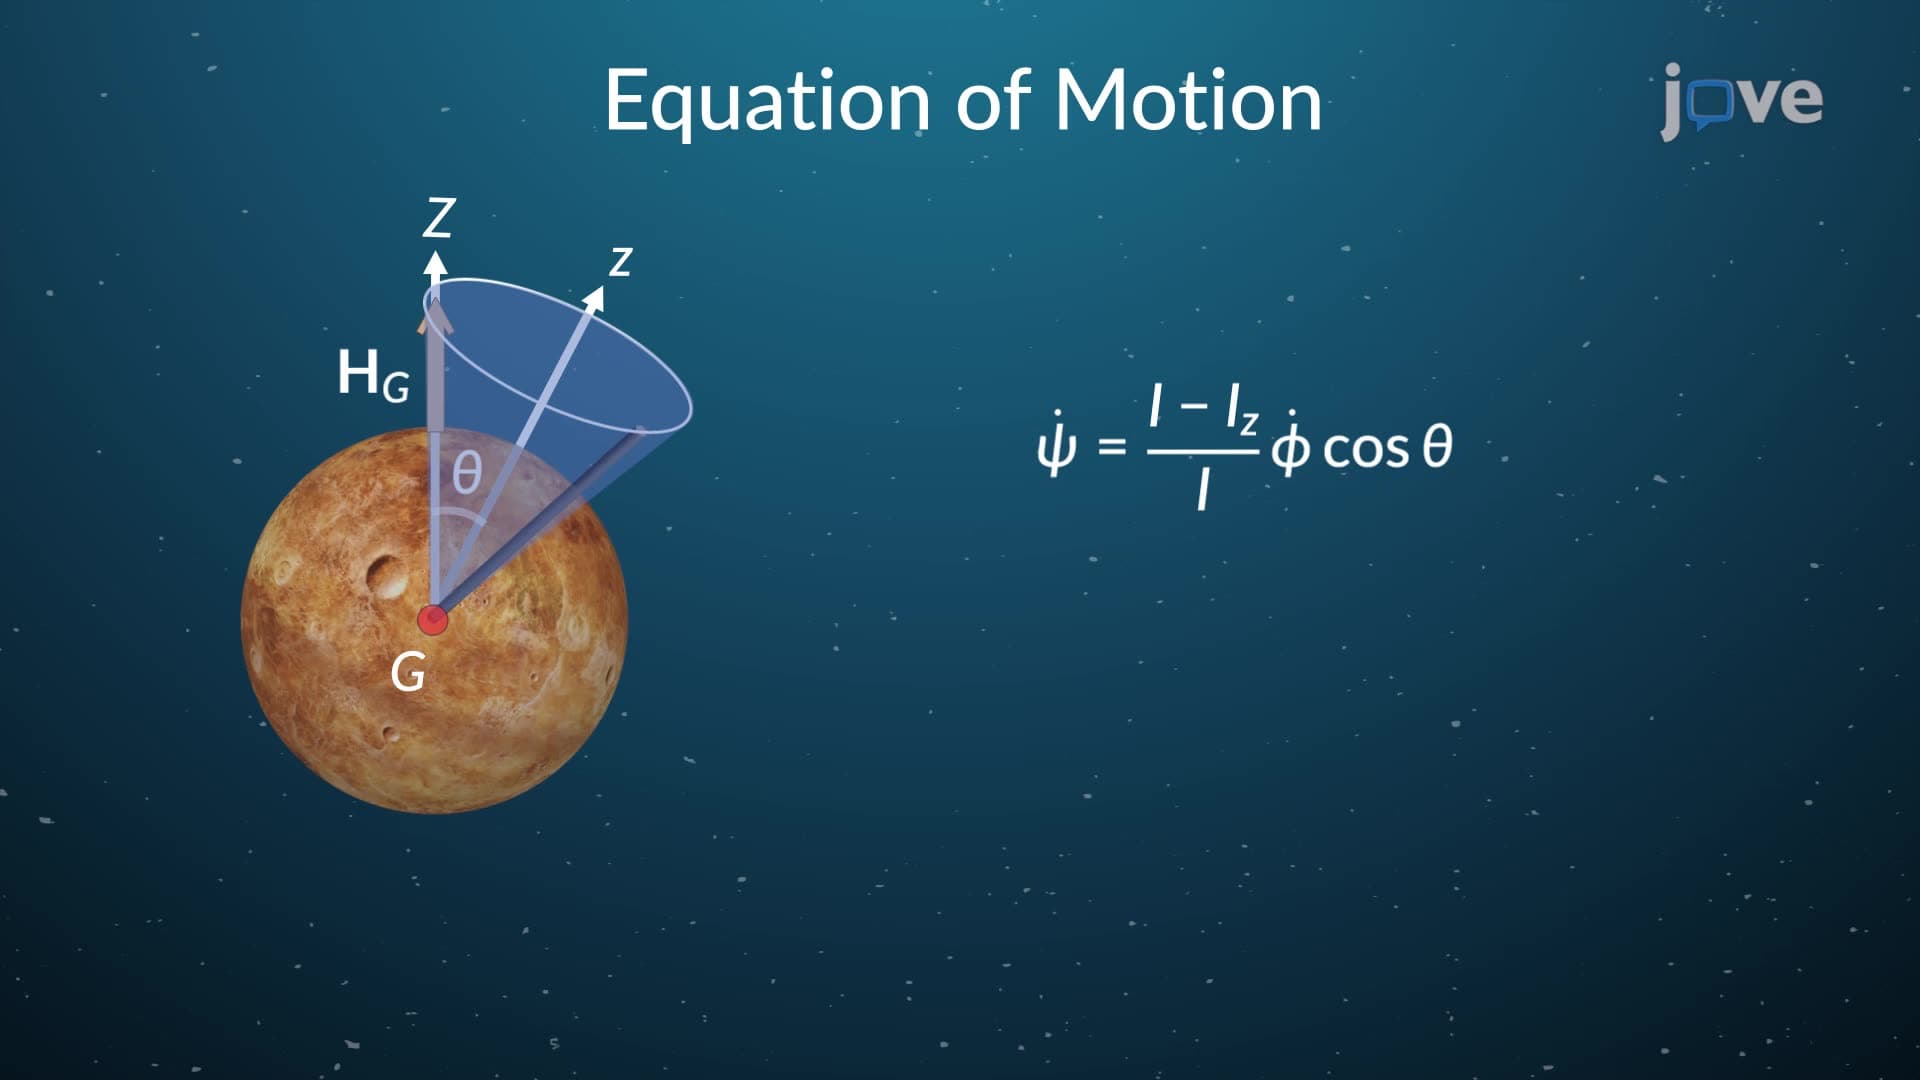
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
877
 01:24
One-Degree-of-Freedom System
875
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
875