相关实验视频
Updated: May 6, 2026
09:36
Measurement of Spatial Stability in Precision Grip
Published on: June 4, 2020
3.6K
无校准的每指力反滑动控制器,用于用三轴触摸传感器通过人形手抓取
Dickson Chiu Yu Wong1, Zheng H Zhu1
1Department of Mechanical Engineering, York University, Toronto, ON, Canada.
Frontiers in robotics and AI
|February 25, 2026

概括
这项研究引入了机器人手的滑动恢复控制器,使机器人手能够在不经校准的情况下对未知物体进行强有力的抓取. 它使用触觉传感器实时检测和纠正滑动,提高机器人操纵的安全性和效率.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统 控制系统
- 传感器技术 传感器技术
背景情况:
- 机器人抓住未知的物体在保持稳定的抓取方面存在挑战.
- 滑动检测和恢复对于强大的机器人操纵至关重要,特别是在动态环境中.
- 现有的方法往往需要广泛的校准或复杂的传感方式.
研究的目的:
- 为人类形象机器人手开发一个强大的,无校准的滑动恢复控制器.
- 通过触觉力传感,实现实时检测和纠正抓地滑动.
- 为了尽量减少实际机器人应用的计算和集成要求.
主要方法:
- 在每个手指上都使用了三轴压电阻触觉力传感器,用于滑动检测.
- 开发了一种基于与基线相对接触力和正常力变化的滑动检测算法.
- 实施了闭环,每指力调整策略,用于滑动恢复与电机电流保护.
主要成果:
- 通过每只手指的调整,证明了快速的局部滑动校正.
- 在包括干扰在内的各种条件下,能够有效地恢复抓住的物体的稳定.
- 验证了对具有不同性质 (刚性,纹理,重量) 的物体的方法.
结论:
- 拟议的方法提供了一种实用,计算效率高的解决方案,用于机器人抓取中的滑动检测和恢复.
- 消除了对象特定校准,摩擦建模或复杂视觉系统的需求.
- 提高掌握稳定性和效率,适用于仓库自动化和人机协作等应用.


相关概念视频
 01:05
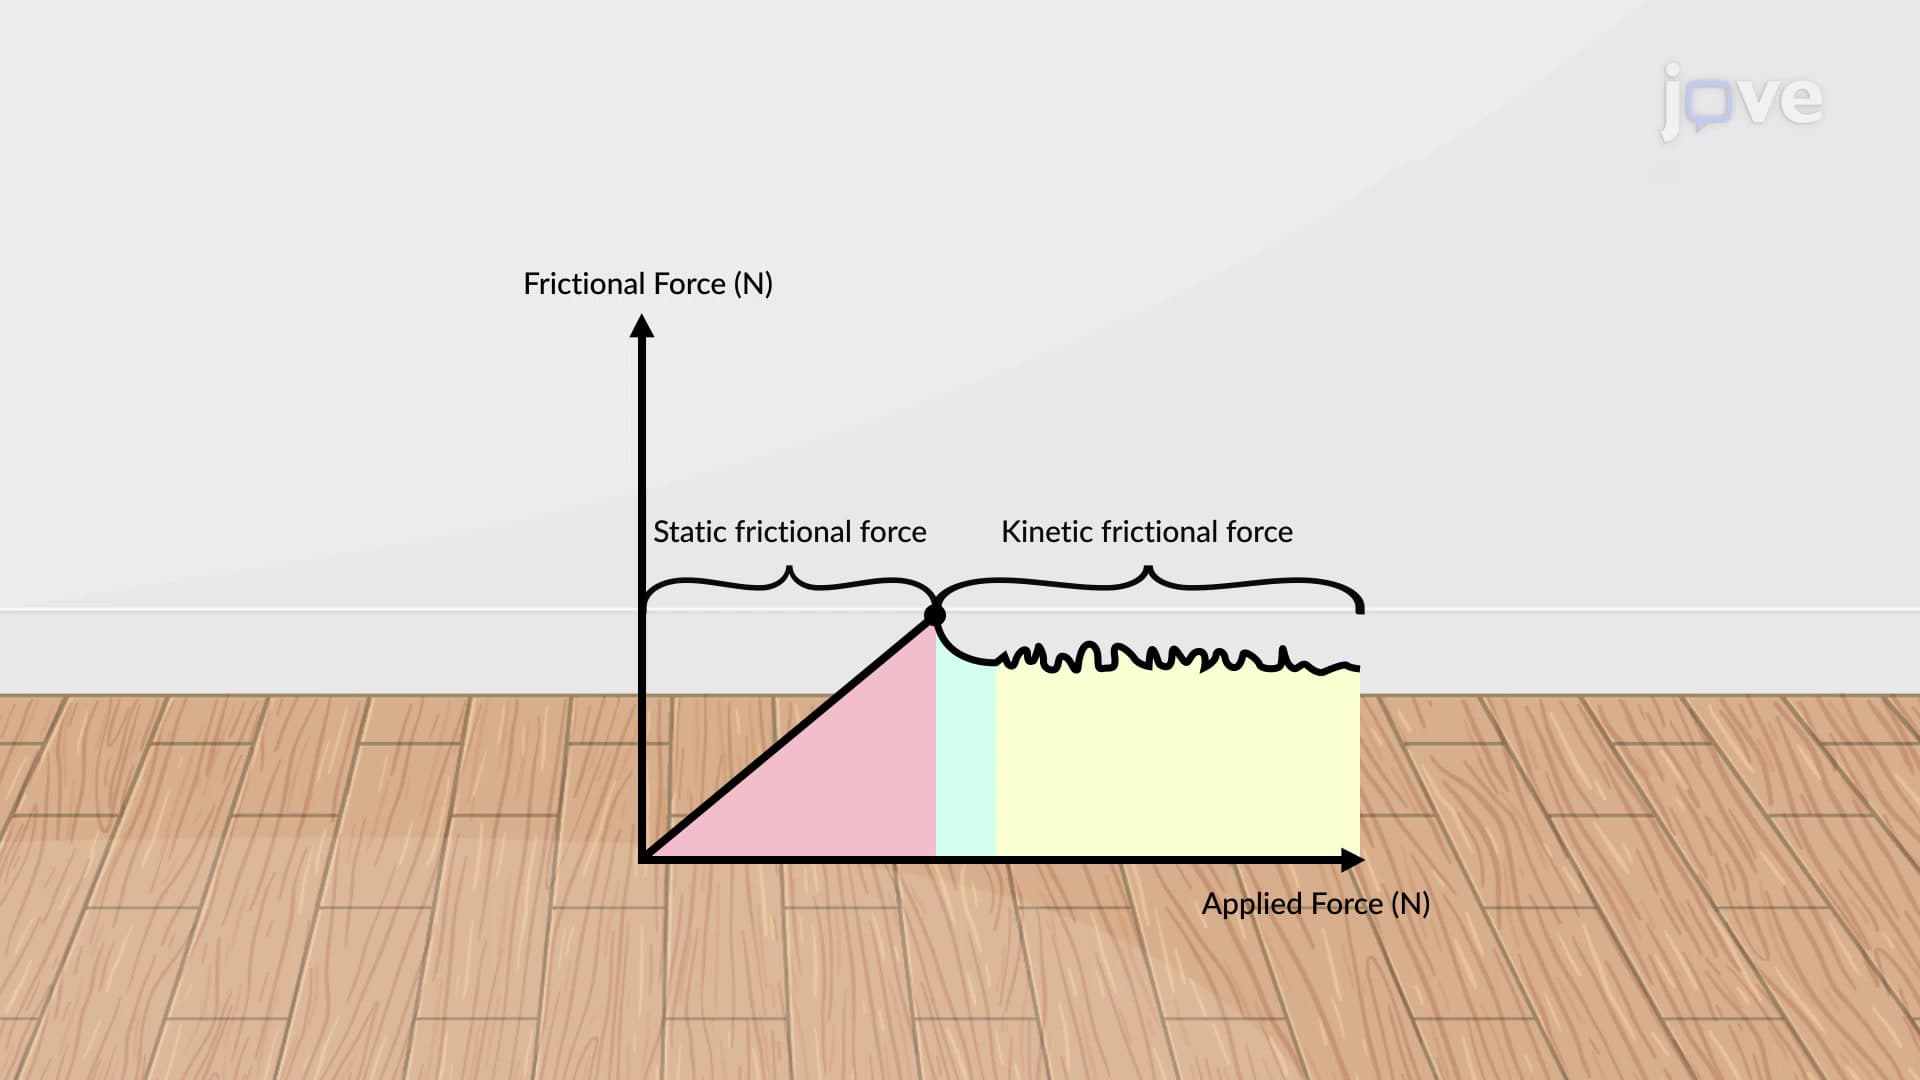
Static and Kinetic Frictional Force
20.5K
One of the simpler characteristics of sliding friction is that it is parallel to the contact surfaces between systems, and is always in a direction that opposes the motion or attempted motion of the systems relative to each other. If two systems are in contact and moving relative to one another, then the friction between them is called kinetic friction. For example, kinetic friction slows a hockey puck sliding on ice.
However, if two systems are in contact and are stationary relative to one...
However, if two systems are in contact and are stationary relative to one...
20.5K
 01:26
Kinetic Friction
1.6K
Consider a truck trying to pull a stationary car. As the truck exerts a force on the car, static friction is created at the point of contact between the two surfaces. This frictional force resists the car's movement and keeps it at rest. However, when the applied force by the truck surpasses the limiting static frictional force, an interesting phenomenon occurs. The frictional force at the interface reduces to a lower value, known as the kinetic frictional force. At this point, the car...
1.6K
 01:27
Types of Friction Problems
1.1K
Friction is an essential concept in physics, engineering, and everyday life. It is the force that opposes the relative motion or tendency of such motion between two surfaces in contact. One of the most common types of friction encountered in various applications is dry friction. Dry friction problems can be broadly categorized into three types, each with unique characteristics and challenges.
The first type of dry friction problem involves situations where there is no apparent impending motion....
The first type of dry friction problem involves situations where there is no apparent impending motion....
1.1K
 01:17
Rolling Resistance: Problem Solving
996
Rolling resistance, also known as rolling friction, is the force that resists the motion of a rolling object, such as a wheel, tire, or ball, when it moves over a surface. It is caused by the deformation of the object and the surface in contact with each other, as well as other factors like internal friction, hysteresis, and energy losses within the materials. Rolling resistance opposes the object's motion, requiring additional energy to overcome it and maintain movement. In practical...
996
 01:14
Design Example: Resistive Touchscreen
951
A device engineer plays a crucial role in designing user interfaces for mobile devices. One such interface is the resistive touchscreen, which fundamentally consists of two metallic layers: a flexible upper layer and a rigid lower layer, separated by a narrow gap. The high resistance between these two layers is a key characteristic of this design.
When a user touches the screen, the two layers make contact at a specific point known as the touchpoint. This contact reduces the resistance between...
When a user touches the screen, the two layers make contact at a specific point known as the touchpoint. This contact reduces the resistance between...
951
 01:26
Feedback control systems
805
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
805