
周期驱动的 O ((N) 标量场理论稳态和响应函数的周期驱动 O ((N) 标量场理论
Oriana K Katharina Diessel1, Subir Sachdev1, Pietro Maria Maria Bonetti2
1Physics, Harvard University Faculty of Arts and Sciences, 17 Oxford Street, Cambridge, Massachusetts, 02138, United States.
Reports on progress in physics. Physical Society (Great Britain)
|February 26, 2026

概括
我们探索了一个驱动的O ((N) -对称理论.
科学领域:
- 理论物理学的理论物理.
- 凝聚物质物理学 凝聚物质物理学
背景情况:
- 研究驱动系统的相图对于理解物质的异常状态至关重要.
- 将理论与热浴和电磁潜力的结合揭示了复杂的行为.
研究的目的:
- 绘制相对论的相位图,参数驱动的O (n) -对称理论与热浴相结合.
- 分析失对称状态的出现及其与电磁场的相互作用.
主要方法:
- 对相对论的分析,参数驱动的O (n) -对称理论.
- 包括马科维亚热浴和背景电磁潜力.
- 研究顺序参数振荡及其对光子质量的影响.
主要成果:
- 识别了各种各样的阶段,包括统一的和空间调制的对称性破裂状态.
- 观察到Meissner效应和一个新的"Meissner极子"从光序参数杂交.
- 由于在对称性破裂附近的波动,发现了类似超导的反应.
结论:
- 驱动的O(N) -对称理论表现出丰富的相位行为,对光诱导的顺序有影响.
- 迈斯纳极子代表了一类新的集体模式,具有潜在的应用.
- 接近对称性破坏的波动可以在没有完全Meissner效应的情况下诱导超导特性.
相关概念视频
 01:24
Transient and Steady-state Response
610
In control systems, test signals are essential for evaluating performance under various conditions. The ramp function is effective for systems undergoing gradual changes, while the step function is suitable for assessing systems facing sudden disturbances. For systems subjected to shock inputs, the impulse function is the most appropriate test signal.
These test signals are integral in designing control systems to exhibit two key performance aspects: transient response and steady-state...
These test signals are integral in designing control systems to exhibit two key performance aspects: transient response and steady-state...
610
 01:11
Types of Responses of Series RLC Circuits
2.1K
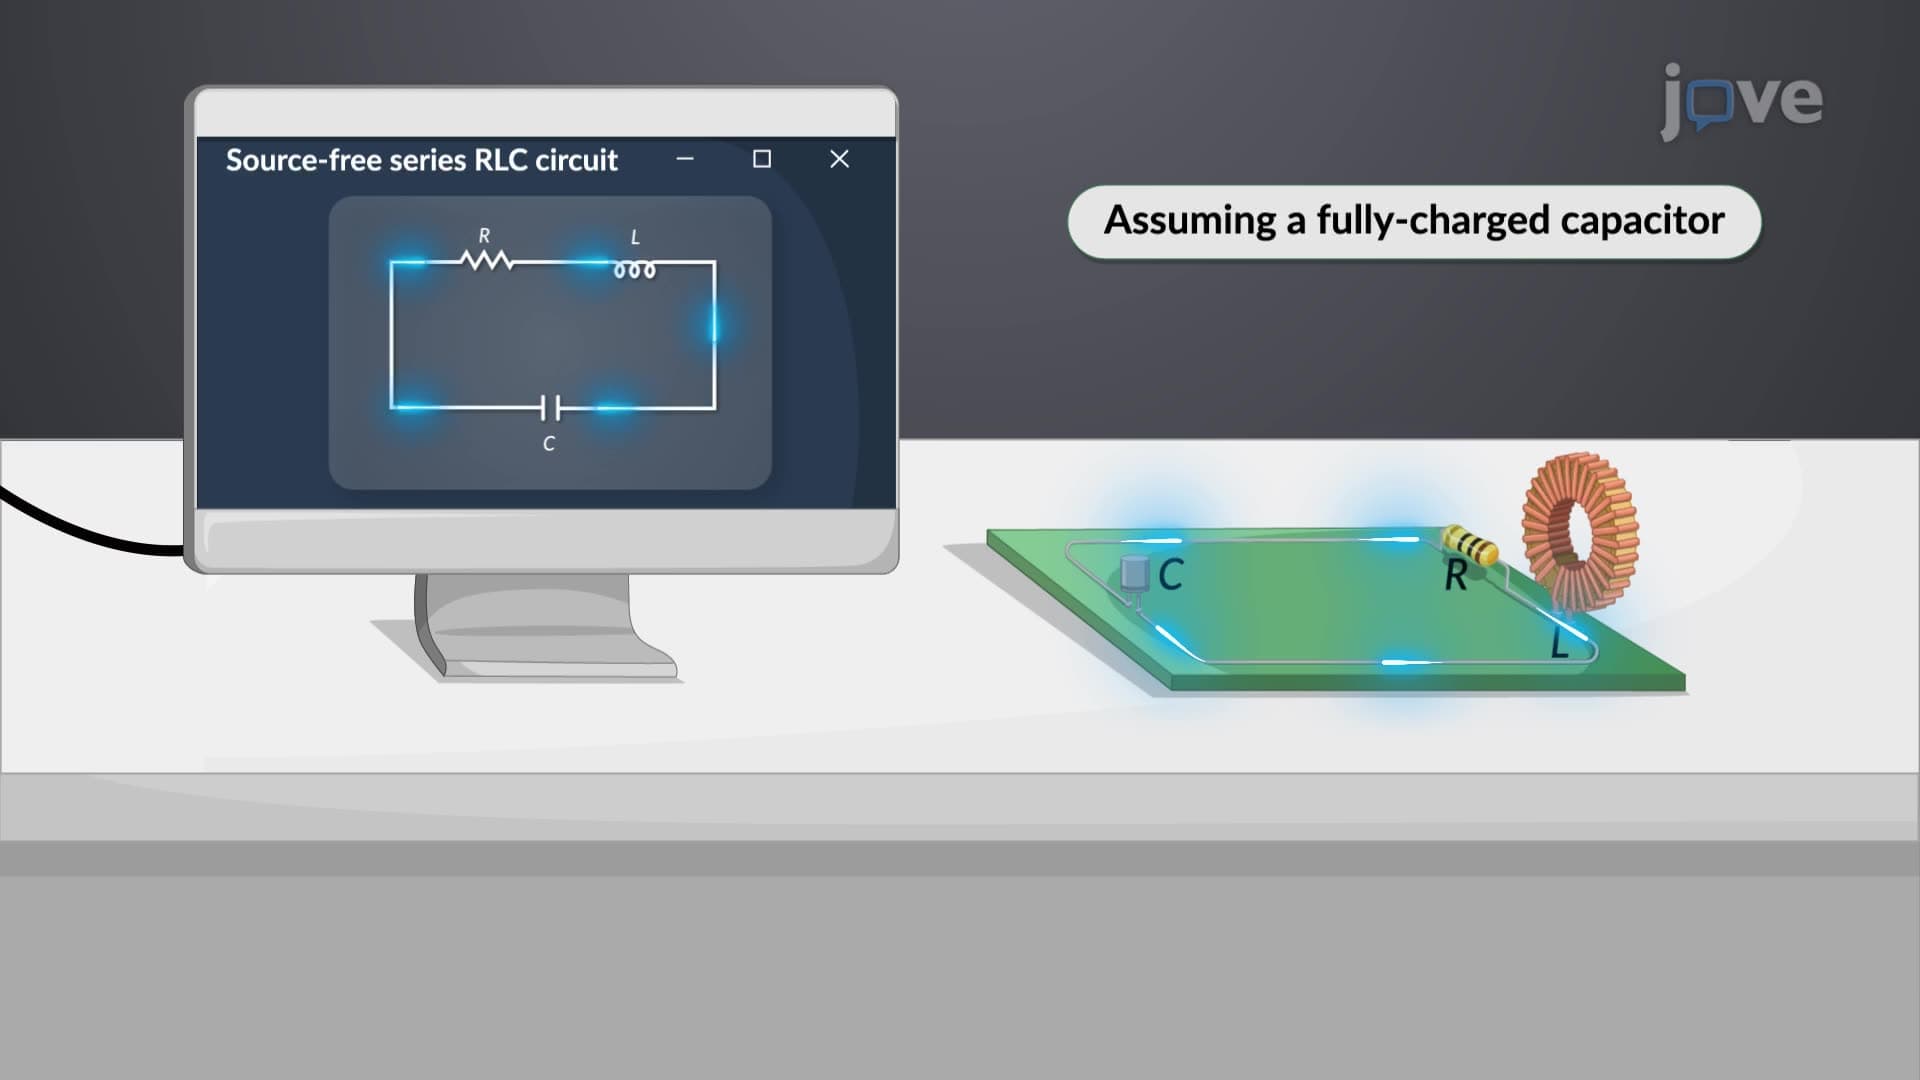
A second-order differential equation characterizes a source-free series RLC circuit, marking its distinct mathematical representation. The complete solution of this equation is a blend of two unique solutions, each linked to the circuit's roots expressed in terms of the damping factor and resonant frequency.
2.1K
 01:26
Linear Approximation in Frequency Domain
407
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
407
 01:28
Stability
432
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
432
 01:18
Second Order systems II
440
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
440
 01:21
Linear Approximation in Time Domain
386
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
386