

测量地雷压力机动力学 通过增强的YOLOv8模型和数学建模来测量地雷压力机动力学
Rui Zhao1,2, Rong Cong1, Ruijie Zhou1
1College of Physical Education, Yunnan Agricultural University, Kunming 650201, China.
Sensors (Basel, Switzerland)
|February 27, 2026

概括
一个新的基于视觉的系统准确地测量了没有物理传感器的地雷压力动力学. 这种非接触式方法为力量训练和研究提供了传统线性位置传感器 (LPT) 的可靠替代方案.
科学领域:
- 生物力学 生物力学
- 计算机视觉 计算机视觉
- 体育科学 运动科学 运动科学
背景情况:
- 地雷压力是一个关键的上体强度评估,但当前的监测工具,如线性位置传感器 (LPTs) 有局限性.
- LPTs需要物理附件,使用专有软件,并且由于传感器漂移和噪音,在高负载下可能不准确.
研究的目的:
- 开发和验证一种无标记,无接触,基于视觉的系统,用于测量地雷压力运动.
- 为了克服传统的LPTs在评估上半身推力方面的限制.
主要方法:
- 开发了一个基于视觉的系统,使用了增强的YOLOv8-OBB模型,具有极化自我注意力机制,C3k2模块和SPPF结构.
- 集成了一个数学建模框架来计算地雷压力集中阶段的动力学指标.
- 在247个试验中,对视觉系统的测量与线性位置传感器 (LPT) 设备 (GymAware) 进行了比较,用于各种负载 (20-35公斤).
主要成果:
- 视觉系统实现了高检测准确度 (mAP@0.5的0.995) 的杆目标.
- 在视觉系统和LPT之间发现了强烈的相关性 (r > 0.85),用于峰值速度,平均速度,峰值功率和平均功率.
- 视觉系统在高负载下显示出与LPTs相似的稳定性,并显示出可预测的速度高估.
结论:
- 开发的基于视觉的系统为监测地雷压力动力学提供了可靠和实用的替代方案.
- 这种非接触式方法比LPT具有优势,特别是在高负载条件下减轻与传感器相关的错误.
- 该系统适用于力量训练应用和需要准确的动力学数据的科学研究.
更多相关视频
 08:24
Sit-to-stand-and-walk from 120% Knee Height: A Novel Approach to Assess Dynamic Postural Control Independent of Lead-limb
Published on: August 30, 2016
10.8K
 07:43
In Vivo Quantification of Hip Arthrokinematics during Dynamic Weight-bearing Activities using Dual Fluoroscopy
Published on: July 2, 2021
3.7K
相关概念视频
 01:17
Kinematic Equations - II
15.5K
The second kinematic equation expresses the final position of an object in terms of its initial position, the distance traveled with the initial constant velocity, and the distance traveled due to a change in velocity. Similar to the first kinematic equation, this equation is also only valid when the acceleration is constant throughout the motion of an object.
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
15.5K
 01:18
Kinematic Equations - III
12.3K
The first two kinematic equations have time as a variable, but the third kinematic equation is independent of time. This equation expresses final velocity as a function of the acceleration and distance over which it acts. The fourth kinematic equation does not have an acceleration term and provides the final position of the object at time t in terms of the initial and final velocities. This equation is useful when the value of the constant acceleration is unknown.
Using the kinematic equations,...
Using the kinematic equations,...
12.3K
 01:26
Kinematic Equations - I
17.1K
When an object moves with constant acceleration, the velocity of the object changes at a constant rate throughout the motion. The kinematic equations of motions are derived for such cases where the acceleration of the object is constant. The first kinematic equation gives an insight into the relationship between velocity, acceleration, and time. We can see, for example:
17.1K
 01:15
Kinematic Equations: Problem Solving
29.5K
When analyzing one-dimensional motion with constant acceleration, the problem-solving strategy involves identifying the known quantities and choosing the appropriate kinematic equations to solve for the unknowns. Either one or two kinematic equations are needed to solve for the unknowns, depending on the known and unknown quantities. Generally, the number of equations required is the same as the number of unknown quantities in the given example. Two-body pursuit problems always require two...
29.5K
 01:30
Kinematic Equations for Rotation
935
In mechanics, when one observes a rigid body in rotational motion with constant angular acceleration, it is possible to establish equations for its rotational kinematics. This process resembles how linear kinematics are dealt with in simpler motion studies.
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
935
 01:14
Mechanical Efficiency of Real Machines
1.4K
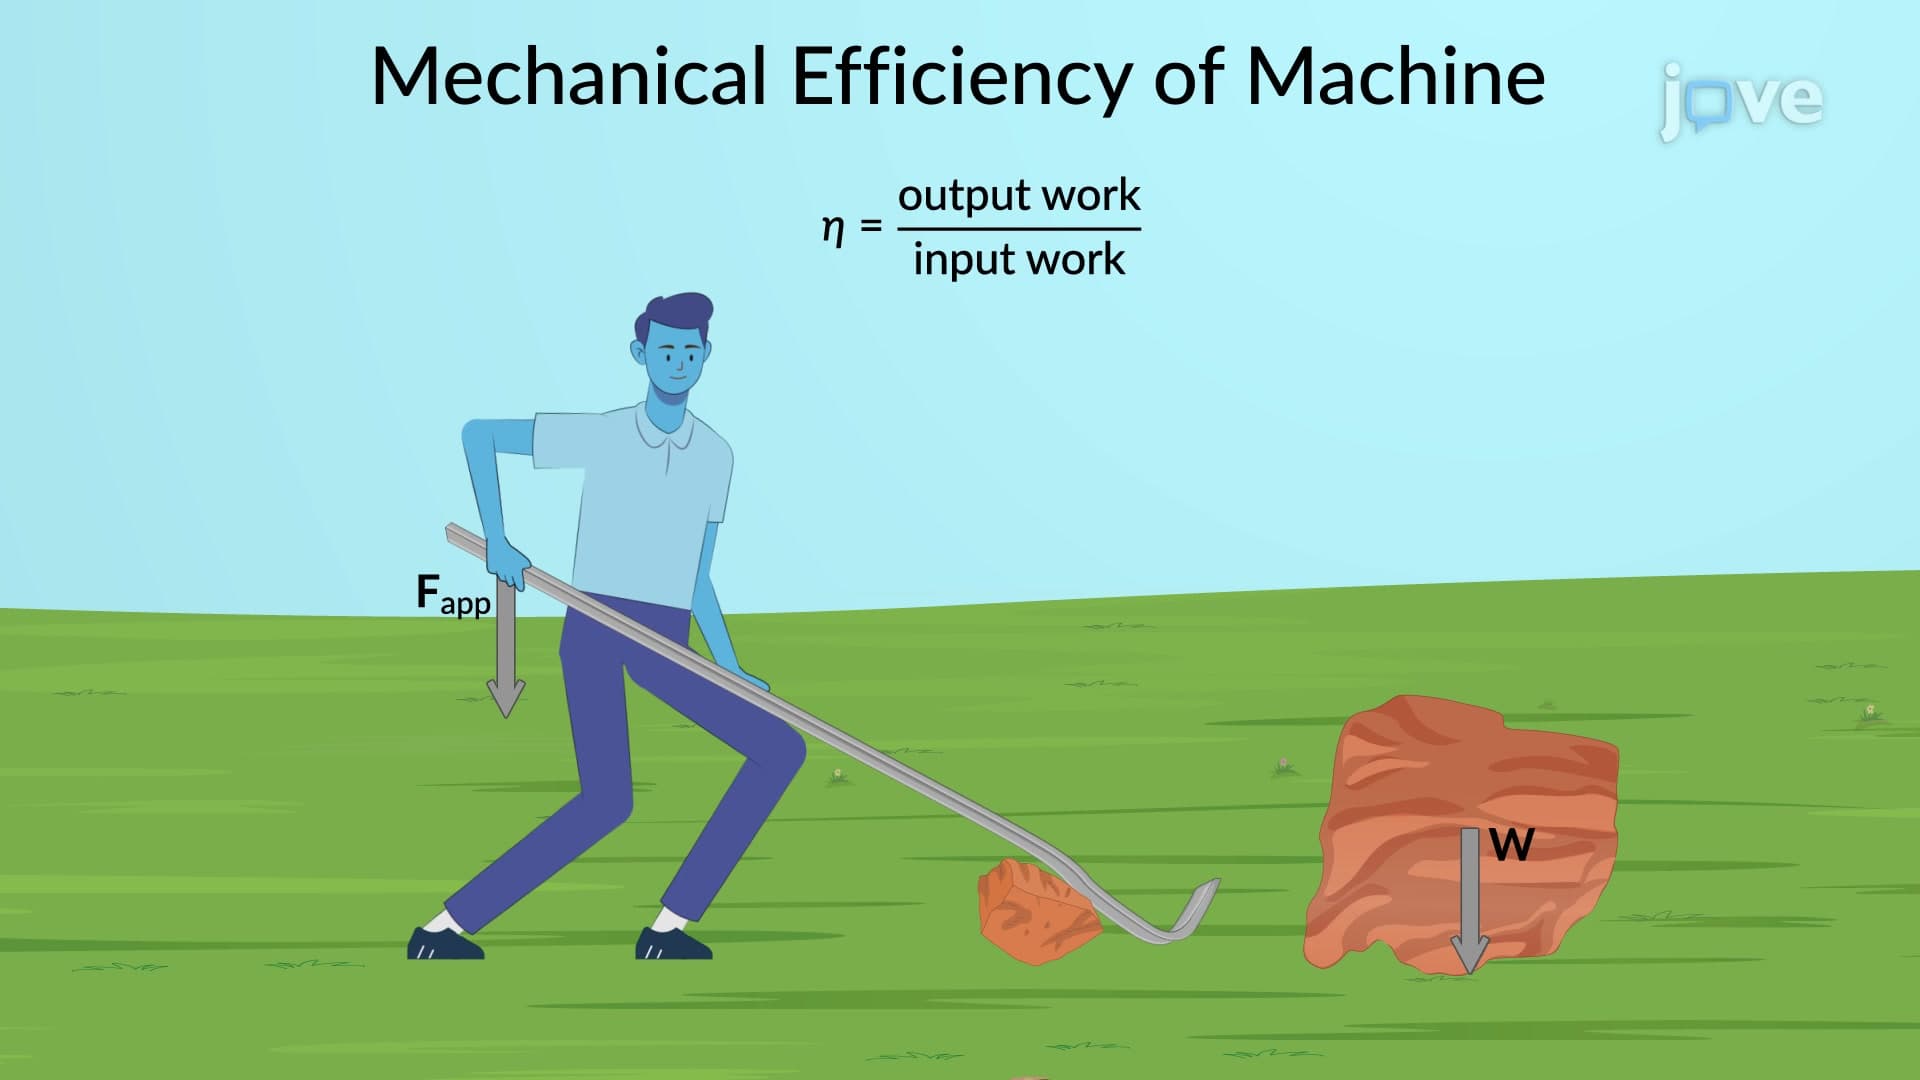
The mechanical efficiency of a machine is a fundamental concept that describes how effectively a machine can convert input work into output work. According to this concept, the efficiency of a machine is equal to the ratio of the output work to the input work. An ideal machine, meaning a machine that has no energy losses, has an efficiency of one. This implies that the input work and the output work are equal.
However, in reality, no machine can be truly ideal, and all of them experience some...
However, in reality, no machine can be truly ideal, and all of them experience some...
1.4K