
使用强化学习模型的刚性合多体机器人的模糊自适应非线性MIMO控制
Chenxu Duan1, Luwen Wang2, Shuangcen Li3
1School of Intelligent Manufacturing, Sichuan University Jinjiang College, Meishan, 620860, Sichuan, China. chasel_duan@163.com.
Scientific reports
|March 1, 2026

概括
本研究介绍了一种新的自适应MIMO控制,用于使用强化学习和海星优化算法 (SFOA) 的机器人. 它增强机器人运动稳定性和灵活性,防止干扰,以精确的轨迹跟踪.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制系统 控制系统
- 人工智能的人工智能
背景情况:
- 机器人等机械系统具有多个自由度 (DOF),对工业和日常生活至关重要.
- 由于合,未知的动态和外部干扰,这些系统的准确表征具有挑战性,限制了传统基于模型的控制.
- 现有的控制方法与现实世界的机器人应用程序的复杂性作斗争.
研究的目的:
- 为机器人和机器人手臂开发一种自适应的MIMO (多输入多输出) 控制方法.
- 提高面临环境不确定性和干扰的机器人系统的稳定性,灵活性和实时性能.
- 在复杂的机器人系统中实现快速而精确的轨迹跟踪.
主要方法:
- 开发了一个基于强化学习的自适应MIMO控制策略.
- 结合海星优化算法 (SFOA),模糊增强学习和有限时间收原则.
- 利用联合空间建模来管理方程和四边形建模来实施控制策略.
- 动态适应,实时学习和即时反被纳入一个多变量反架构.
主要成果:
- 拟议的控制策略在模拟中表现出色.
- 这种方法提高了机器人在干扰下运动的稳定性和灵活性.
- 实现了快速而精确的轨迹跟踪,展示了更好的实时性能,准确性和稳定性.
- 在具有两度和五度自由度的机器人上成功测试.
结论:
- 基于强化学习的自适应MIMO控制有效地解决了机器人系统表征和控制方面的挑战.
- 集成SFOA,模糊增强学习和有限时间融合为复杂的机器人任务提供了强大的解决方案.
- 开发的控制策略提供了卓越的实时性能,准确性和稳定性,使其适用于关键应用.

相关概念视频
 01:17
Open and closed-loop control systems
1.8K
Control systems are foundational elements in automation and engineering. They are broadly categorized into open-loop and closed-loop systems. These classifications hinge on the presence or absence of feedback mechanisms, significantly influencing the system's performance, complexity, and application.
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal...
1.8K
 01:26
Feedback control systems
746
Feedback control systems are categorized in various ways based on their design, analysis, and signal types.
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
746
 01:21
Rigid Body Equilibrium Problems - II
8.1K
A rigid body is in static equilibrium when the net force and the net torque acting on the system are equal to zero.
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
Consider two children sitting on a seesaw, which has negligible mass. The first child has a mass (m1) of 26 kg and sits at point A, which is 1.6 meters (r1) from the pivot point B; the second child has a mass (m2) of 32 kg and sits at point C. How far from the pivot point B should the second child sit (r2) to balance the seesaw?
8.1K
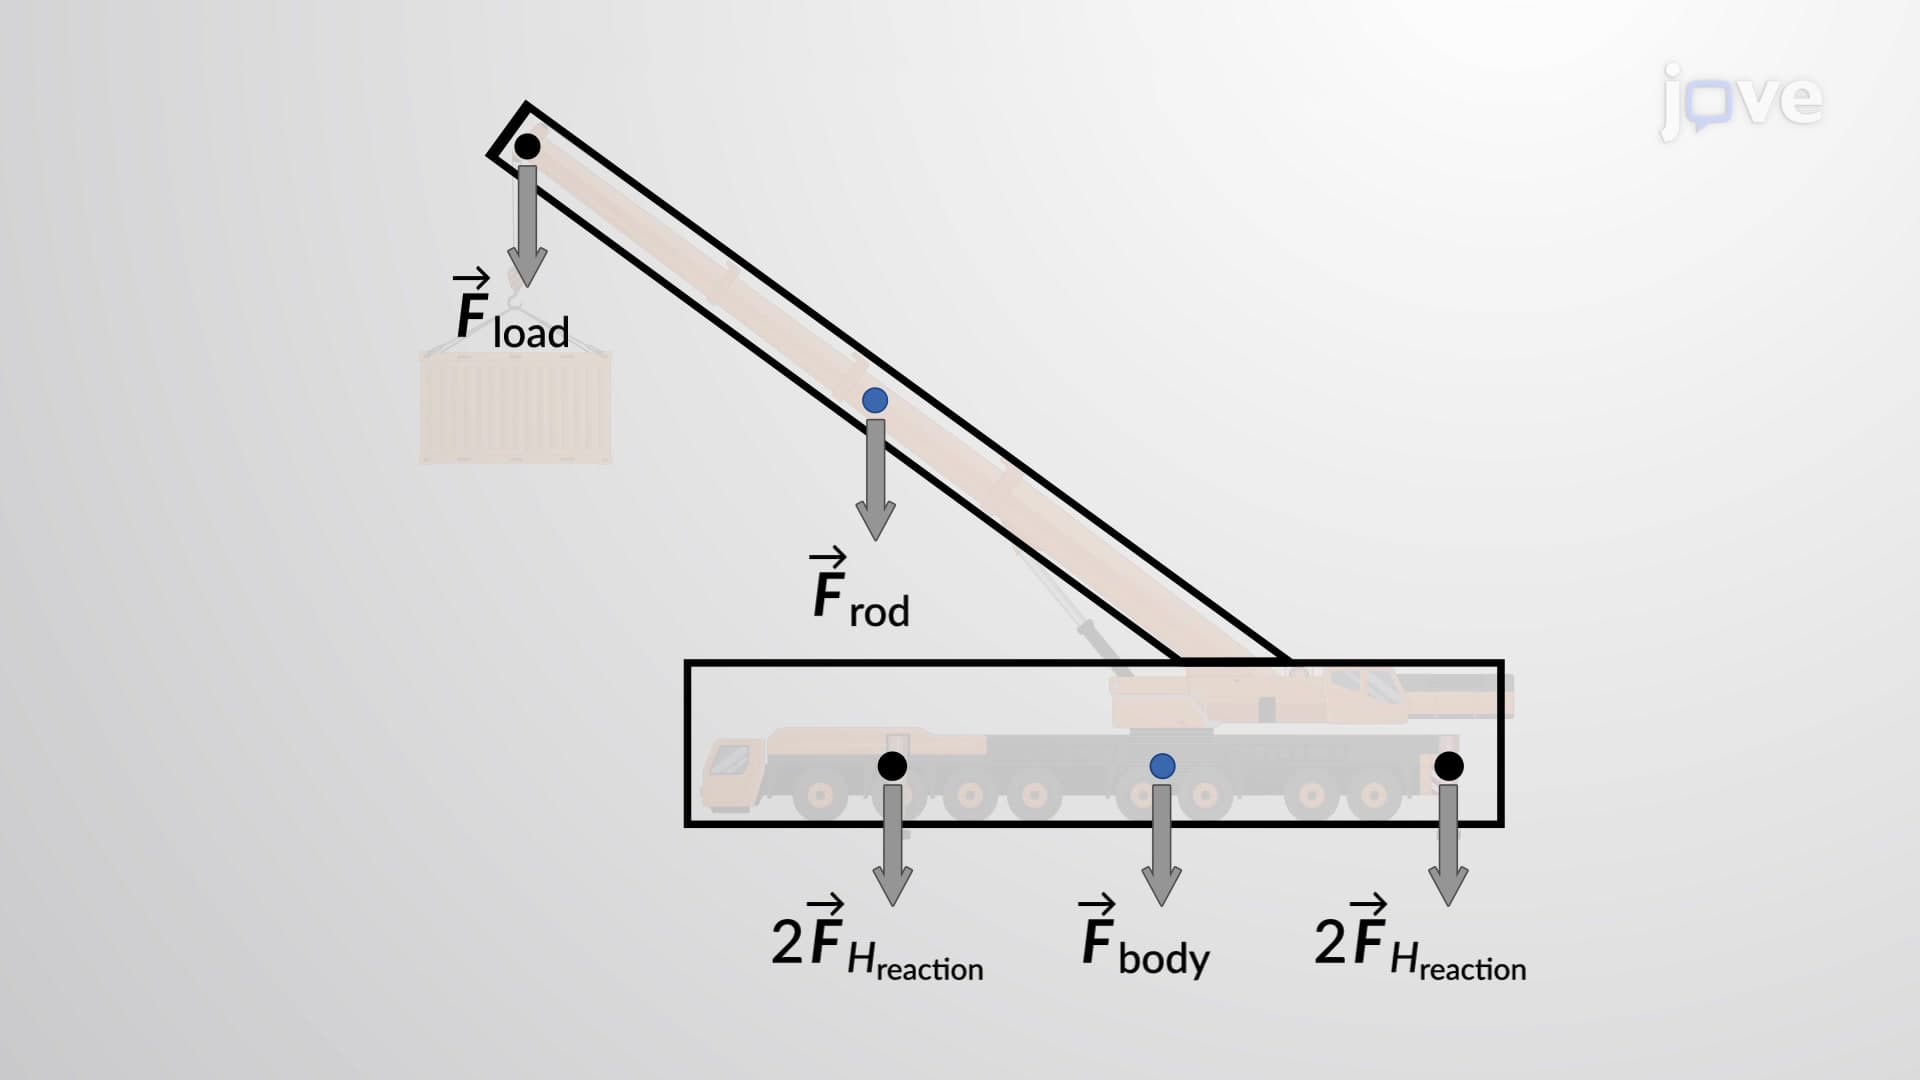 00:49
Rigid Body Equilibrium Problems - I
5.6K
A rigid body is said to be in static equilibrium when the net force and the net torque acting on the system is equal to zero. To solve for rigid body equilibrium problems, do the following steps.
5.6K
 01:24
One-Degree-of-Freedom System
879
In mechanical engineering, one-degree-of-freedom systems form the basis of a wide range of electrical and mechanical components. Using these models, engineers can predict the behavior of various parts in a larger system, which gives them insight into how different forces interact with each other.
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
879
 01:30
Three-Dimensional Force System:Problem Solving
1.4K
A three-dimensional force system refers to a scenario in which three forces act simultaneously in three different directions. This type of problem is commonly encountered in physics and engineering, where it is necessary to calculate the resultant force on the system, which can then be used to predict or analyze the behavior of the object or structure under consideration.
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
To solve a three-dimensional force system, first resolve each force into its respective scalar components. Do this using...
1.4K