
在损失的量子通道上进行私人远程相位估计
Farzad Kianvash1, Marco Barbieri2,3,4, Matteo Rosati1
1Università degli Studi Roma Tre, Dipartimento di Ingegneria Civile, Informatica e delle Tecnologie Aeronautiche, Via della Vasca Navale 79, 00146 Rome, Italy.
Physical review letters
|March 1, 2026

概括
这项研究引入了一种使用连续变量状态的新私人远程量子传感协议. 现实的通道建模显著提高了估计参数的准确性,并确保了对敌人的隐私.
科学领域:
- 量子信息科学 量子信息科学
- 量子通信是一种量子通信.
- 量子传感器是一种量子传感器.
背景情况:
- 私人远程量子传感旨在通过量子通道远距离估计参数,平衡估计性能与信息泄漏.
- 没有特定的道模型,估计性能的现有限制是松散的,阻碍了实际应用.
- 连续变量 (CV) 状态为增强的量子传感协议提供了潜力.
研究的目的:
- 提出和分析一种使用连续变量状态的新型私人远程量子传感协议.
- 在现实的通道条件下量化协议的估计错误和隐私.
- 展示现实的通道建模的好处,以提高传感性能和安全性.
主要方法:
- 开发一个单用户私人遥感协议,具有连续变量状态.
- 在一类丢失量子通道攻击下分析协议性能.
- 量子通信工具的应用用于计算估计误差和隐私.
- 在非对称 (多通道使用) 和有限大小的系统中进行调查.
主要成果:
- 拟议的协议有效地估计了参数,同时限制了信息泄露.
- 现实的道模型假设导致更严格的估计误差和隐私量化.
- 这种方法的好处在非对称和有限大小的场景中都很明显.
- 道模型的测量数据验证提高了边界的可靠性.
结论:
- 连续变量状态适用于私人远程量子传感.
- 现实的道建模对于精确的量子传感性能评估至关重要.
- 开发的协议为量子通信网络中安全的参数估计提供了实际优势.
相关概念视频
 00:59
Propagation of Uncertainty from Random Error
2.0K
An experiment often consists of more than a single step. In this case, measurements at each step give rise to uncertainty. Because the measurements occur in successive steps, the uncertainty in one step necessarily contributes to that in the subsequent step. As we perform statistical analysis on these types of experiments, we must learn to account for the propagation of uncertainty from one step to the next. The propagation of uncertainty depends on the type of arithmetic operation performed on...
2.0K
 01:05
Estimation of the Physical Quantities
8.3K
On many occasions, physicists, other scientists, and engineers need to make estimates of a particular quantity. These are sometimes referred to as guesstimates, order-of-magnitude approximations, back-of-the-envelope calculations, or Fermi calculations. The physicist Enrico Fermi was famous for his ability to estimate various kinds of data with surprising precision. Estimating does not mean guessing a number or a formula at random. Instead, estimation means using prior experience and sound...
8.3K
 01:21
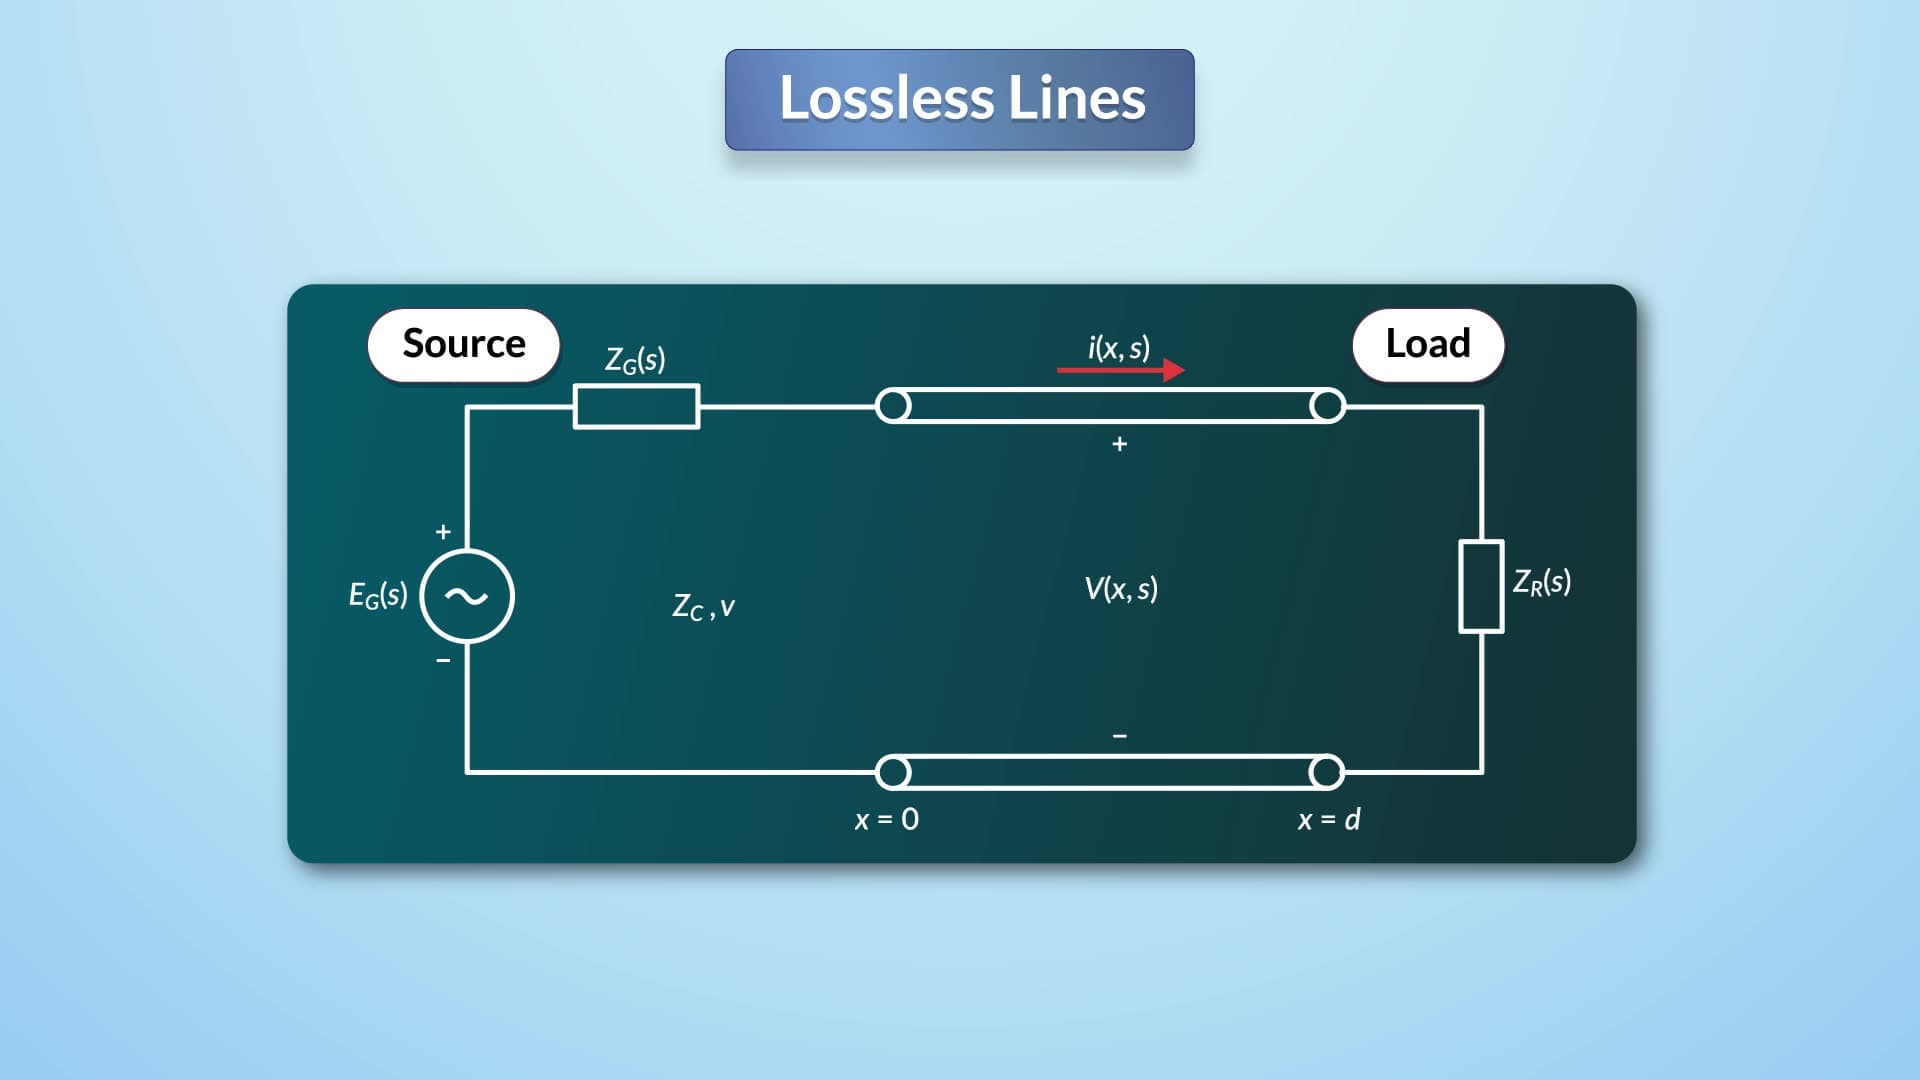
Boundary Conditions: Lossless Lines
449
Consider a single-phase, two-wire, lossless transmission line terminated by an impedance at the receiving end and a source with Thevenin voltage and impedance at the sending end. The line, with length, has a surge impedance and wave velocity determined by the line's inductance and capacitance.
At the receiving end, the boundary condition states that the voltage equals the product of the receiving-end impedance and current. This relationship is expressed as a function of the incident and...
At the receiving end, the boundary condition states that the voltage equals the product of the receiving-end impedance and current. This relationship is expressed as a function of the incident and...
449
 01:21
Time and frequency -Domain Interpretation of Phase-lag Control
429
Phase-lag controllers are widely used in control systems to improve stability and reduce steady-state errors. A dimmer switch controlling the brightness of a light bulb serves as a practical example of phase-lag control, gradually adjusting the bulb's brightness. Mathematically, phase-lag control or low-pass filtering is represented when the factor 'a' is less than 1.
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
Phase-lag controllers do not place a pole at zero, but instead influence the steady-state error by amplifying any...
429
 01:21
Linear Approximation in Time Domain
386
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
386
 01:26
Linear Approximation in Frequency Domain
409
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
409