OptimalCap:在自由环境中高效和强大的基于LiDAR的动作捕捉

概括
OptimalCap为真实世界的场景提供了基于LiDAR的强大的人类运动捕捉. 这个框架实现了准确的,实时的多人跟踪,即使在杂的环境中,设置了一个新的标准.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 计算机视觉 计算机视觉
- 生物机械工程 生物机械工程
背景情况:
- 基于LiDAR的人类运动捕捉对于大规模,不受约束的设置是有希望的.
- 现有的方法与杂的数据和动态场景作斗争,限制了实际使用.
- 需要强大而高效的激光雷达运动捕捉解决方案.
研究的目的:
- 开发一个强大而高效的基于LiDAR的框架,用于准确的,实时的多人运动捕获.
- 引入一个大规模的合成数据集,用于训练和评估在噪音环境中的运动捕捉.
- 为了建立一个新的标准,可扩展的,现实世界的基于激光雷达的动作捕捉.
主要方法:
- 拟议的OptimalCap框架整合了层次结构骨架建模.
- 采用动态意识的时间优化,以实现连贯的运动捕捉.
- 介绍了NoiseMotion,一个合成数据集,模拟在噪音条件下的人物对象交互.
主要成果:
- OptimalCap实现了最先进的准确性,稳定性和时间一致性.
- 该框架支持超过20个同时被捕的个人.
- 在60 FPS的实时性能,达到100米的范围.
结论:
- OptimalCap在基于LiDAR的人类运动捕捉方面取得了重大进展.
- 该框架在具有挑战性,杂和动态的环境中非常有效.
- OptimalCap为可扩展和实用的现实世界运动捕捉应用程序设定了一个新的基准.
相关概念视频
 01:24
Absolute Motion Analysis- General Plane Motion
639
Visualize a drone, with its propellers spinning rapidly, hovering mid-air. The fascinating movements and operations of this drone can be comprehended by applying the principle of general plane motion.
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
As the drone's propellers rotate, an upward force is generated that counteracts the force of gravity, enabling the drone to lift off from the ground. This initial movement of the drone is along a straight path, representing a form of translational motion. In this phase, every point on the...
639
 01:25
Relative Motion Analysis using Rotating Axes
1.0K
Consider a component AB undergoing a linear motion. Along with a linear motion, point B also rotates around point A. To comprehend this complex movement, position vectors for both points A and B are established using a stationary reference frame.
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it...
1.0K
 01:22
Planar Rigid-Body Motion
1.3K
Understanding the movement of a rigid body in planar motion involves recognizing that every particle within this body is traversing a path that maintains a consistent distance from a specific plane. This concept is fundamental in the study of physics and mechanical engineering, and it allows us to comprehend better how objects move in space.
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
Planar motion is typically divided into three distinct categories. The first is rectilinear translation, demonstrated by a subway train that moves along...
1.3K
 01:24
Relative Motion Analysis - Velocity
864
A stroke engine has a slider-crank mechanism that converts rotational motion from the crank into linear motion of the slider or vice versa. This mechanism consists of three main parts: the crank, the connecting rod, and the slider.
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
When an external force is exerted, it sets the crank into a rotational movement. This, in turn, instigates the motion of the connecting rod, leading to what is referred to as a general plane motion. This process involves two key points - point A on the connecting rod...
864
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
805
Consider a crane whose telescopic boom rotates with an angular velocity of 0.04 rad/s and angular acceleration of 0.02 rad/s2. Along with the rotation, the boom also extends linearly with a uniform speed of 5 m/s. The extension of the boom is measured at point D, which is measured with respect to the fixed point C on the other end of the boom. For the given instant, the distance between points C and D is 60 meters.
Here, in order to determine the magnitude of velocity and acceleration for point...
Here, in order to determine the magnitude of velocity and acceleration for point...
805
 01:15
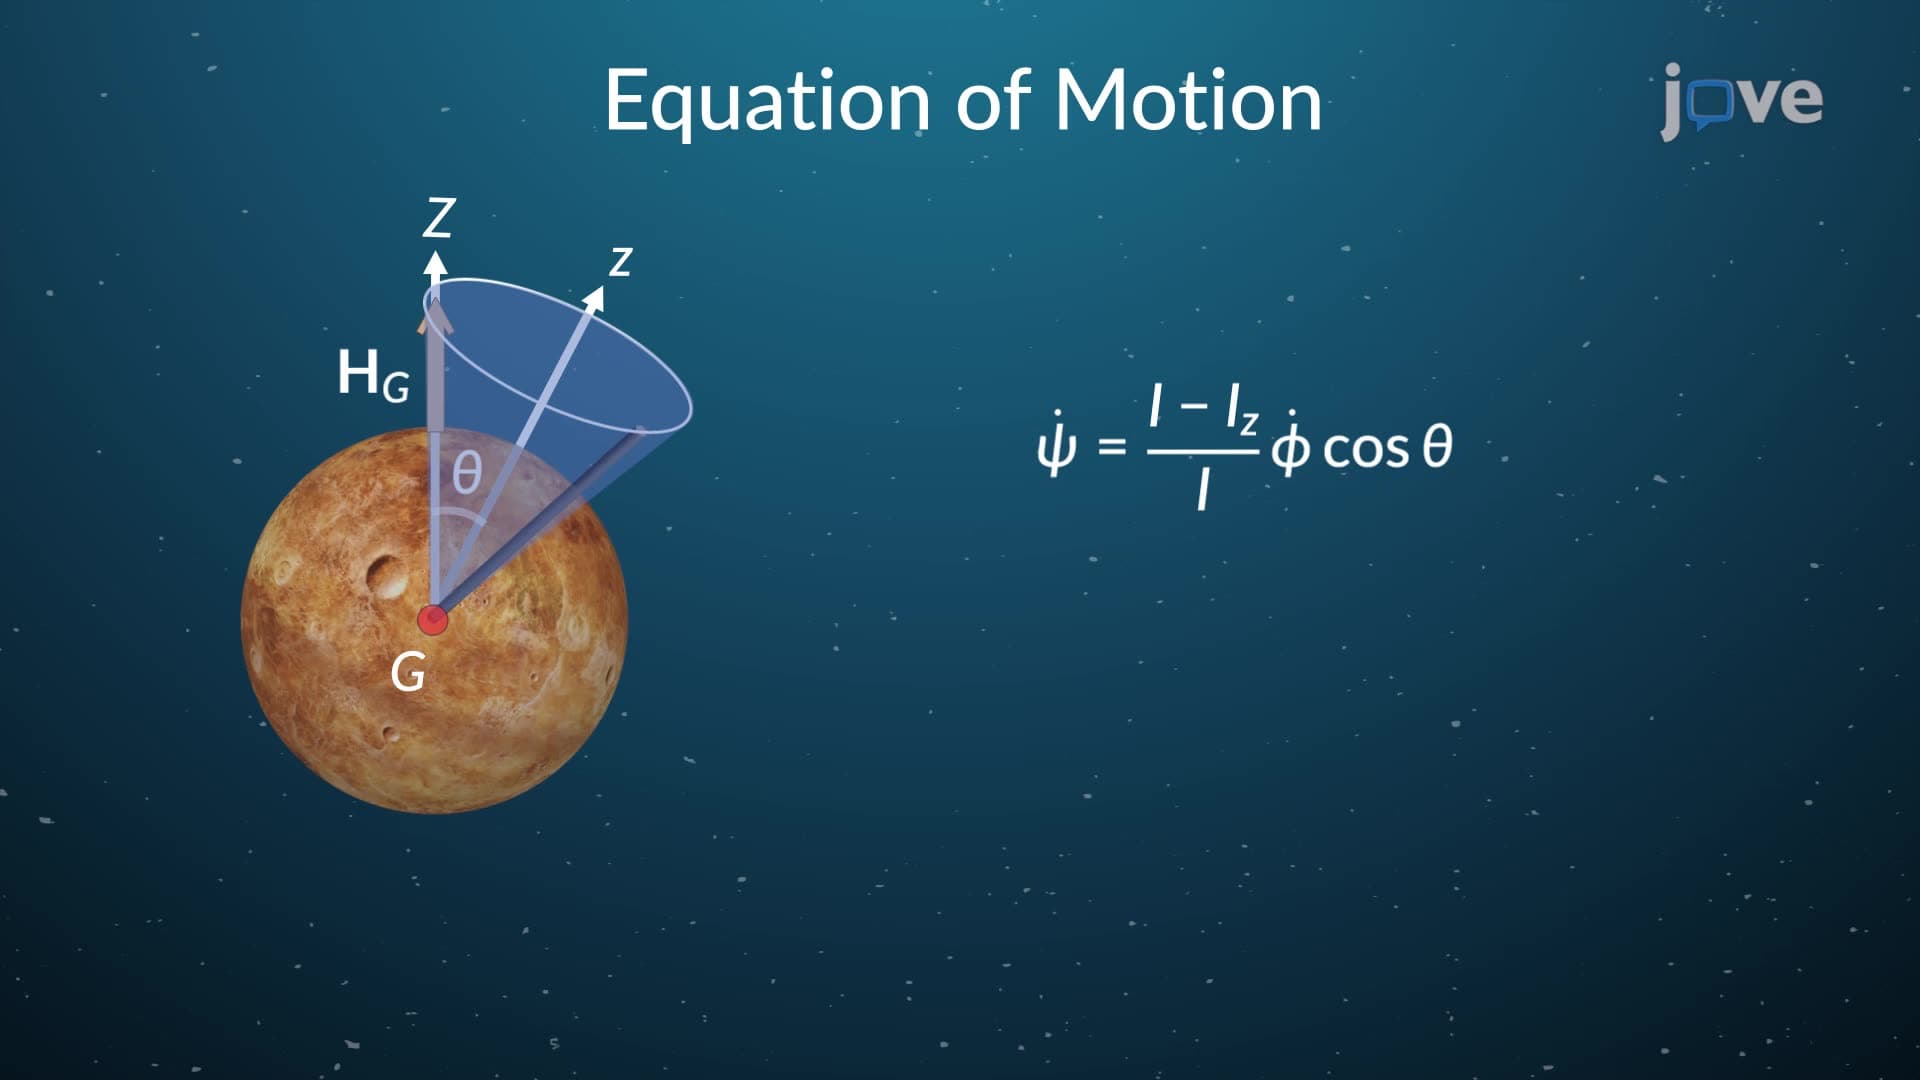
Torque Free Motion
897
The torque-free motion refers to the movement of a rigid body in space when no external torques are acting upon it. This type of motion can be observed in environments where there are no external forces or frictions, like in outer space. For example, a rotation of Mars in space is a torque-free motion. Mars is an axisymmetric object, meaning it has an axis of symmetry along which it rotates, designated as the z-axis. The rotating frame of reference is defined such that the center of mass of...
897