对于所需的可变阻抗模型的放松状态独立稳定性约束
Zhaobao Yu1, Jianheng Mao1, Liaoxue Liu1
1School of Automation, Nanjing University of Science and Technology, Nanjing, 210094, China.
ISA transactions
|March 7, 2026

概括
可变阻抗控制 (VIC) 增强了机器人任务,但时间变化的参数可能会导致不稳定. 本研究为所需的可变阻抗模型 (DVIM) 引入了新的,不那么保守的稳定性约束,以确保在各种条件下系统的稳定性.
科学领域:
- 机器人技术 机器人技术 机器人技术
- 控制理论 控制理论
- 系统稳定性 系统稳定性
背景情况:
- 可变阻抗控制 (VIC) 对于先进的机器人应用至关重要.
- 在VIC中时间变化的阻抗参数可能导致系统不稳定.
- 现有的稳定性约束通常是保守的,并限制了适用性.
研究的目的:
- 对所需的可变阻抗模型 (DVIM) 进行研究并推导出新的稳定性约束.
- 开发适用于一般阻抗矩阵的不那么保守的约束.
- 在外部力量和错误的存在下确保系统的稳定性和稳健性.
主要方法:
- 在非自主系统中利用一种不变性理论.
- 导出两个放松的独立于状态的全球均指数稳定性 (GUES) 约束.
- 使用输入到状态稳定性 (ISS) 框架.
主要成果:
- 为DVIM提出了两个新的,不那么保守的GUES约束.
- 第一个约束允许非严格的不平等.
- 第二个约束适用于非正确的确定的/可差分的和无限制的刚度变化率.
结论:
- 拟议的约束保证了有限的DVIM状态在有限的外力下.
- 具有这些限制的VIC框架证明了对跟踪和测量错误的稳定性.
- 模拟和实验结果验证了衍生约束的有效性.
更多相关视频
 12:30
Electric Cell-substrate Impedance Sensing for the Quantification of Endothelial Proliferation, Barrier Function, and Motility
Published on: March 28, 2014
61.3K
 11:25
A Millimeter Scale Flexural Testing System for Measuring the Mechanical Properties of Marine Sponge Spicules
Published on: October 11, 2017
9.8K
相关概念视频
 01:24
Pole and System Stability
1.1K
The transfer function is a fundamental concept representing the ratio of two polynomials. The numerator and denominator encapsulate the system's dynamics. The zeros and poles of this transfer function are critical in determining the system's behavior and stability.
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
1.1K
 01:28
Stability
434
The time response of a linear time-invariant (LTI) system can be divided into transient and steady-state responses. The transient response represents the system's initial reaction to a change in input and diminishes to zero over time. In contrast, the steady-state response is the behavior that persists after the transient effects have faded.
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
434
 01:26
Constraints and Statical Determinacy
1.0K
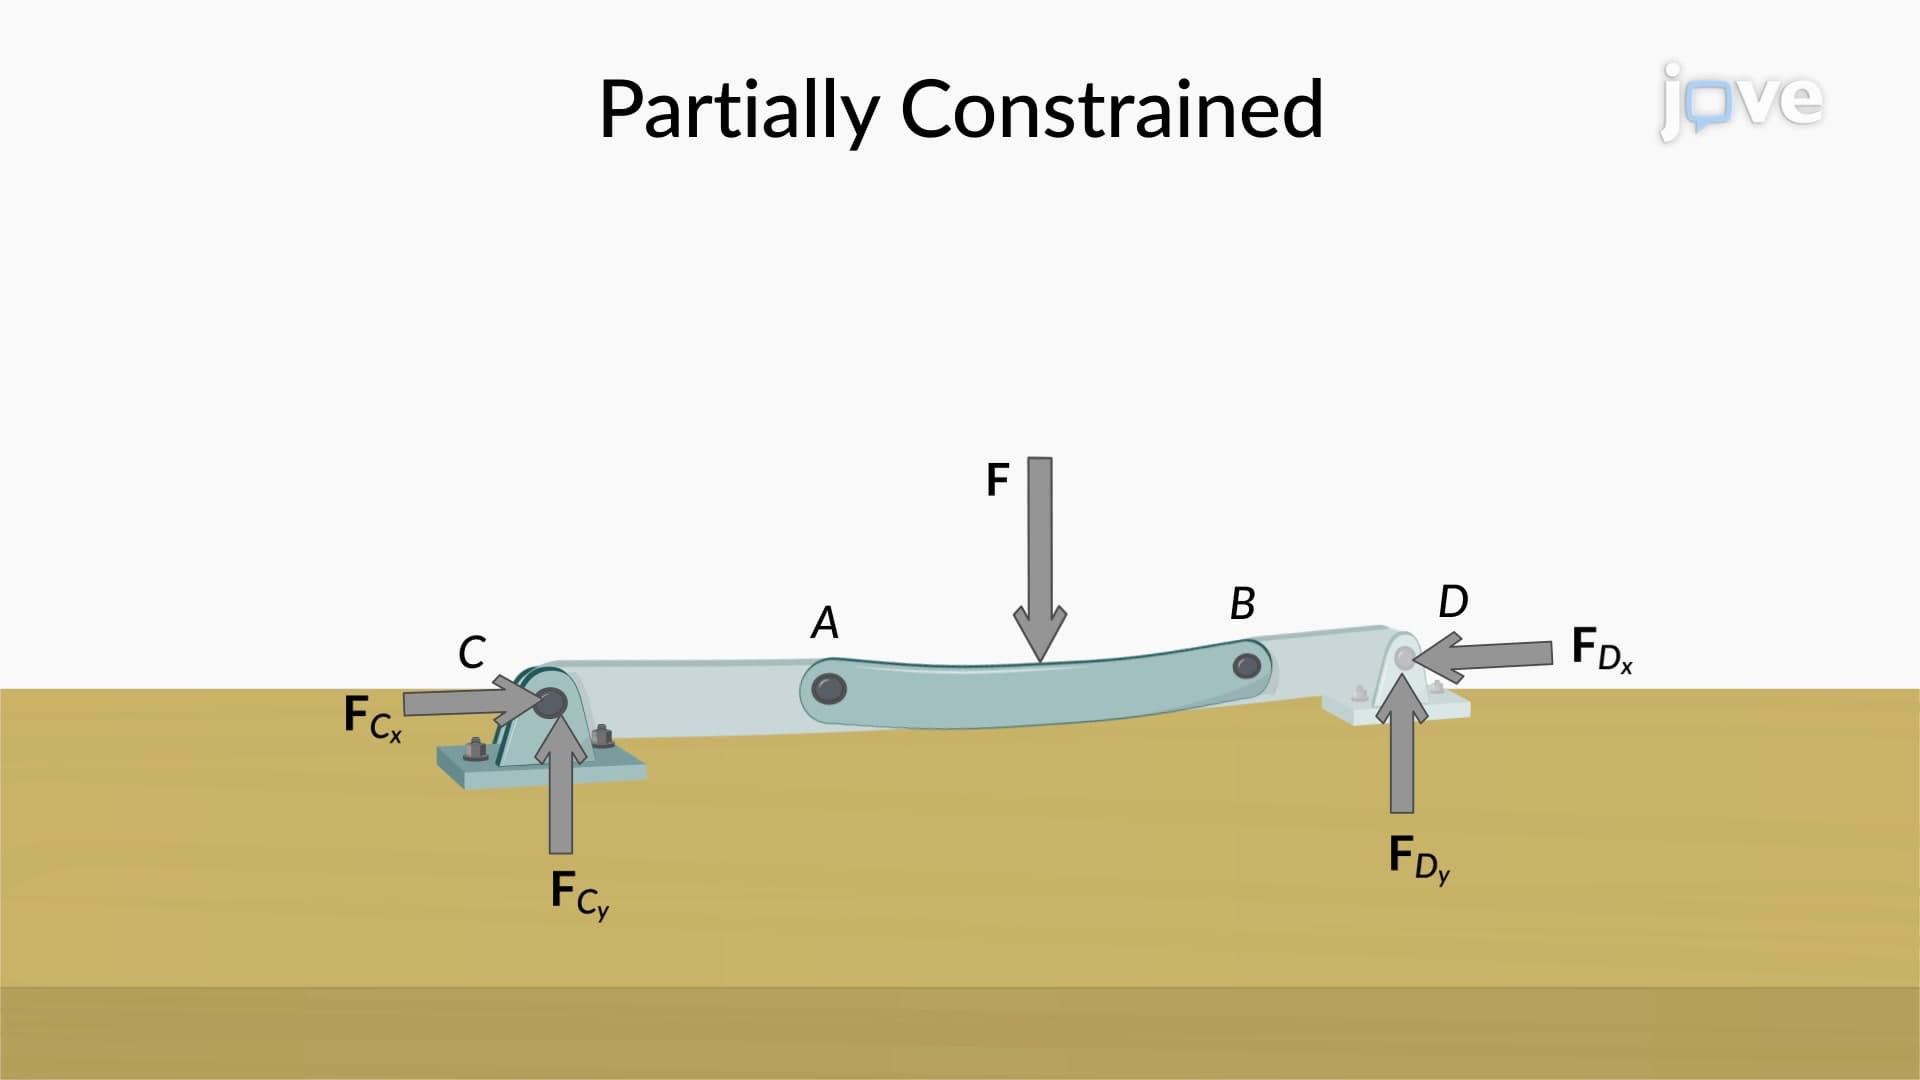
In structural engineering, the equilibrium of a system is not only determined by its equations of equilibrium but also with the help of constraints. Constraints refer to restrictions on the motion of a system. The proper combinations of constraints can minimize the total number of constraints needed to maintain a system in mechanical equilibrium. When this happens, the system is said to be statically determinate. For such systems, the unknown reaction supports can be estimated using equilibrium...
1.0K
 01:25
Multimachine Stability
600
Multimachine stability analysis is crucial for understanding the dynamics and stability of power systems with multiple synchronous machines. The objective is to solve the swing equations for a network of M machines connected to an N-bus power system.
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
In analyzing the system, the nodal equations represent the relationship between bus voltages, machine voltages, and machine currents. The nodal equation is given by:
600
 01:14
Stability of structures
553
In mechanical engineering, the stability of systems under various forces is critical for designing durable and efficient structures. One fundamental way to explore these concepts is by analyzing systems like two rods connected at a pivot point, O, with a torsional spring of spring constant k at the pivot point. This system is similar in appearance to a scissor jack used to change tires on a car. In this case, the arms of the linkage (equivalent to the rods in this system) are entirely vertical,...
553
 01:24
BIBO stability of continuous and discrete -time systems
1.0K
System stability is a fundamental concept in signal processing, often assessed using convolution. For a system to be considered bounded-input bounded-output (BIBO) stable, any bounded input signal must produce a bounded output signal. A bounded input signal is one where the modulus does not exceed a certain constant at any point in time.
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
1.0K