
改变手臂物理参数对人类伸展运动的最小扭矩变化轨迹的影响
Kotaro Muramatsu1, Takahiro Kagawa2, Naomichi Ogihara1
1Laboratory of Human Evolutionary Biomechanics, Department of Biological Sciences, Graduate School of Science, The University of Tokyo, 7-3-1 Hongo, Bunkyo-ku, 113-0033 Tokyo, Japan.
Cognitive neurodynamics
|March 9, 2026

概括
最小扭矩变化模型预测了直臂运动,但这项研究发现,当臂特性发生变化时,曲线轨迹会变化. 这表明人类达到的运动依赖于对生物力学变异不那么敏感的标准.
科学领域:
- 生物力学 生物力学
- 计算神经科学是一种神经科学.
- 人类运动控制人体运动控制
背景情况:
- 最小扭矩变化模型通过计算解释了人类的伸展运动,并预测了直线轨迹.
- 这个模型的预测可能会受到手臂物理参数 (质量,惯性,粘度) 的变化的影响.
研究的目的:
- 调查手臂物理参数的变化如何影响最低扭矩变化标准预测的最佳手臂轨迹.
- 要确定最小扭矩变化标准是否对生物机械性质变化具有稳定性.
主要方法:
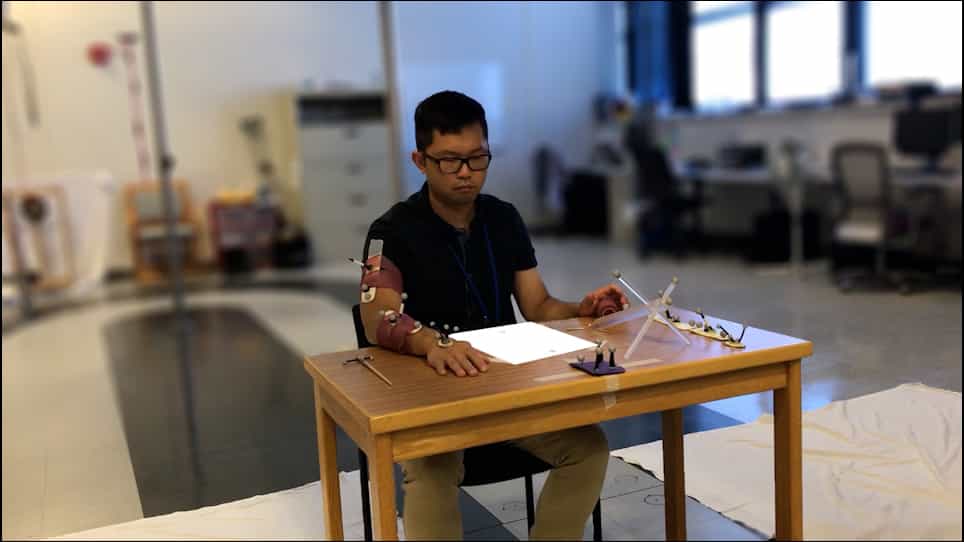
- 系统模拟到达运动.
- 在计算模型中修改手臂物理参数 (质量,惯性瞬间,粘度).
- 分析得到的手轨迹和速度概况.
主要成果:
- 改变前臂的物理参数 (翻倍或减半) 会导致显著曲的最佳轨迹.
- 修改参数以使其在生物机械上"更合适",也产生了曲线轨迹,与观察到的人类运动有所不同.
- 最小扭矩变化模型的预测对手臂物理性质的变化很敏感.
结论:
- 在人类伸手运动中,手的轨迹可能受到动态优化原理的控制,这种原理对生物机械性质变化不那么敏感.
- 仅仅是最小扭矩变化标准可能无法完全捕捉到人类达到轨迹形成的基本原则.
- 需要进一步的研究来确定人类运动控制的替代或补充优化标准.
相关概念视频
 01:10
Torque
23.2K
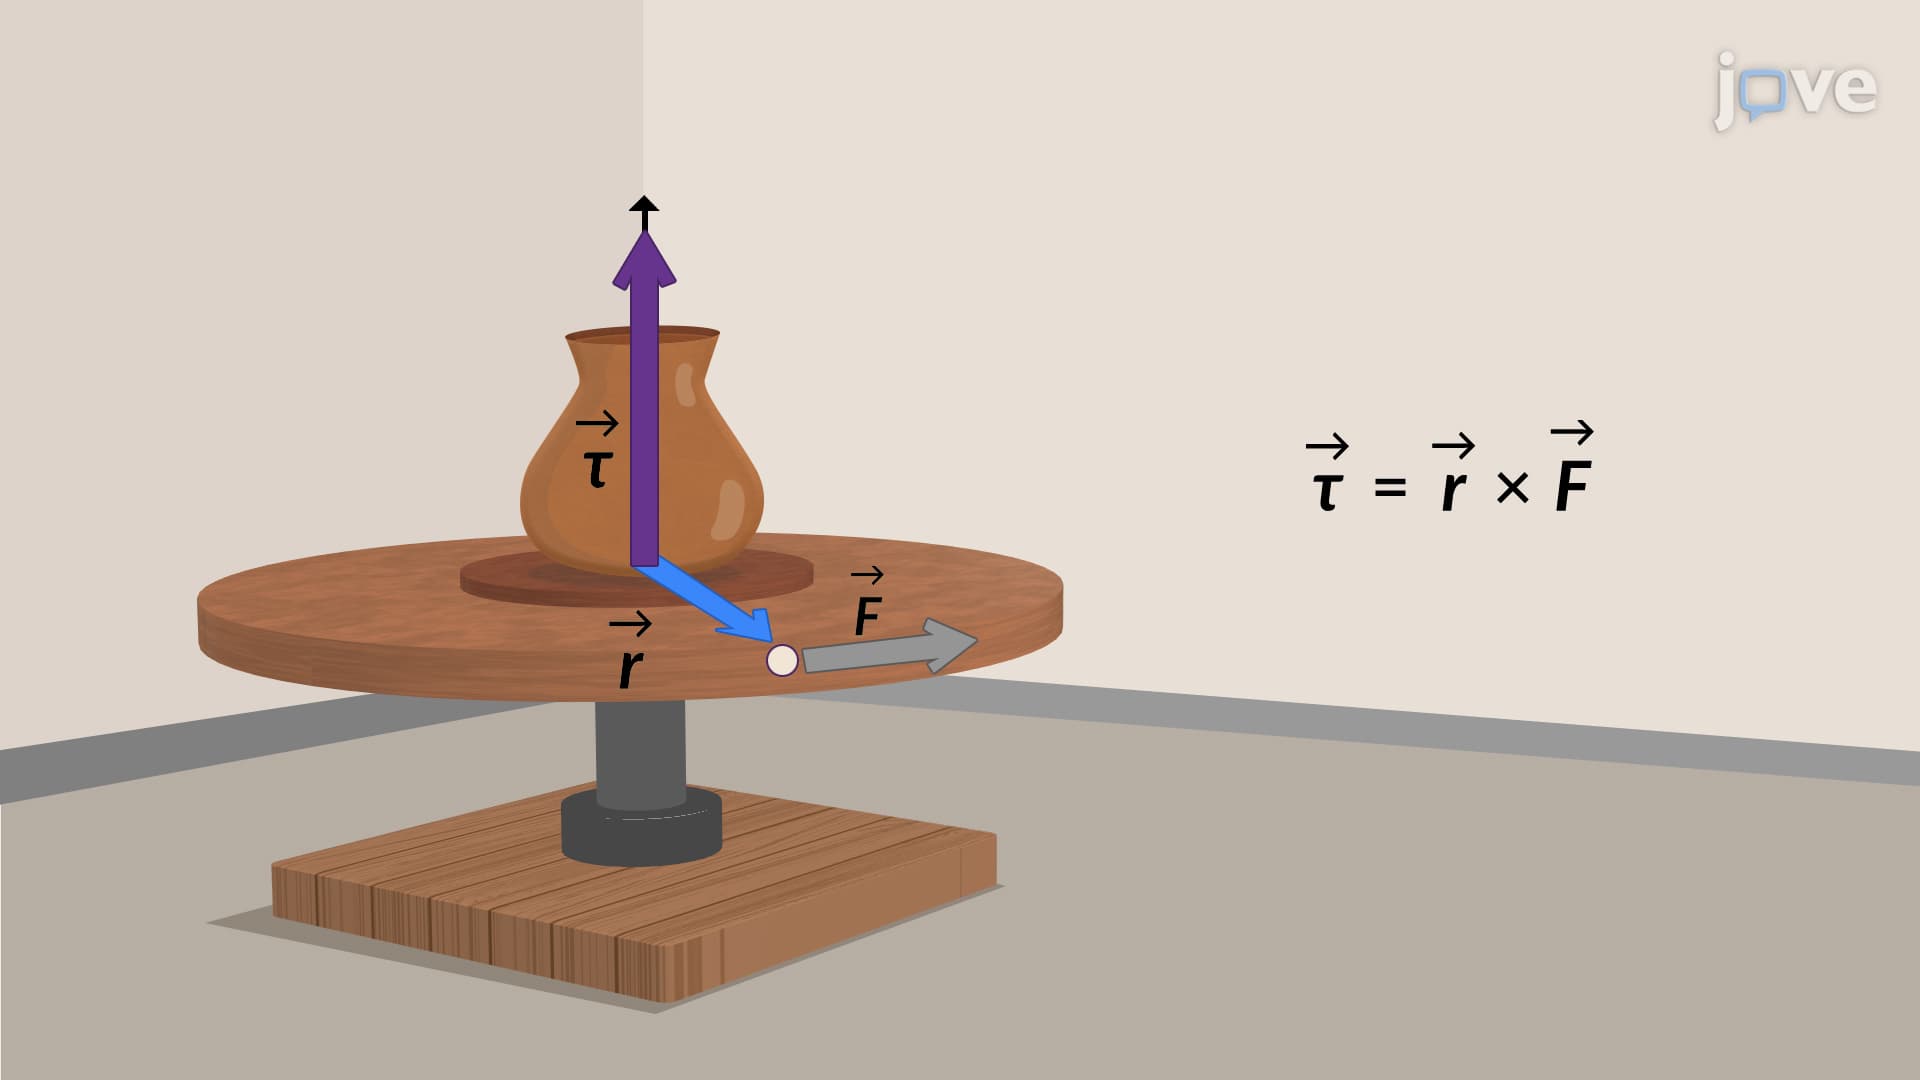
Torque is an important quantity for describing the dynamics of a rotating rigid body. We see the application of torque in many ways in the world, such as when pressing the accelerator in a car, which causes the engine to apply additional torque on the drivetrain. Here, we define torque and provide a framework to create an equation to calculate torque for a rigid body with fixed-axis rotation.
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
Torque can be considered as the rotational counterpart to force. Since forces change the translational...
23.2K
 01:19
Net Torque Calculations
11.9K
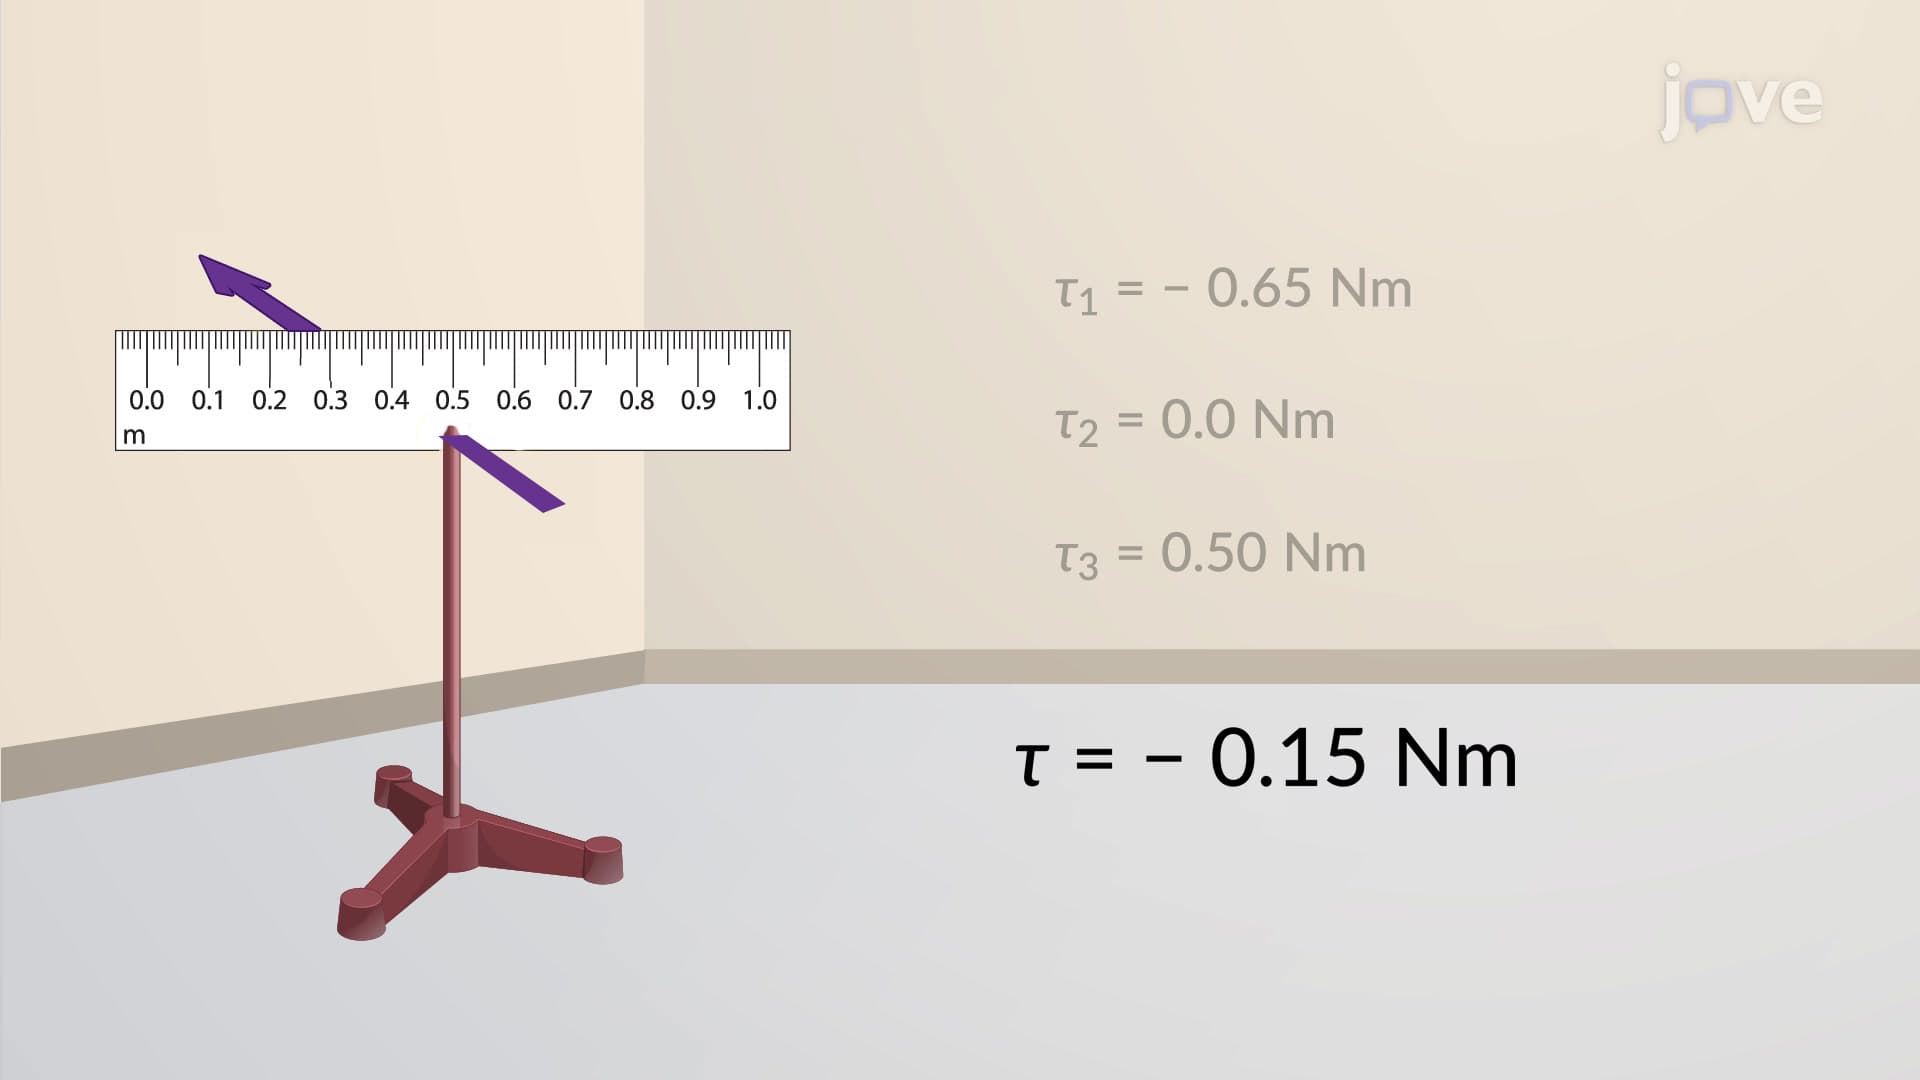
When a mechanic tries to remove a hex nut with a wrench, it is easier if the force is applied at the farthest end of the wrench handle. The lever arm is the distance from the pivot point (the hex nut in this case) to the person’s hand. If this distance is large, the torque is higher. Only the component of the force perpendicular to the lever arm contributes to the torque. Therefore, pushing the wrench perpendicular to the lever arm is more advantageous. If multiple people apply force to...
11.9K