
两个时间依赖系数的同时数值确定在二次抛物线方程中,具有非局部初始和边界条件
Mohammed A J Al-Shatrah1, Mohammed Sabah Hussein2
1Ministry of Education, Directorate of Education Thi Qar, Thi Qar, 64001, Iraq.
F1000Research
|March 9, 2026

概括
本研究提出了一个稳定的计算框架,用于识别抛物线偏微分方程中的未知系数. 该方法使用规范化来确保准确和可靠的结果,即使有杂的数据.
科学领域:
- 应用数学 应用数学 应用数学
- 数字分析 数字分析
- 计算科学 计算科学
背景情况:
- 专注于在1D抛物线部分微分方程中识别两个依赖时间的系数.
- 包含非局部的初始,边界和整体的过度决定条件.
研究的目的:
- 开发一个数学上一致和计算效率高的框架来解决反向问题.
- 在抛物线PDEs中同时识别未知的时间依赖系数.
主要方法:
- 使用Crank-Nicolson有限差异方法 (FDM) 解决直接问题,以获得稳定性和准确性.
- 反向问题被重新表述为非线性规范最小平方优化问题.
- 提霍诺夫正规化用于解决不良位置并增强数量稳定性.
主要成果:
- 数字实验在精确和杂的数据下证明了准确性和收性.
- 正规化有效地减少了重建错误,并减轻了振荡.
- 灵敏度分析突出了调整参数在平衡稳定性和准确性的作用.
结论:
- 拟议的方法为反向问题提供了一个准确且计算效率高的工具.
- 适用于传热,扩散过程和其他科学领域.
- 为未知系数提供可靠的回收,对于应用科学至关重要.
更多相关视频
 06:45
Design and Application of a Fault Detection Method Based on Adaptive Filters and Rotational Speed Estimation for an Electro-Hydrostatic Actuator
Published on: October 28, 2022
2.2K
 06:44
Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
658
相关概念视频
 01:21
Linear Approximation in Time Domain
387
Nonlinear systems often require sophisticated approaches for accurate modeling and analysis, with state-space representation being particularly effective. This method is especially useful for systems where variables and parameters vary with time or operating conditions, such as in a simple pendulum or a translational mechanical system with nonlinear springs.
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
387
 01:18
Second Order systems II
445
In an underdamped second-order system, where the damping ratio ζ is between 0 and 1, a unit-step input results in a transfer function that, when transformed using the inverse Laplace method, reveals the output response. The output exhibits a damped sinusoidal oscillation, and the difference between the input and output is termed the error signal. This error signal also demonstrates damped oscillatory behavior. Eventually, as the system reaches a steady state, the error diminishes to zero.
445
 01:27
Linear Differential Equations
130
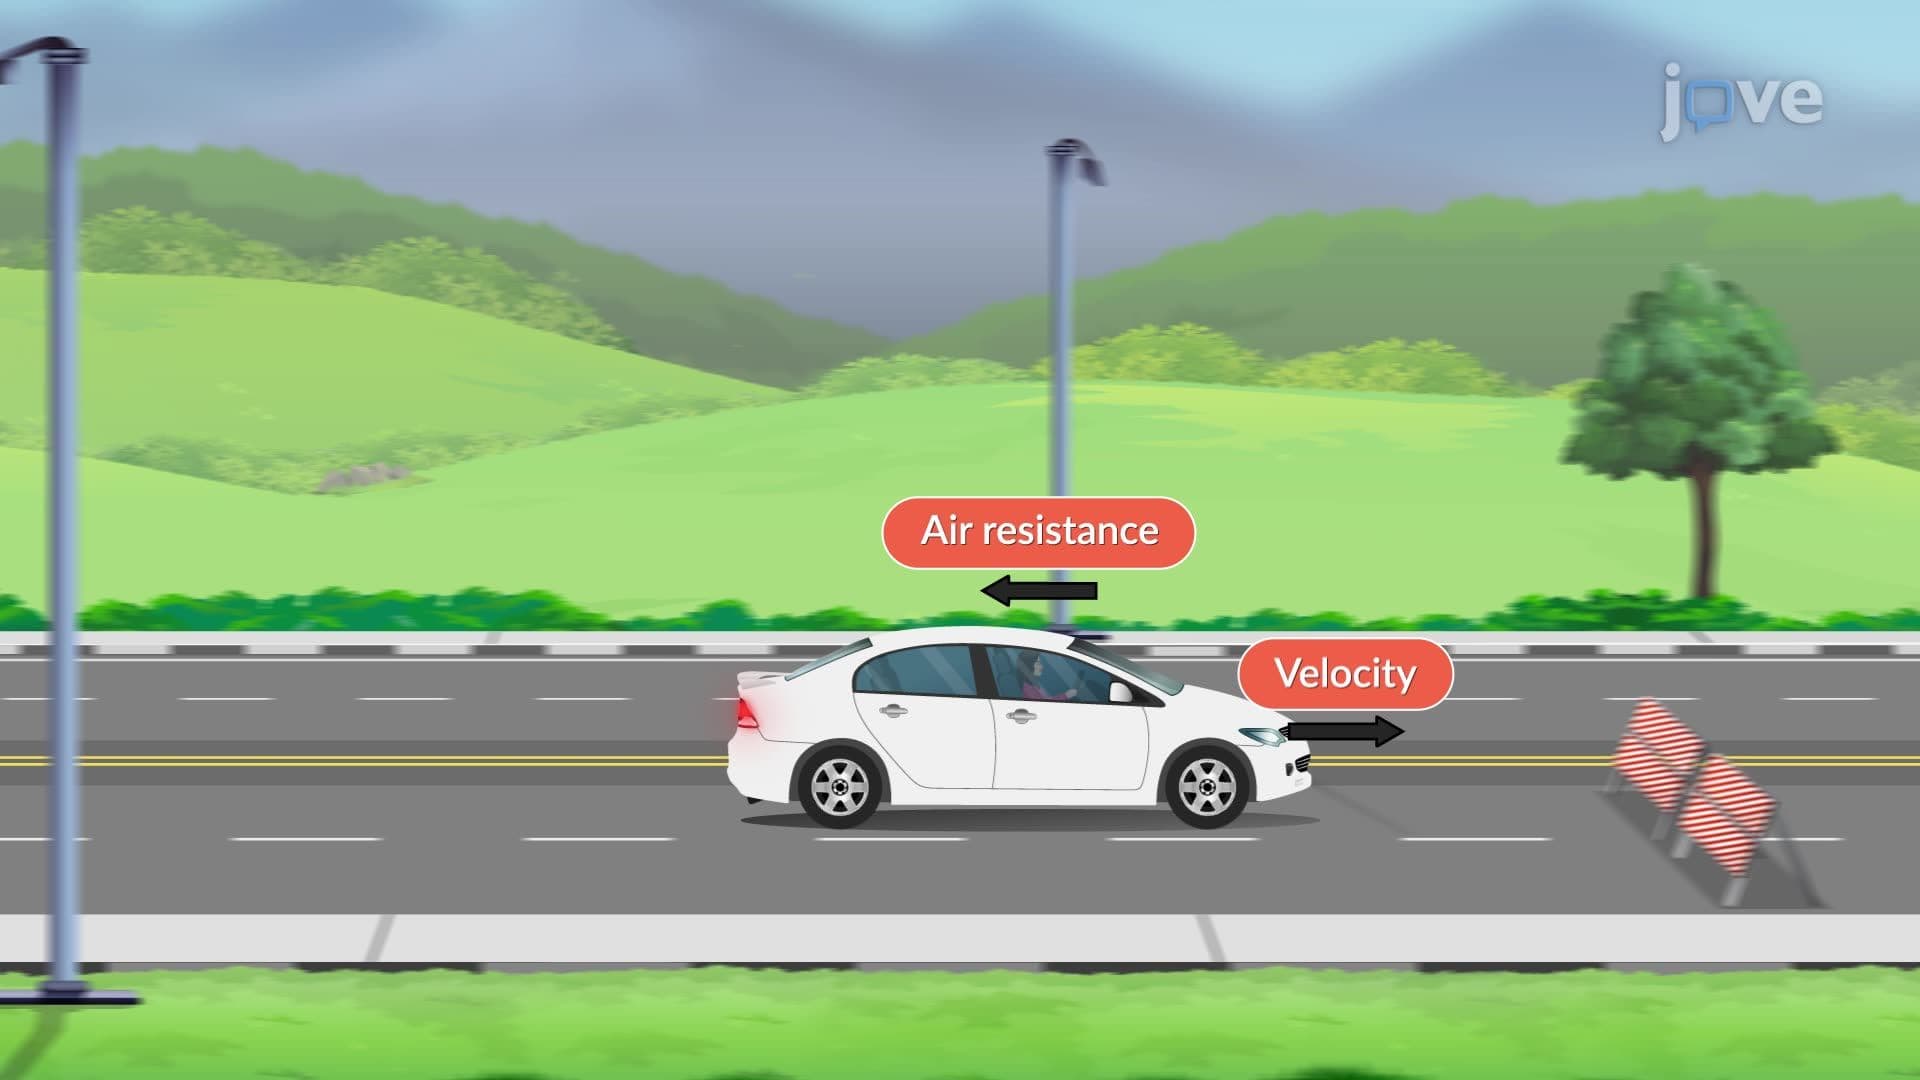
The integrating factor method provides a systematic way to solve first-order linear differential equations, especially those that cannot be handled by separation of variables. This method is particularly useful in modeling time-dependent physical systems influenced by both constant inputs and resistive forces. A common example is the motion of a car subjected to a constant engine force while experiencing air resistance proportional to its velocity.In such scenarios, Newton’s second law...
130
 01:20
Introduction to Differential Equations
188
A differential equation is a mathematical expression that establishes a relationship between a function and its derivatives. These equations are fundamental in modeling dynamic systems across various fields of science and engineering. The order of a differential equation is defined by the highest order derivative present in the equation. A first-order differential equation includes only the first derivative, while a second-order differential equation includes up to the second derivative of the...
188
 01:21
Differential Equations: Problem Solving
102
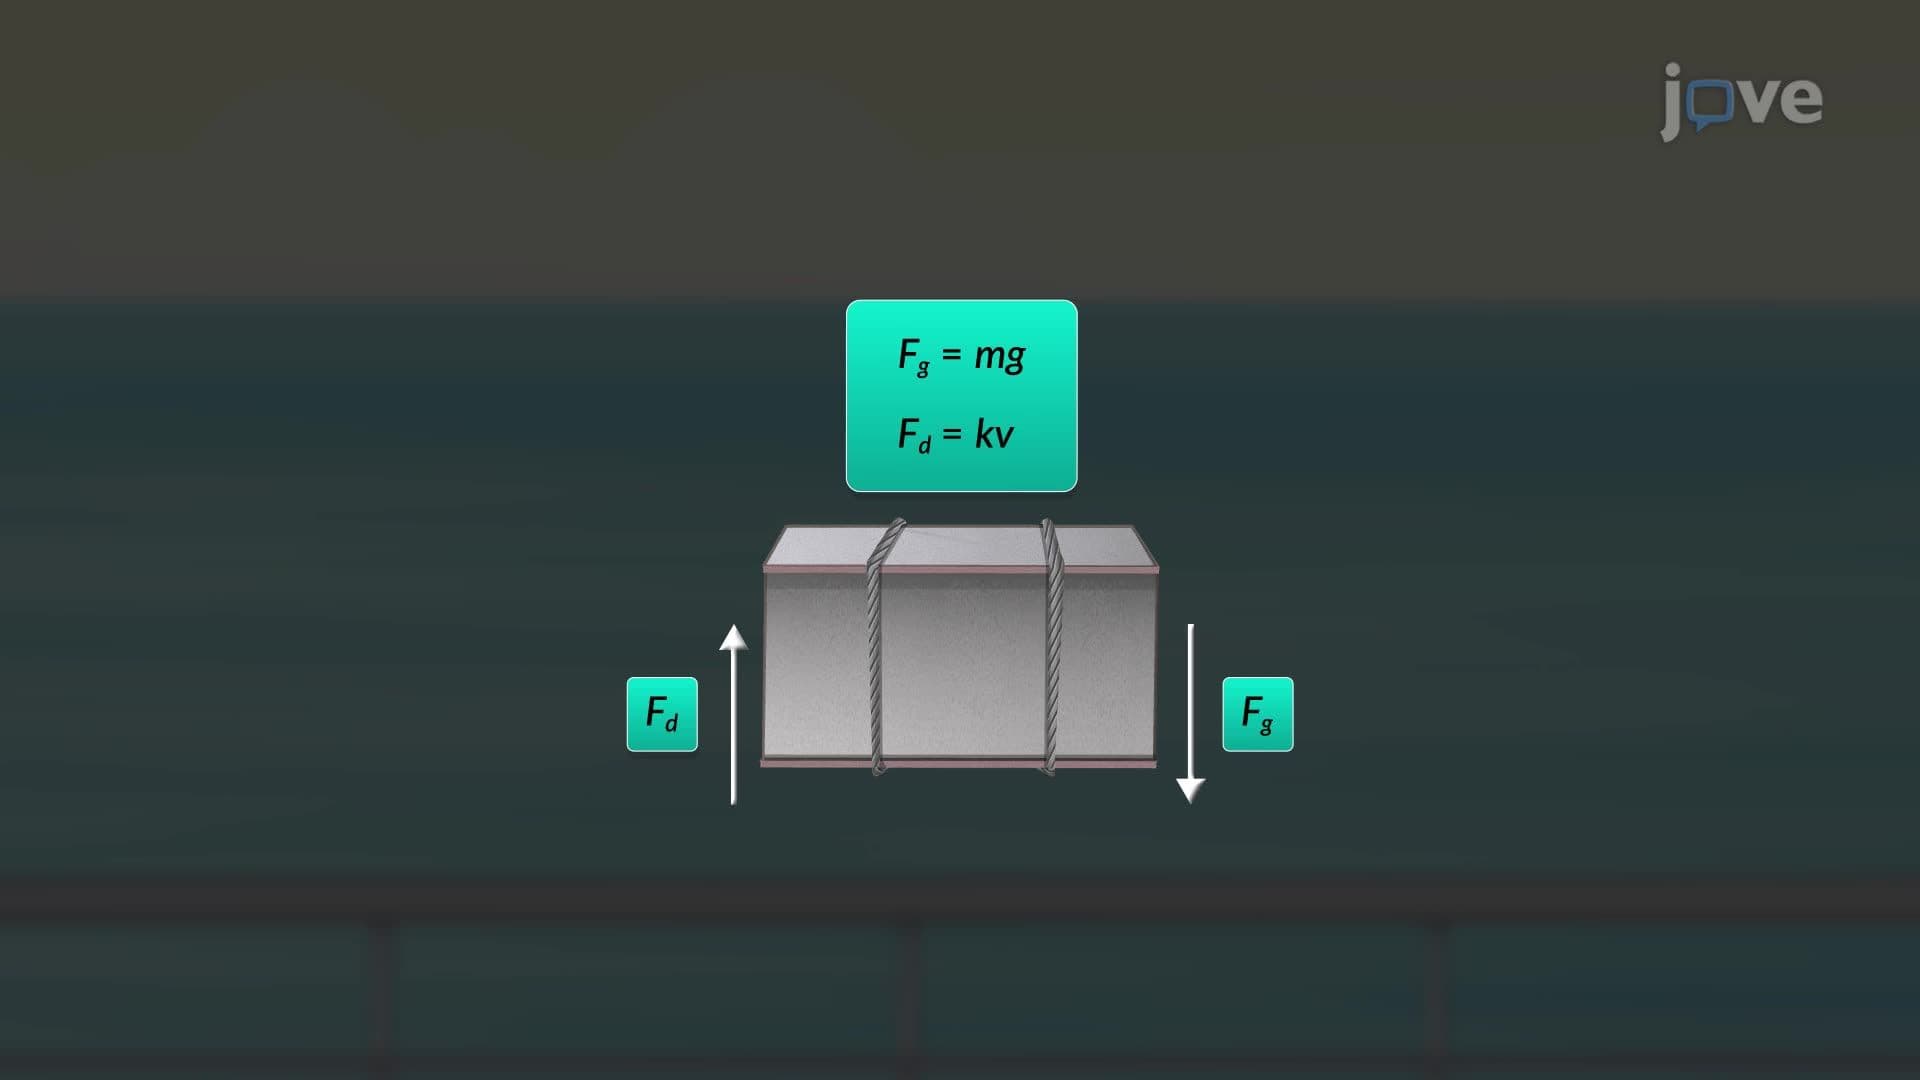
When analyzing the motion of falling objects, it is essential to consider not only the force of gravity but also the opposing force of air resistance. A practical example involves releasing a heavy test weight during a safety check on a ship. As the weight falls from rest, gravity accelerates it downward while air resistance exerts an upward force that increases with velocity. This dynamic interplay of forces is well described by differential equations, which provide a mathematical framework...
102
 01:26
Linear Approximation in Frequency Domain
412
Linear systems are characterized by two main properties: superposition and homogeneity. Superposition allows the response to multiple inputs to be the sum of the responses to each individual input. Homogeneity ensures that scaling an input by a scalar results in the response being scaled by the same scalar.
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
In contrast, nonlinear systems do not inherently possess these properties. However, for small deviations around an operating point, a nonlinear system can often be approximated as linear....
412