随机扰动动态系统的稳定和不稳定多元体的数值计算:操作员的方法
相关实验视频
Updated: Mar 12, 2026

Experimental Methods to Study Human Postural Control
Published on: September 11, 2019
Kaio C B Benedetti1, Paulo B Gonçalves2, Stefano Lenci3
1School of Civil and Environmental Engineering, Federal University of Goiás, Goiânia, Brazil.

非线性动态系统中的不变多元体是使用可测量动力学理论对非确定性系统进行概括的. 这项研究定义并证明了它们的存在,提供了计算方法,并揭示了微型架构中的随机现象.
科学领域:
- 动态系统理论 动态系统理论
- 随机过程 随机过程
- 几何动力学 几何动力学
背景情况:
- 不变变种群对于理解非线性动态系统的长期行为至关重要.
- 将不变多元体泛化为非确定性系统需要考虑概率行为和不确定性.
- 可测量的动力学理论提供了必要的工具,如转移运算符和乌拉姆离散.
研究的目的:
- 定义和确定不确定性的动态系统不变的多样性的存在.
- 开发一个计算框架,用可测量的动态来分析这些多元体.
- 调查随机现象对多重行为的影响.
主要方法:
- 从可测量的动态中利用概念,包括流量图和转移运算符 (在封闭和开放空间中的双重运算符).
- 应用了Ulam离散式到常量分布的空间.
- 定义并证明了不稳定的多元分布 (fWu) 和稳定的多元可观 (gWs) 的存在.
主要成果:
- 确立了fWu存在于不稳定的多重体上,其双可观察的gWs存在于稳定的多重体上.
- 为计算fWu和gWs的开放流转移运营商提出了一个离散化策略.
- 观察到在电力驱动的微架中趋同概率降低,稳定的多元体扩张和不稳定的多元体融合.
结论:
- 可测量的动力学理论成功地定义并证明了不稳定的多元分布和稳定的多元可观测的存在.
- 介绍了一种基于开放流转移运算符的Ulam离散的计算方法.
- 该研究揭示了相互关联的随机现象,影响系统动态和多重结构.
更多相关视频
 06:44
Age-dependent Dynamics of Locomotion in Caenorhabditis elegans: A Lyapunov Exponent Analysis
Published on: September 23, 2025
 07:49
Application of Consistent Massage-Like Perturbations on Mouse Calves and Monitoring the Resulting Intramuscular Pressure Changes
Published on: September 20, 2019
相关概念视频
 01:28
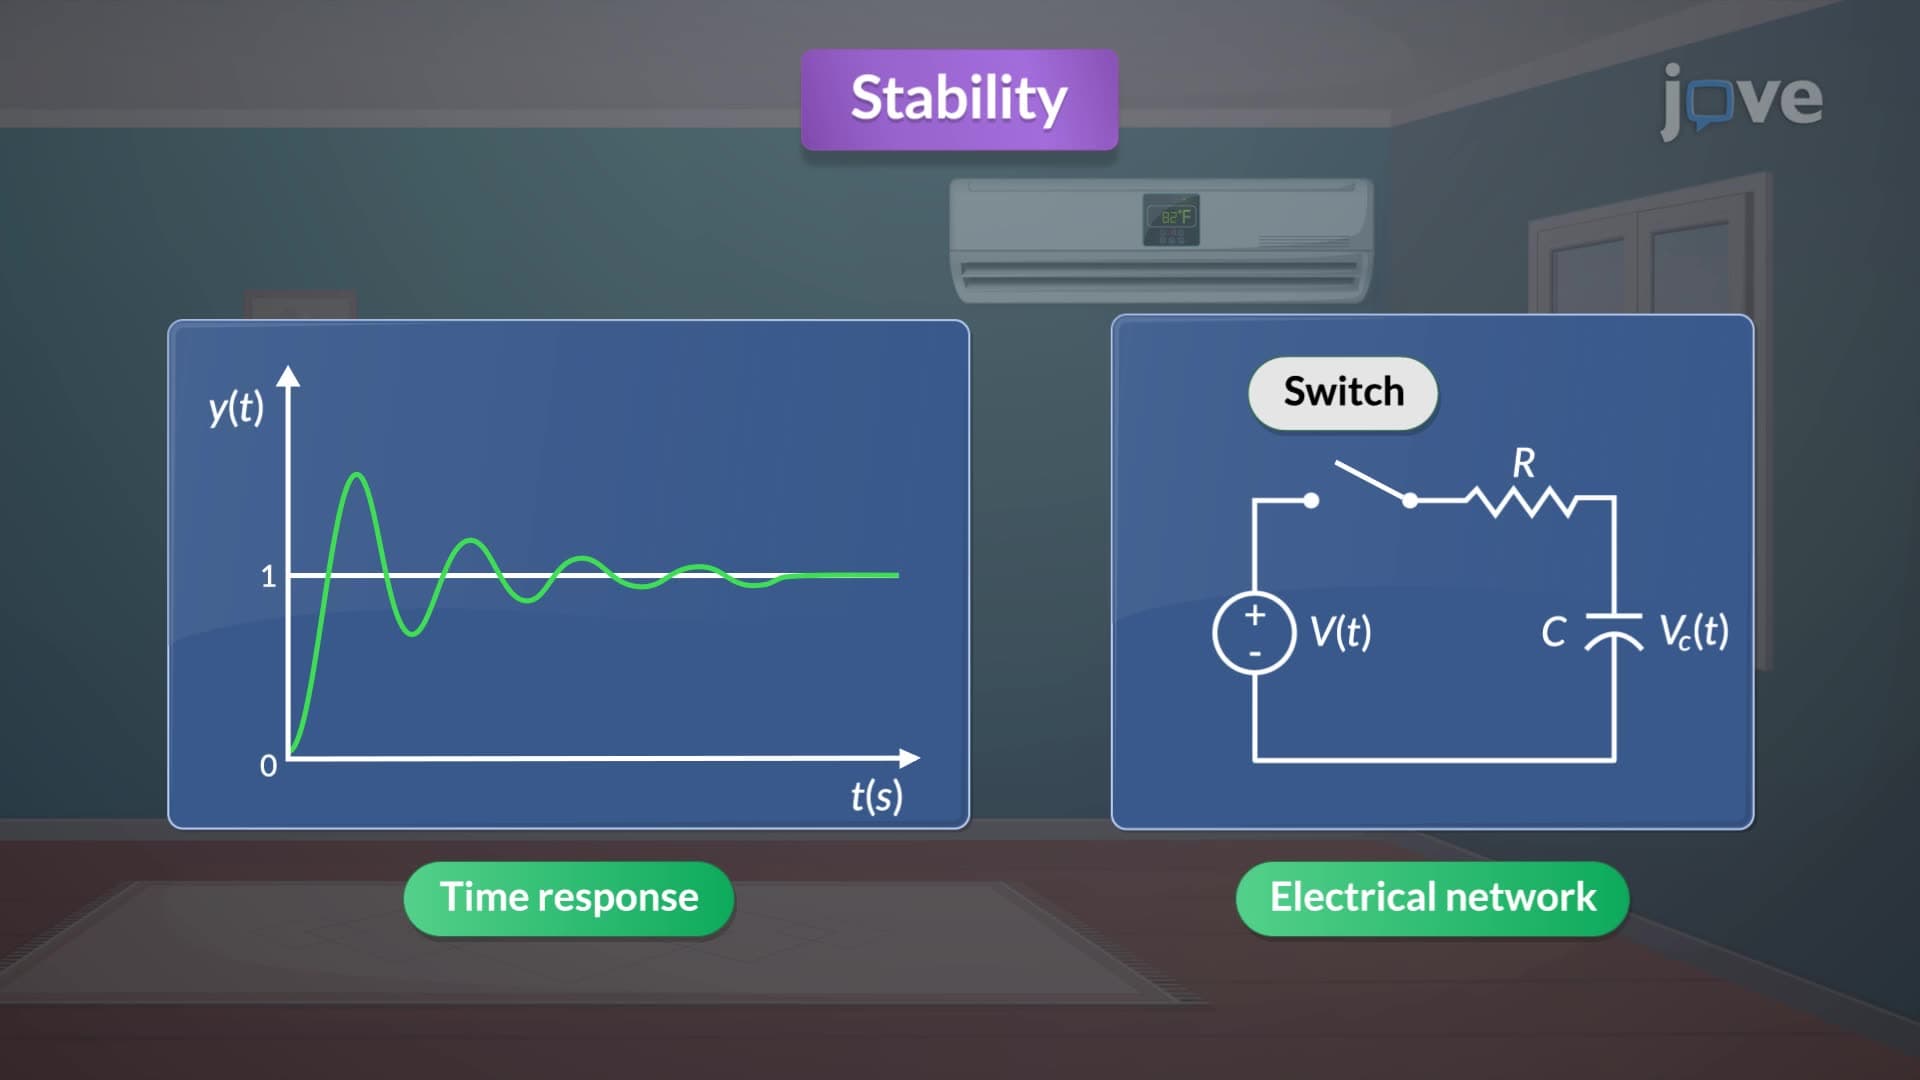
Stability
The stability of an LTI system is determined by the roots of its characteristic equation, known as poles. A system is stable if it produces a bounded...
 01:13
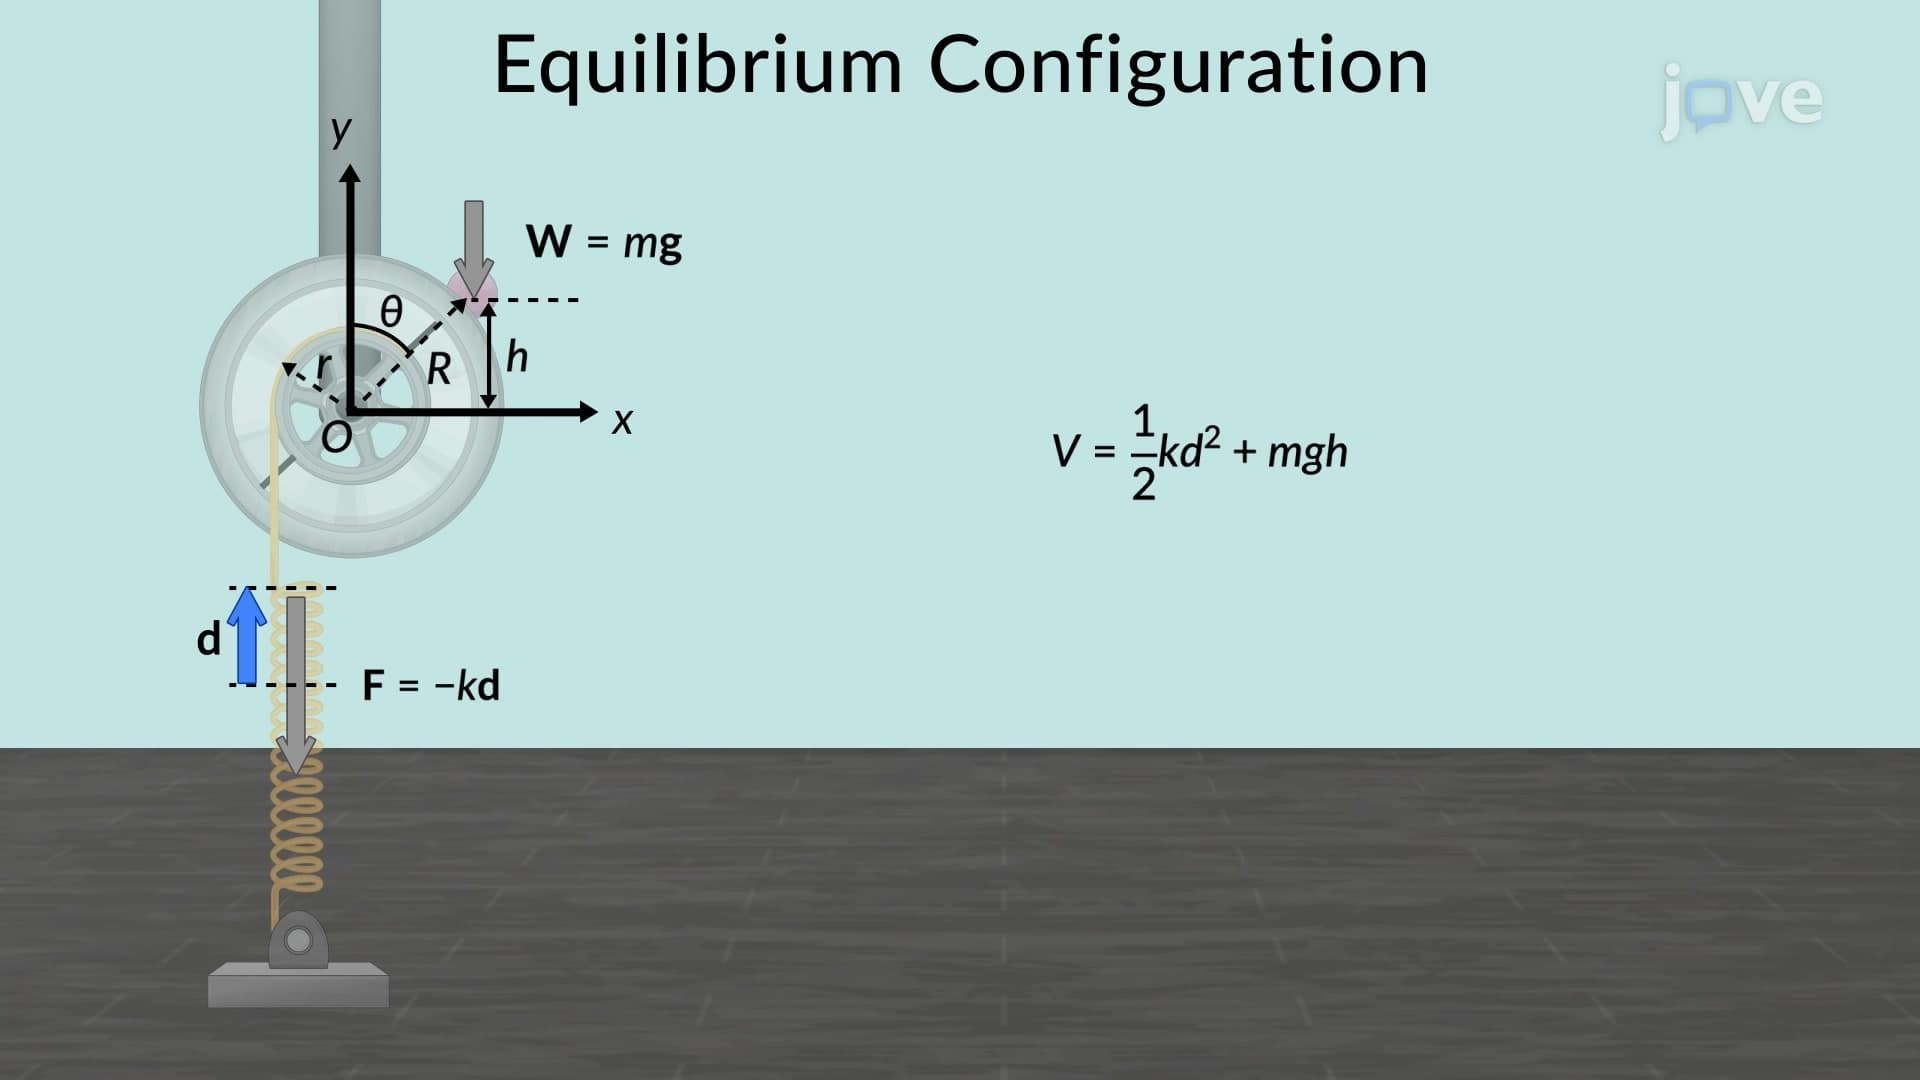
Stability of Equilibrium Configuration: Problem Solving
Problem-solving in the context of the stability of equilibrium configuration...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's...
 01:21
Linear Approximation in Time Domain
For a simple pendulum with a mass evenly distributed along its length and the center of mass located at half the pendulum's length,...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:23
Stability of Equilibrium Configuration
A stable equilibrium occurs when a system tends to return to its original position when given a small displacement, and the potential energy is at its minimum. An example of a stable equilibrium is when a cantilever beam is fixed at one end and a weight is attached to the other end. If the weight...