Related Experiment Video
Updated: Aug 14, 2026
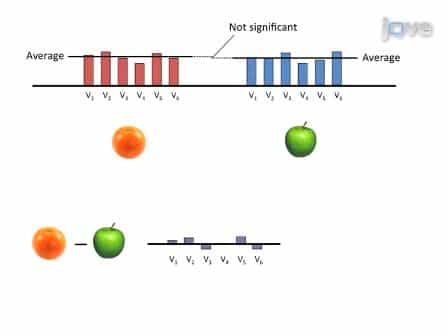

Cross-Modal Multivariate Pattern Analysis
Published on: November 9, 2011
The extrinsic/intrinsic classification of two-dimensional motion signals with barber-pole stimuli
E Castet1, V Charton, A Dufour
1Laboratoire de Psychophysique Sensorielle, Université Louis Pasteur, Strasbourg, France. ecastet@currif.u-strasbg.fr

Abstract:
The perceived direction of different barber-pole stimuli was assessed by adjusting an arrow on the screen. The terminator ratio (TR: number of terminators moving along the long side divided by the number of terminators moving along the small side) was either one or three. In this latter case, the aperture orientation was either vertical or horizontal. The grating was either in the same plane as the aperture (intrinsic condition) or behind the aperture--the frame containing the aperture had a crossed disparity relative to the grating--(extrinsic condition). A nested design with 120 observers was used for the whole study. Five grating orientations were intermingled within any session. With a terminator ratio of three, the results depend strongly on the aperture's orientation. When the rectangular aperture is horizontal, the perceived direction of an intrinsic grating is horizontal (the typical barber-pole illusion), whereas it is only slightly biased towards orthogonal one-dimensional (1D) motion signals (Vp) in the extrinsic condition. When the aperture is vertical, the perceived direction in the intrinsic condition is largely biased toward Vp, and on average it is close to Vp in the extrinsic condition. In this latter case, however, analysing the distributions of responses shows that many responses do not lie around Vp but are clustered near vertical or horizontal. This motion capture depends on the grating's orientation. With a terminator ratio of one, motion capture is present in both the extrinsic and intrinsic conditions. Moreover, a global bias toward horizontal is observed: this horizontal bias is much larger in the extrinsic condition. Altogether, these results suggest that binocular disparity alone is a weak determinant of the extrinsic/intrinsic classification of two-dimensional (2D) motion signals compared to the occlusion cues provided by unpaired regions in binocular images. Second, truly extrinsic 2D motion signals are not suppressed but rather actively compete against each other to capture the 1D motion signals. This results in a perceptual multistability which is much stronger with extrinsic signals. Finally, given the inherent multistability of barber-pole stimuli, high-level factors can alter the strength of this competition and prime any of the 2D motion signals.
More Related Videos

Related Concept Videos
 01:20
Two-Dimensional Force System
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:23
Curvilinear Motion: Rectangular Components
As the car advances, its position evolves over time. Quantifying the car's velocity involves computing the time...
 01:27
Curvilinear Motion: Polar Coordinates
The particle's location is described using a unit vector along the radial direction. Deriving the particle's position with respect to time...
 01:30
Classification of Signals
A continuous-time signal holds a value at every instant in time, representing information seamlessly. In contrast, a discrete-time signal holds values only at specific moments, often denoted as x(n), where...
 01:24
Pole and System Stability
Simple poles are unique roots of the denominator polynomial. Each simple pole corresponds to a distinct solution to the system's characteristic equation, typically resulting in exponential decay terms in the system's response.