Related Experiment Video
Updated: Oct 20, 2026
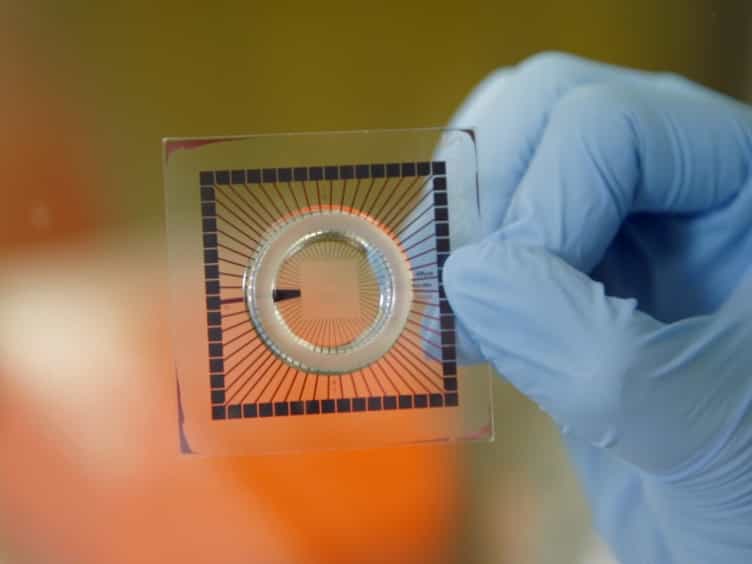
Closed-loop Neuro-robotic Experiments to Test Computational Properties of Neuronal Networks
Published on: March 2, 2015
Online evolution for a self-adapting robotic navigation system using evolvable hardware
D Keymeulen1, M Iwata, Y Kuniyoshi
1Electrotechnical Laboratory, Tsukuba, Ibaraki 305-8568, Japan.

Abstract:
Great interest has been shown in the application of the principles of artificial life to physically embedded systems such as mobile robots, computer networks, home devices able continuously and autonomously to adapt their behavior to changes of the environments. At the same time researchers have been working on the development of evolvable hardware, and new integrated circuits that are able to adapt their hardware autonomously and in real time in a changing environment. This article describes the navigation task for a real mobile robot and its implementation on evolvable hardware. The robot must track a colored ball, while avoiding obstacles in an environment that is unknown and dynamic. Although a model-free evolution method is not feasible for real-world applications due to the sheer number of possible interactions with the environment, we show that a model-based evolution can reduce these interactions by two orders of magnitude, even when some of the robot's sensors are blinded, thus allowing us to apply evolutionary processes online to obtain a self-adaptive tracking system in the real world, when the implementation is accelerated by the utilization of evolvable hardware.
Related Concept Videos
 01:19
Electro-mechanical Systems
A key component of the DC motor is the armature, a rotating circuit positioned within a magnetic field. As an electric current passes through the...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:17
Open and closed-loop control systems
An open-loop control system operates without feedback from the output. It consists of two primary elements: the controller and the controlled process. The controller receives an input signal and...
 01:26
Feedback control systems
Linear feedback systems are theoretical models that simplify analysis and design. These systems operate under the principle that their output is directly proportional to their input within certain ranges. For instance, an amplifier in a control system behaves linearly as long as the input signal remains within a specific range. However, most physical systems exhibit inherent nonlinearity...
 01:25
Control Systems: Applications
In modern vehicles, control systems manage various functions to enhance performance and safety. The steering wheel and accelerator are primary inputs in a car's control system. The direction...
 01:18
Hierarchy of Motor Control