Viewer-centered and body-centered frames of reference in direct visuomotor transformations
Related Experiment Video
Updated: Aug 23, 2026
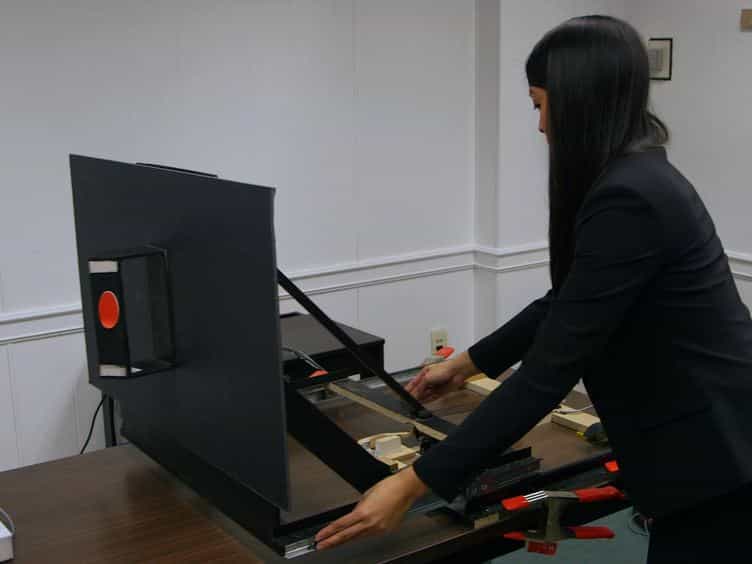
Methods to Explore the Influence of Top-down Visual Processes on Motor Behavior
Published on: April 16, 2014
M Carrozzo1, J McIntyre, M Zago
1Human Physiology Section, Scientific Institute Santa Lucia, via Ardeatina 306, I-00179 Rome, Italy. carrozzo@caspur.it

Abstract:
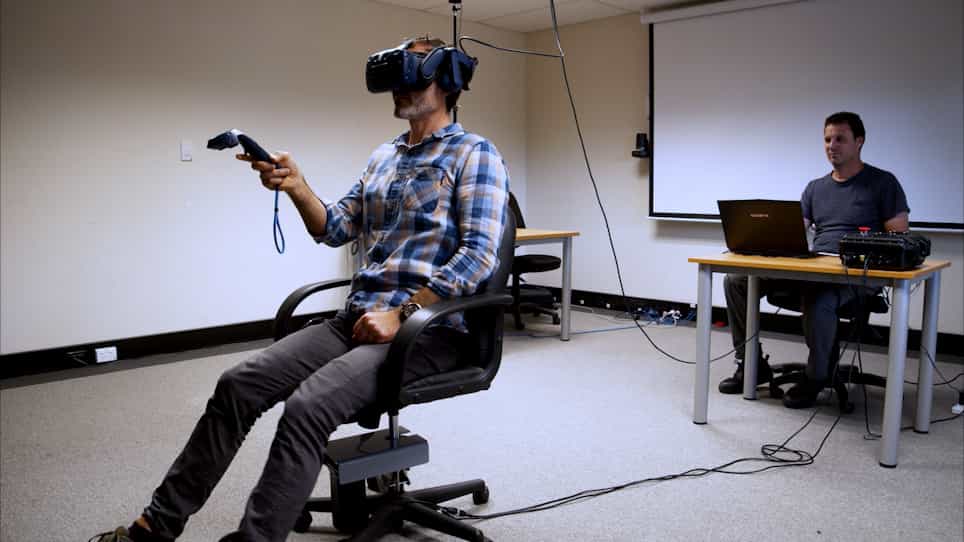
It has been hypothesized that the end-point position of reaching may be specified in an egocentric frame of reference. In most previous studies, however, reaching was toward a memorized target, rather than an actual target. Thus, the role played by sensorimotor transformation could not be disassociated from the role played by storage in short-term memory. In the present study the direct process of sensorimotor transformation was investigated in reaching toward continuously visible targets that need not be stored in memory. A virtual reality system was used to present visual targets in different three-dimensional (3D) locations in two different tasks, one with visual feedback of the hand and arm position (Seen Hand) and the other without such feedback (Unseen Hand). In the Seen Hand task, the axes of maximum variability and of maximum contraction converge toward the mid-point between the eyes. In the Unseen Hand task only the maximum contraction correlates with the sight-line and the axes of maximum variability are not viewer-centered but rotate anti-clockwise around the body and the effector arm during the move from the right to the left workspace. The bulk of findings from these and previous experiments support the hypothesis of a two-stage process, with a gradual transformation from viewer-centered to body-centered and arm-centered coordinates. Retinal, extra-retinal and arm-related signals appear to be progressively combined in superior and inferior parietal areas, giving rise to egocentric representations of the end-point position of reaching.

Related Concept Videos
 01:03
Inertial Frames of Reference
 01:27
Non-inertial Frames of Reference
 01:16
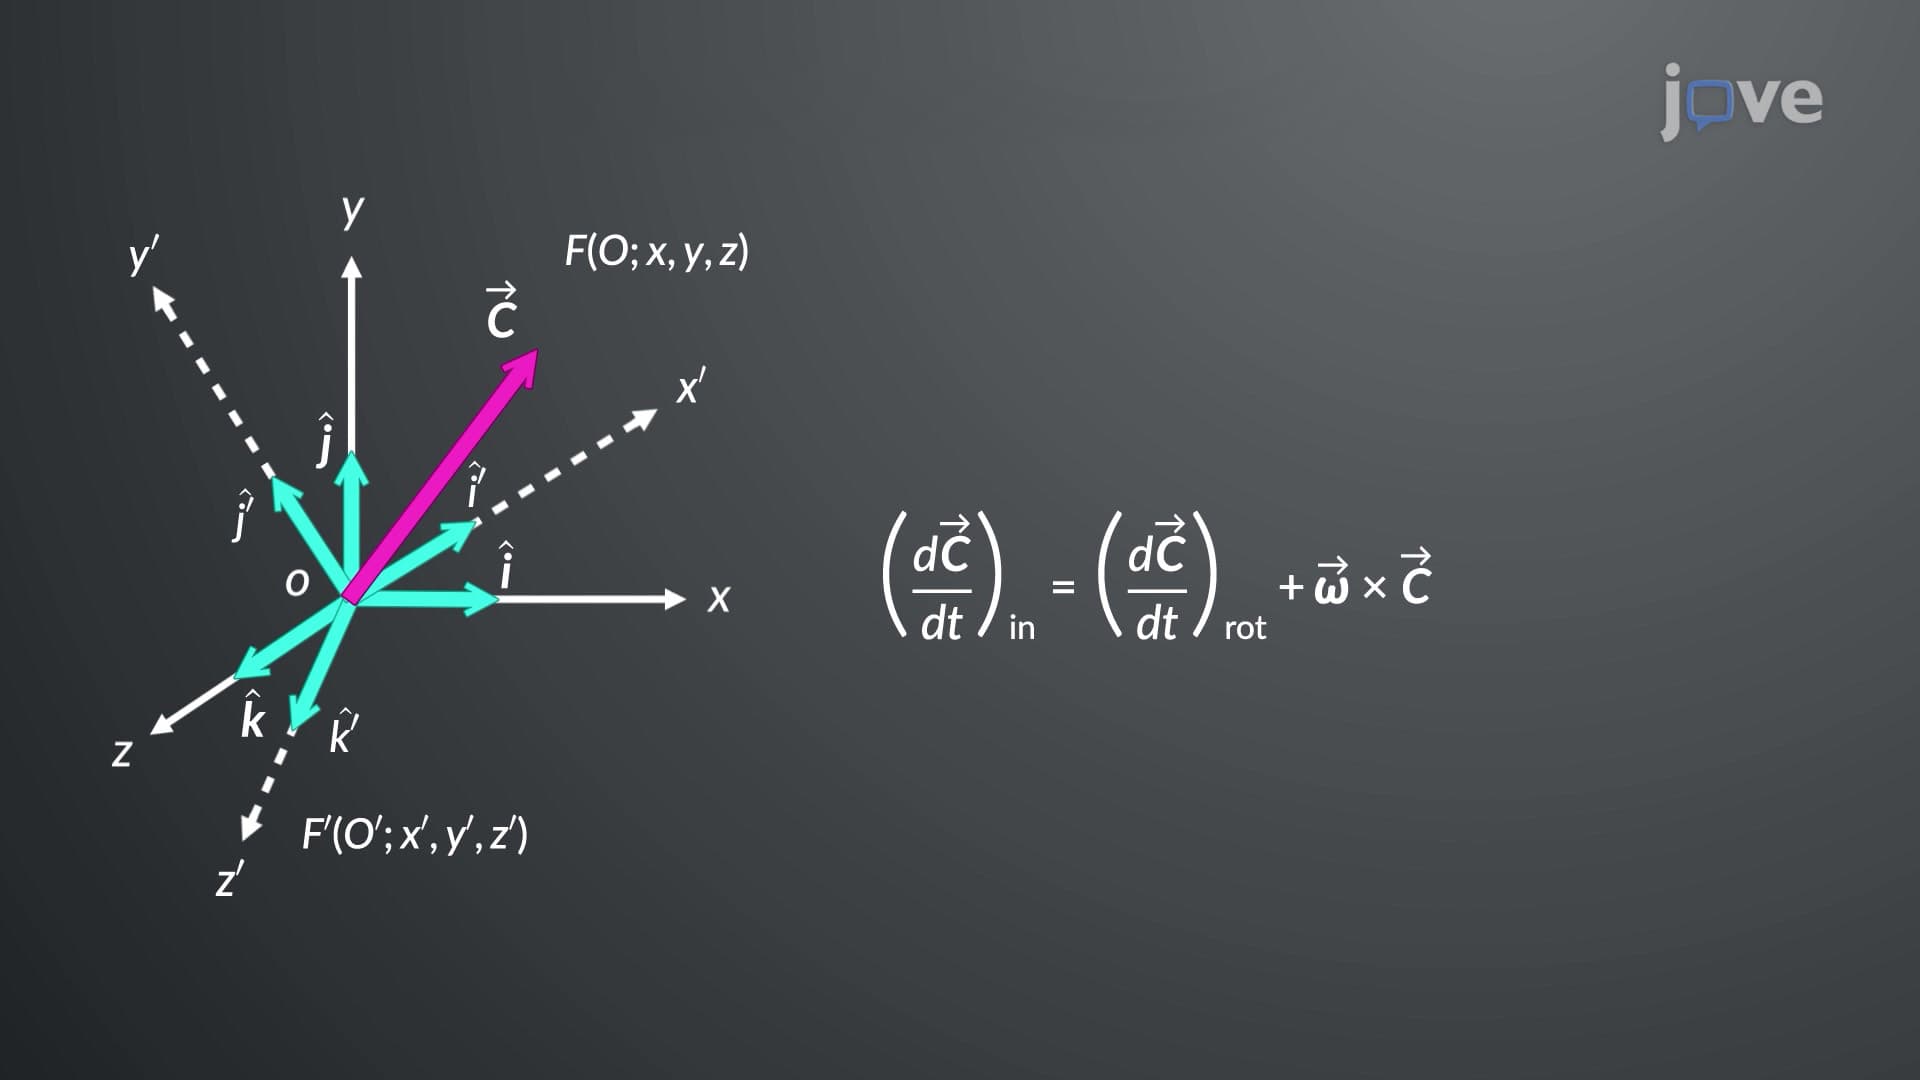
Vector Transformation in Rotating Coordinate Systems
 01:25
Relative Motion Analysis using Rotating Axes
However, to express the relative position of point B relative to point A, an additional frame of reference, denoted as x'y', is necessary. This additional frame not only translates but also rotates relative to the fixed frame, making it instrumental in...
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...