Related Experiment Video
Updated: Aug 16, 2026
Quantifying Microorganisms at Low Concentrations Using Digital Holographic Microscopy (DHM)
Published on: November 1, 2017
A universal time-varying distributed H-system of degree 2
1Institut Universitaire de Technologie, Groupe d'Informatique Fondamentale de Metz, France. margens@antares.iut.univ-metz.fr

Abstract:
A time-varying distributed H system is a splicing system which has the following feature: at different moments one uses different sets of splicing rules. The number of these sets is called the degree of the system. The passing from a set of rules to another one is specified in a cycle. It is a well known fact that any formal language can be generated by a time-varying distributed H-system of degree at least 7. Here we prove that there are universal time-varying distributed H-systems of degree 2. The question of whether or not there are universal time-varying distributed H-systems of degree 1 remains open.
Related Concept Videos
 02:05
Degree of Unsaturation
The degree of unsaturation for hydrocarbons is U = (2C + 2 − H) / 2, where C is the number of carbon atoms and H is the number of hydrogen atoms.
For...
 01:24
One-Degree-of-Freedom System
A one-degree-of-freedom system is defined by an independent variable that determines its state and behavior. One example of a one-degree-of-freedom system is a simple harmonic oscillator, such as a...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be calculated...
 01:21
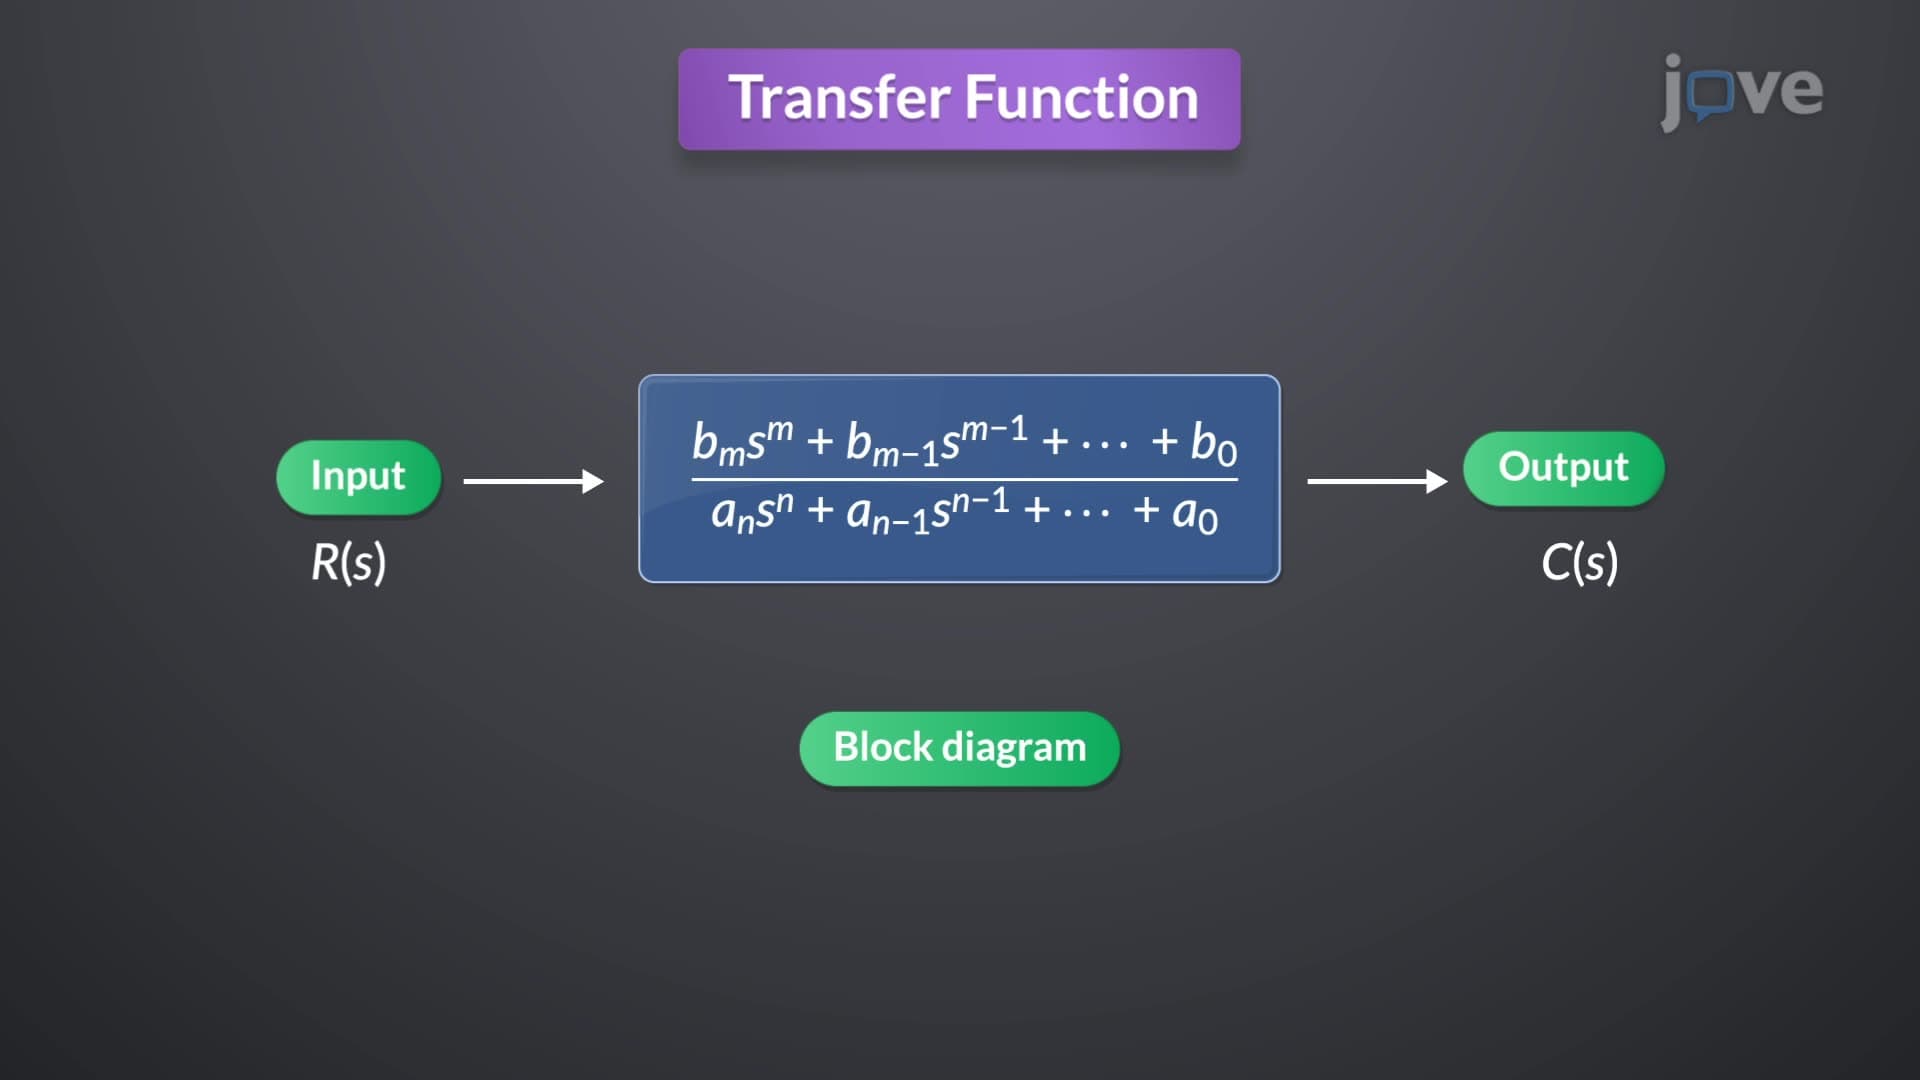
Transfer Function in Control Systems
To derive the transfer function, consider a general nth-order linear time-invariant...
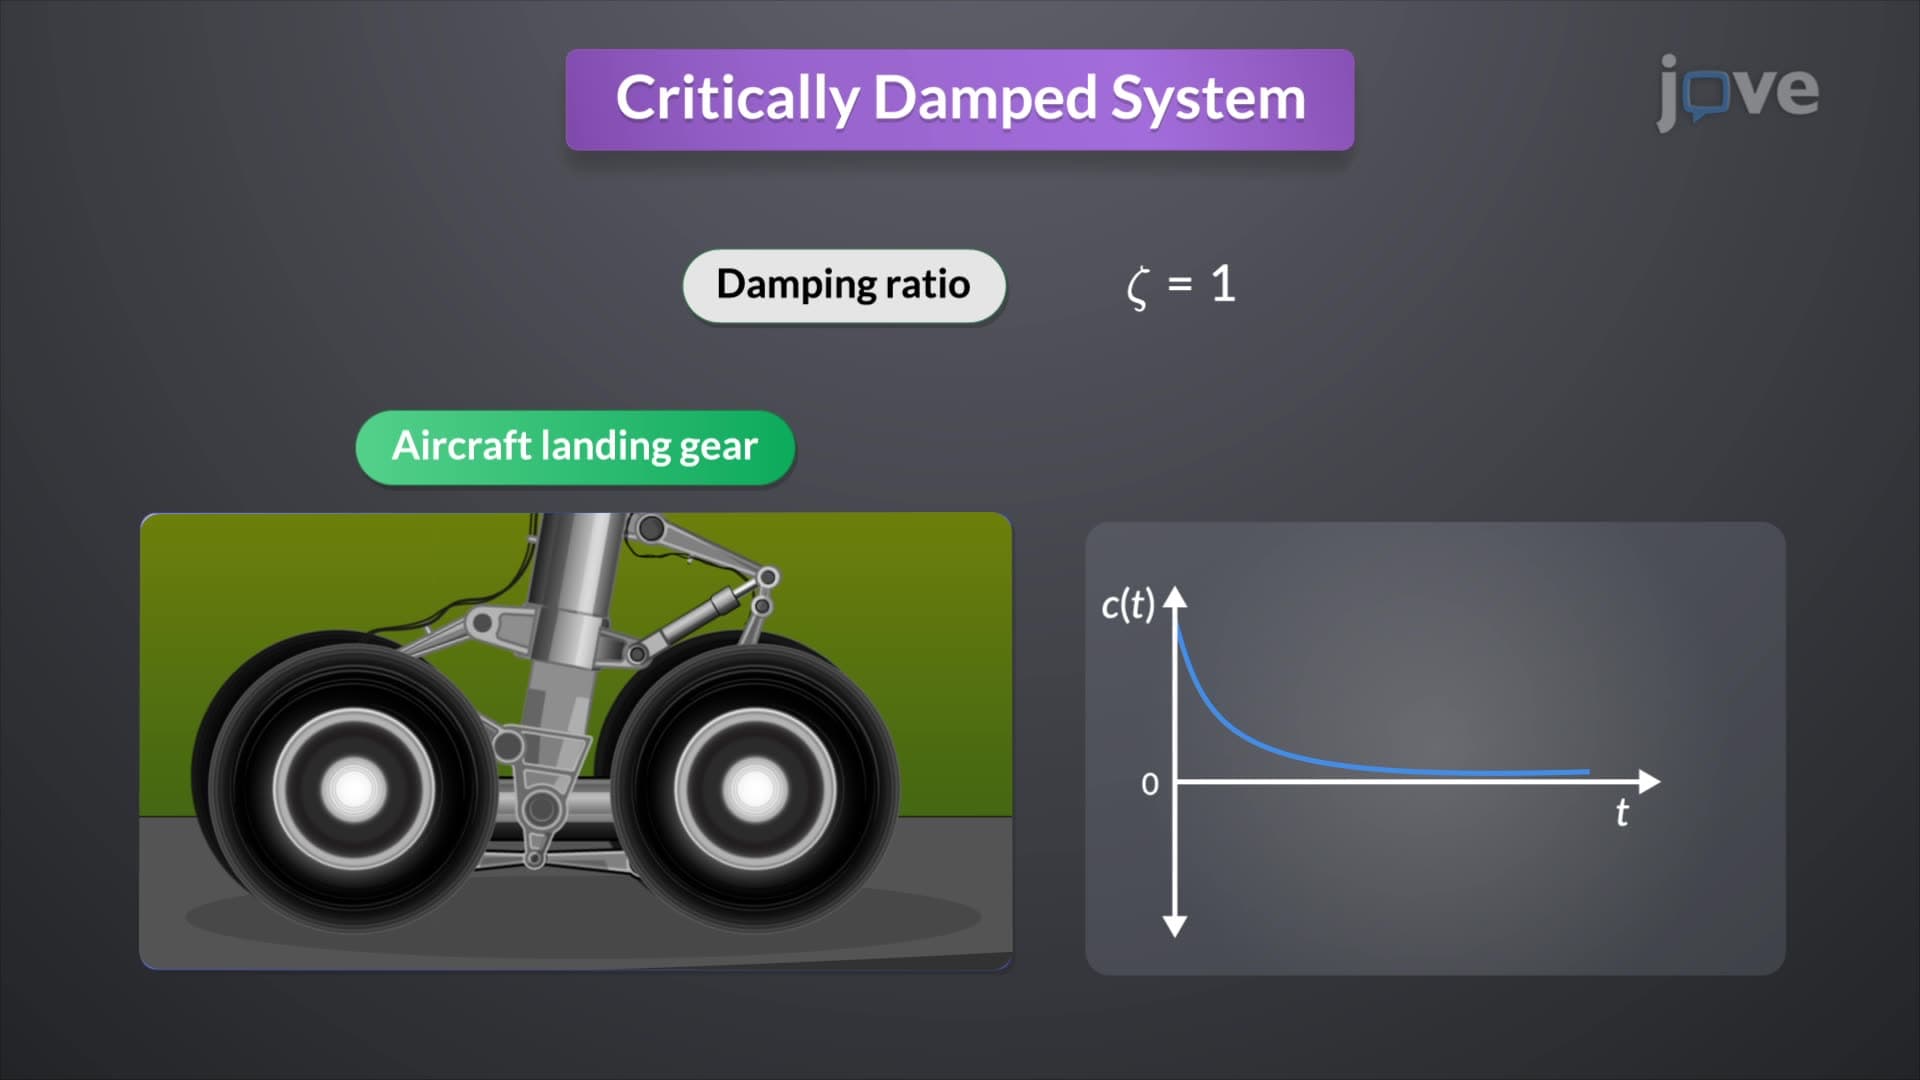 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:29
Radian and Degree Measure