Related Experiment Video
Updated: Aug 11, 2026

Controlled Synthesis and Fluorescence Tracking of Highly Uniform Poly(N-isopropylacrylamide) Microgels
Published on: September 8, 2016
Second-order iterative approach to inverse scattering: numerical results
1Dipartimento di Ingegneria dell'Informazione, Seconda Universita di Napoli, Aversa, Italy. pierri@unina.it

Abstract:
We introduce an iterative algorithm for the reconstruction of dielectric profile functions from scattered field data, in which each step corresponds to the solution of a quadratic inversion problem. This means that, at each iteration, we perform a second-order approximation of the scattering operator connecting the unknown profile to the data about a reference profile function. This procedure is then compared with a linear iterative inversion algorithm, and it is pointed out that, within a prescribed class of profile functions, the linear iterative inversion does not converge to the actual solution, whereas the proposed approach does. This feature can be explained by reference not only to the improved approximation provided by the addition of a further term for profile functions of a larger norm but also to the different classes of functions that can be reconstructed by either the linear or the quadratic model. Numerical examples of profile reconstruction in the scalar two-dimensional geometry, with far-zone scattered field data at a fixed frequency, confirm the theoretical analysis.
Related Concept Videos
 01:20
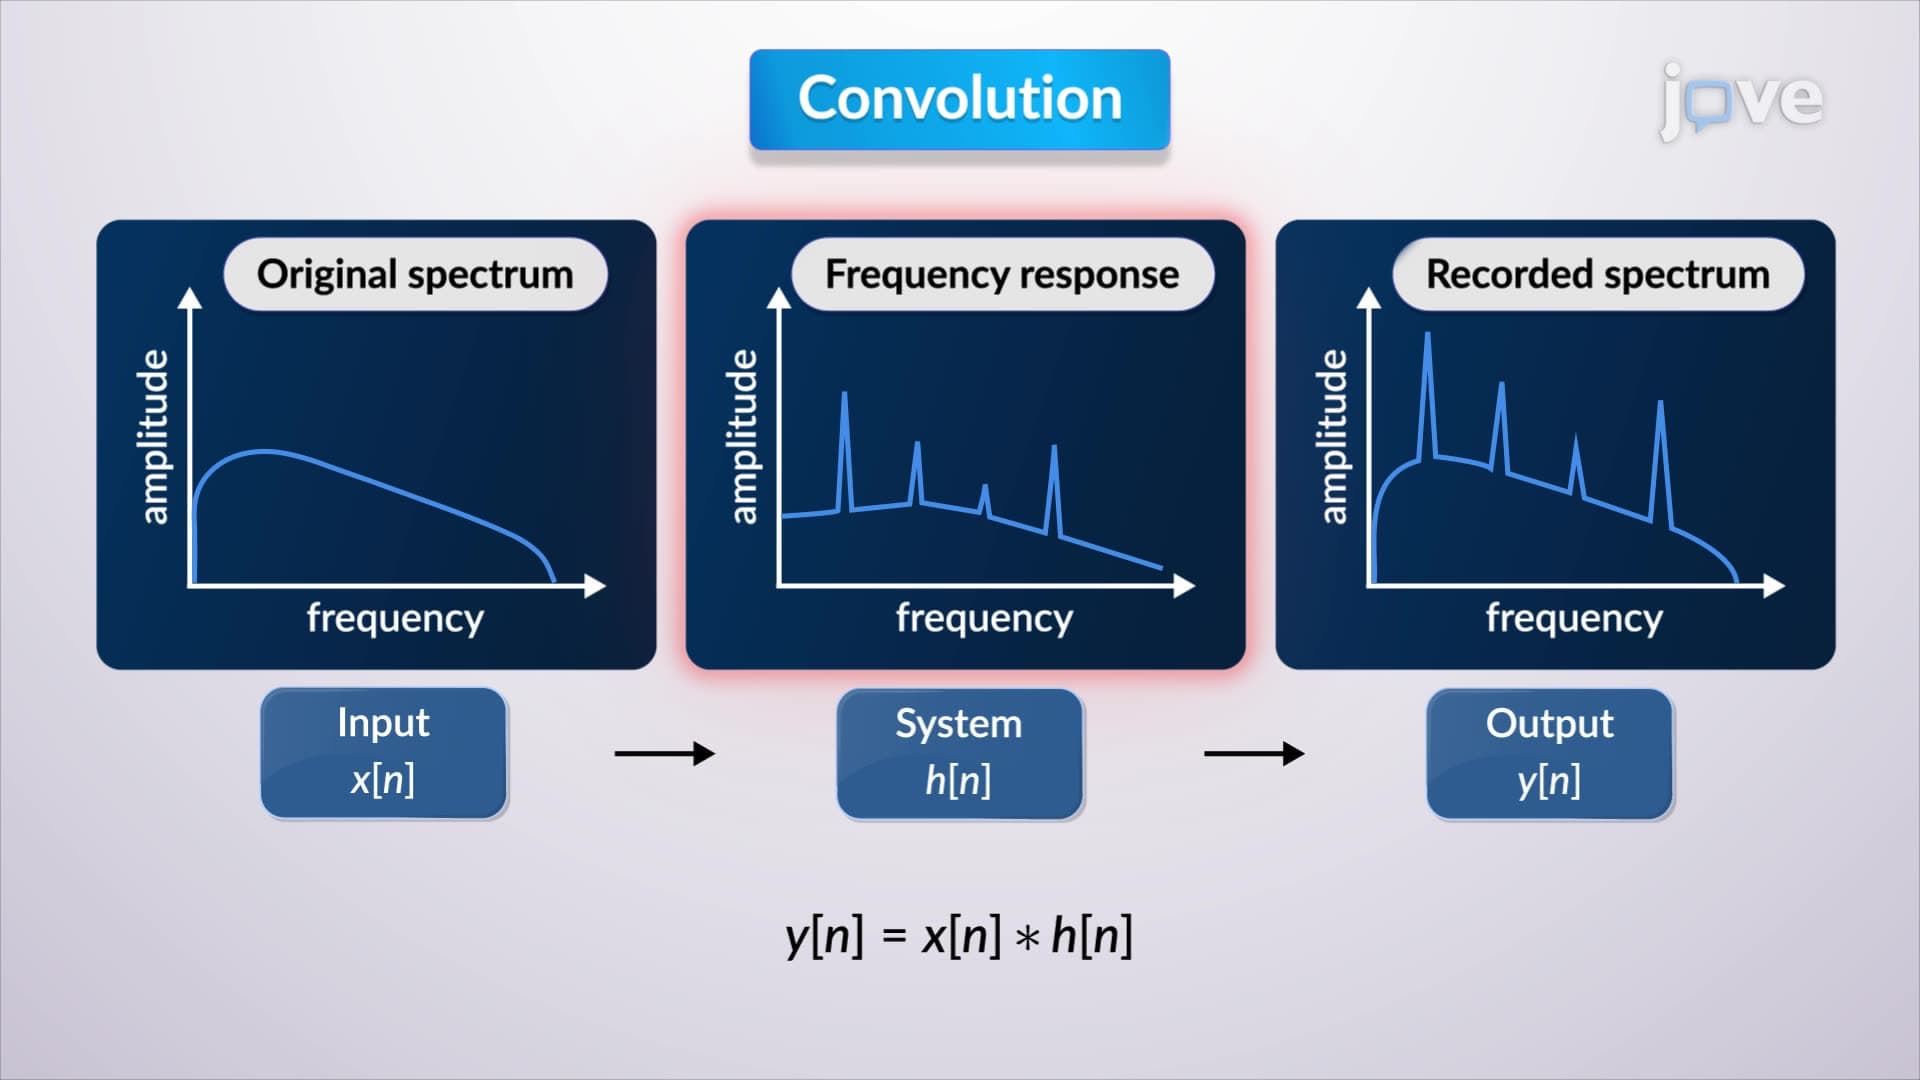
Deconvolution
Deconvolution involves several mathematical techniques to derive the impulse response. One common approach is polynomial division. In this method, the input and output sequences are treated as coefficients of...
 01:20
Inverse z-Transform by Partial Fraction Expansion
To begin the process, the poles of the function are identified and the function is...
 01:20
Second Order systems I
By reinterpreting the system, one can derive the closed-loop transfer function, which...
 01:18
Second Order systems II
If ζ...
 01:30
Derivatives of Inverse Trigonometric Functions
 01:28
Simpson's Rule II