Observable operator models for discrete stochastic time series
1German National Research Center for Information Technology, Institute for Intelligent Autonomous Systems, Sankt Augustin.

Abstract:
A widely used class of models for stochastic systems is hidden Markov models. Systems that can be modeled by hidden Markov models are a proper subclass of linearly dependent processes, a class of stochastic systems known from mathematical investigations carried out over the past four decades. This article provides a novel, simple characterization of linearly dependent processes, called observable operator models. The mathematical properties of observable operator models lead to a constructive learning algorithm for the identification of linearly dependent processes. The core of the algorithm has a time complexity of O(N + nm3), where N is the size of training data, n is the number of distinguishable outcomes of observations, and m is model state-space dimension.
Related Concept Videos
 01:24
BIBO stability of continuous and discrete -time systems
To determine the BIBO stability, the convolution integral is utilized when a bounded continuous-time input is applied to a Linear Time-Invariant (LTI) system....
 01:22
Basic Continuous Time Signals
The unit step function, denoted u(t), is zero for negative time values and one for positive time values, exhibiting a discontinuity at t=0. This function often represents abrupt changes, such as the step voltage introduced when turning a car's...
 01:23
Linear time-invariant Systems
The input-output behavior of an LTI system can be fully defined by its response to an impulsive excitation at its input. Once this impulse response is known, the system's reaction to any other input can be...
 01:09
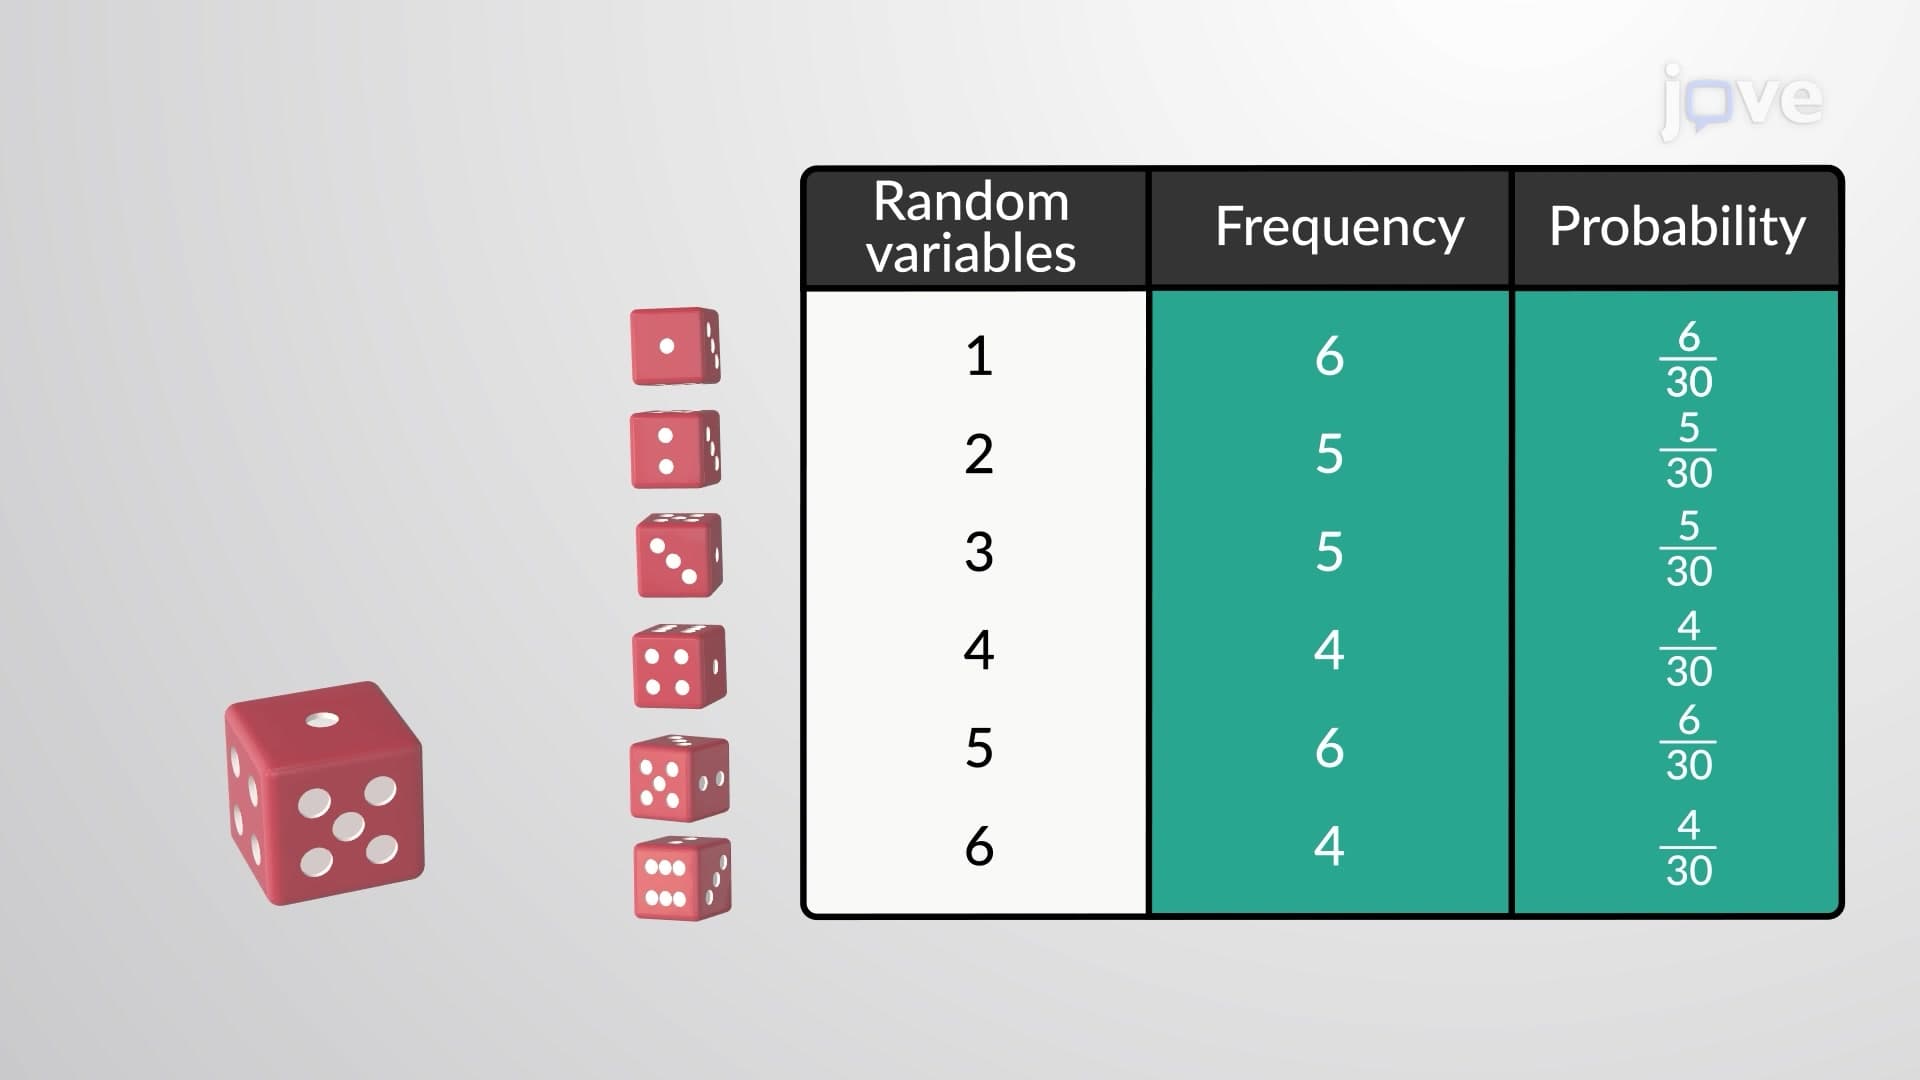
Random Variables
Uppercase letters such as X or Y denote a random variable. Lowercase letters like x or y denote the value of a random variable. If X is a random variable, then X is written in words, and x is given as a number.
For example, let X = the...
 01:26
Per-Unit Sequence Models
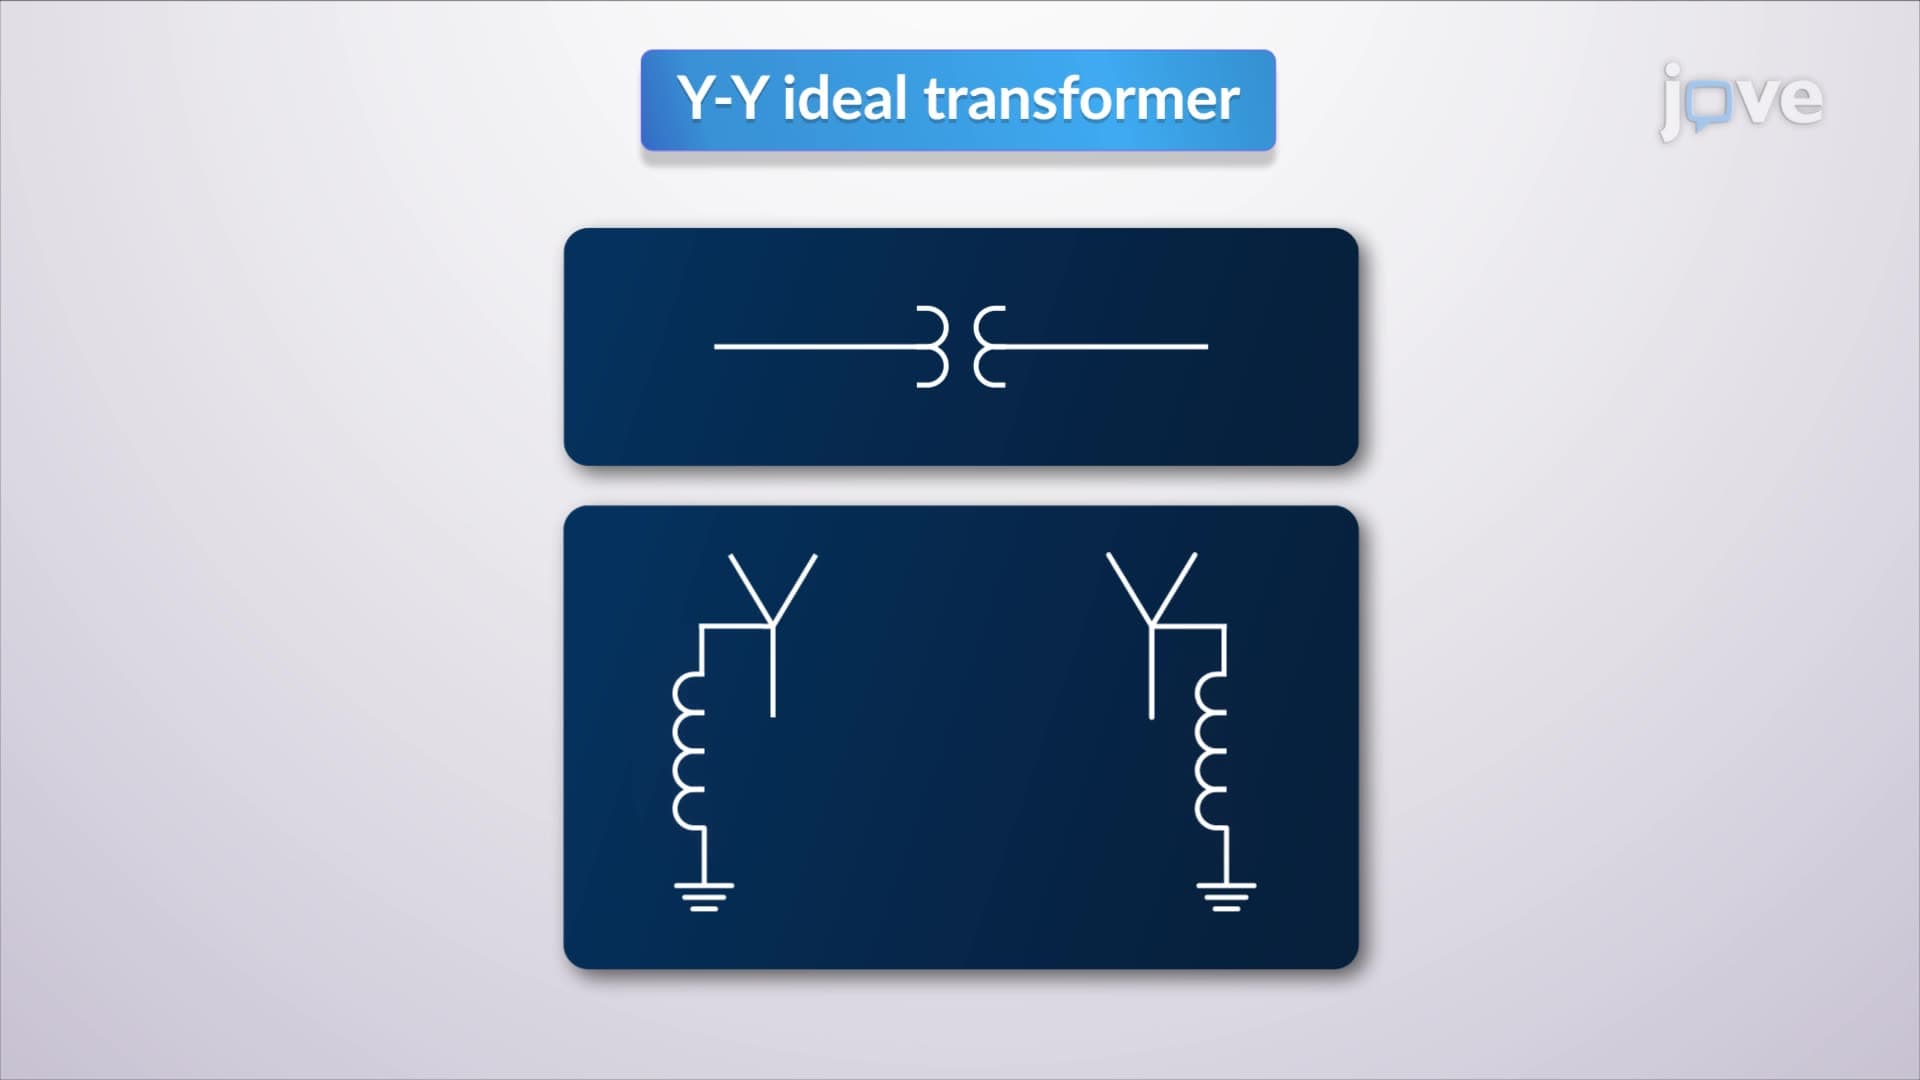
Zero-sequence currents, which are identical in magnitude and phase, generate a neutral current, resulting in voltage drops across the neutral impedance and the low-voltage winding. If the...
 01:16
Basic Discrete Time Signals
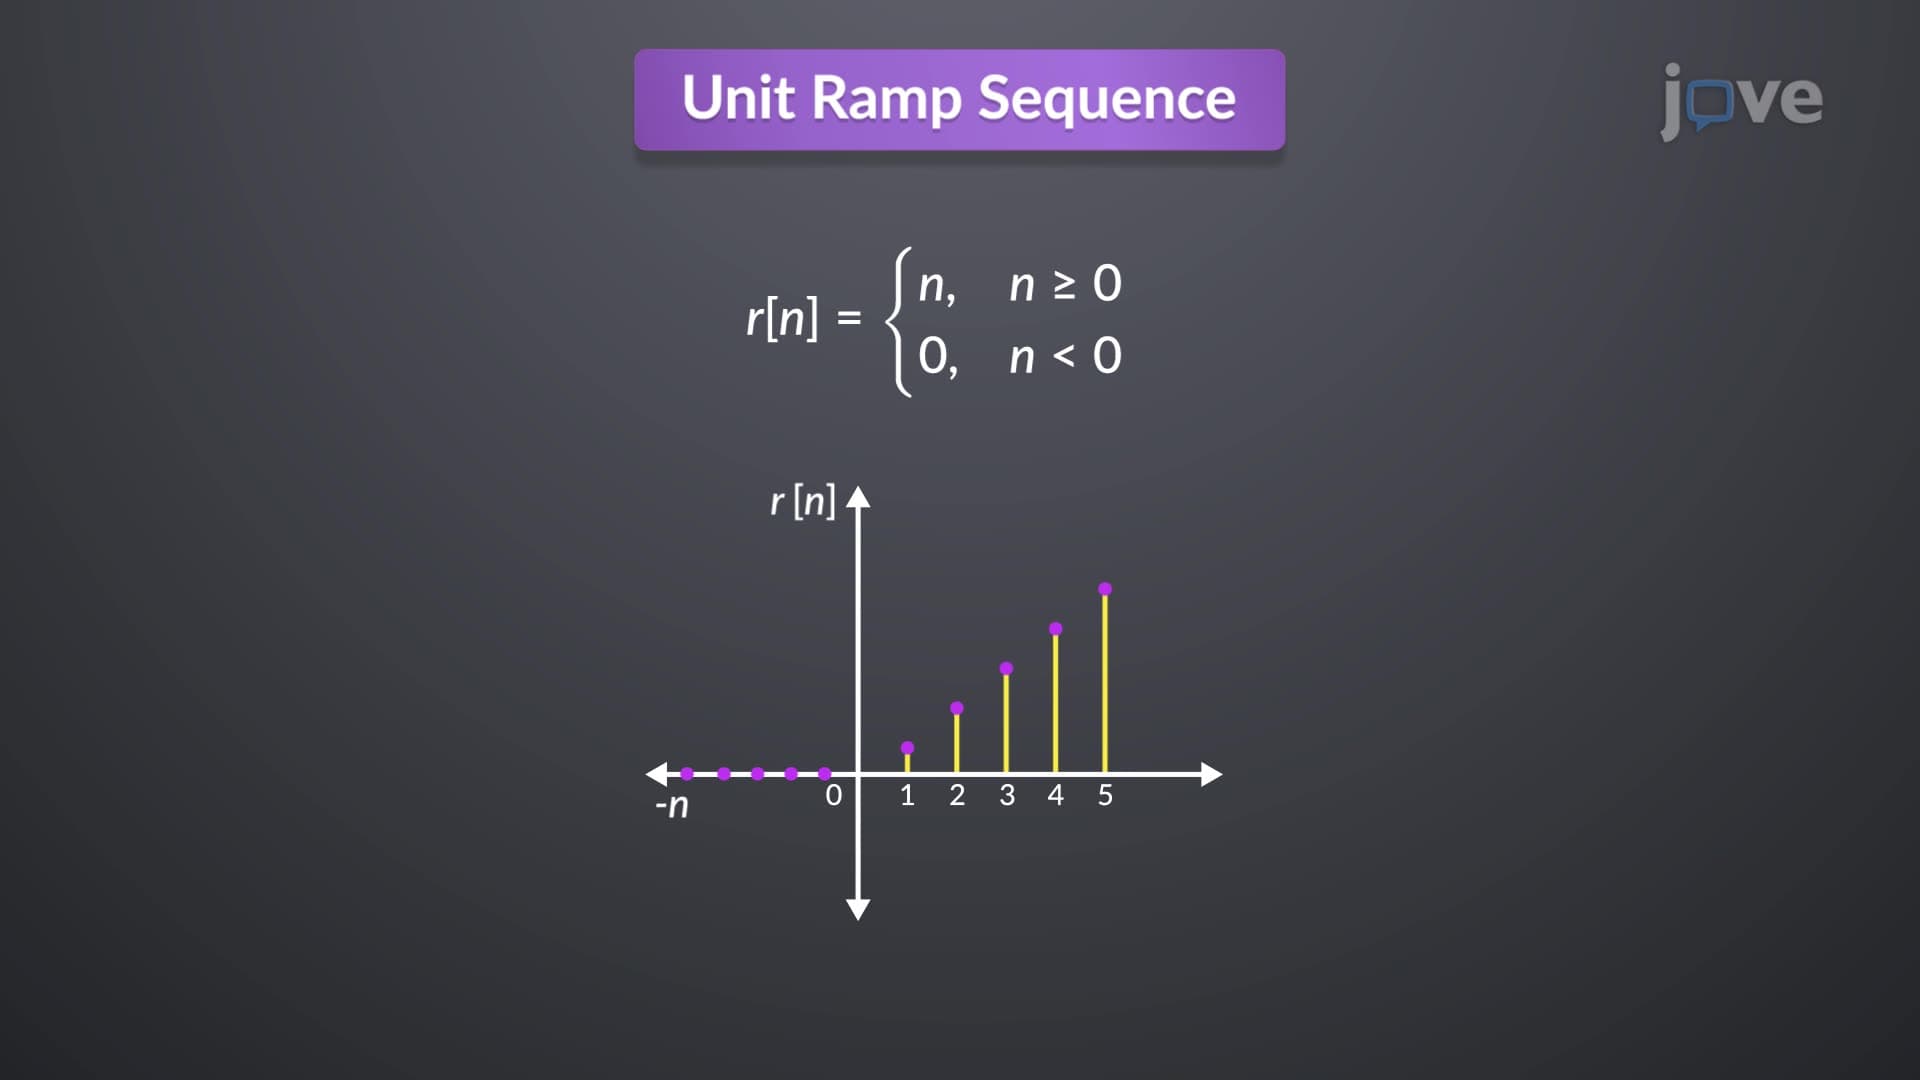
The unit impulse or sample sequence is mathematically expressed as zero for all n values except at n=0, where it is one. The unit impulse sequence, denoted by δ(n), is the first difference of the unit step sequence, while the unit step sequence u(n) is the...