Related Experiment Video
Updated: Oct 10, 2026
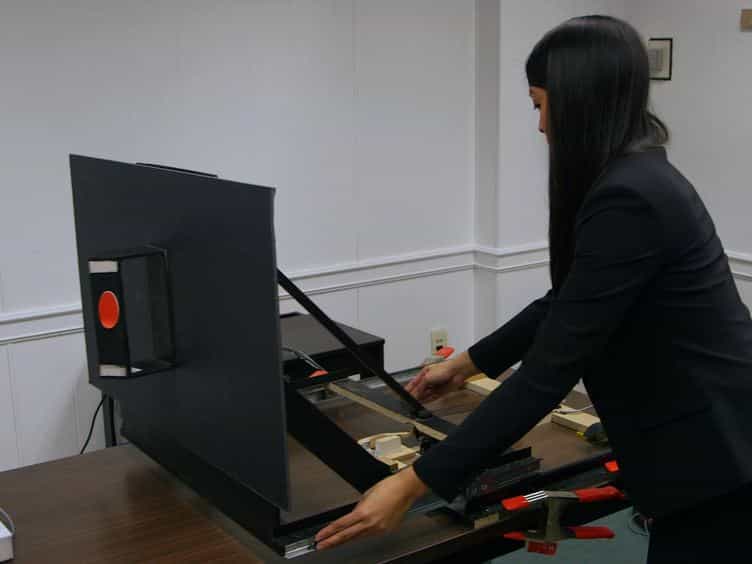
Methods to Explore the Influence of Top-down Visual Processes on Motor Behavior
Published on: April 16, 2014
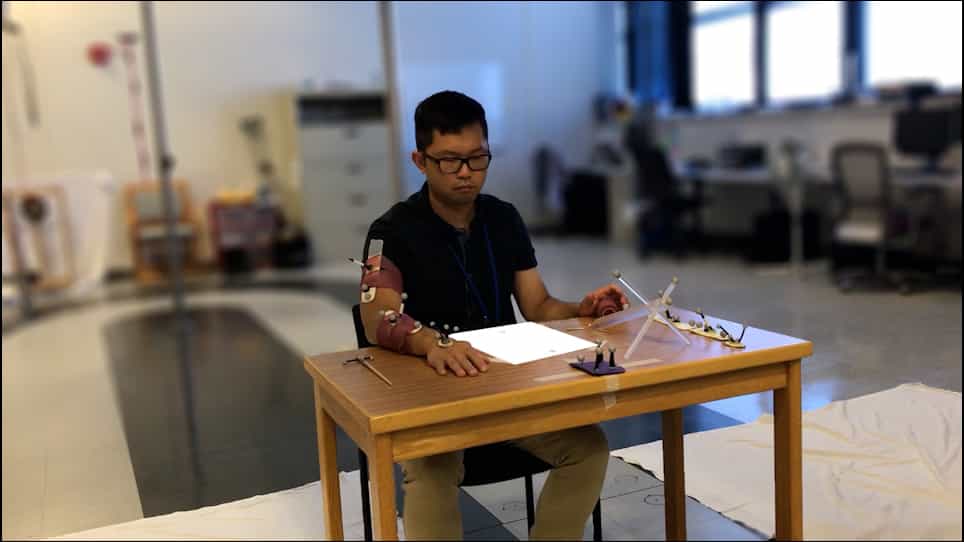
Learning of visuomotor transformations for vectorial planning of reaching trajectories
J W Krakauer1, Z M Pine, M F Ghilardi
1Departments of Neurology and Neurobiology and Behavior, Columbia University, College of Physicians and Surgeons, New York, New York 10032, USA.

Abstract:
The planning of visually guided reaches is accomplished by independent specification of extent and direction. We investigated whether this separation of extent and direction planning for well practiced movements could be explained by differences in the adaptation to extent and directional errors during motor learning. We compared the time course and generalization of adaptation with two types of screen cursor transformation that altered the relationship between hand space and screen space. The first was a gain change that induced extent errors and required subjects to learn a new scaling factor. The second was a screen cursor rotation that induced directional errors and required subjects to learn new reference axes. Subjects learned a new scaling factor at the same rate when training with one or multiple target distances, whereas learning new reference axes took longer and was less complete when training with multiple compared with one target direction. After training to a single target, subjects were able to transfer learning of a new scaling factor to previously unvisited distances and directions. In contrast, generalization of rotation adaptation was incomplete; there was transfer across distances and arm configurations but not across directions. Learning a rotated reference frame only occurred after multiple target directions were sampled during training. These results suggest the separate processing of extent and directional errors by the brain and support the idea that reaching movements are planned as a hand-centered vector whose extent and direction are established via learning a scaling factor and reference axes.
Related Concept Videos
 01:30
Vector Functions and Motion: Problem Solving
 01:29
Relative Motion Analysis using Rotating Axes-Problem Solving
Here, in order to determine the magnitude of velocity and acceleration for point...
 01:16
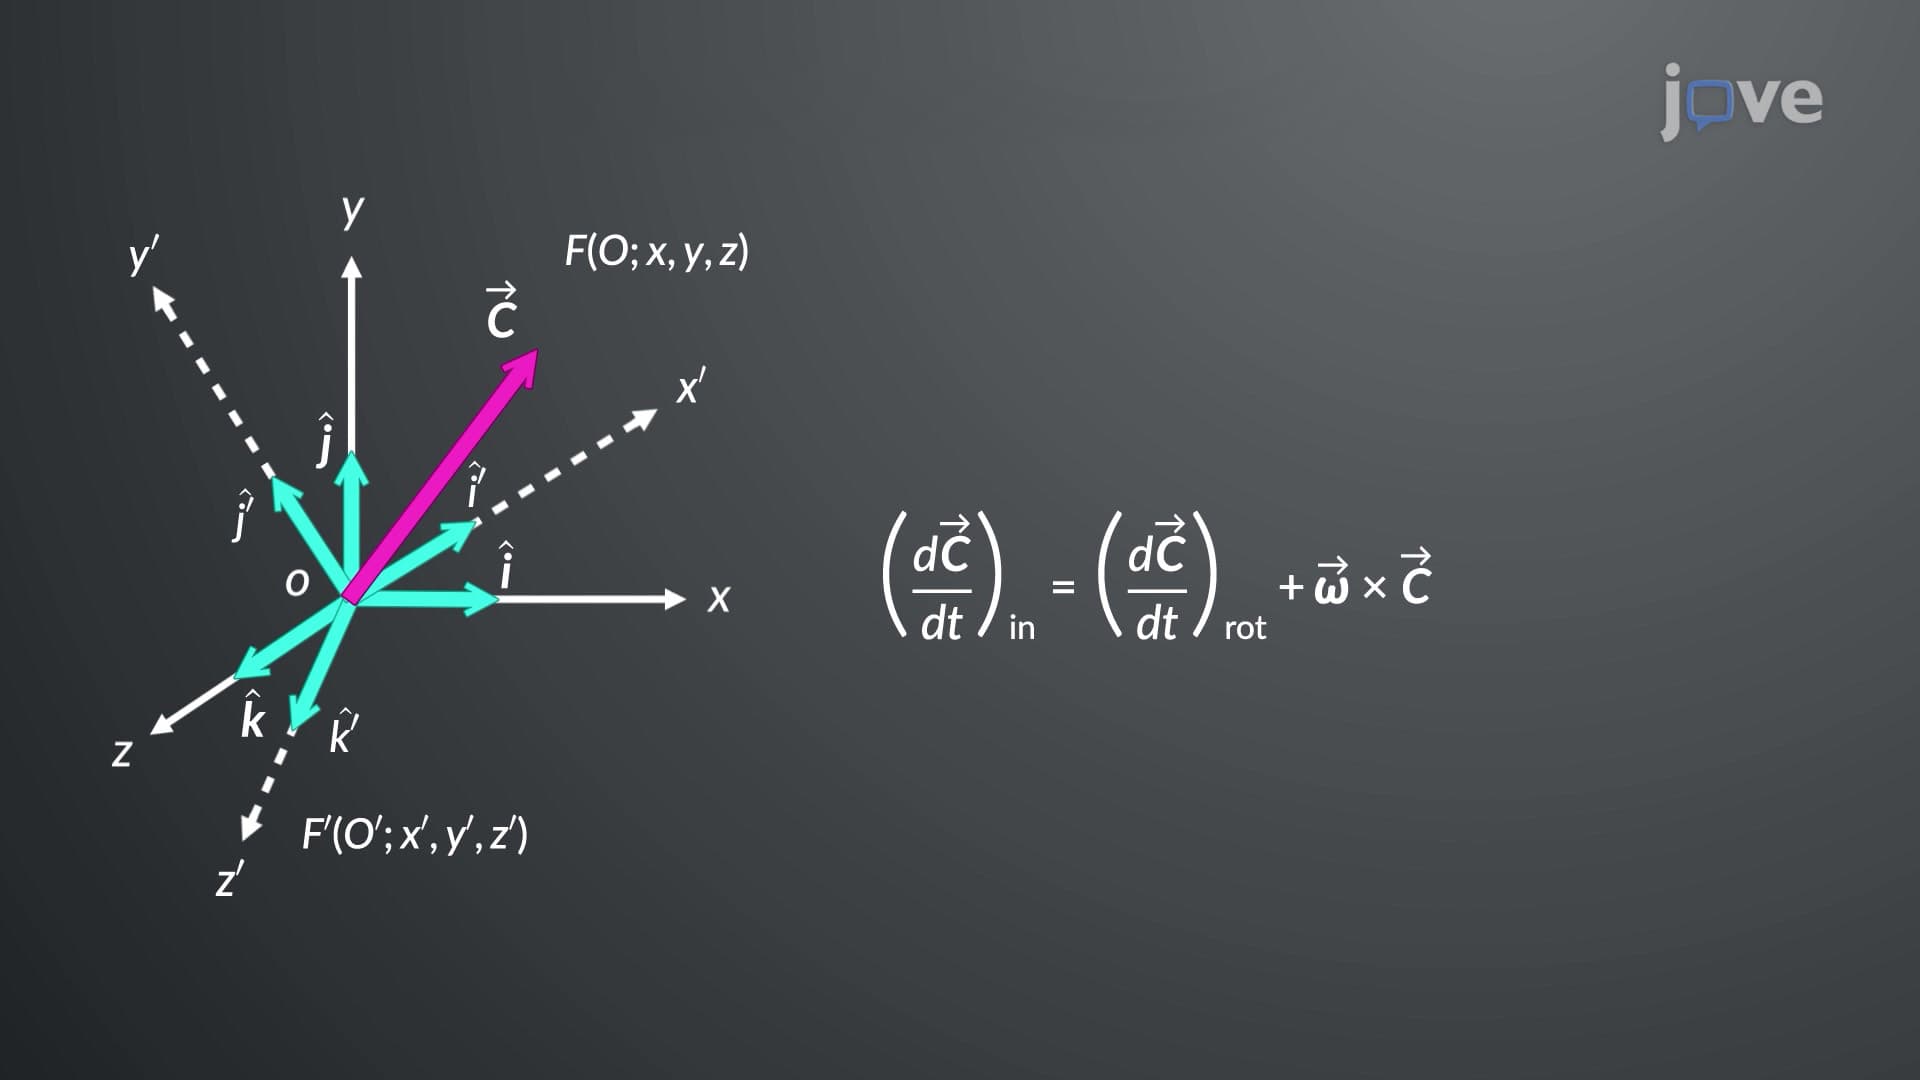
Vector Transformation in Rotating Coordinate Systems
 01:26
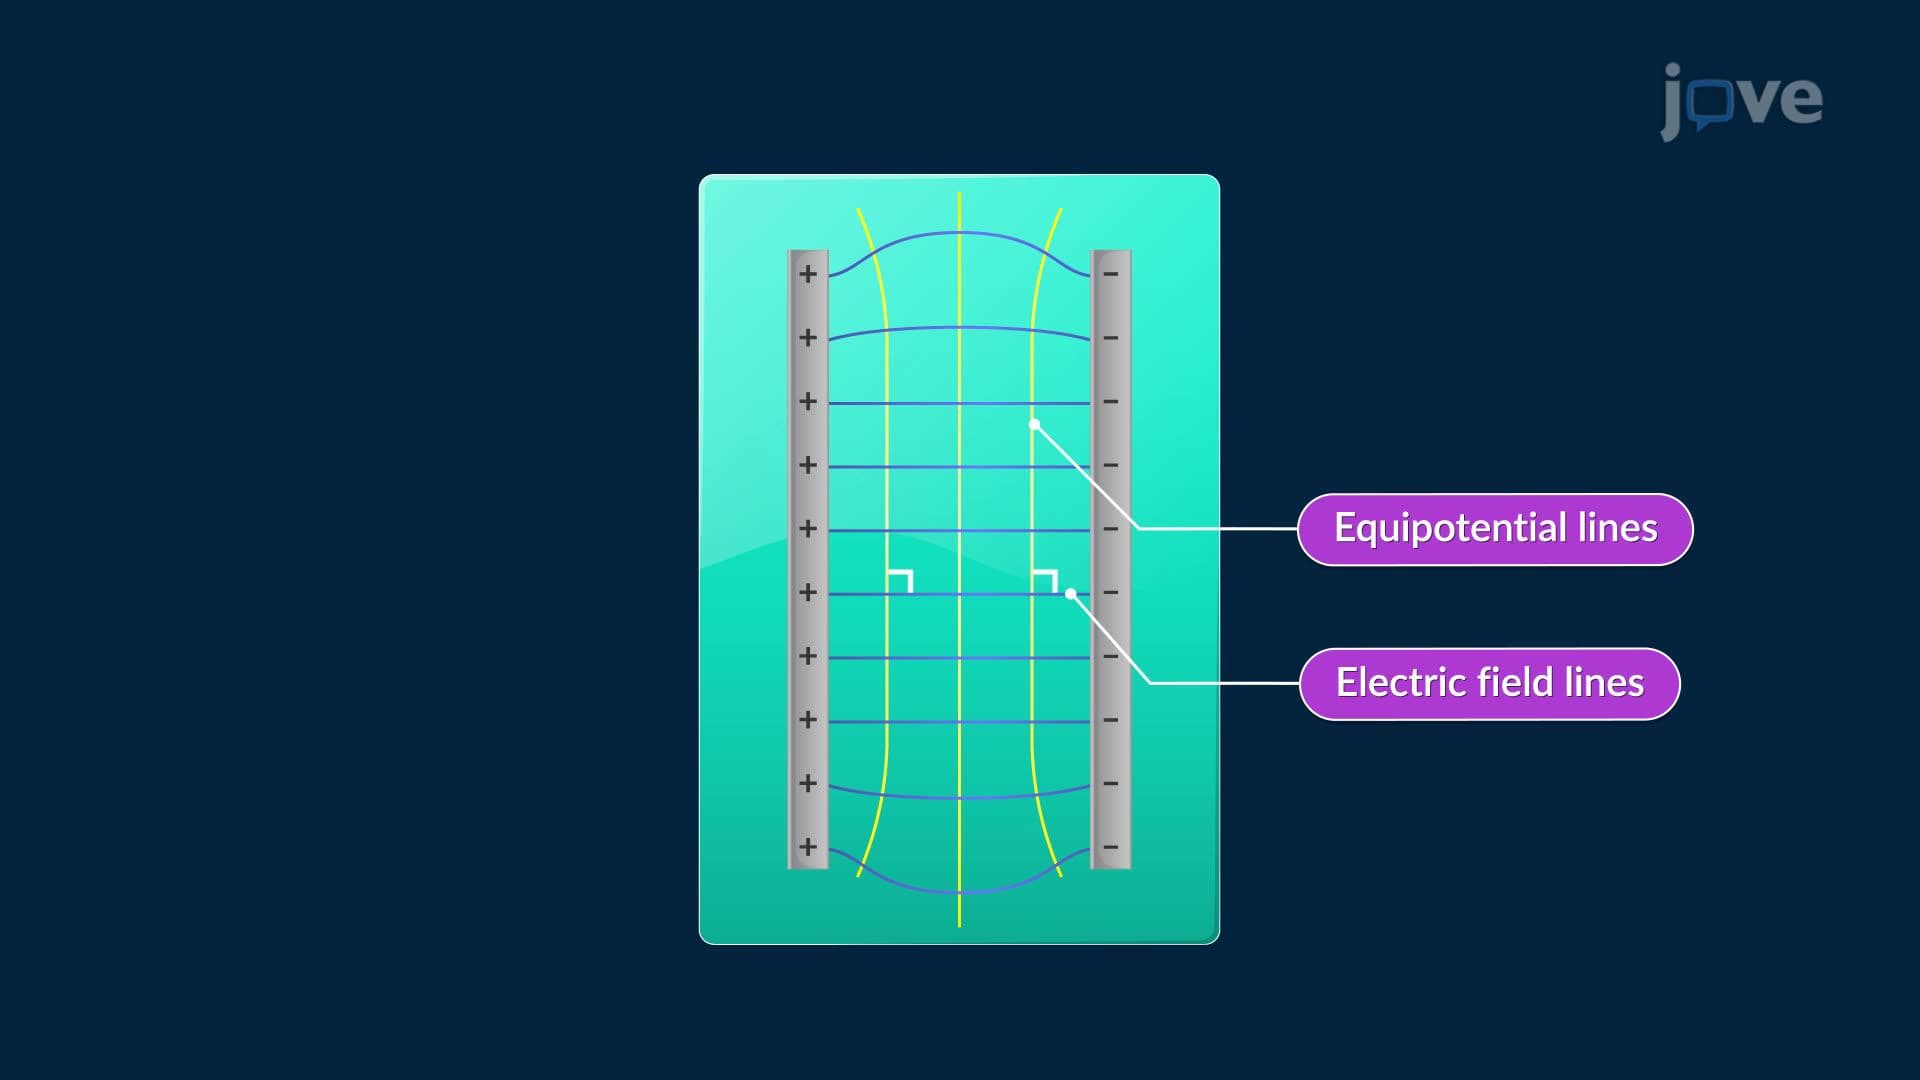
Orthogonal Trajectories
 01:26
Vectors in Space: Problem Solving
 01:15
Kinematic Equations: Problem Solving