Related Experiment Video
Updated: Oct 9, 2026
Subject-specific Musculoskeletal Model for Studying Bone Strain During Dynamic Motion
Published on: April 11, 2018
Methods for kinematic modeling of biological and robotic systems
M Ouerfelli1, V Kumar, W S Harwin
1St. Clair College of Applied Arts and Technology, 2000 Talbot Road West, Box 26, Ontario, N9A 654, Windsor, Canada. mouerfelli@stclairc.on.ca

Abstract:
The main objective is to develop methods that automatically generate kinematic models for the movements of biological and robotic systems. Two methods for the identification of the kinematics are presented. The first method requires the elimination of the displacement variables that cannot be measured while the second method attempts to estimate the changes in these variables. The methods were tested using a planar two-revolute-joint linkage. Results show that the model parameters obtained agree with the actual parameters to within 5%. Moreover, the methods were applied to model head and neck movements in the sagittal plane. The results indicate that these movements are well modeled by a two-revolute-joint system. A spatial three-revolute-joint model was also discussed and tested.

Related Concept Videos
 01:15
Kinematic Equations: Problem Solving
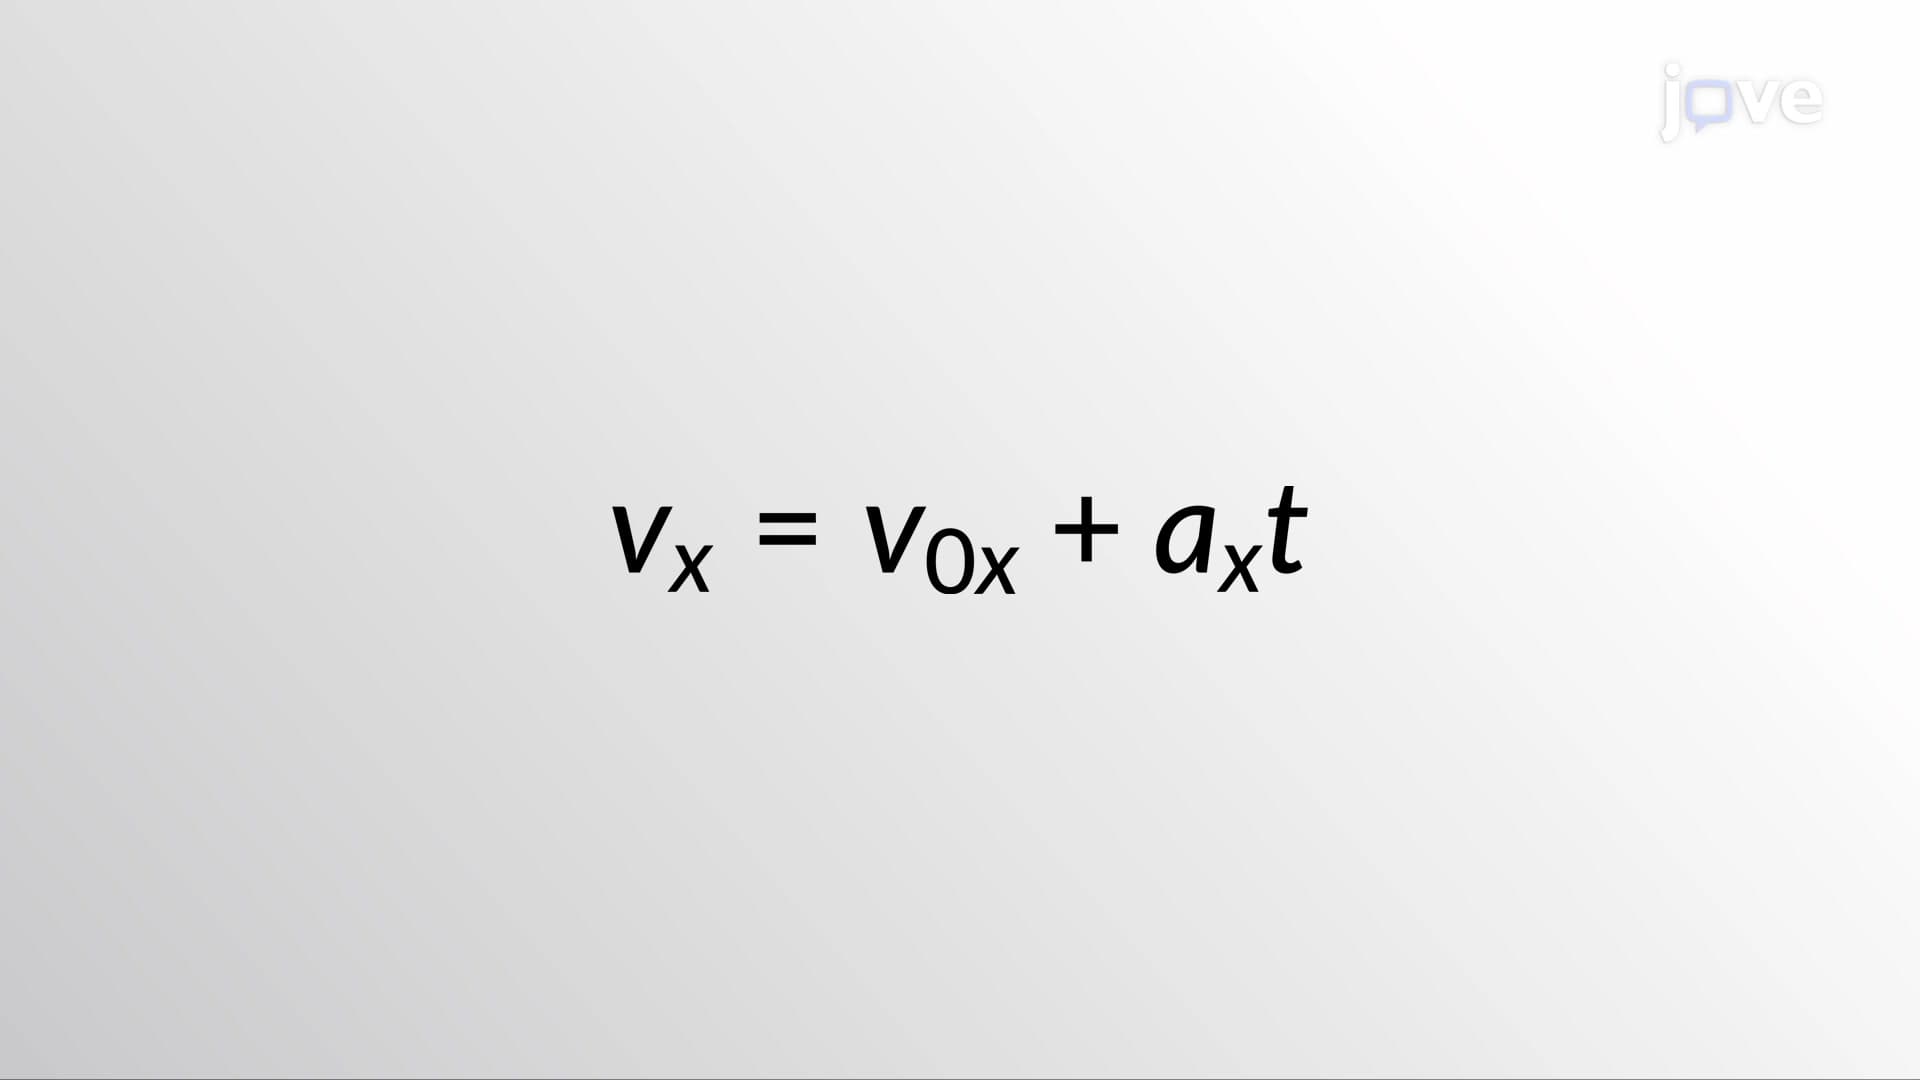 01:26
Kinematic Equations - I
 01:30
Kinematic Equations for Rotation
For instance, imagine a point A on a rigid body engaged in circular motion. The translational velocity of this particular point can be calculated by taking the time derivatives of the displacement equation, which essentially measures the...
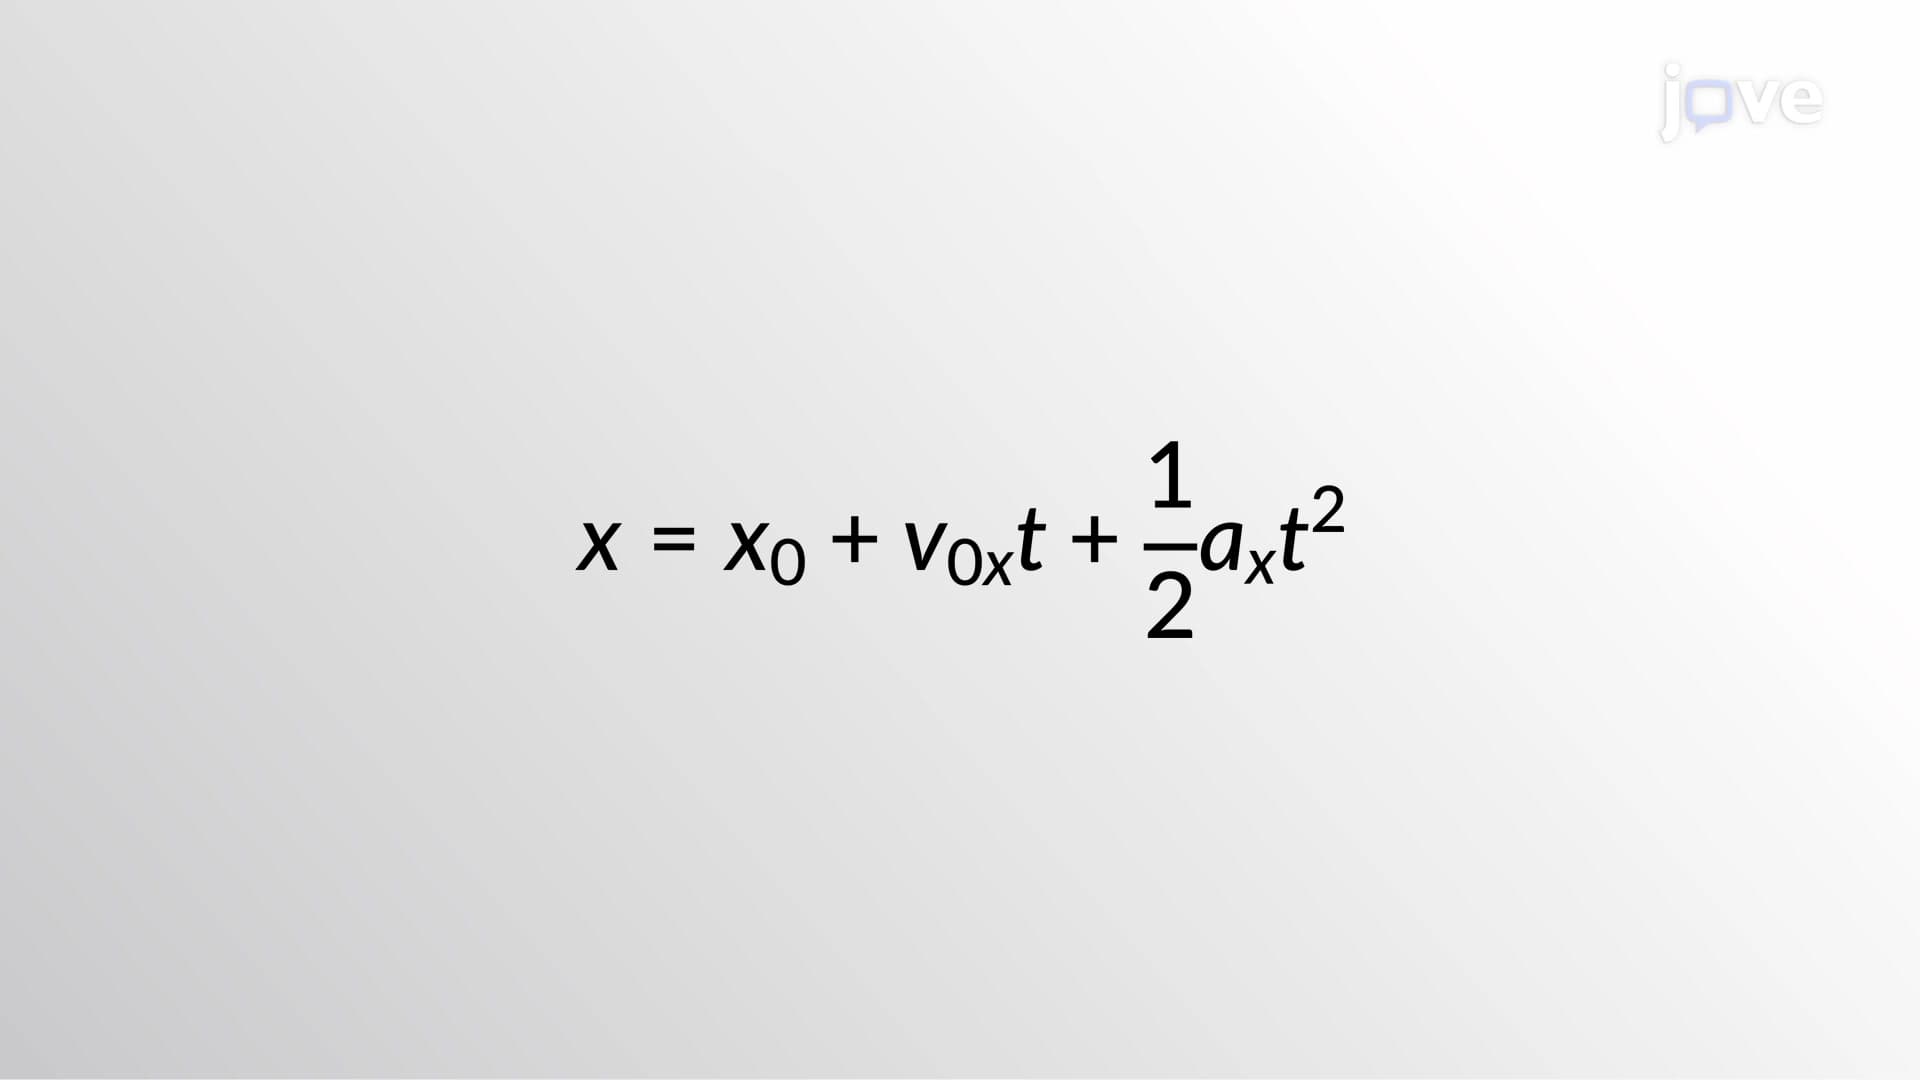 01:17
Kinematic Equations - II
Suppose a car merges into freeway traffic on a 200 m long ramp. If its initial velocity is 10 m/s and it accelerates at 2 m/s2, then the...
 01:18
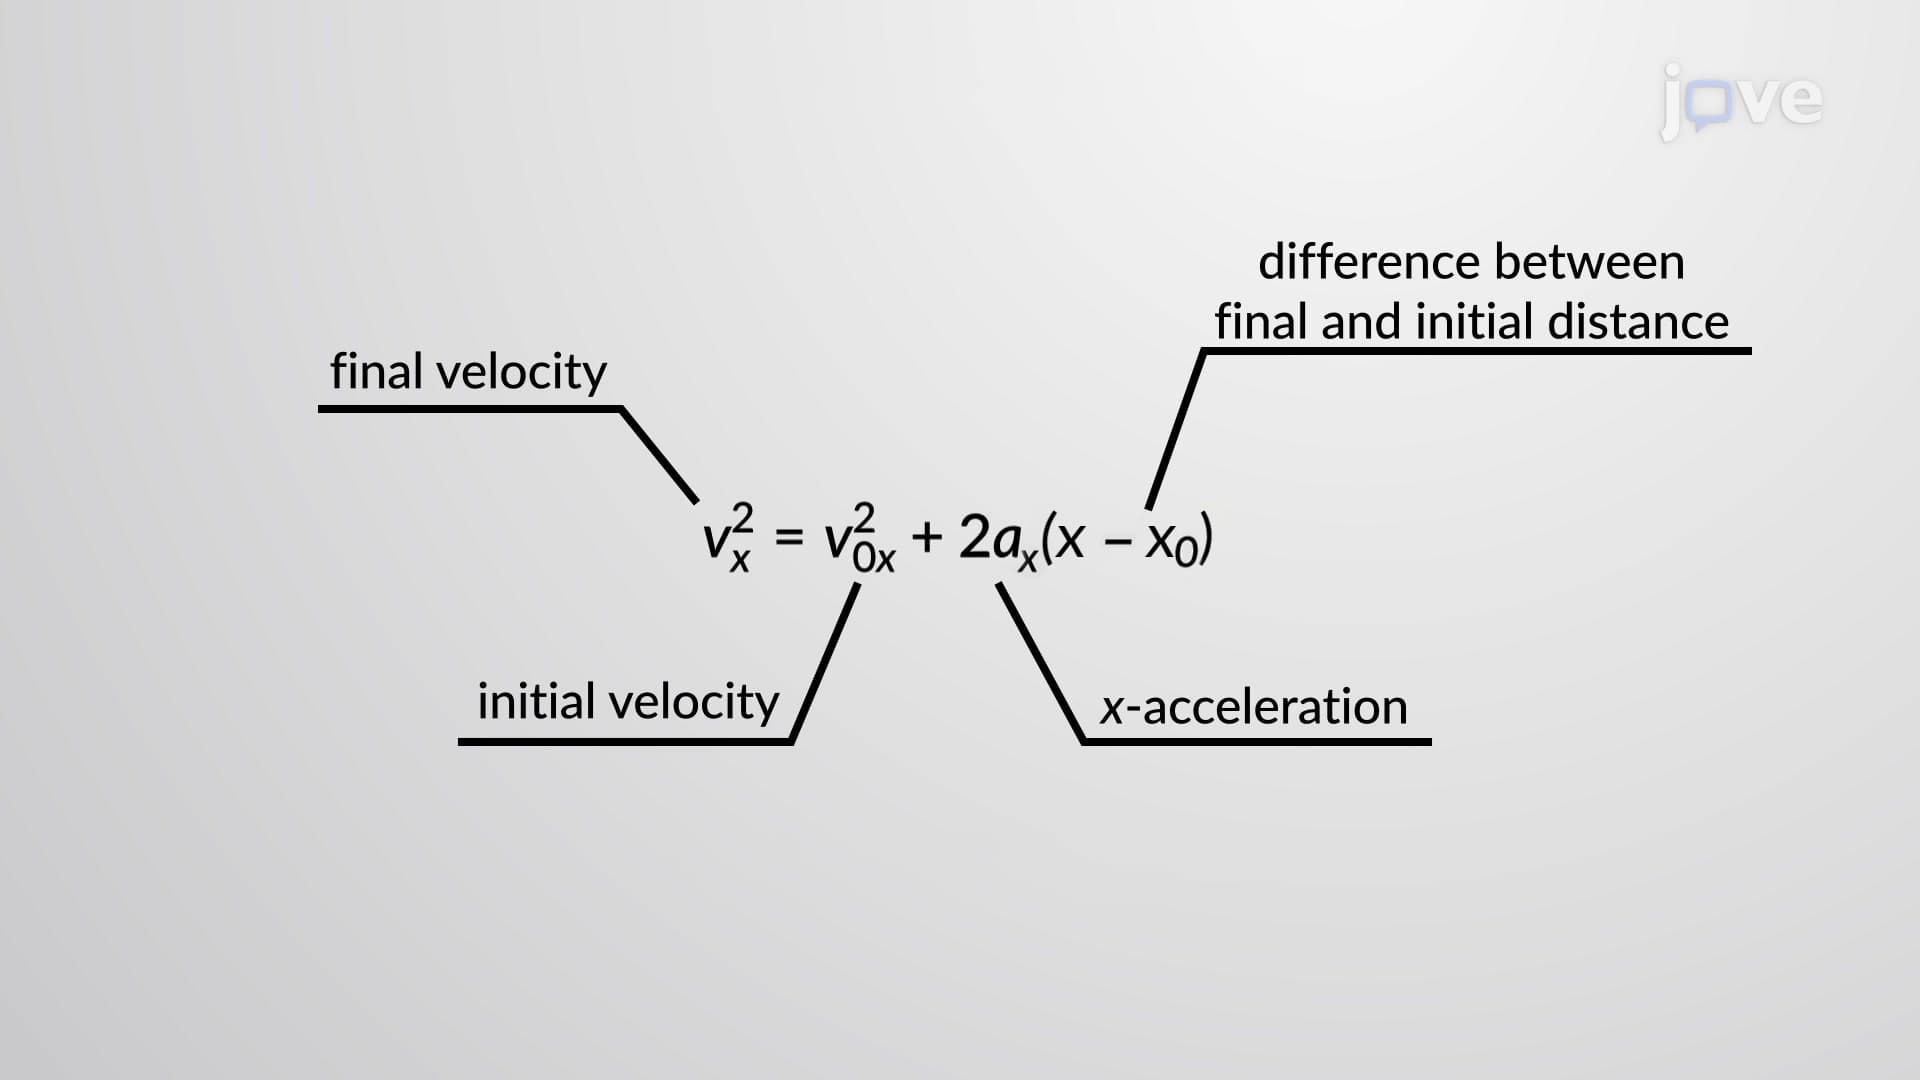
Kinematic Equations - III
Using the kinematic equations,...
 01:23
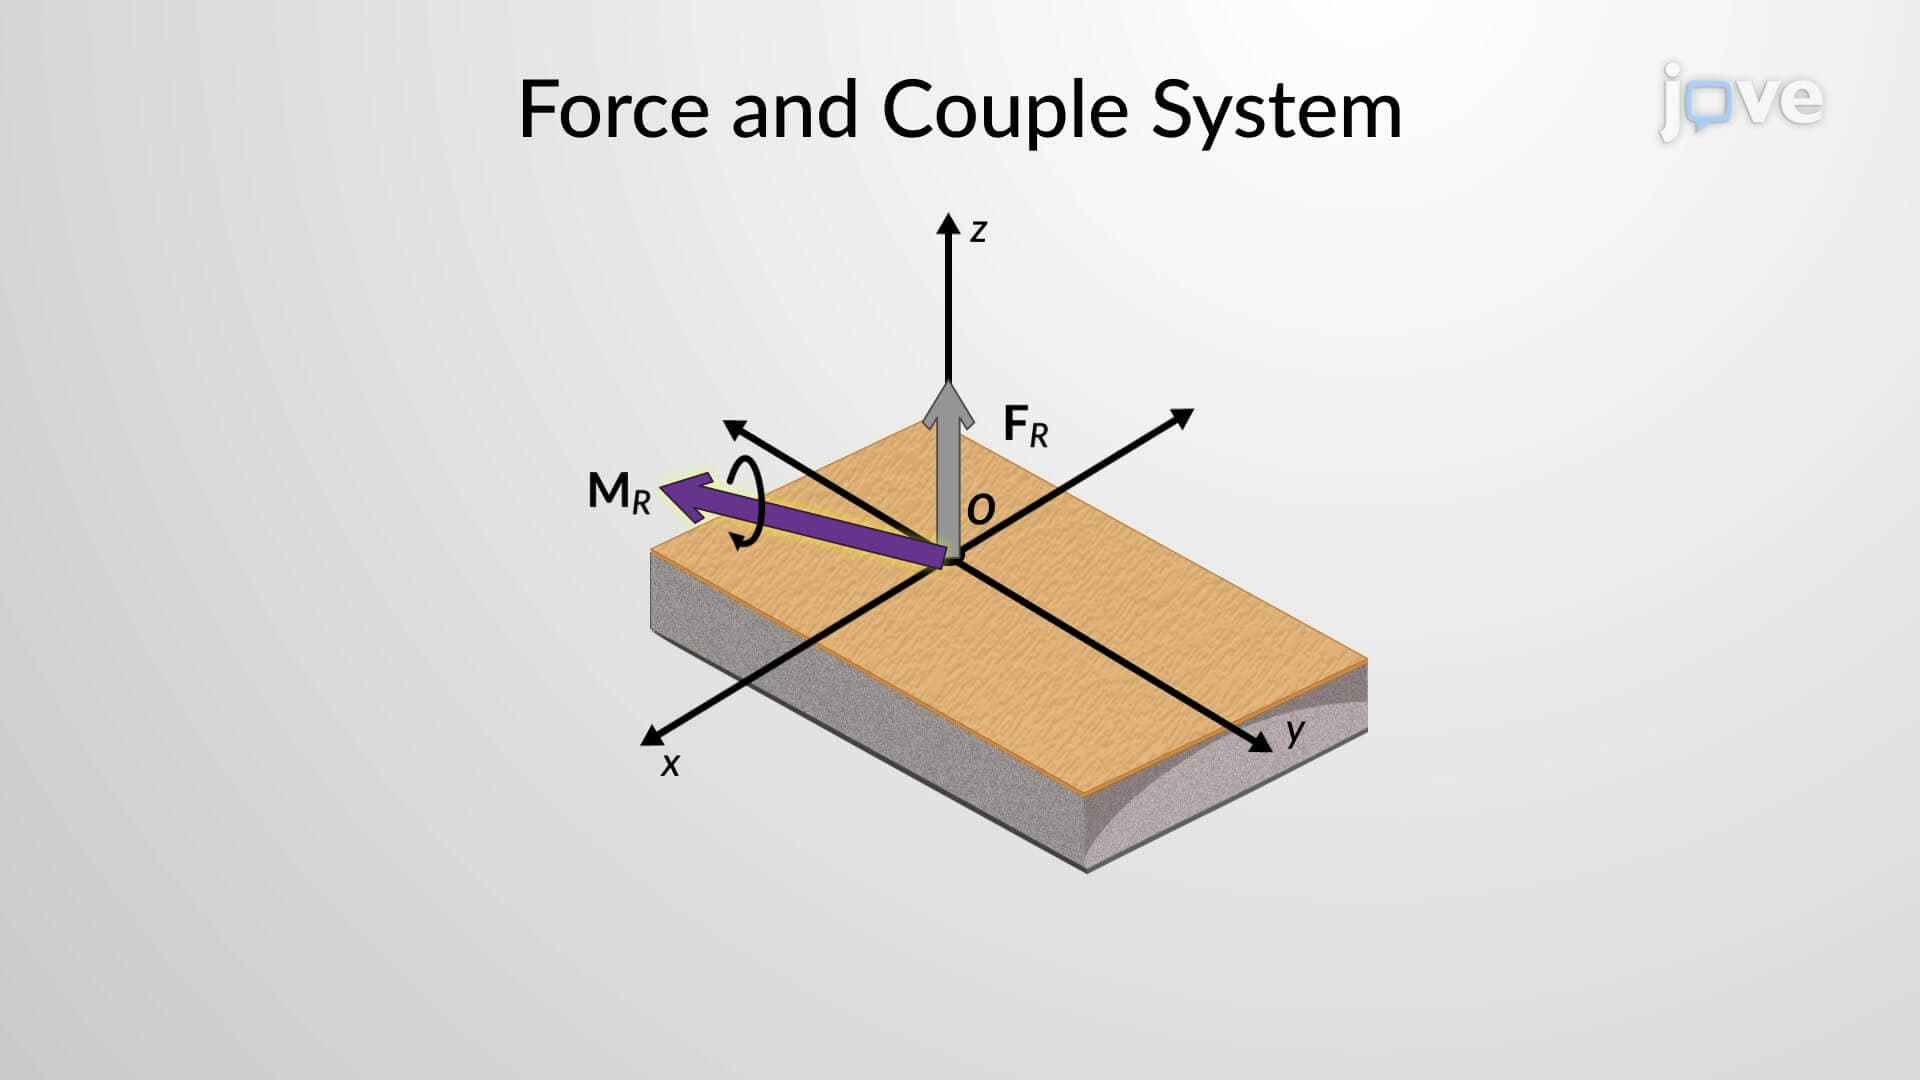
Simplification of a Force and Couple System: II