Related Experiment Video
Updated: Oct 25, 2026
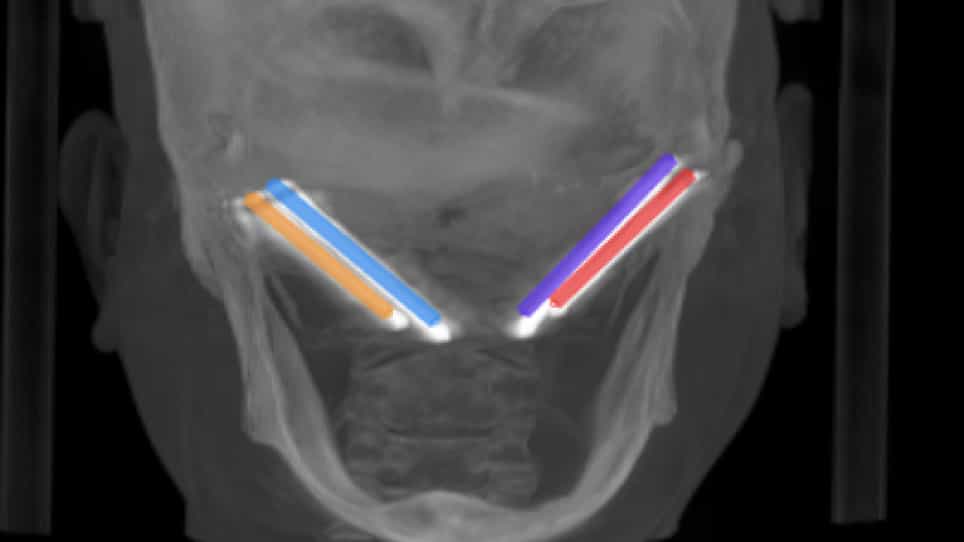
Real-Time Dynamic Navigation System for the Precise Quad-Zygomatic Implant Placement in a Patient with a Severely Atrophic Maxilla
Published on: October 18, 2021
Force-Torque Classification of Reference-Profile-Defined Drilling States During Robot-Assisted Dental Implant
Jiaqiang Li1, Yangdong Wu2, Yao Wang2
1Key Laboratory of Advanced Manufacturing Technology, Guizhou University, Huaxi campus, No.515,Jiaxiunanlu Road, Guiyang, Guizhou, 550025, China.

Purpose:
To evaluate whether force-torque features can classify three predefined, reference-profile-defined operational drilling states during robot-assisted implant osteotomy under specimen-level separation. Materials and Methods: Thirty porcine hemimandibular specimens underwent 180 robot-controlled osteotomies under three drilling conditions. Axial force (Fz) and drilling torque (Mz) were sampled at 1000 Hz, segmented into 100-ms windows with a 50-ms step, and represented by 42 time-, frequency-, and wavelet-domain features; 23 features were selected using training-only ANOVA ranking and correlation pruning. Specimens were separated into training, validation, and held-out test sets (18/6/6). Linear support vector machine (SVM), random forest (RF), and XGBoost were evaluated against predefined depth-indexed operational reference profiles; a same-acquisition CBCT rule served as an imaging comparator. Results: The dataset contained 92,675 overlapping windows. On six held-out specimens (36 osteotomies; 18,496 windows), XGBoost achieved 93.0% accuracy (specimen-clustered 95% CI, 92.0-94.0%), 82.9% balanced accuracy, and 85.6% macro-F1. RF and SVM accuracies were 90.5% and 88.8%, respectively. The CBCT rule achieved 92.3% accuracy but lower balanced accuracy (80.1%) and transitional recall (51.1%). XGBoost transitional recall was 59.6%, increasing to 73.0% in a weighted sensitivity configuration at the cost of lower overall accuracy. Accuracy decreased from 94.1% away from class boundaries to 75.6% in boundary-adjacent windows. Conclusion: Force-torque features differentiated the three predefined reference-profile-defined drilling states under specimen-separated evaluation. XGBoost achieved the highest classification performance, with errors concentrated primarily in transitional and boundary-adjacent windows. Keywords: robot-assisted implant osteotomy; force-torque sensing; reference-profile classification; drilling-state classification; XGBoost; specimen-level validation .